Next
Papers near this one.
Walkthroughs
 7:55
CASH: Capability-Aware Shared Hypernetworks for Flexible Heterogeneous Multi-Robot Coordination
shares Collaboration 5:39
ReCoDe: Reinforcement Learning-based Dynamic Constraint Design for Multi-Agent Coordination
shares Distributed control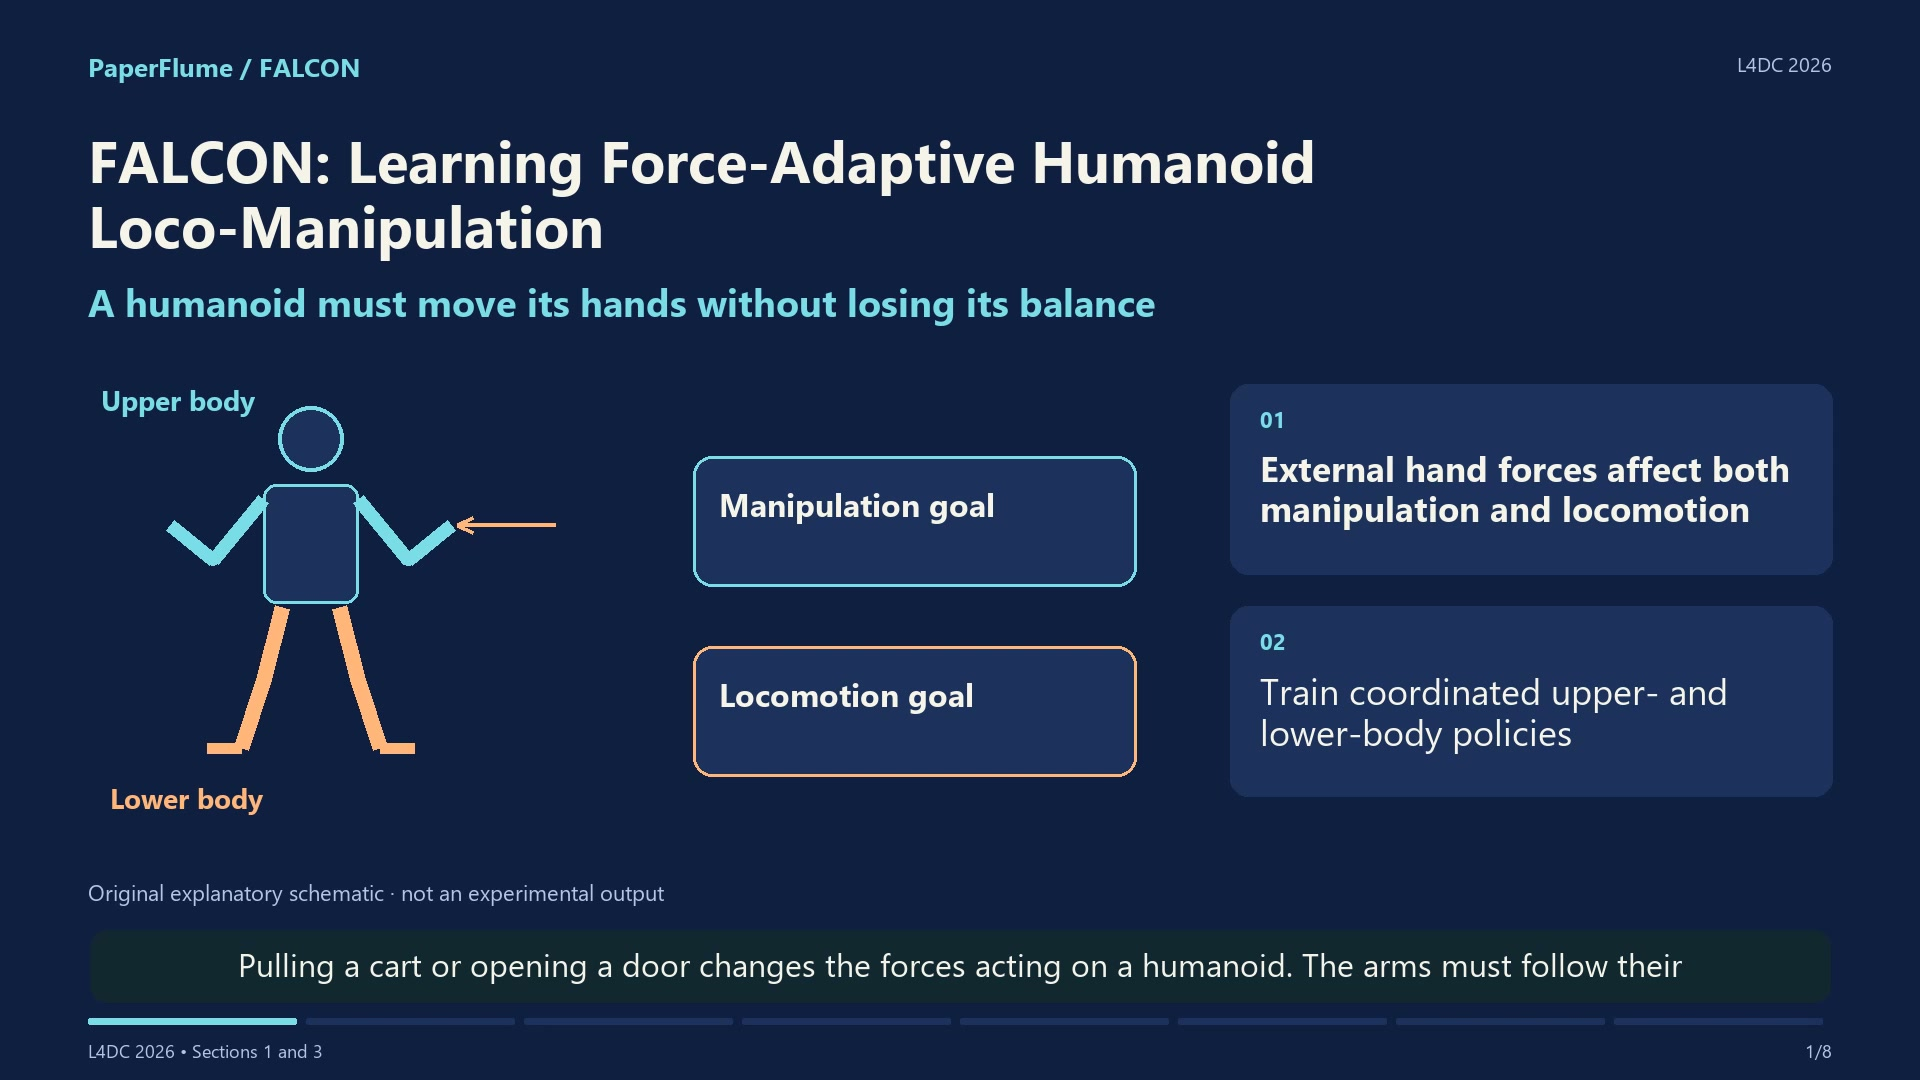 6:22
FALCON: Learning Force-Adaptive Humanoid Loco-Manipulation
shares Mobile manipulationShort cuts
 1:08
CASH: Capability-Aware Shared Hypernetworks for Flexible Heterogeneous Multi-Robot Coordination
shares Collaboration 0:54
ReCoDe: Reinforcement Learning-based Dynamic Constraint Design for Multi-Agent Coordination
shares Distributed control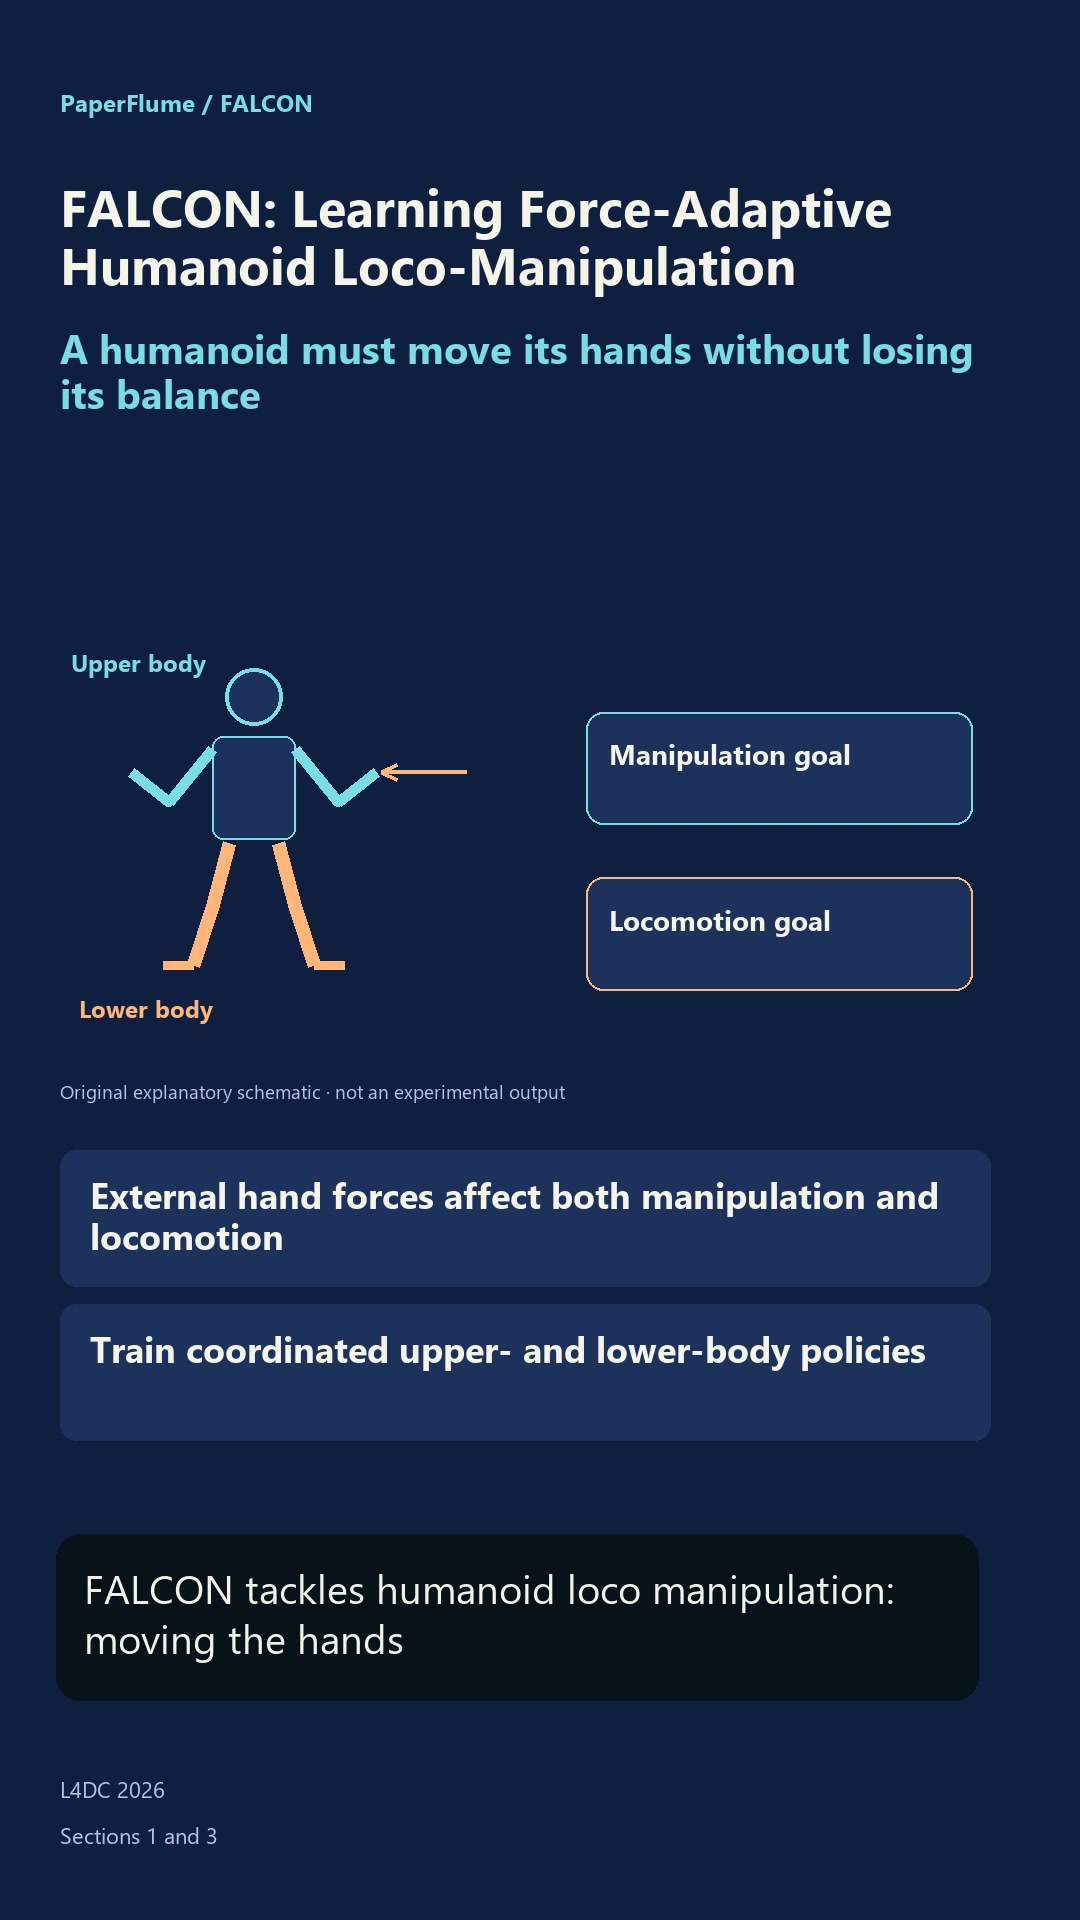 1:02