Library
Two fields today. More on the way.
Robotics and computer vision. Other STEM fields are being added.
Recently added
 6:45
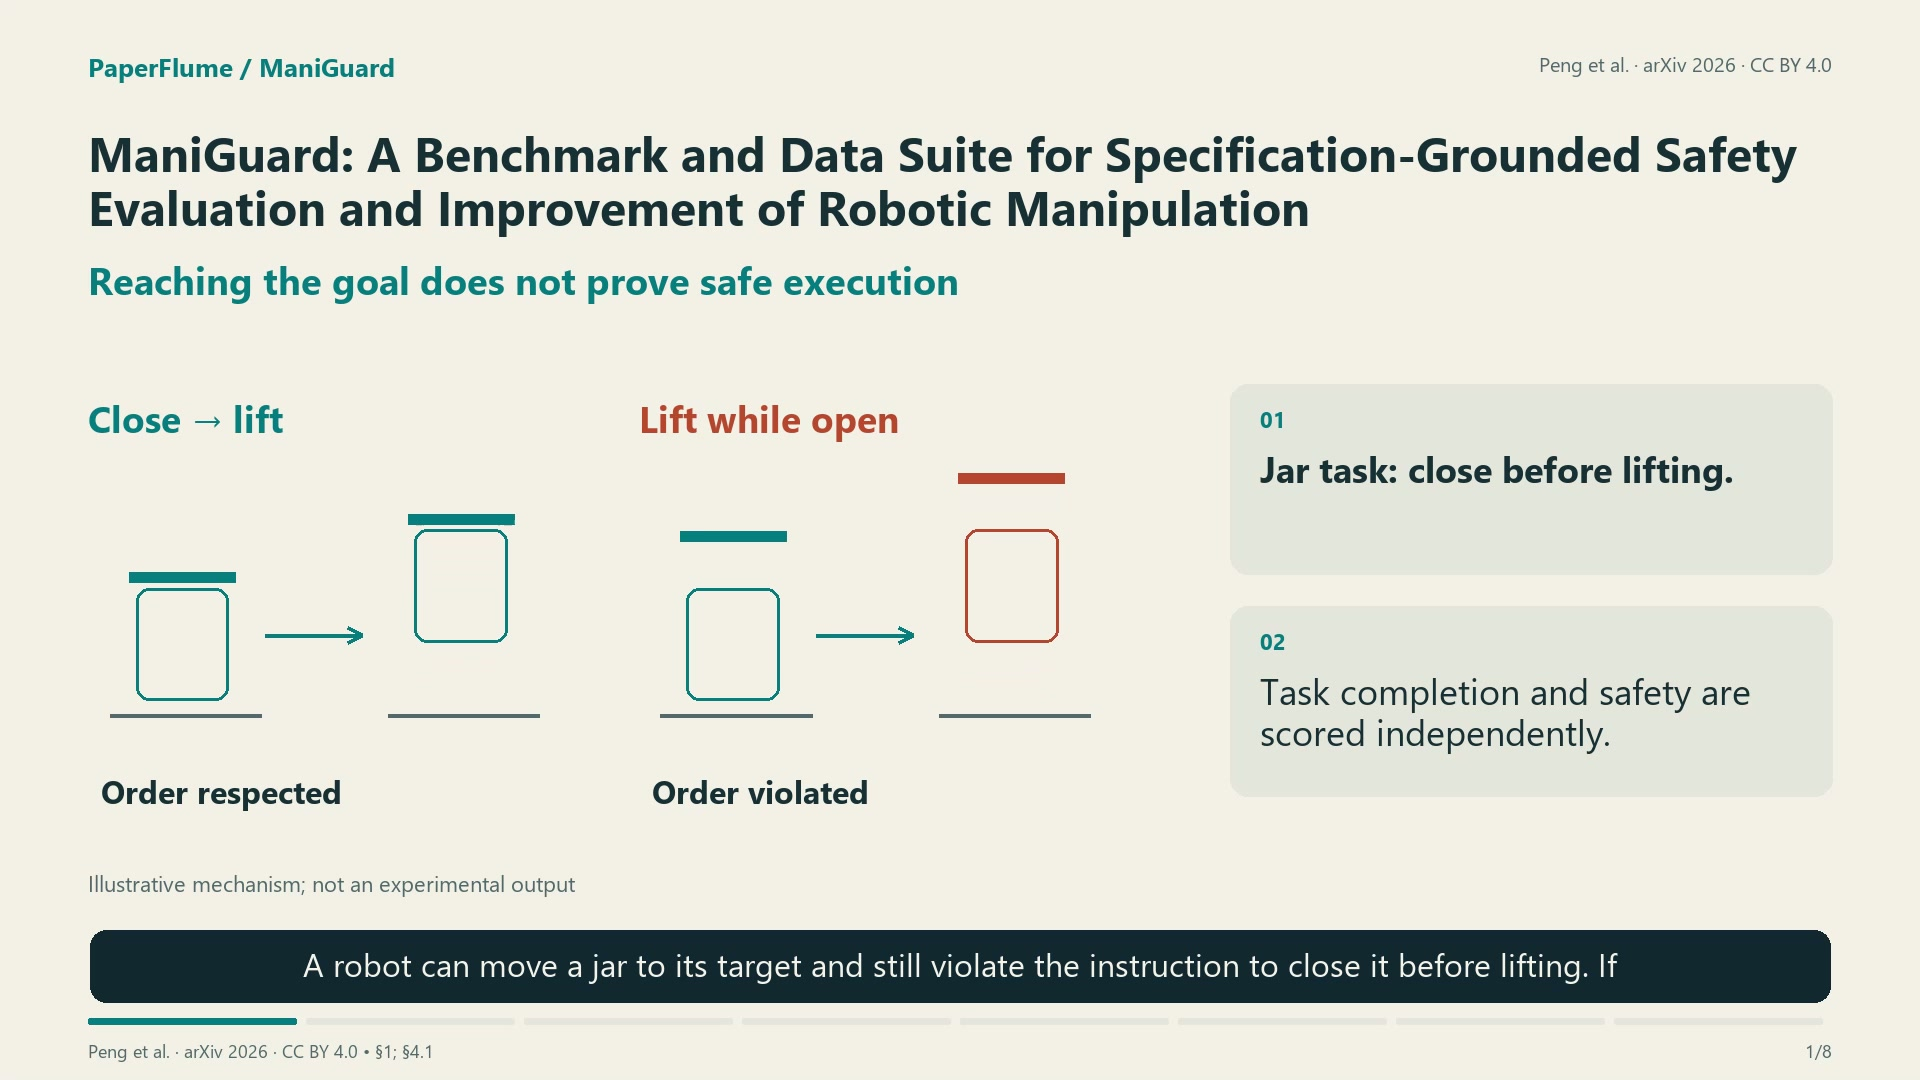
ManiGuard: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
VLA models · deck
2608.17386
 6:45
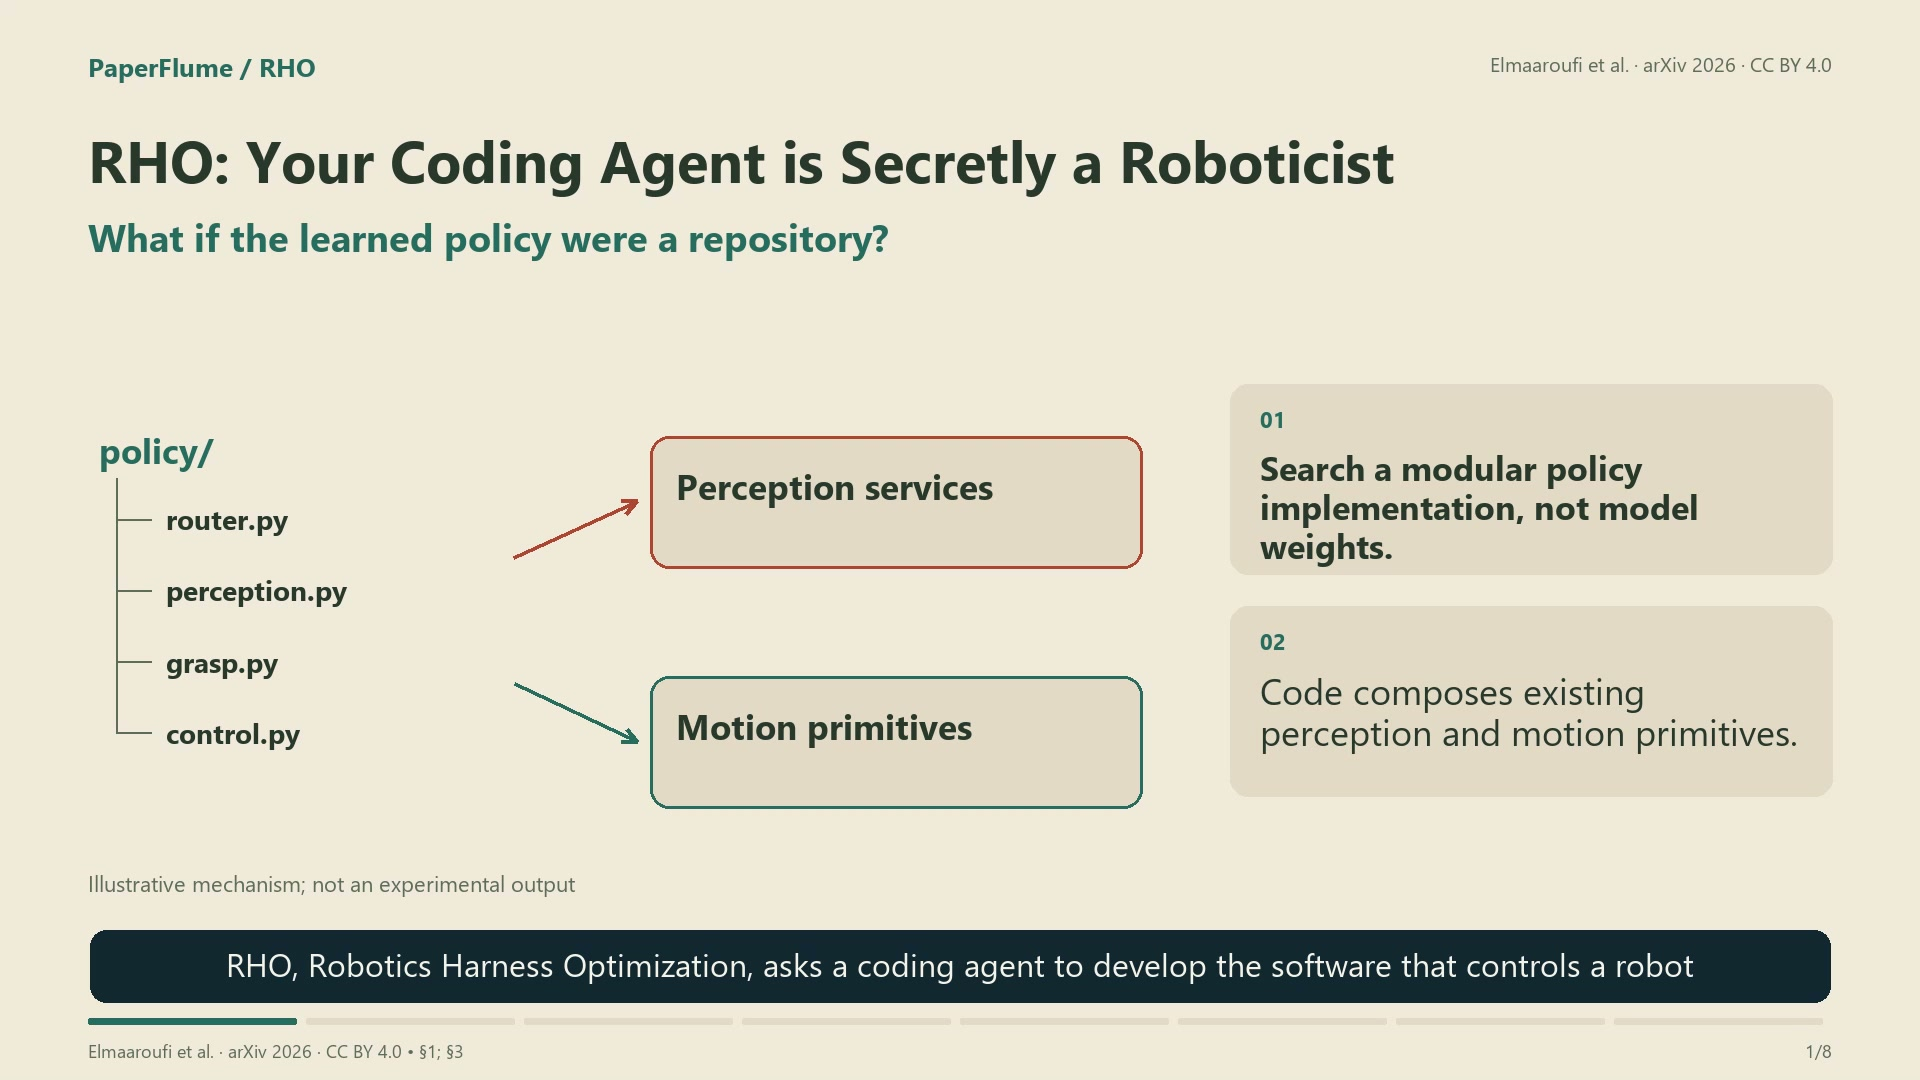
RHO: Your Coding Agent is Secretly a Roboticist
Multimodal LLMs · deck
2606.16458
 6:10
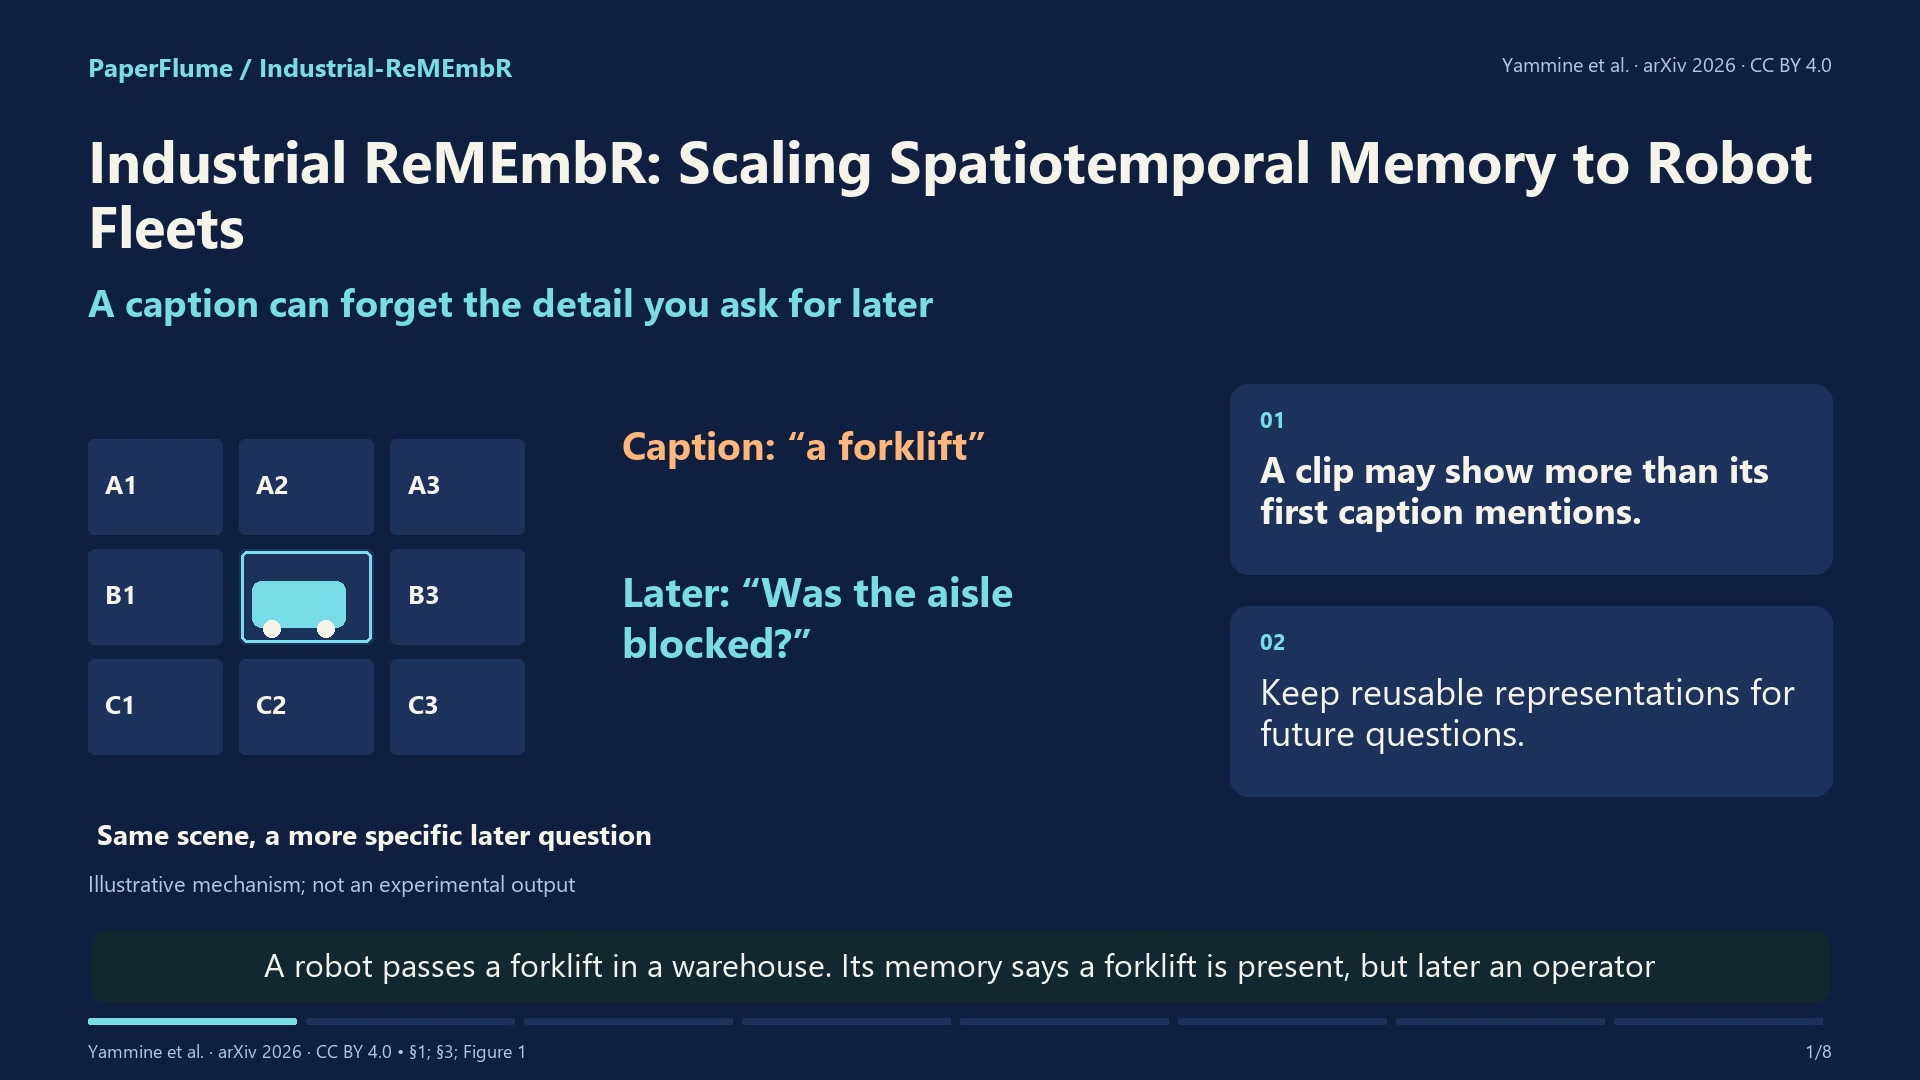
Industrial ReMEmbR: Scaling Spatiotemporal Memory to Robot Fleets
Video understanding · deck
2610.28624
 5:47
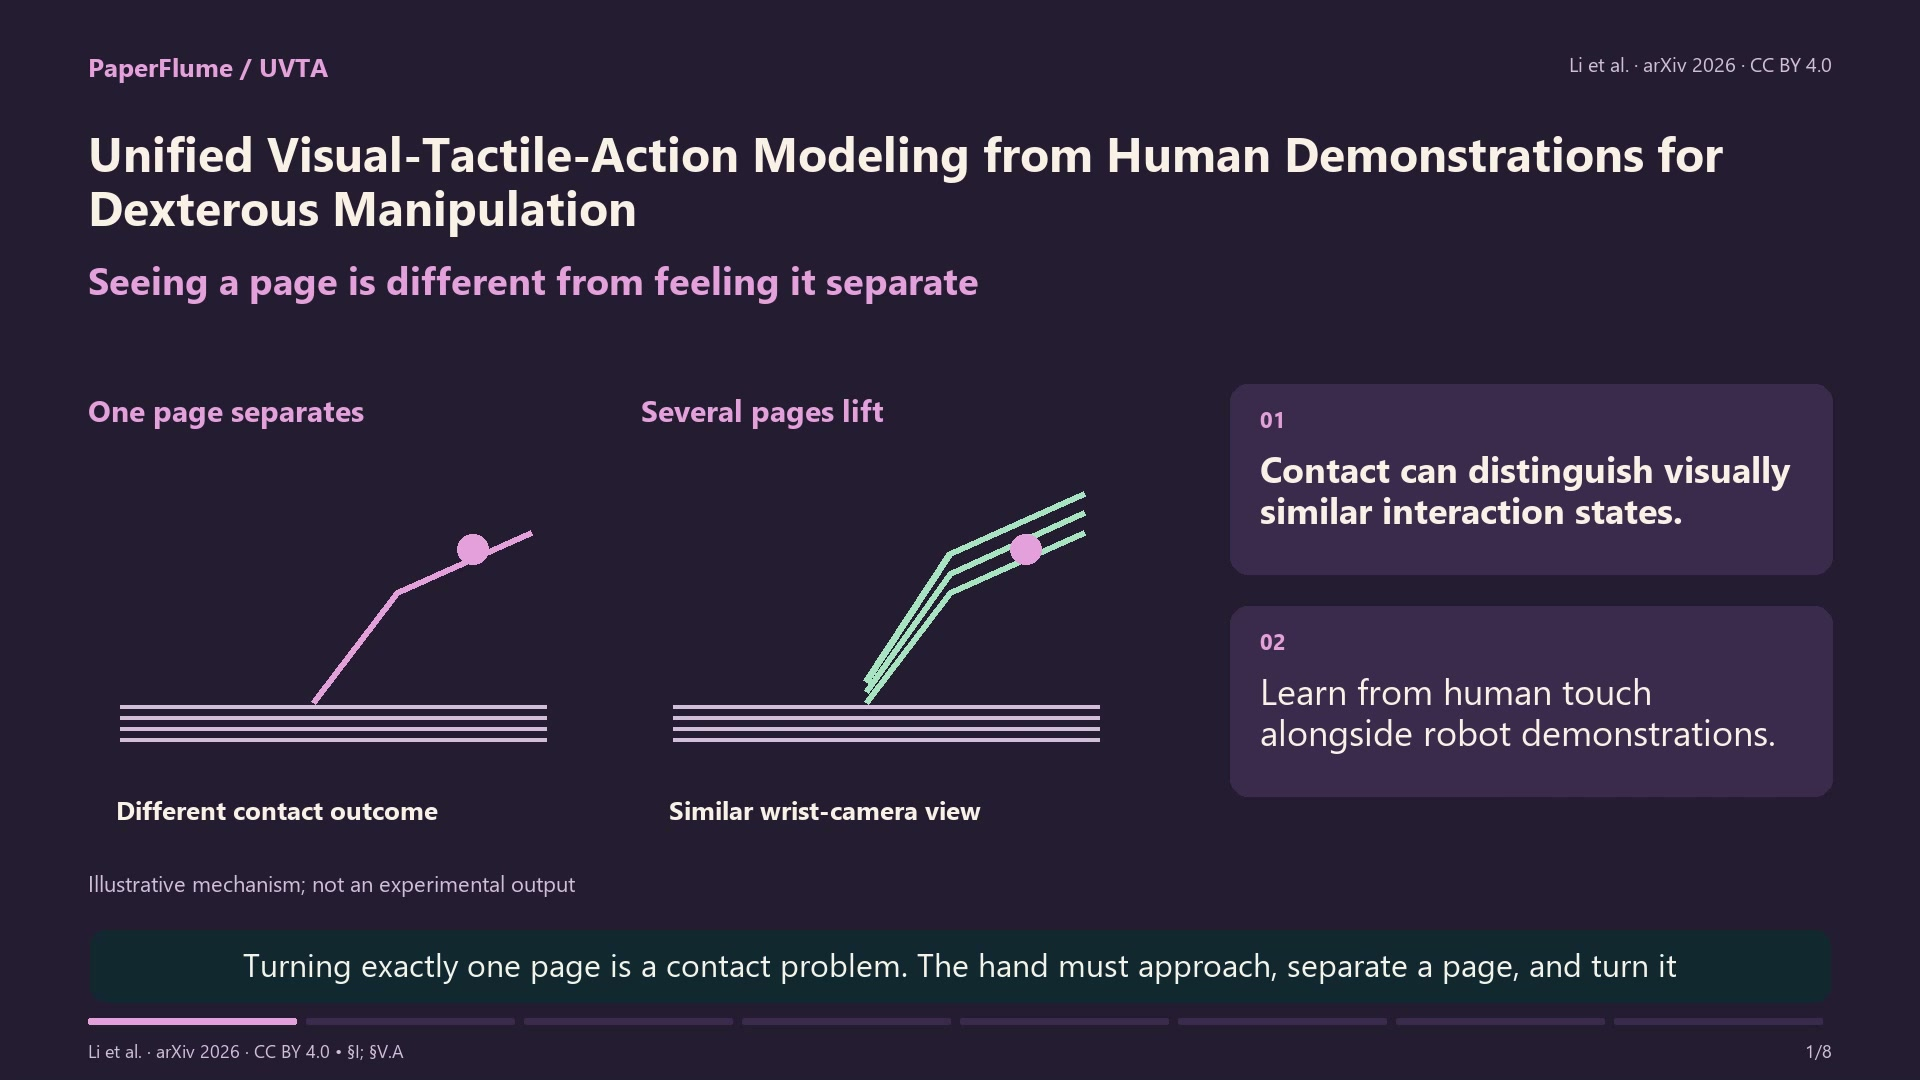
Unified Visual-Tactile-Action Modeling from Human Demonstrations for Dexterous Manipulation
Dexterous hands · deck
2609.34182
 6:42
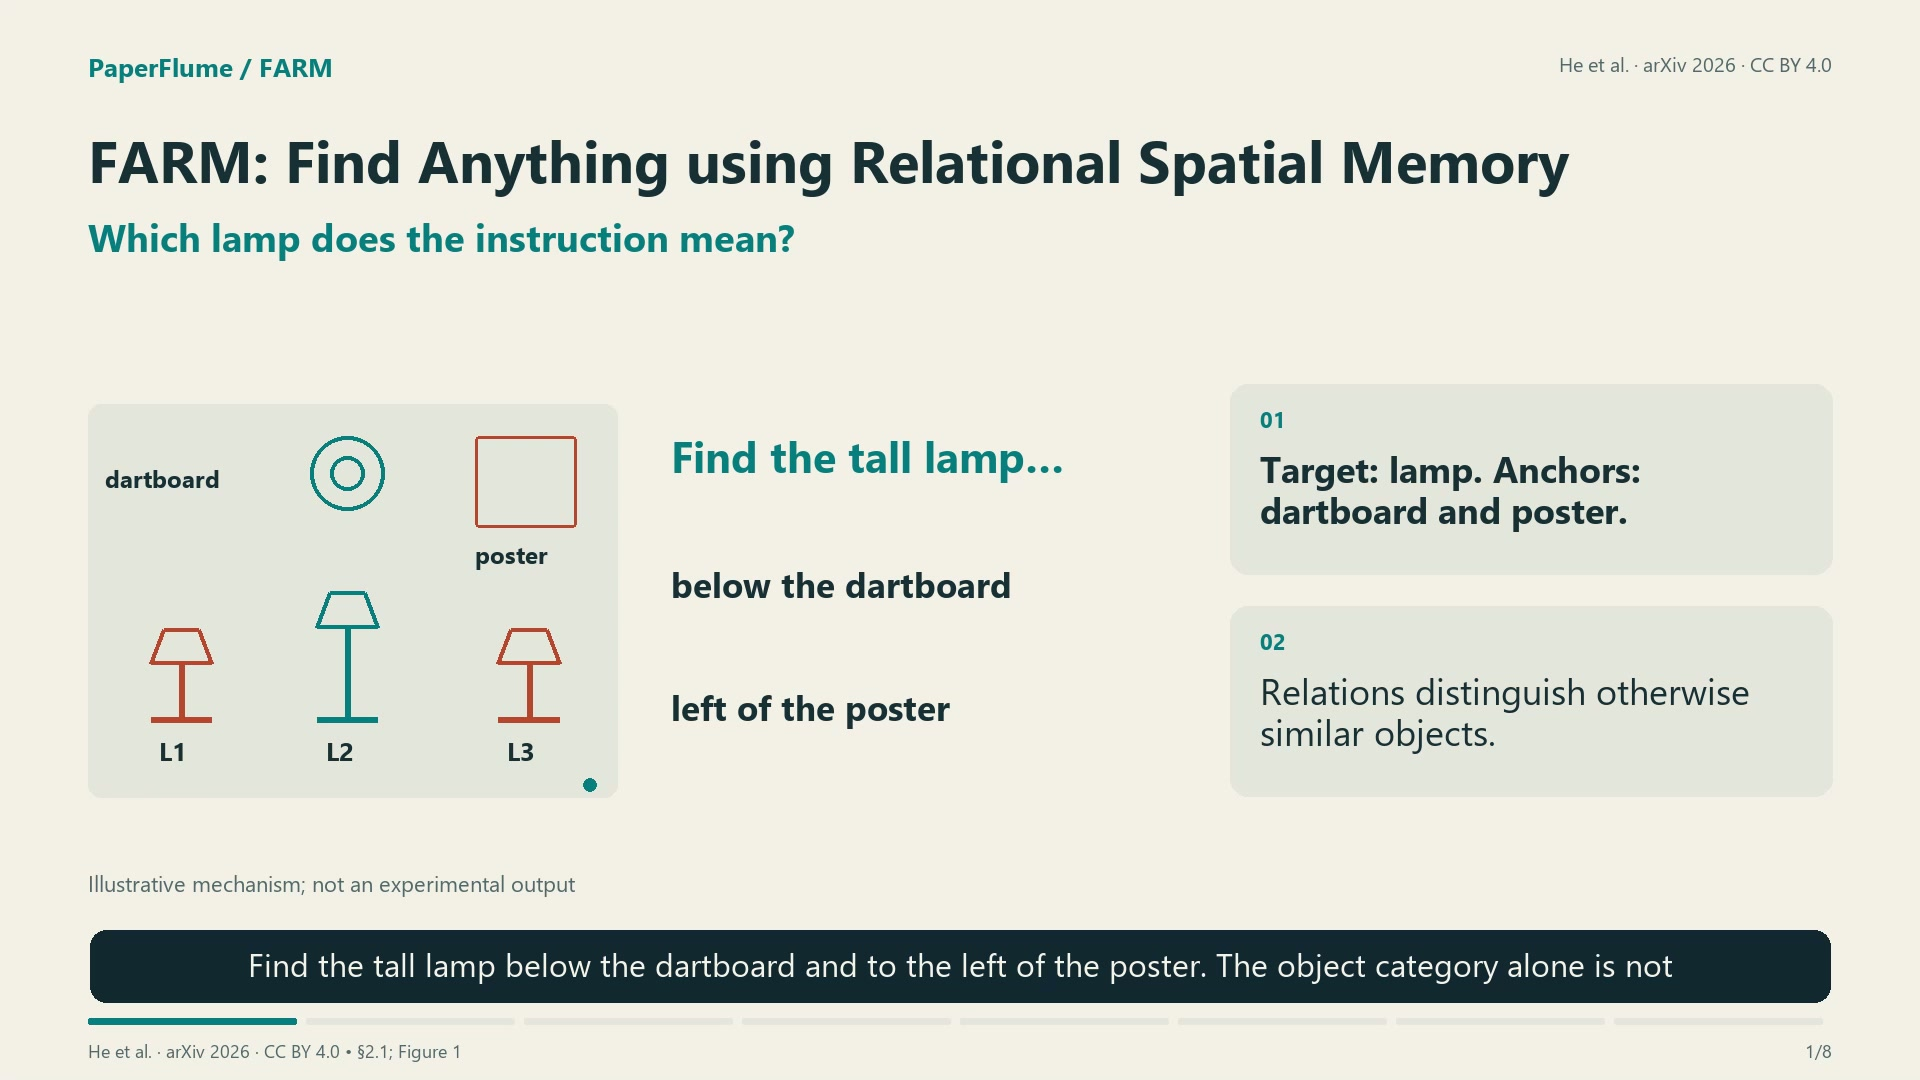
FARM: Find Anything using Relational Spatial Memory
Open-vocabulary perception · deck
2606.15476
 8:24
Foundation4D: Towards a unified perception and reconstruction model for autonomous vehicles
Gaussian splatting · deck
2610.30340
 7:13
FLEX-WAM: Flexible Block-Causal World-Action Models for Long-Horizon Imagination and Planning
VLA models · deck
2610.05483
 6:28
Long-WAM: Scaling the Context of World-Action Models
VLA models · deck
2610.10528
 7:04
Agentic World Action Models
VLA models · deck
2610.30136
 5:39
Multimodal Fused Learning for Solving the Generalized Traveling Salesman Problem in Robotic Task Planning
Task allocation · deck
 5:46
ObjectReact: Learning Object-Relative Control for Visual Navigation
· deck
 5:27
Residual Neural Terminal Constraint for MPC-based Collision Avoidance in Dynamic Environments
Model predictive control · deck
 5:01
TinyMIG: Transferring Generalization from Vision Foundation Models to Single-Domain Medical Imaging
· deck
 5:24
CogniPlan: Uncertainty-Guided Path Planning with Conditional Generative Layout Prediction
Informative path planning · deck
 5:28
Learning Smooth State-Dependent Traversability from Dense Point Clouds
Point cloud understanding · deck
 5:38
Distribution-aware Fairness Learning in Medical Image Segmentation From A Control-Theoretic Perspective
Medical image segmentation · deck
 4:39
iDPA: Instance Decoupled Prompt Attention for Incremental Medical Object Detection
Continual learning · deck
 5:42
L-Diffusion: Laplace Diffusion for Efficient Pathology Image Segmentation
Diffusion models · deck
 4:58
Learning Long-Horizon Robot Manipulation Skills via Privileged Action
· deck
 6:14
SPIN: distilling Skill-RRT for long-horizon prehensile and non-prehensile manipulation
· deck
Motion planning and control
See all 20 →
6:45
ManiGuard: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
VLA models · deck
2608.17386
6:45
RHO: Your Coding Agent is Secretly a Roboticist
Multimodal LLMs · deck
2606.16458
5:27
Residual Neural Terminal Constraint for MPC-based Collision Avoidance in Dynamic Environments
Model predictive control · deck
6:14
SPIN: distilling Skill-RRT for long-horizon prehensile and non-prehensile manipulation
· deck
 5:32
Multi-critic Learning for Whole-body End-effector Twist Tracking
RL for control · deck
 5:21
Multi-Loco: Unifying Multi-Embodiment Legged Locomotion via Reinforcement Learning Augmented Diffusion
RL for control · deck
 10:43
TopoCut: Learning Multi-Step Cutting with Spectral Rewards and Discrete Diffusion Policies
RL for control · deck
 6:35
ReWiND: Language-Guided Rewards Teach Robot Policies without New Demonstrations
RL for control · deck
 6:27
Geometric Red-Teaming for Robotic Manipulation
Safe control and safety filters · deck
 6:24
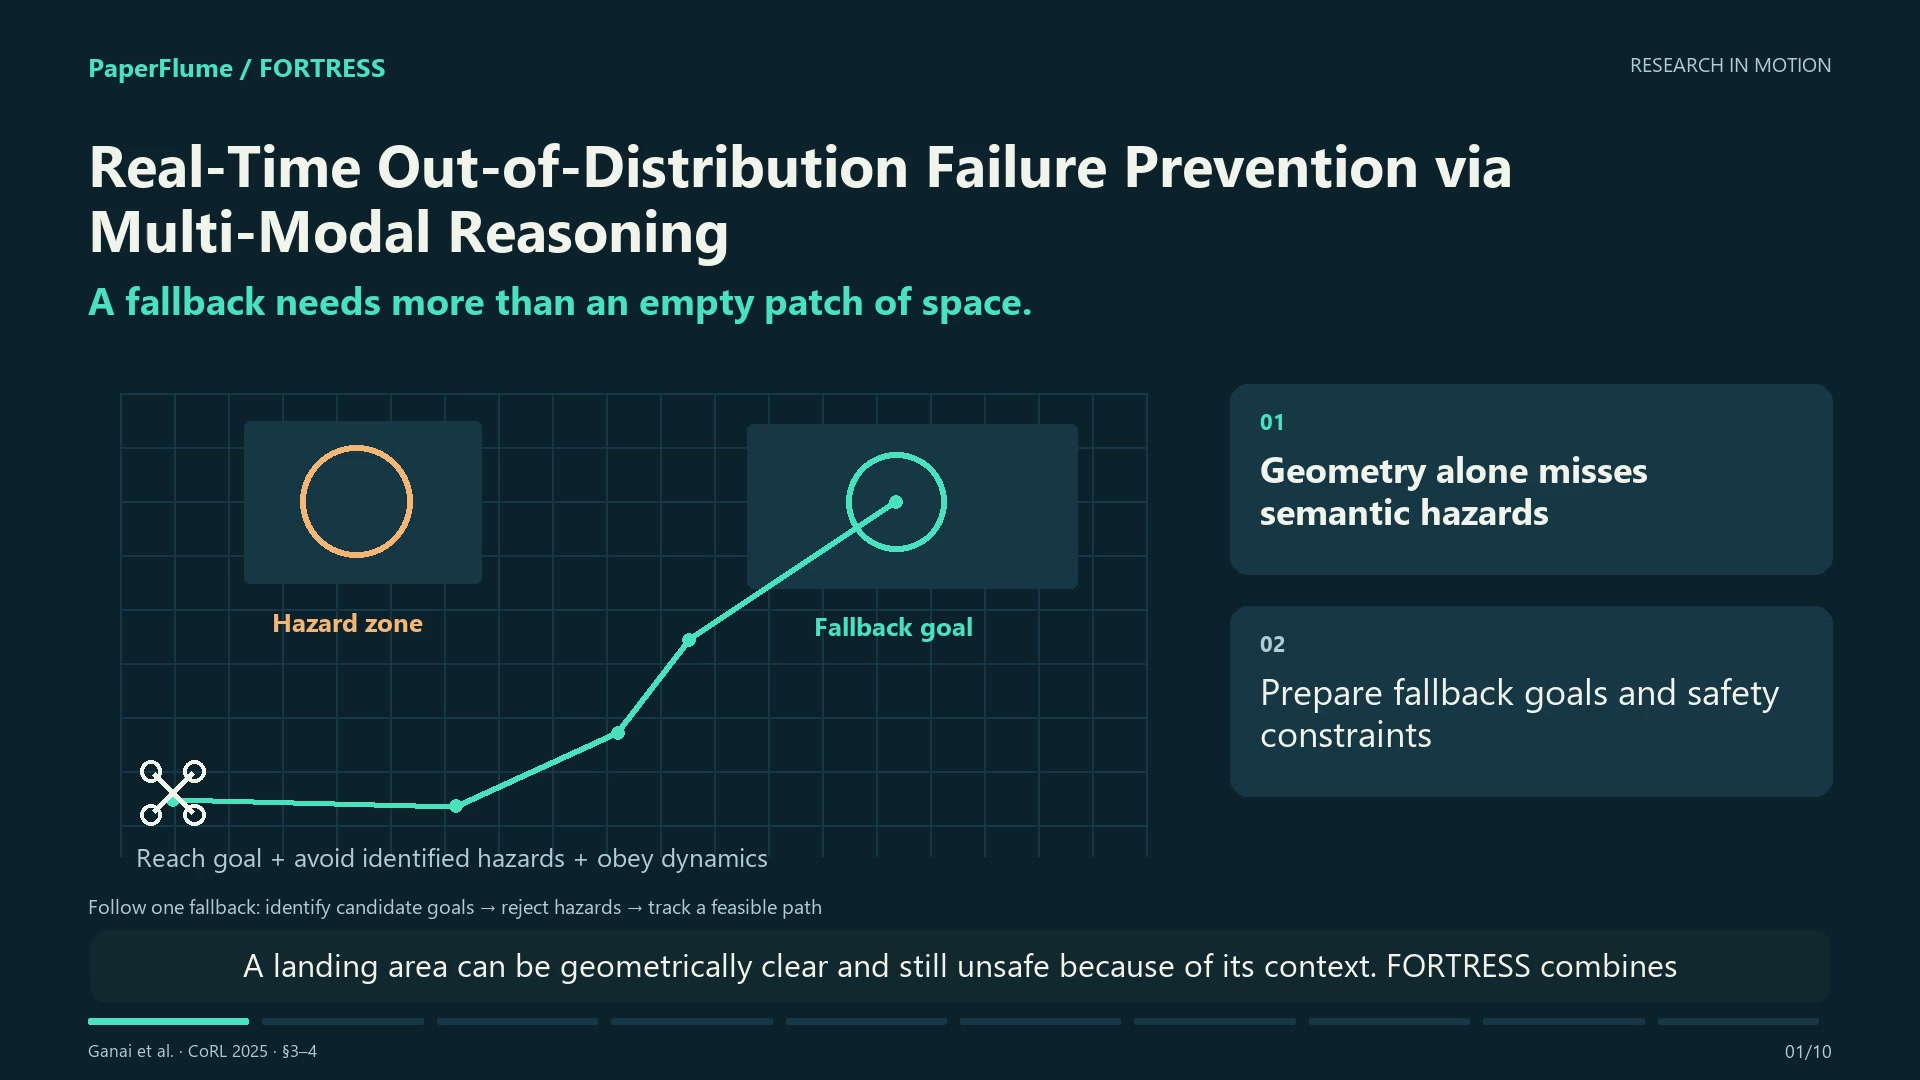
Real-Time Out-of-Distribution Failure Prevention via Multi-Modal Reasoning
Safe control and safety filters
 6:33
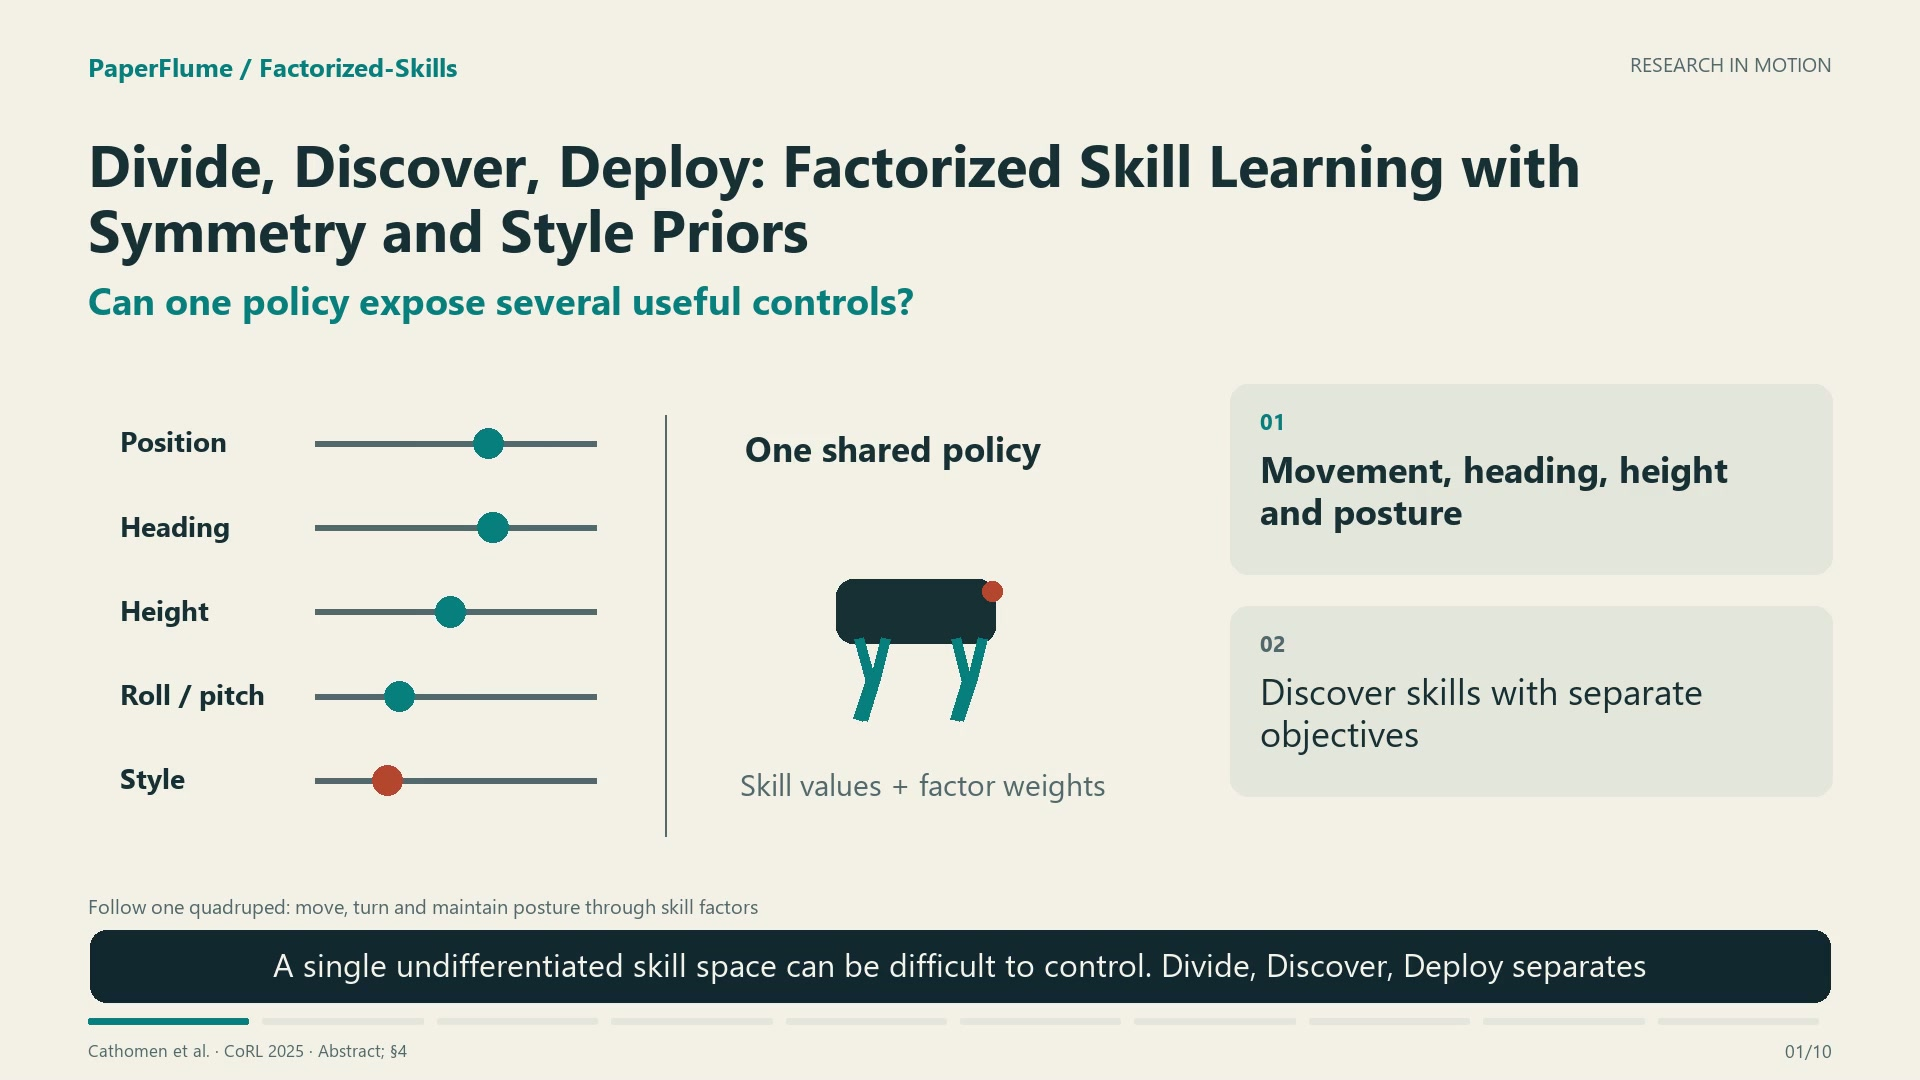
Divide, Discover, Deploy: Factorized Skill Learning with Symmetry and Style Priors
RL for control
 6:20
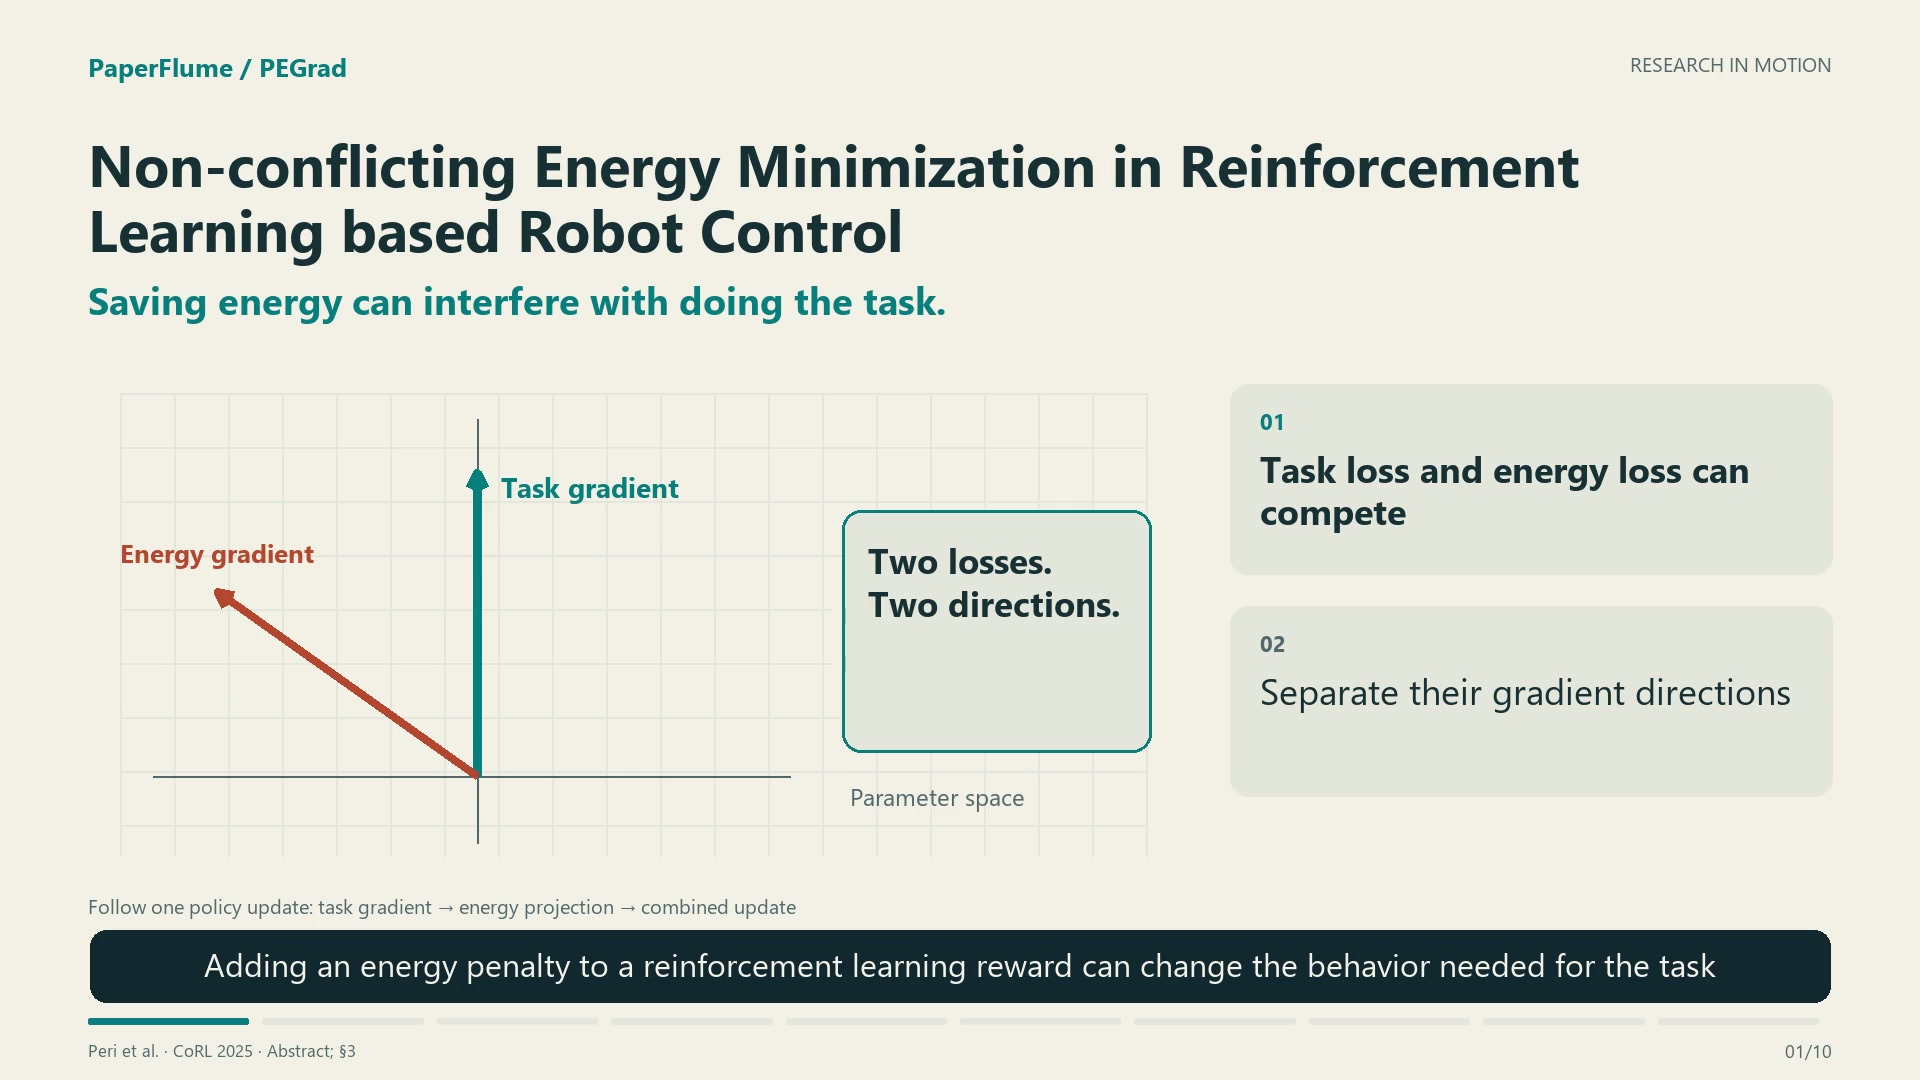
Non-conflicting Energy Minimization in Reinforcement Learning based Robot Control
RL for control
 6:19
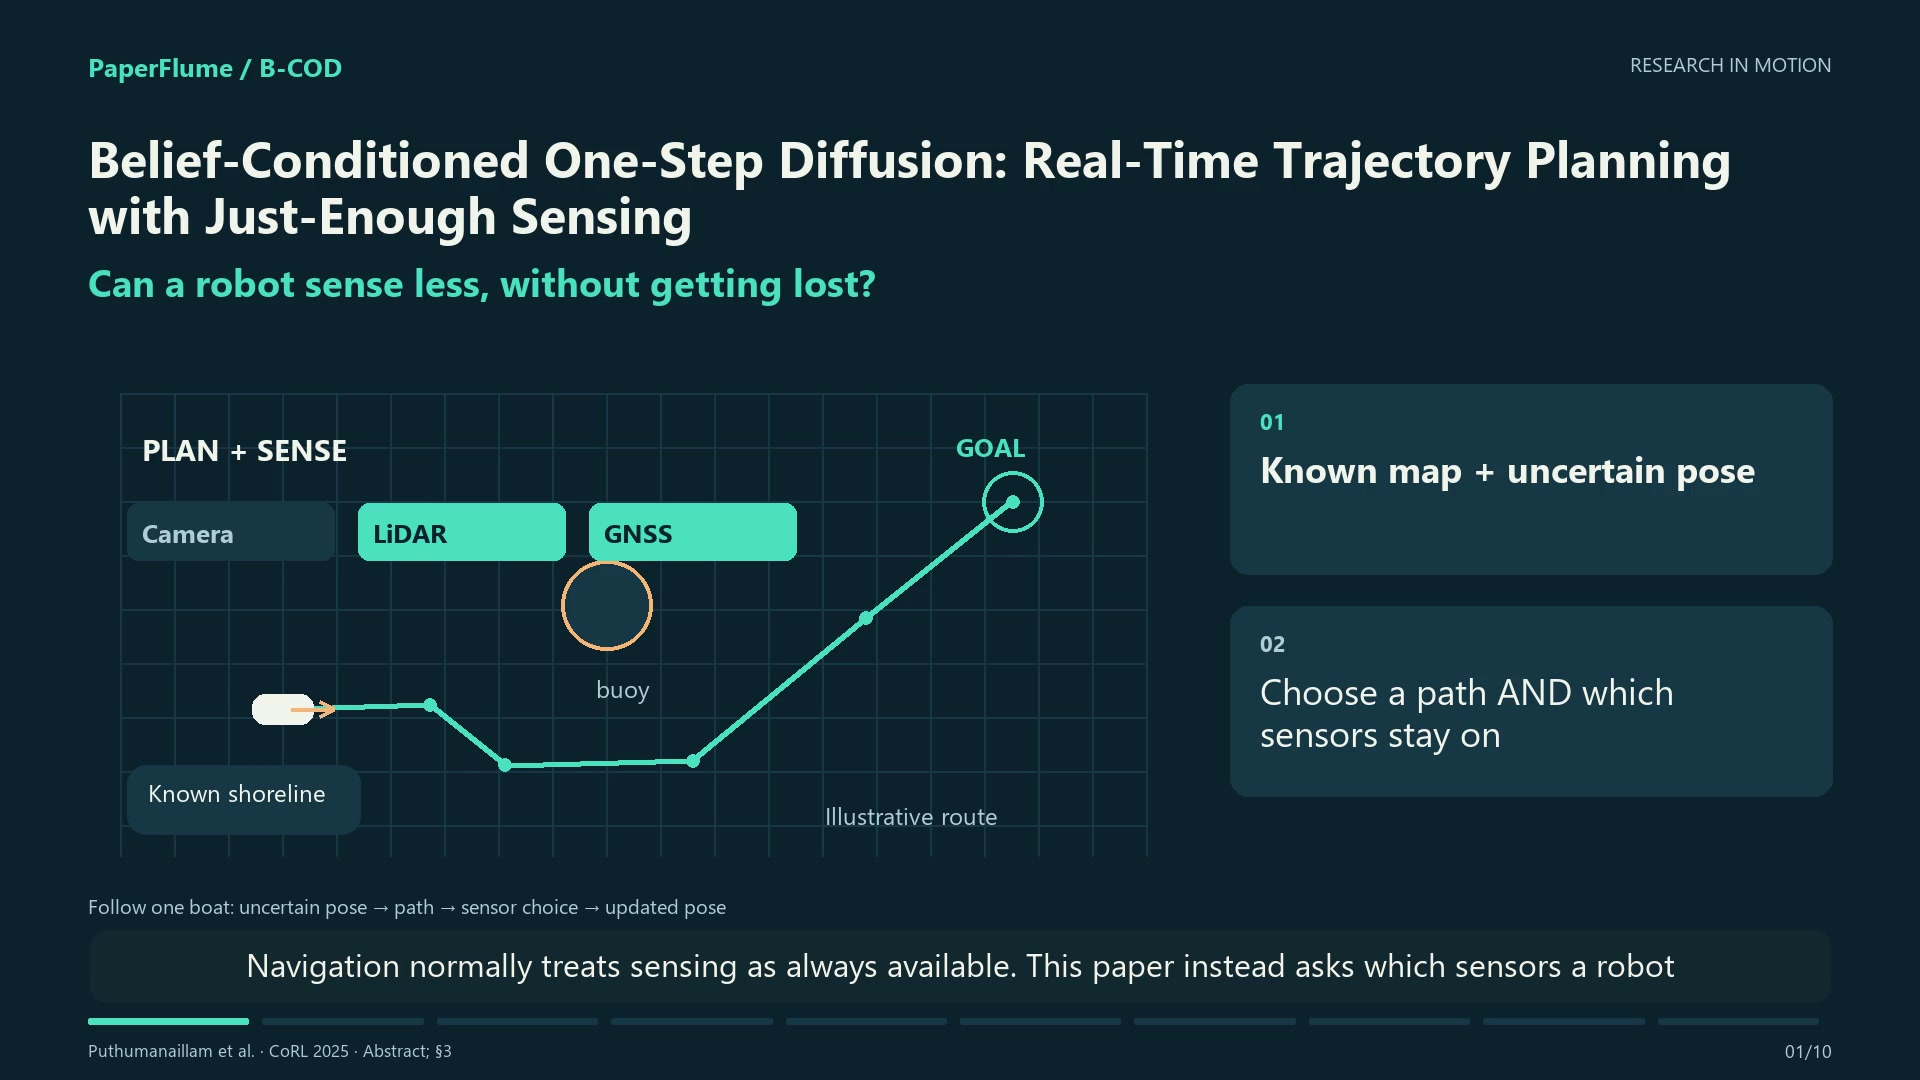
Belief-Conditioned One-Step Diffusion: Real-Time Trajectory Planning with Just-Enough Sensing
Trajectory optimisation
 4:33
Planning from Point Clouds over Continuous Actions for Multi-object Rearrangement
Point cloud understanding · deck
 7:21
LocoFormer: Generalist Locomotion via Long-context Adaptation
RL for control · deck
 5:12
HuB: Learning Extreme Humanoid Balance
RL for control · deck
 5:54
FACET: Force-Adaptive Control via Impedance Reference Tracking for Legged Robots
RL for control · deck
 6:56
Steering Your Diffusion Policy with Latent Space Reinforcement Learning
RL for control · deck
 4:51
WOMBET: World Model-based Experience Transfer for Robust and Sample-efficient Reinforcement Learning
RL for control · deck
 5:44
Trajectory-Level Experimental Design for Fast Safety Parameter Estimation of Unknown Environments by Autonomous Systems
Safe control and safety filters · deck
Vision and language
See all 20 →
6:45
ManiGuard: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
VLA models · deck
2608.17386
6:45
RHO: Your Coding Agent is Secretly a Roboticist
Multimodal LLMs · deck
2606.16458
6:10
Industrial ReMEmbR: Scaling Spatiotemporal Memory to Robot Fleets
Video understanding · deck
2610.28624
6:42
FARM: Find Anything using Relational Spatial Memory
Open-vocabulary perception · deck
2606.15476
7:13
FLEX-WAM: Flexible Block-Causal World-Action Models for Long-Horizon Imagination and Planning
VLA models · deck
2610.05483
6:28
Long-WAM: Scaling the Context of World-Action Models
VLA models · deck
2610.10528
7:04
Agentic World Action Models
VLA models · deck
2610.30136
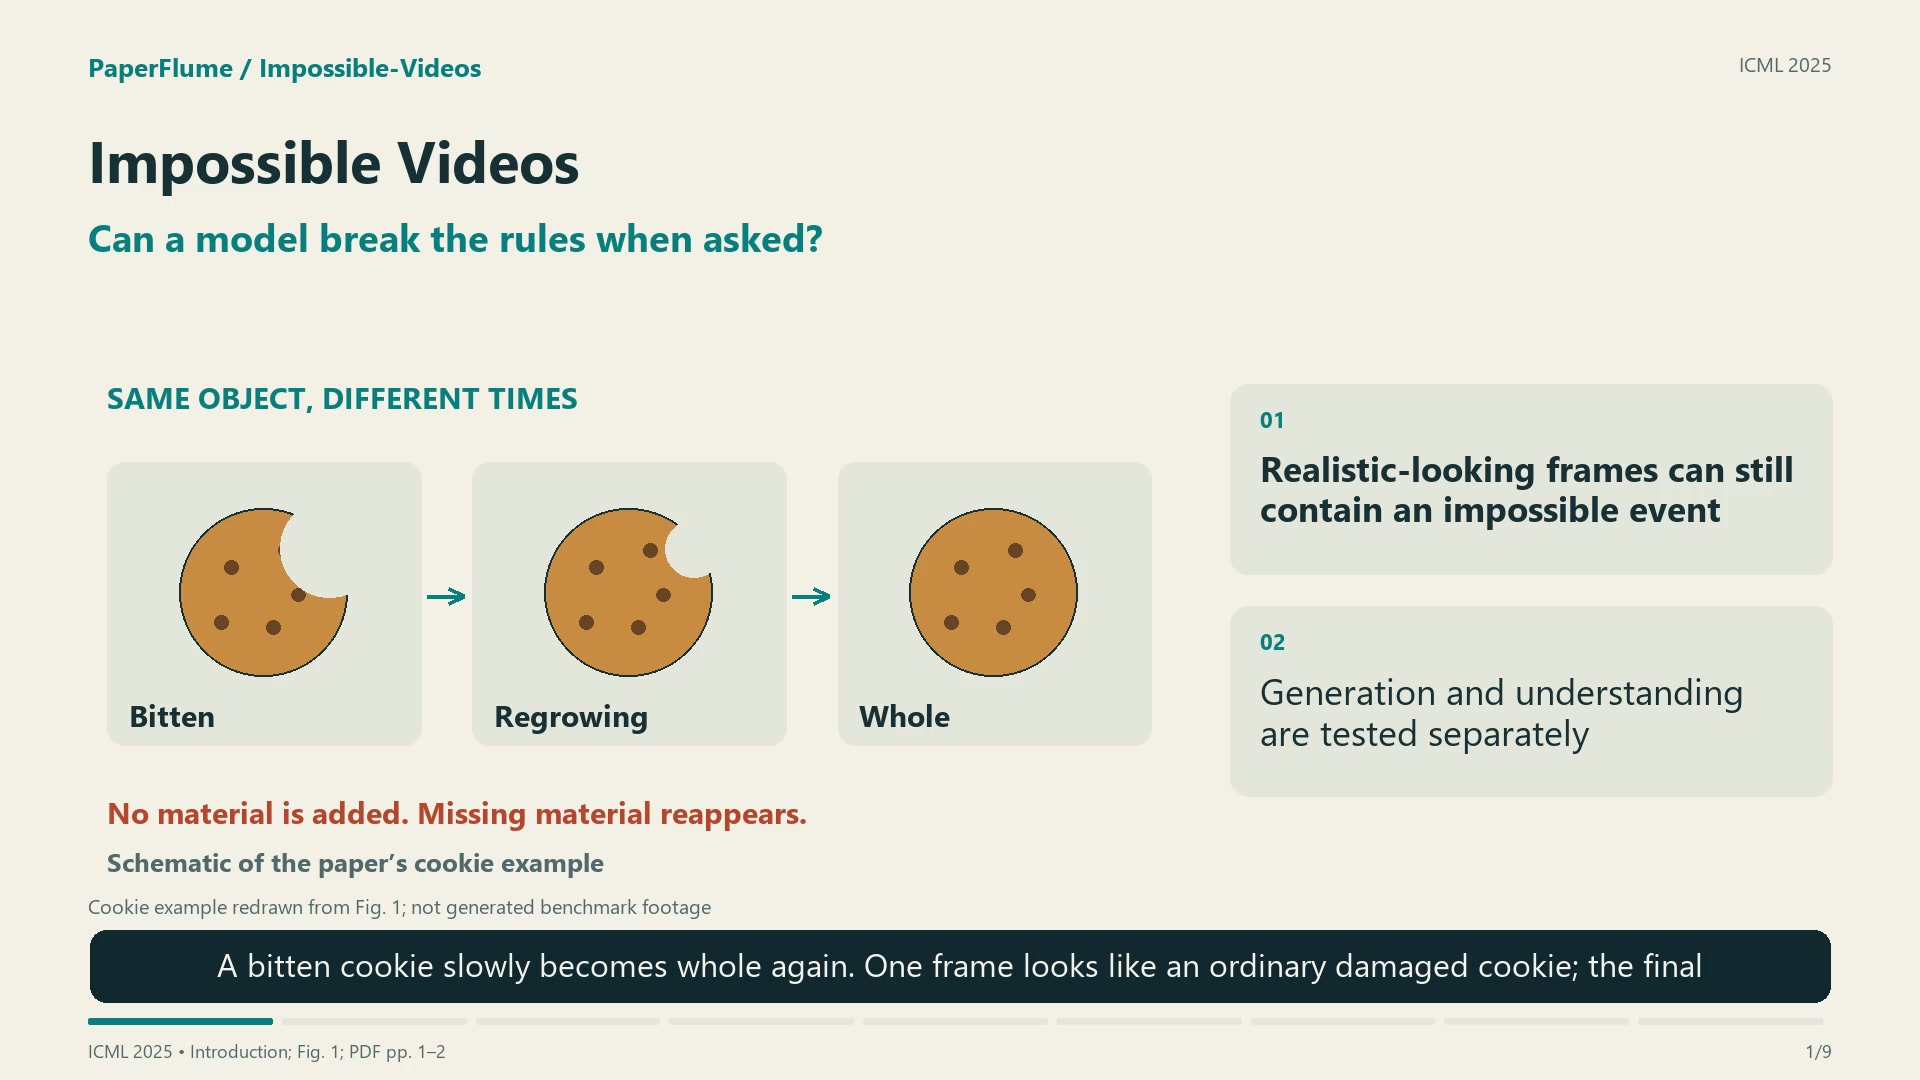 7:46
Impossible Videos
Video generation · deck
 5:21
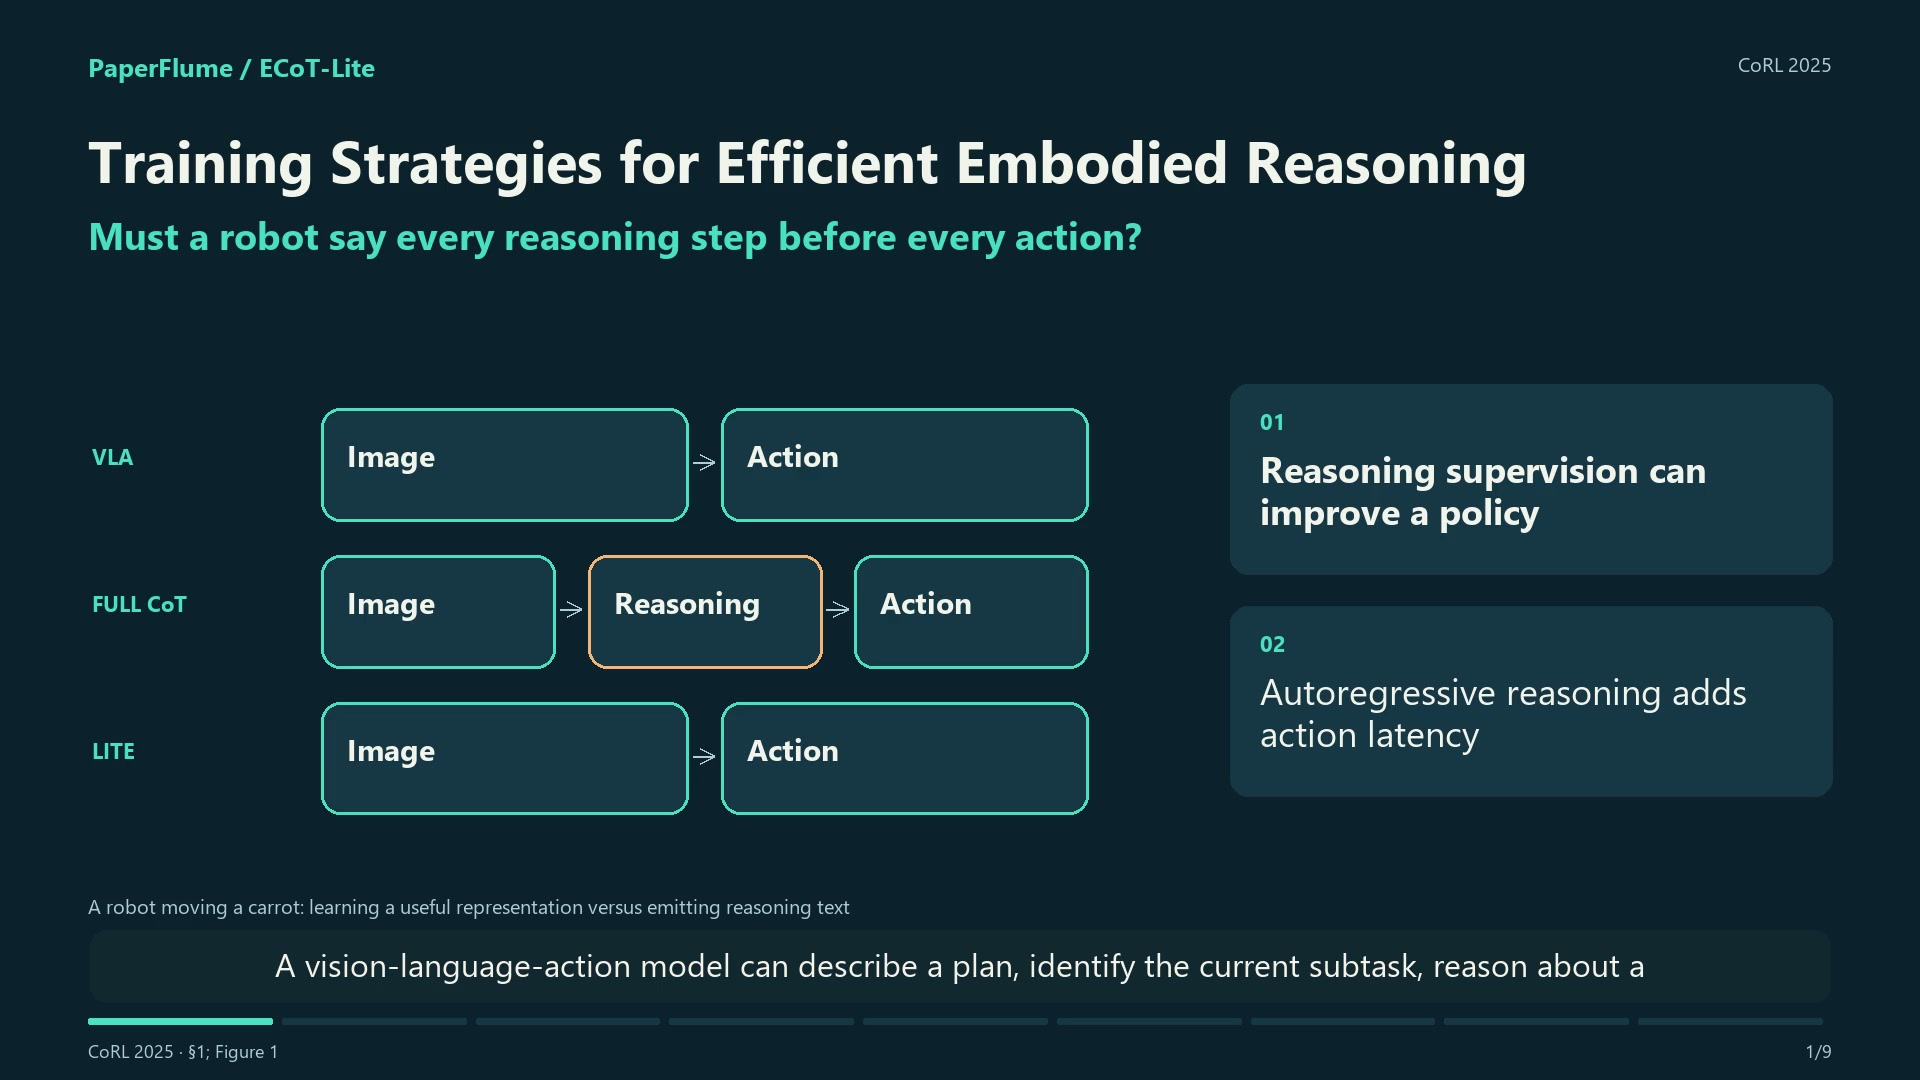
Training Strategies for Efficient Embodied Reasoning
VLA models · deck
 5:33
LARA: Latent Action Representation Alignment for Vision-Language-Action Models
VLA models · deck
 5:31
Prototype-Based Test-Time Adaptation of Vision-Language Models
Test-time scaling · deck
 6:23
The Lie We Tell: Correcting the Euclidean Fallacy in Vision Language Action Policies via Score Matching on Tangent Space
VLA models · deck
 6:44
UniPercept: Towards Unified Perceptual-Level Image Understanding across Aesthetics, Quality, Structure, and Texture
Multimodal LLMs · deck
 7:12
What Does Vision Tool-Use Reinforcement Learning Really Learn? Disentangling Tool-Induced and Intrinsic Effects for Crop-and-Zoom
Multimodal LLMs · deck
 6:23
When RAG Hurts: Diagnosing and Mitigating Attention Distraction in Retrieval-Augmented LVLMs
Multimodal LLMs · deck
 6:25
SPARC: Separating Perception And Reasoning Circuits for Test-time Scaling of VLMs
Multimodal LLMs · deck
 5:28
Active Exploring like a Pigeon: Reinforcing Spatial Reasoning via Agentic Vision-Language Models
Video understanding · deck
 7:19
MoDA: Modulation Adapter for Fine-Grained Visual Understanding in Instructional MLLMs
Multimodal fusion · deck
 7:09
VideoTrace-R1: Long Video-based Retrieval-Augmented Generation via Reinforcement Learning
Video understanding · deck
 6:44
SciVideoBench: Benchmarking Scientific Video Reasoning in Large Multimodal Models
Video understanding · deck
Recognition and detection
See all 20 →
8:24
Foundation4D: Towards a unified perception and reconstruction model for autonomous vehicles
Gaussian splatting · deck
2610.30340
5:28
Learning Smooth State-Dependent Traversability from Dense Point Clouds
Point cloud understanding · deck
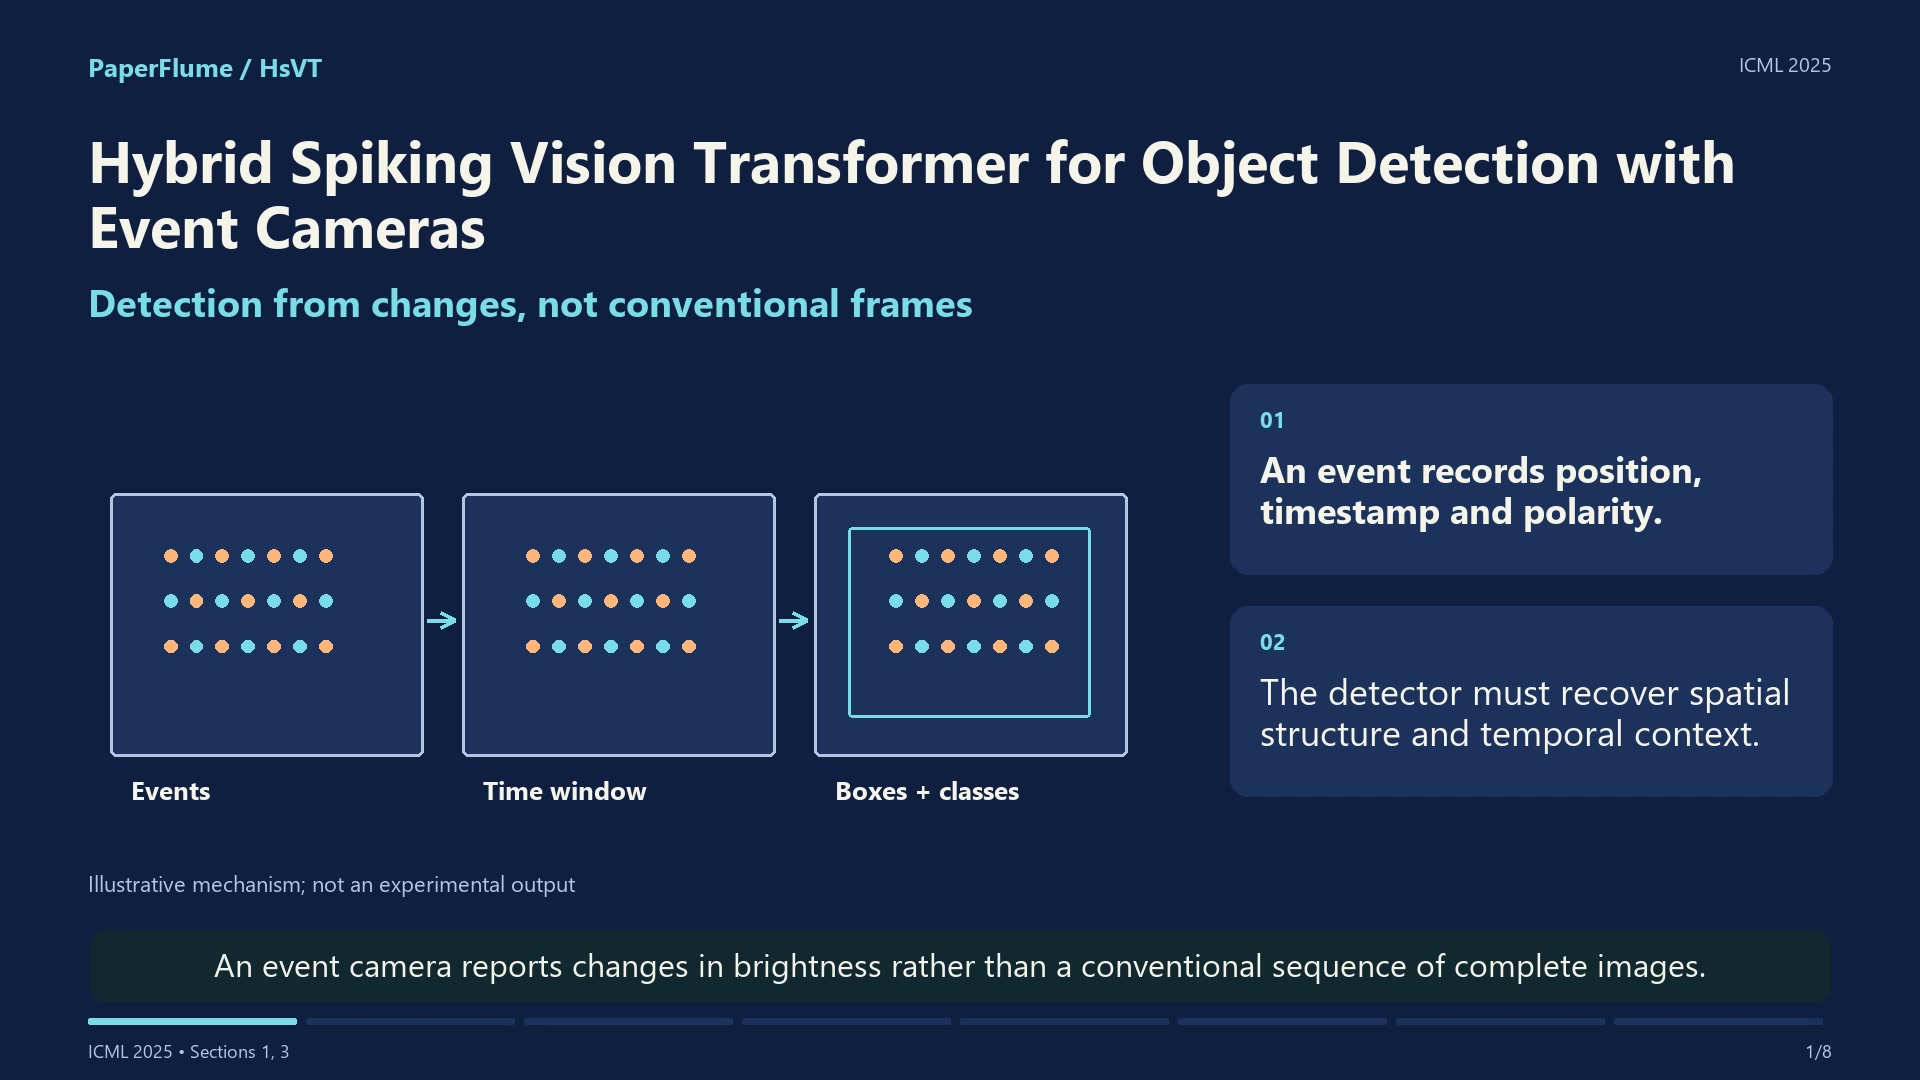 5:57
Hybrid Spiking Vision Transformer for Object Detection with Event Cameras
Object detection · deck
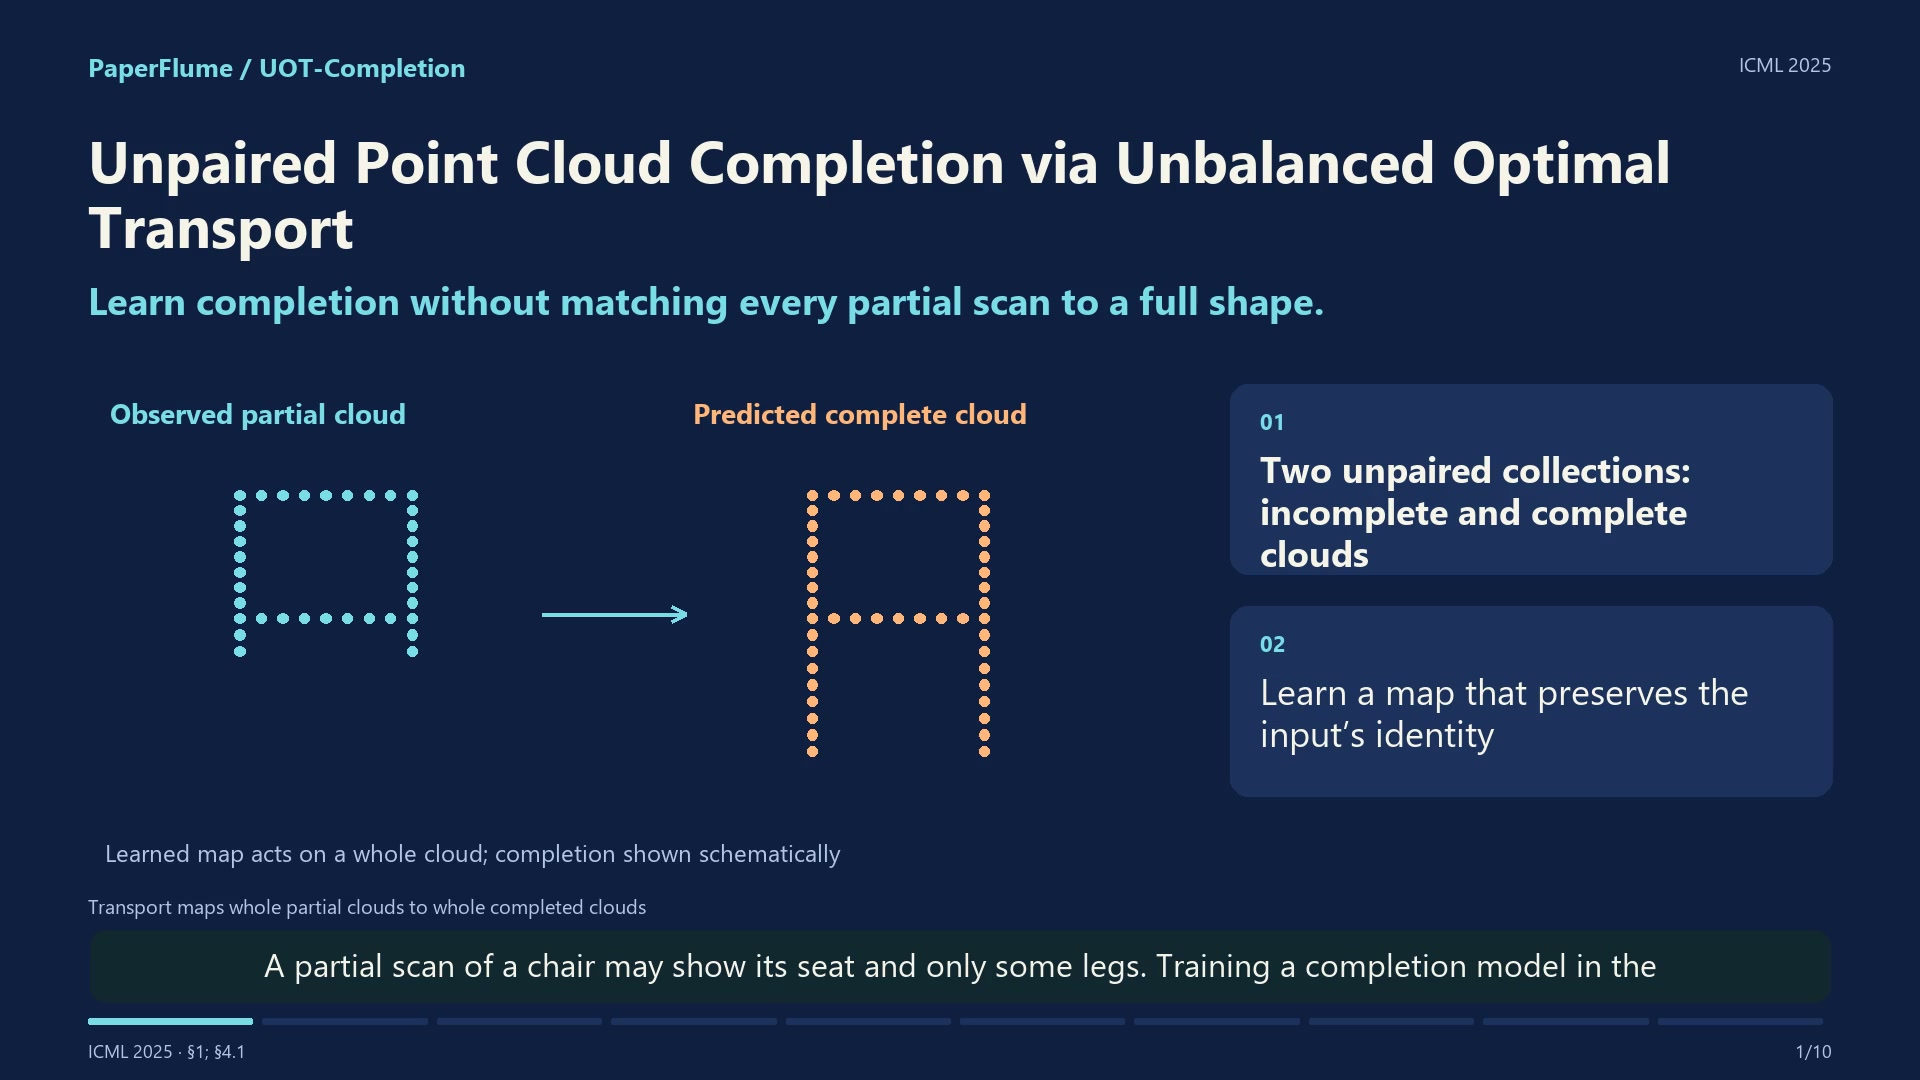 7:19
Unpaired Point Cloud Completion via Unbalanced Optimal Transport
Point cloud understanding · deck
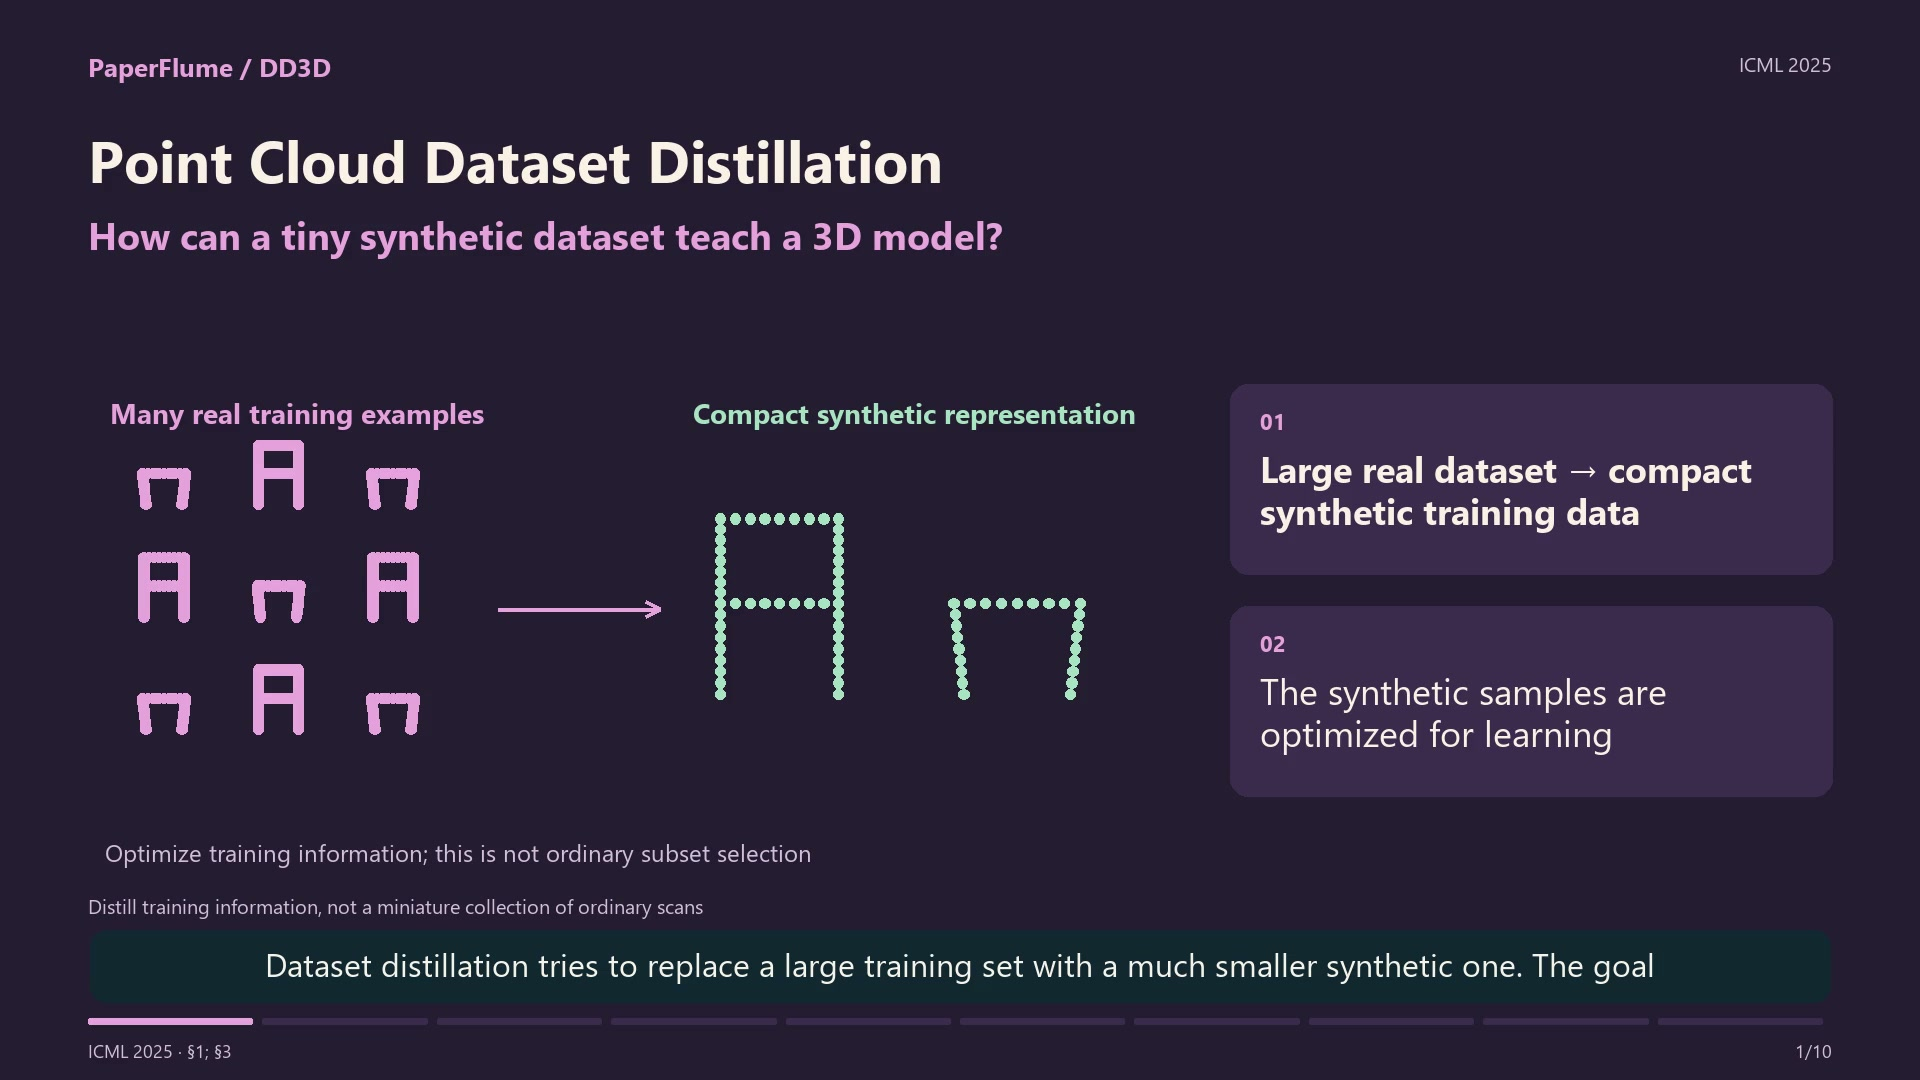 7:20
Point Cloud Dataset Distillation
Point cloud understanding · deck
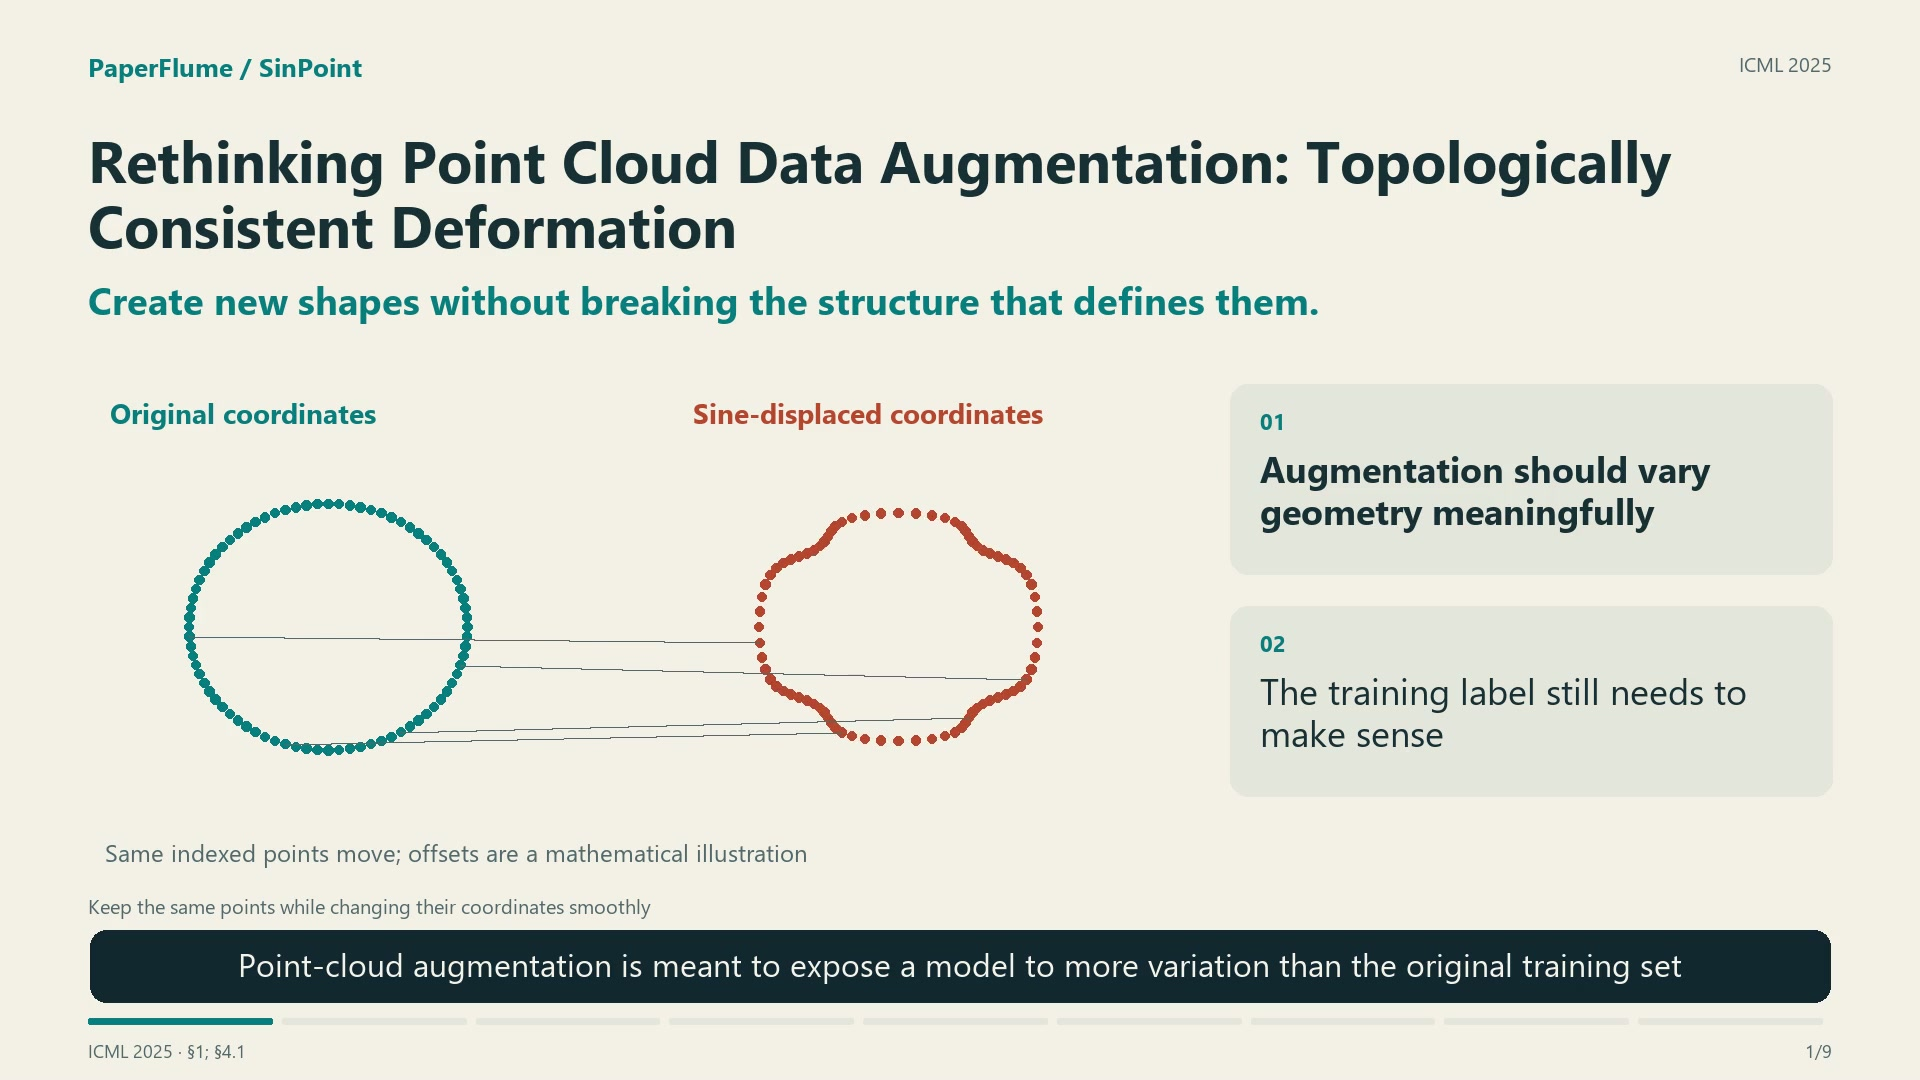 6:39
Rethinking Point Cloud Data Augmentation: Topologically Consistent Deformation
Point cloud understanding · deck
 8:00
Exploring Vision Semantic Prompt for Efficient Point Cloud Understanding
Point cloud understanding · deck
 8:12
GAPrompt: Geometry-Aware Point Cloud Prompt for 3D Vision Model
Point cloud understanding · deck
 7:57
Generative Point Cloud Registration
Diffusion models · deck
 4:21
Generalizable Multi-Camera 3D Object Detection from a Single Source via Fourier Cross-View Learning
Object detection · deck
4:33
Planning from Point Clouds over Continuous Actions for Multi-object Rearrangement
Point cloud understanding · deck
 5:56
FOVI: A biologically-inspired foveated interface for deep vision models
· deck
 6:36
ConEx: Human-Interpretable Saliency Maps via Concept-Aware Attribution
· deck
 7:39
Cross-Modal Semantic Decoupling and Transfer for Text-to-Visible-Infrared Person Re-Identification
Multimodal fusion · deck
 6:52
TVDRNet: Text-driven Viewpoint Optimization via Differentiable Rendering for 3D Reasoning Segmentation
Neural rendering · deck
 8:29
LightAVSeg: Lightweight Audio-Visual Segmentation
Segmentation · deck
 6:37
Multi-Label Learning with Contrastive Cluster Self-Supervision for 3D Hierarchical Semantic Segmentation
Segmentation · deck
 6:46
Amodal Instance Segmentation with IRAIS Dataset for Sim-to-Real Transfer
Segmentation · deck
 6:41
Focus, Align, and Sustain: Counteracting Gradient Dilution in Incremental Object Detection
Object detection · deck
 7:03
Refining Context-Entangled Content Segmentation via Curriculum Selection and Anti-Curriculum Promotion
Segmentation · deck
Generative vision
See all 20 →
7:13
FLEX-WAM: Flexible Block-Causal World-Action Models for Long-Horizon Imagination and Planning
VLA models · deck
2610.05483
5:42
L-Diffusion: Laplace Diffusion for Efficient Pathology Image Segmentation
Diffusion models · deck
 4:50
Human Body Restoration with One-Step Diffusion Model and A New Benchmark
Diffusion models · deck
 5:00
RestoreGrad: Signal Restoration Using Conditional Denoising Diffusion Models with Jointly Learned Prior
Diffusion models · deck
 5:35
You Always Recognize Me (YARM): Robust Texture Synthesis Against Multi-View Corruption
· deck
 6:23
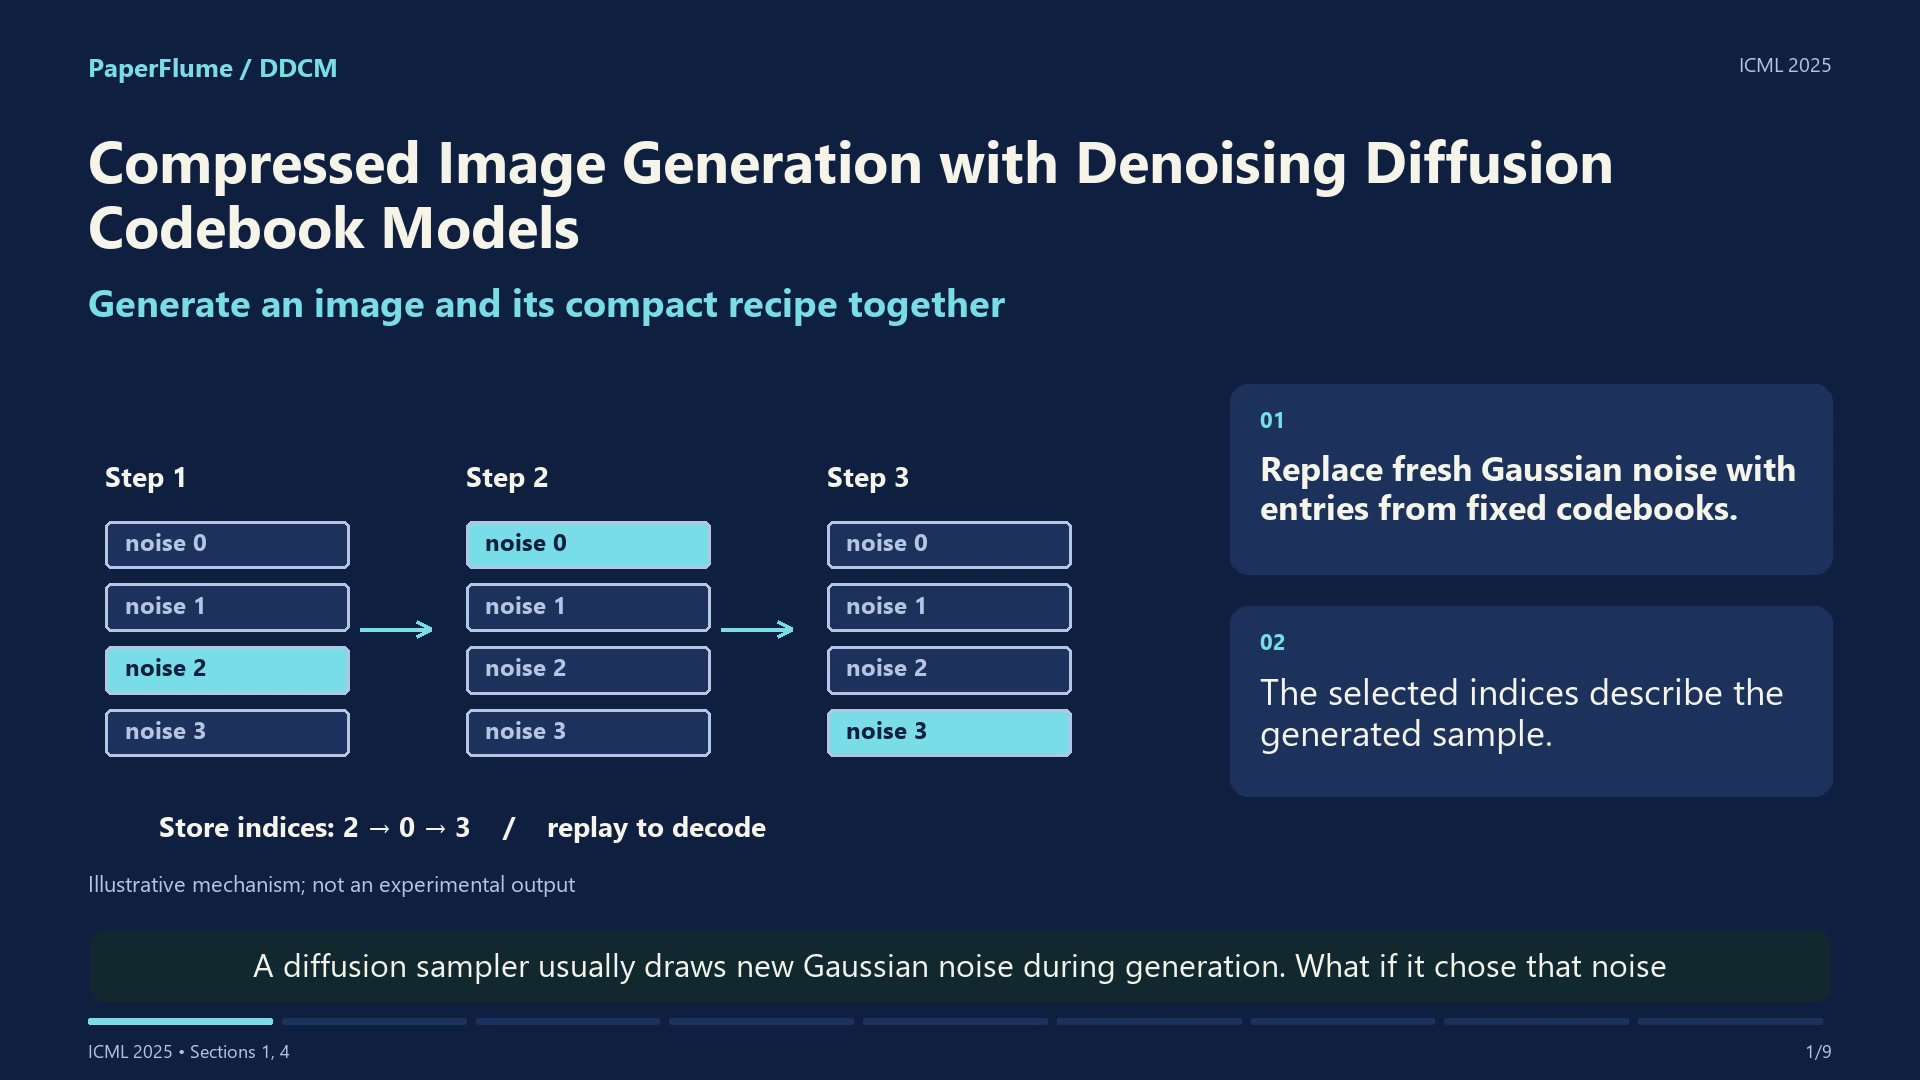
Compressed Image Generation with Denoising Diffusion Codebook Models
Diffusion models · deck
 5:42
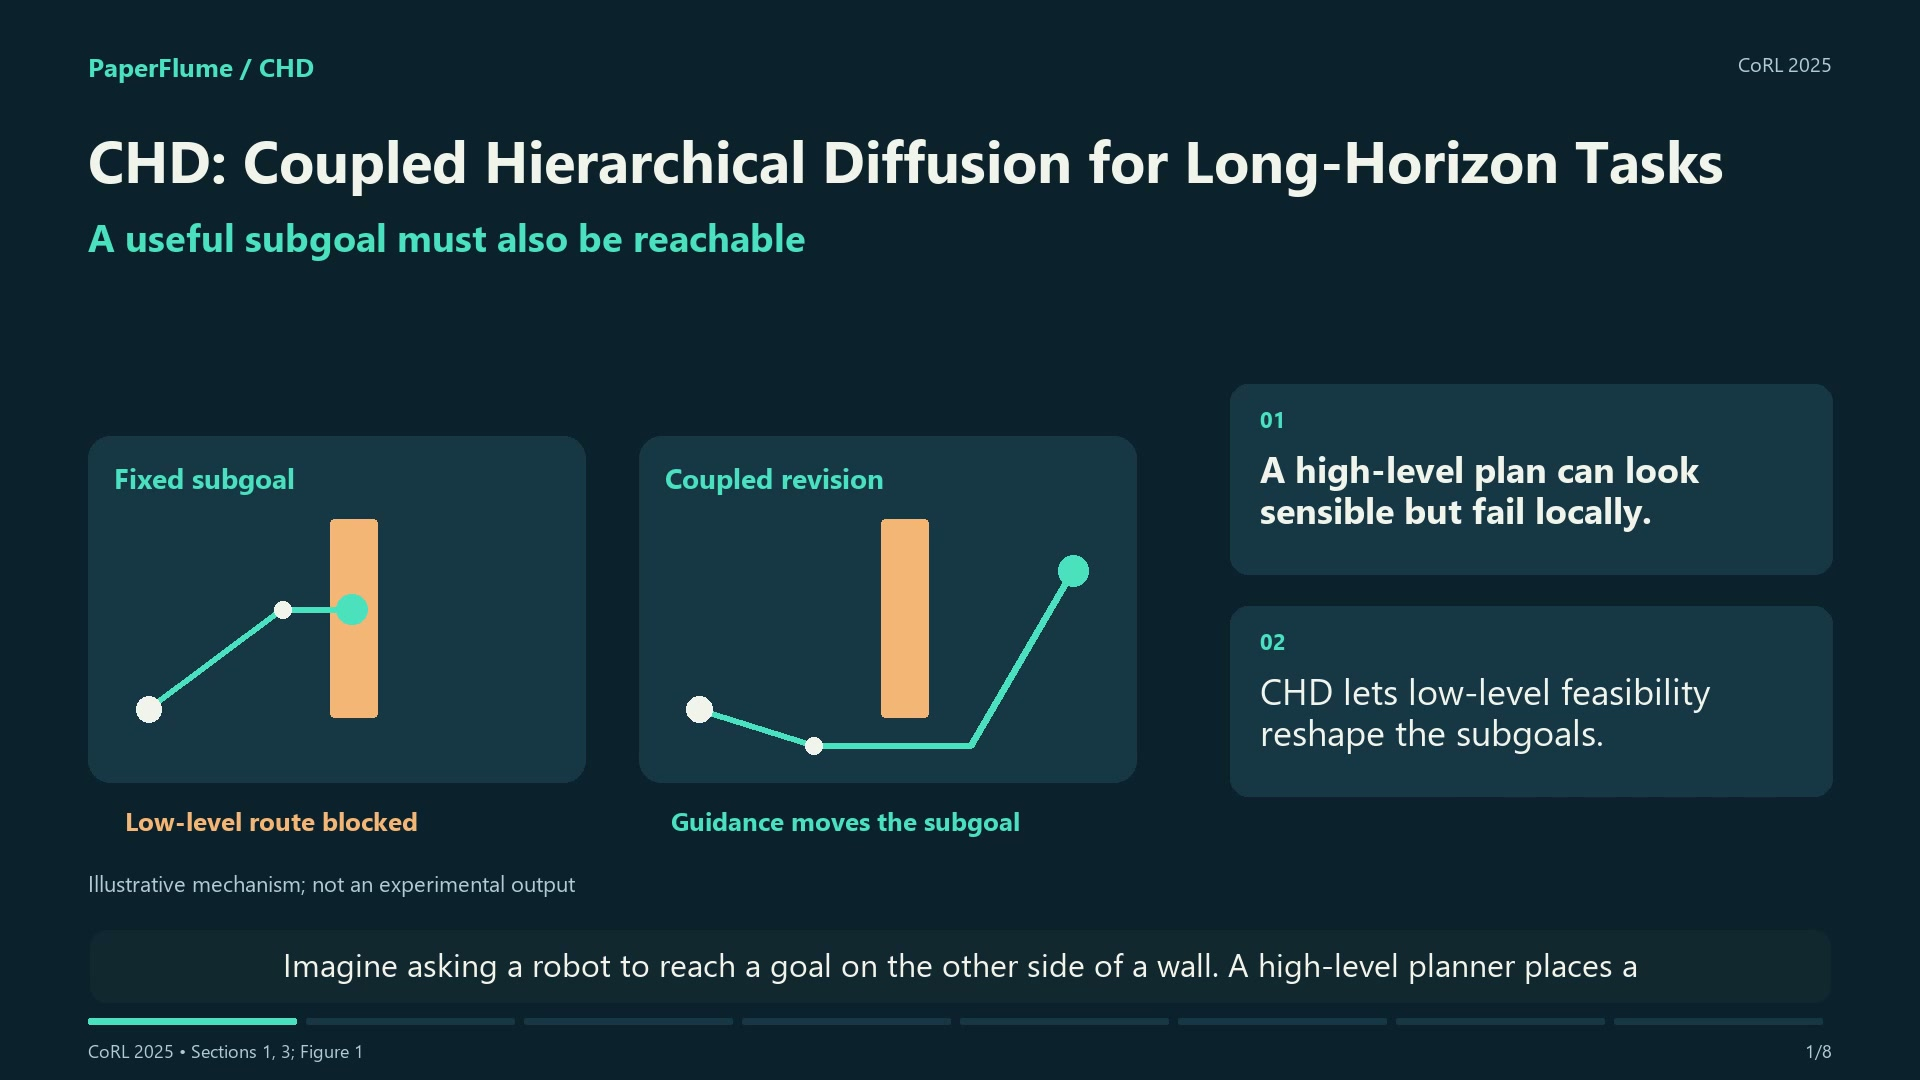
CHD: Coupled Hierarchical Diffusion for Long-Horizon Tasks
Diffusion models · deck
 5:26
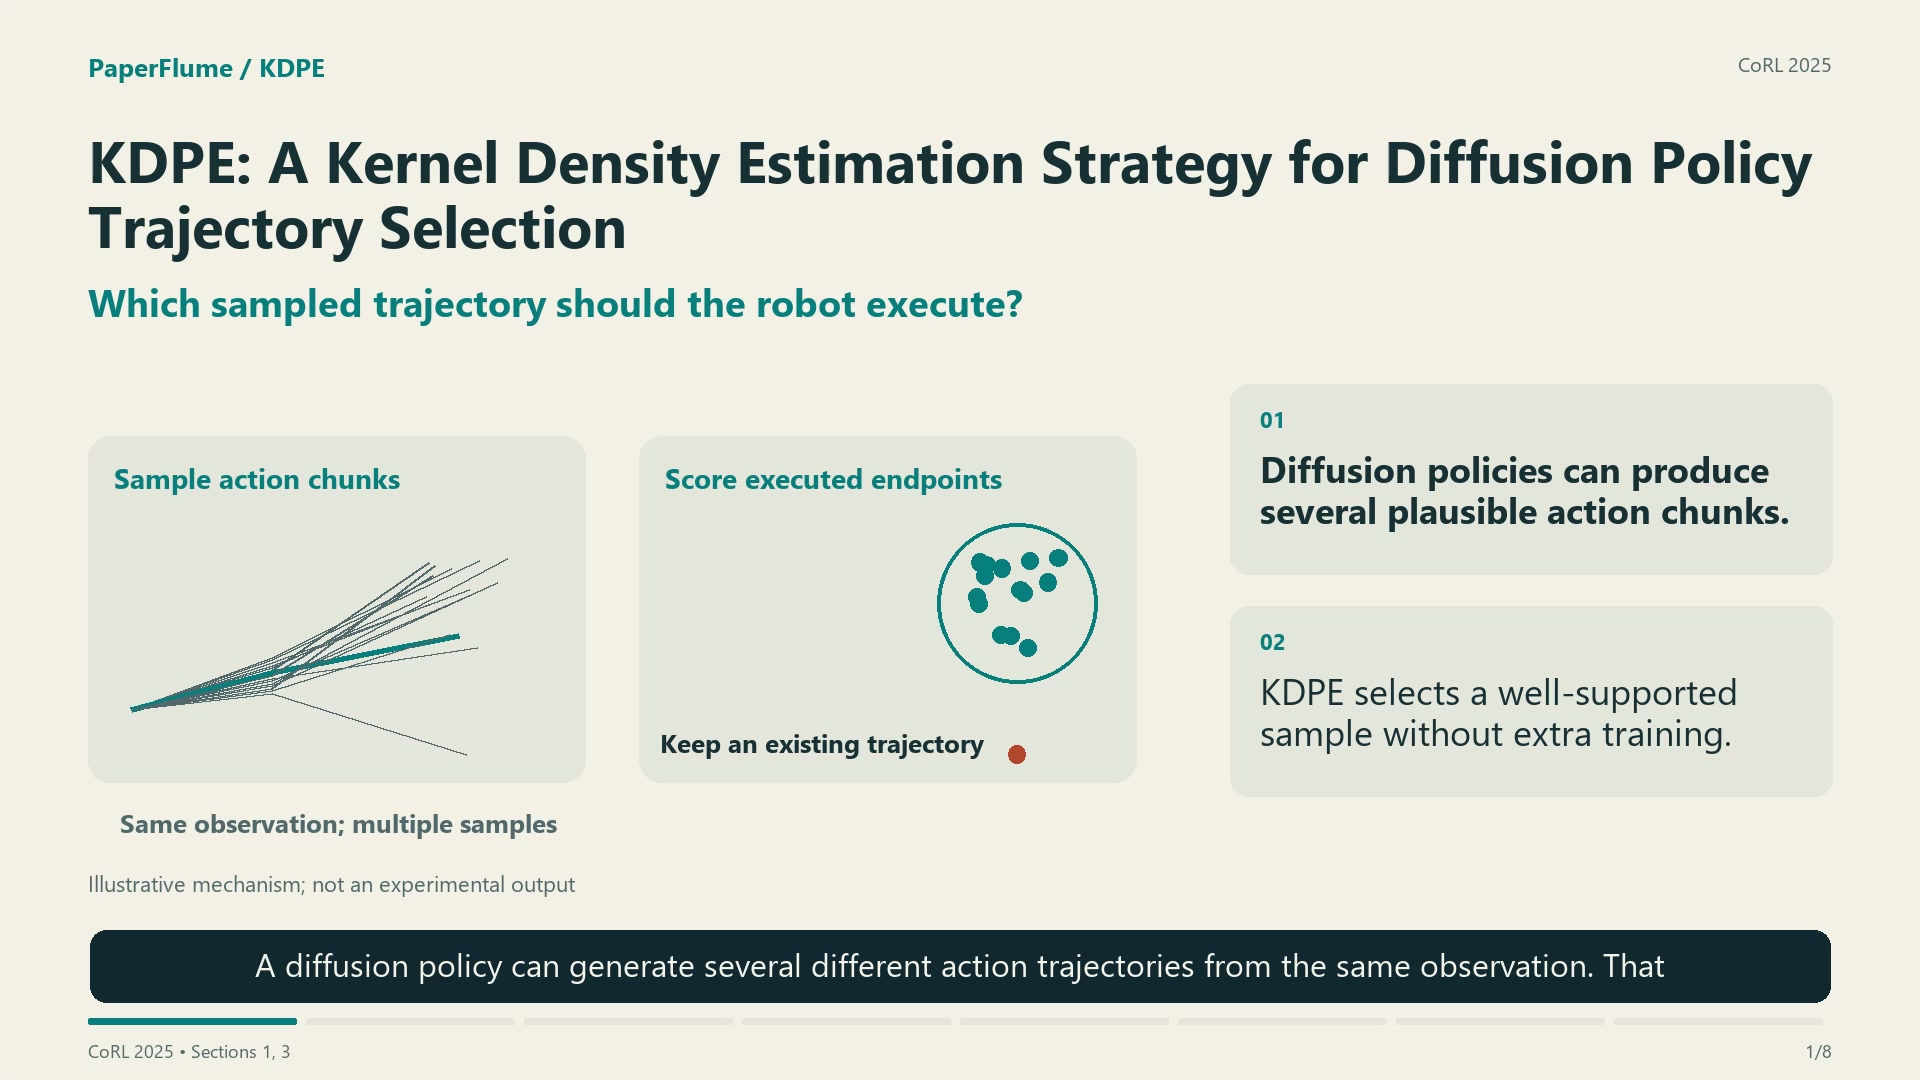
KDPE: A Kernel Density Estimation Strategy for Diffusion Policy Trajectory Selection
Learning from demonstration · deck
7:46
Impossible Videos
Video generation · deck
 6:33
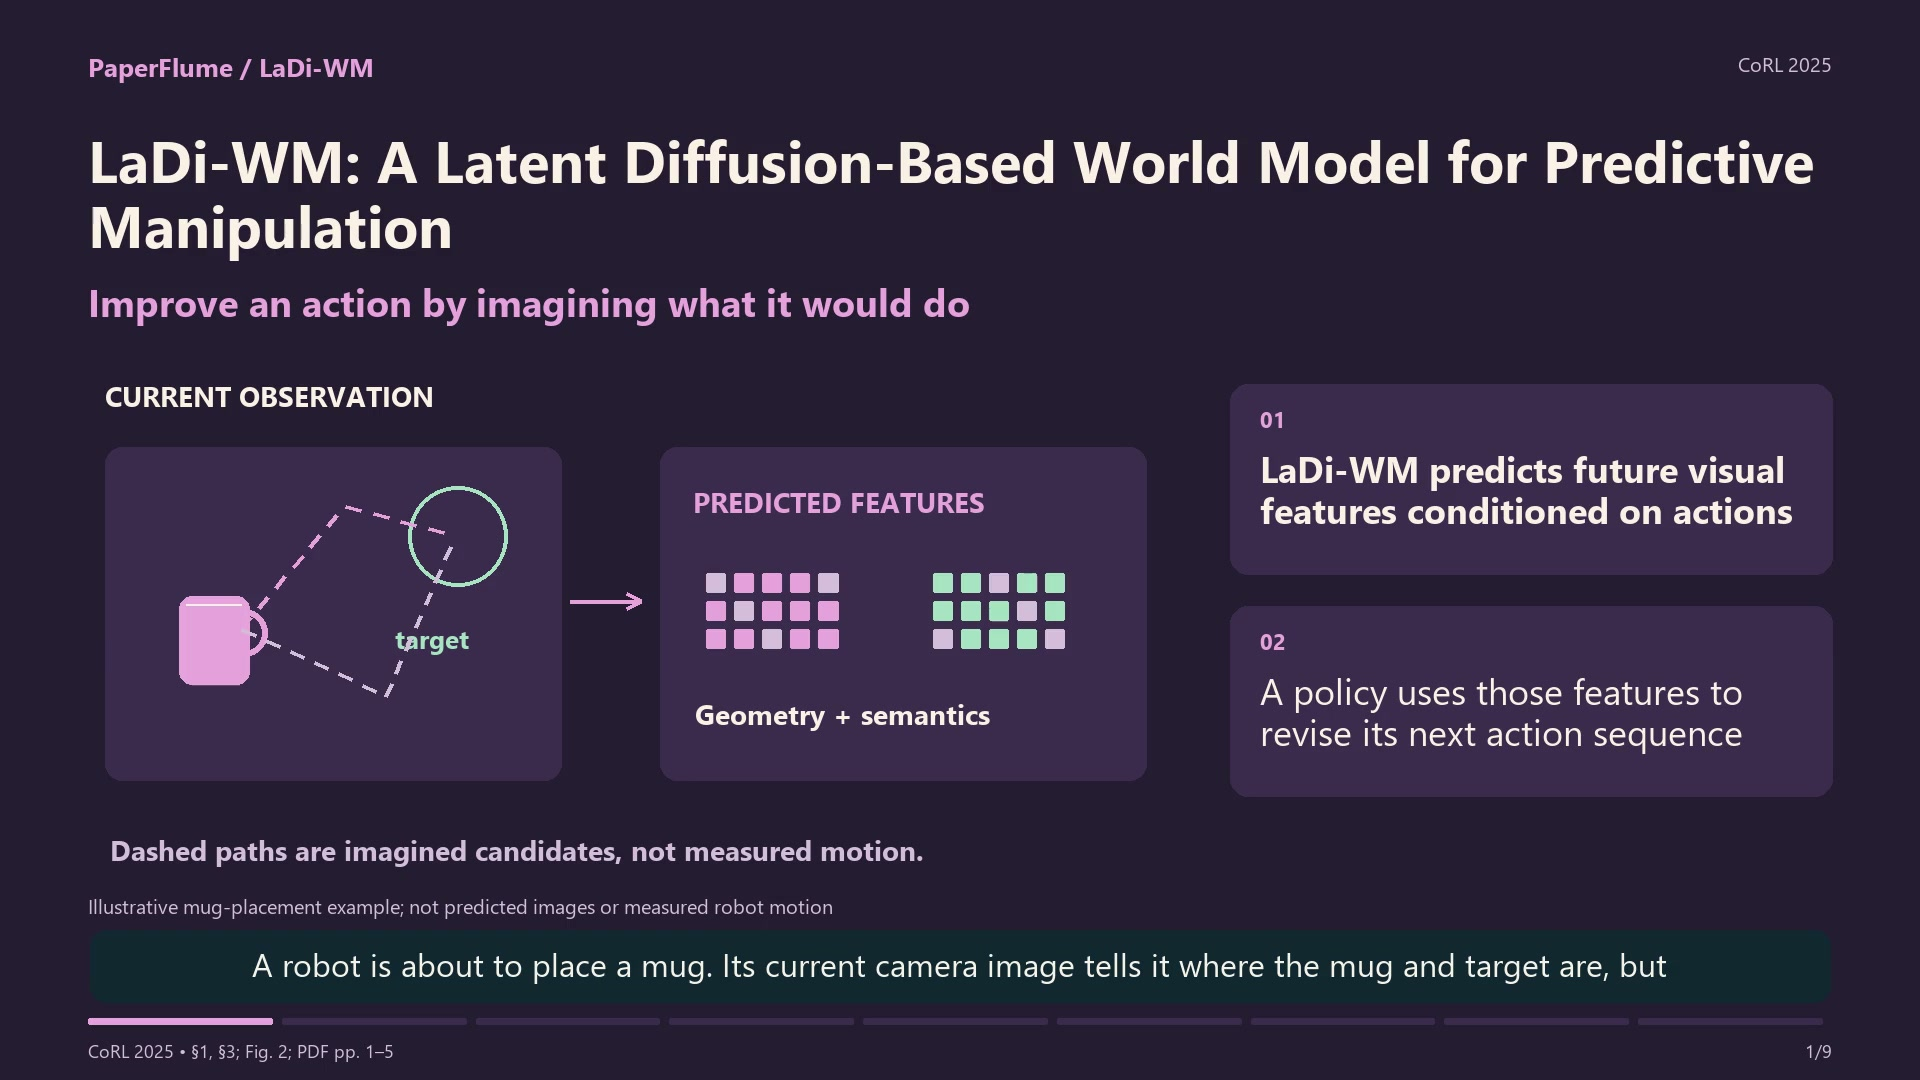
LaDi-WM: A Latent Diffusion-Based World Model for Predictive Manipulation
Diffusion models · deck
 9:33
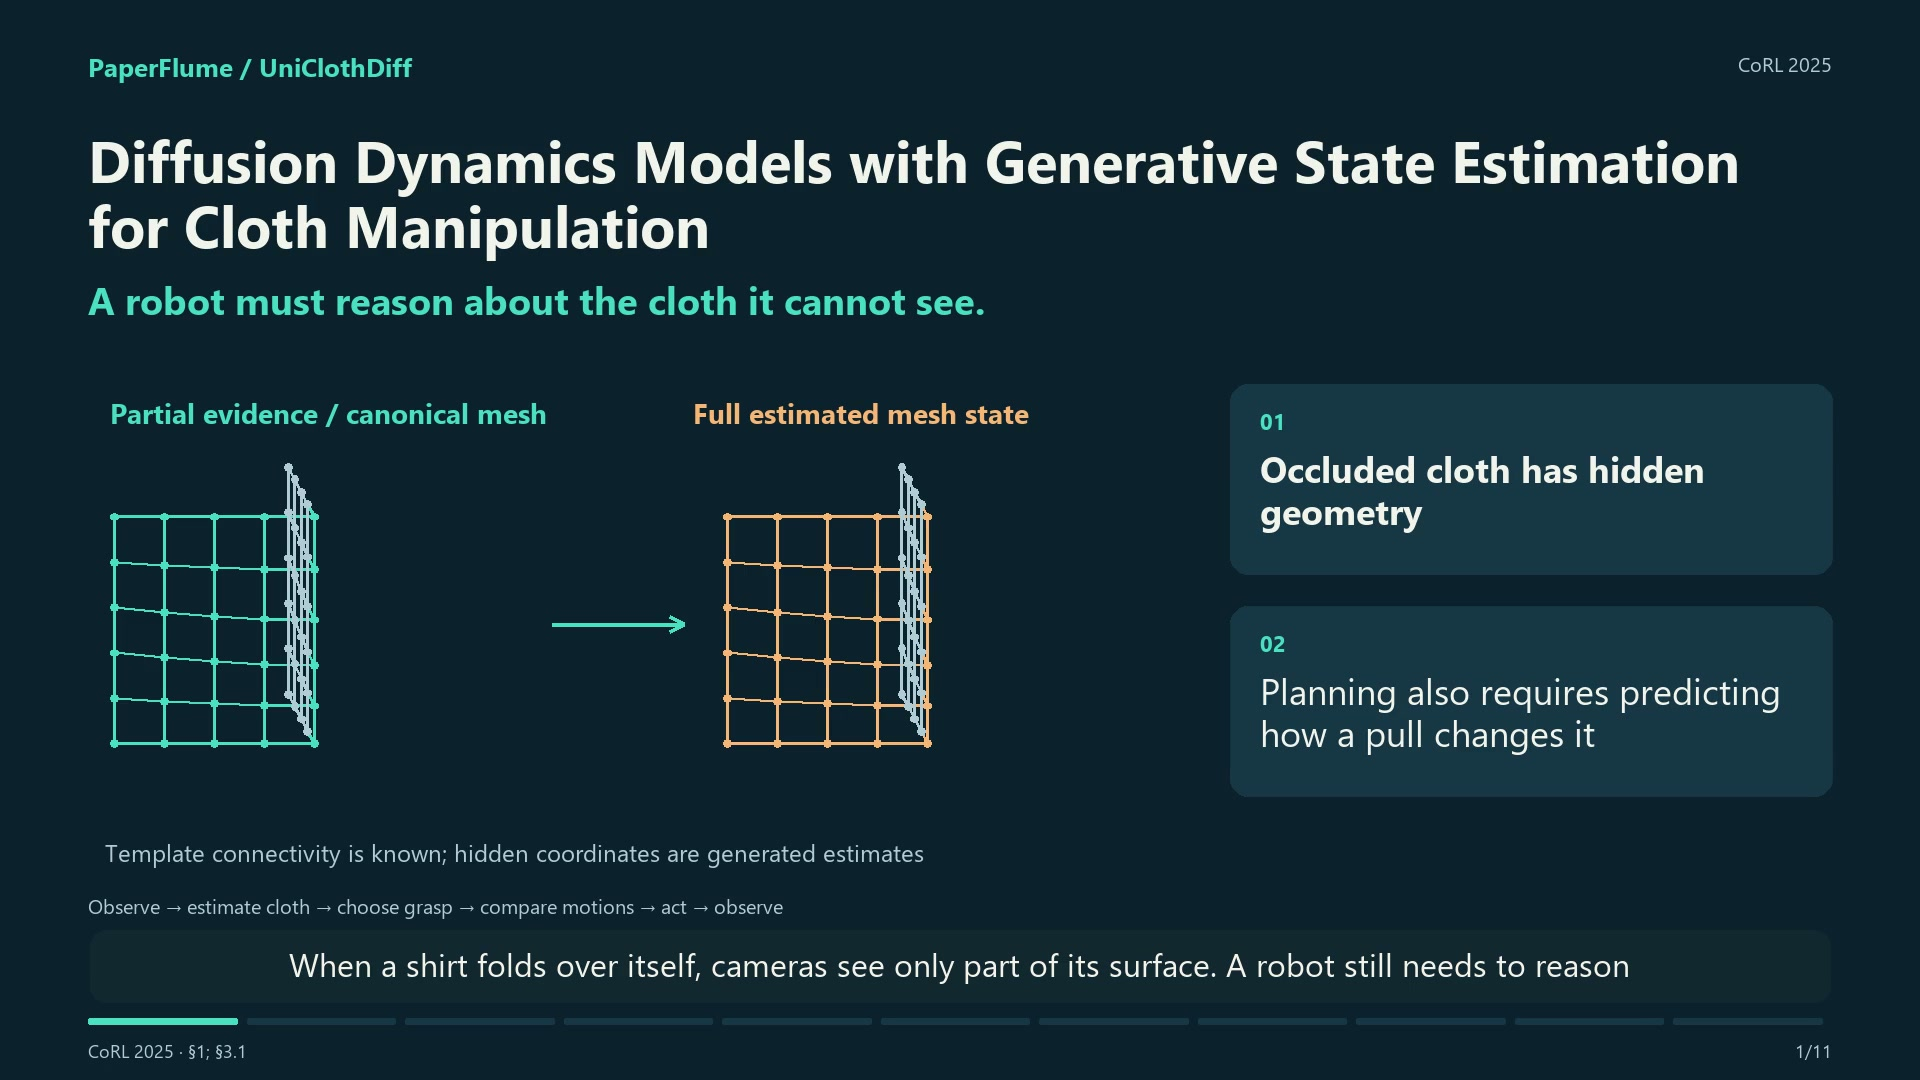
Diffusion Dynamics Models with Generative State Estimation for Cloth Manipulation
Diffusion models · deck
7:57
Generative Point Cloud Registration
Diffusion models · deck
 5:53
Rethinking Video Generation Model for the Embodied World
Video generation · deck
 5:49
Attention Sparsity is Input-Stable: Training-Free Sparse Attention for Video Generation via Offline Sparsity Profiling and Online QK Co-Clustering
Video generation · deck
 5:50
Self-Refining Video Sampling
Video generation · deck
 6:45
Motion-Aware Caching for Efficient Autoregressive Video Generation
Diffusion models · deck
 7:58
When Environments Shift: Safe Planning with Generative Priors and Robust Conformal Prediction
Model predictive control · deck
 9:50
Taming I2V models for Image HOI Editing: A Cognitive Benchmark and Agentic Self-Correcting Framework
Diffusion models · deck
 5:29
Responsible Text-to-Image Diffusion: Interpretable and Linearly Controllable Semantics for Fair and Safe Generation
Open-vocabulary perception · deck
 8:59
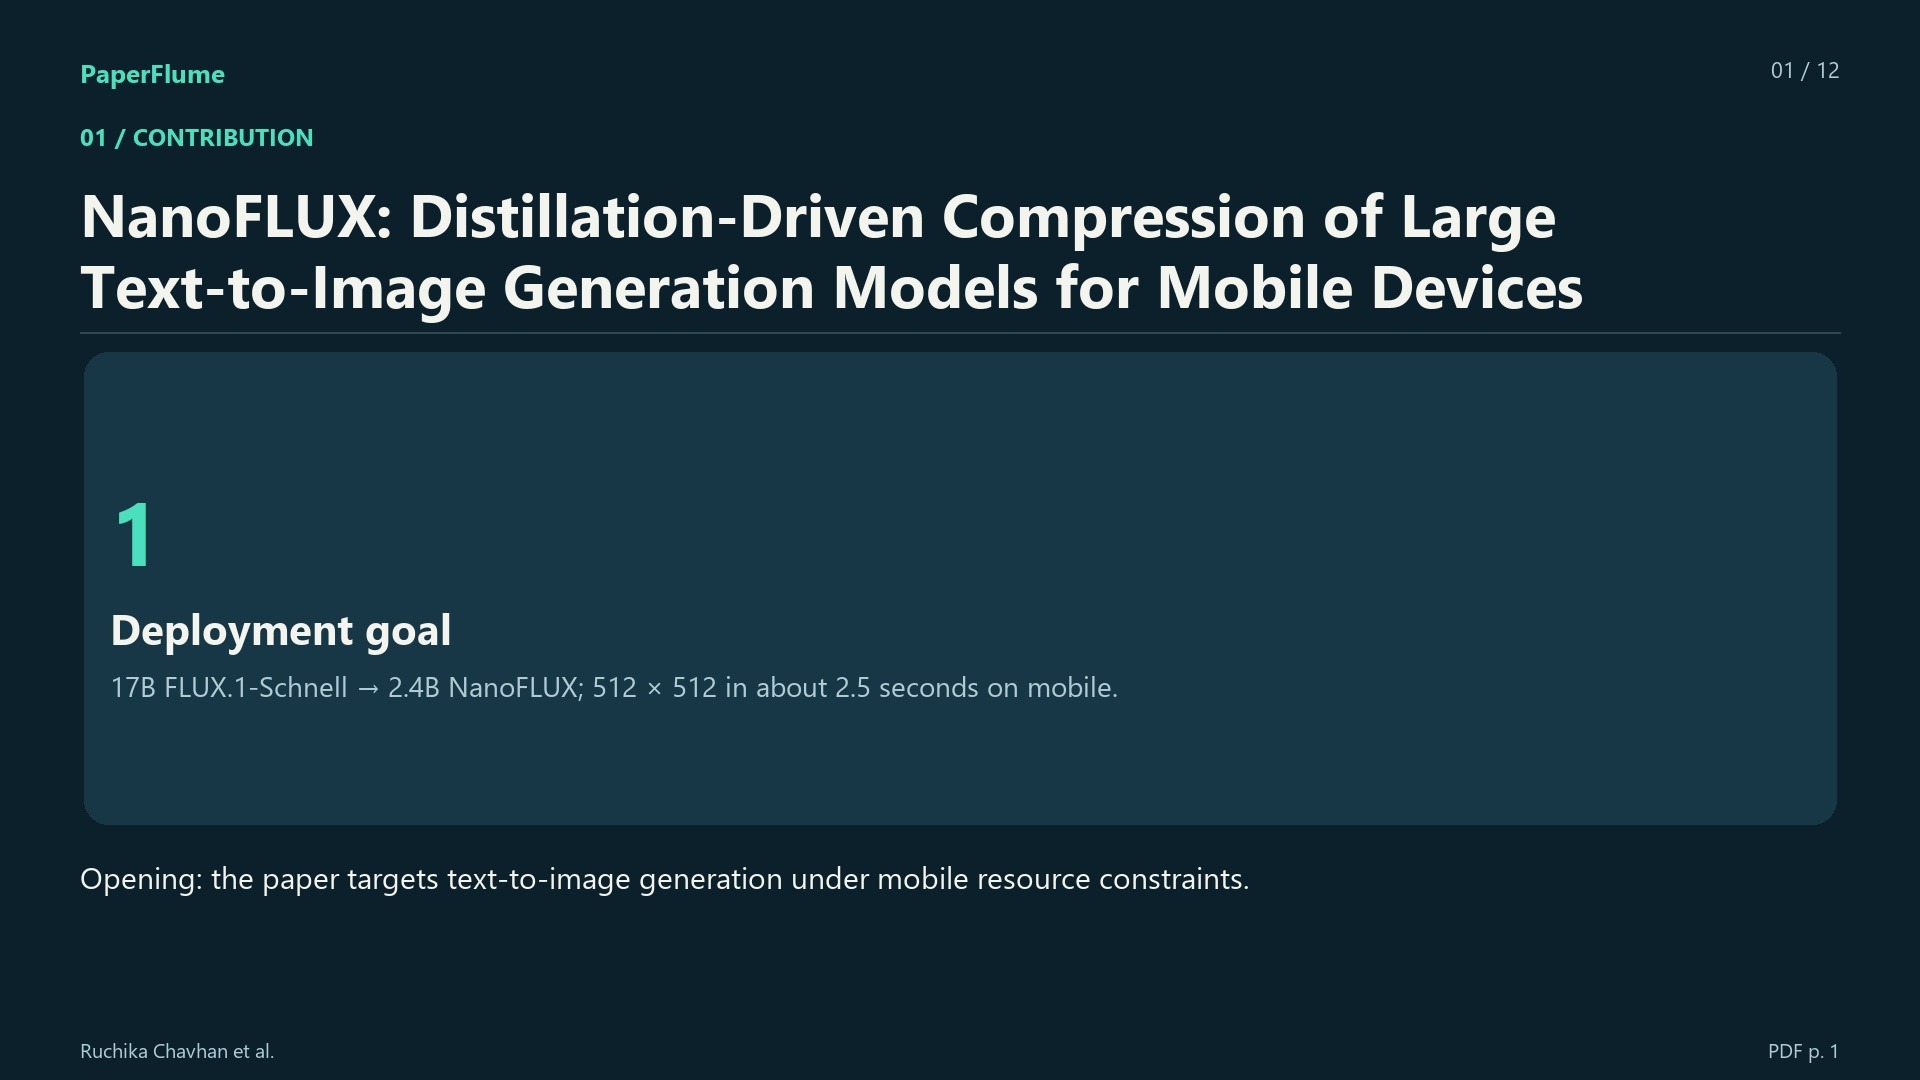
NanoFLUX: Distillation-Driven Compression of Large Text-to-Image Generation Models for Mobile Devices
Neural rendering · deck
Manipulation
See all 20 →
6:45
ManiGuard: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
VLA models · deck
2608.17386
6:45
RHO: Your Coding Agent is Secretly a Roboticist
Multimodal LLMs · deck
2606.16458
5:47
Unified Visual-Tactile-Action Modeling from Human Demonstrations for Dexterous Manipulation
Dexterous hands · deck
2609.34182
4:58
Learning Long-Horizon Robot Manipulation Skills via Privileged Action
· deck
6:14
SPIN: distilling Skill-RRT for long-horizon prehensile and non-prehensile manipulation
· deck
 5:54
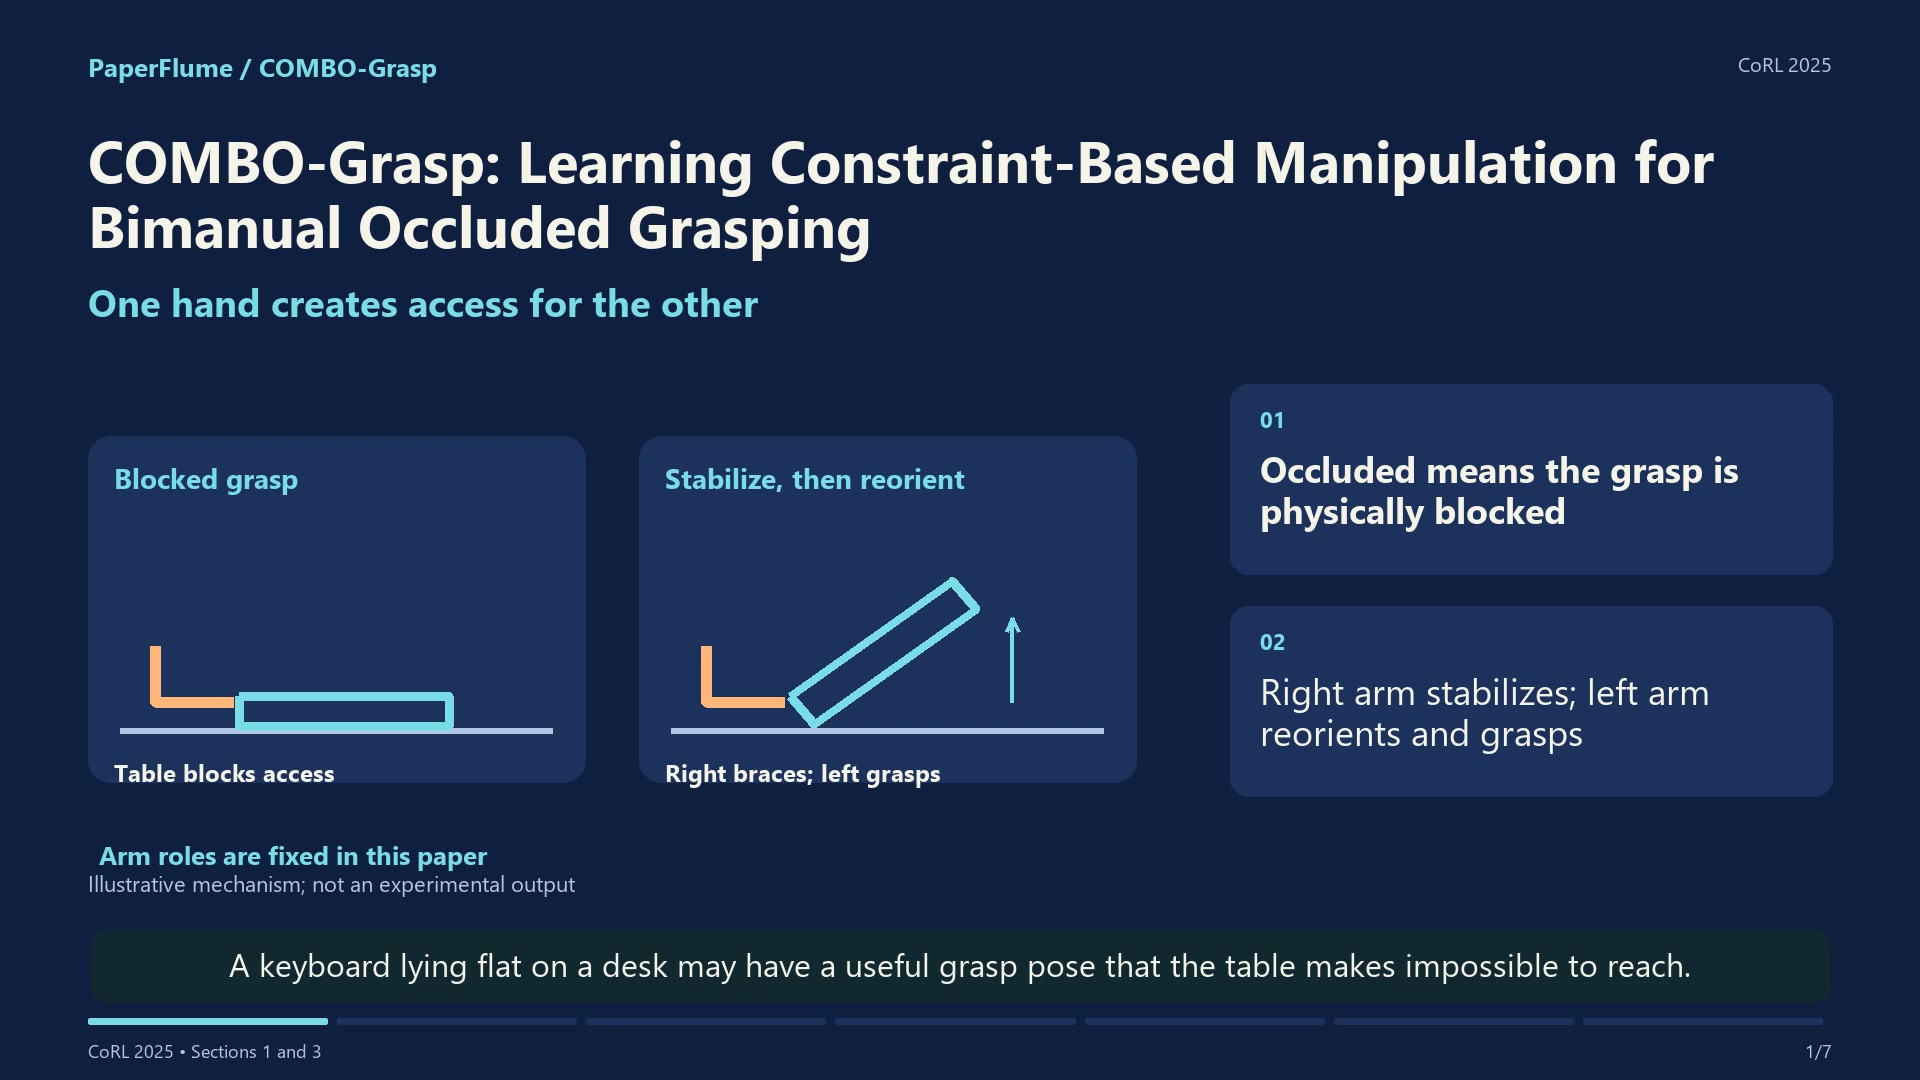
COMBO-Grasp: Learning Constraint-Based Manipulation for Bimanual Occluded Grasping
Grasping · deck
5:42
CHD: Coupled Hierarchical Diffusion for Long-Horizon Tasks
Diffusion models · deck
6:33
LaDi-WM: A Latent Diffusion-Based World Model for Predictive Manipulation
Diffusion models · deck
 7:39
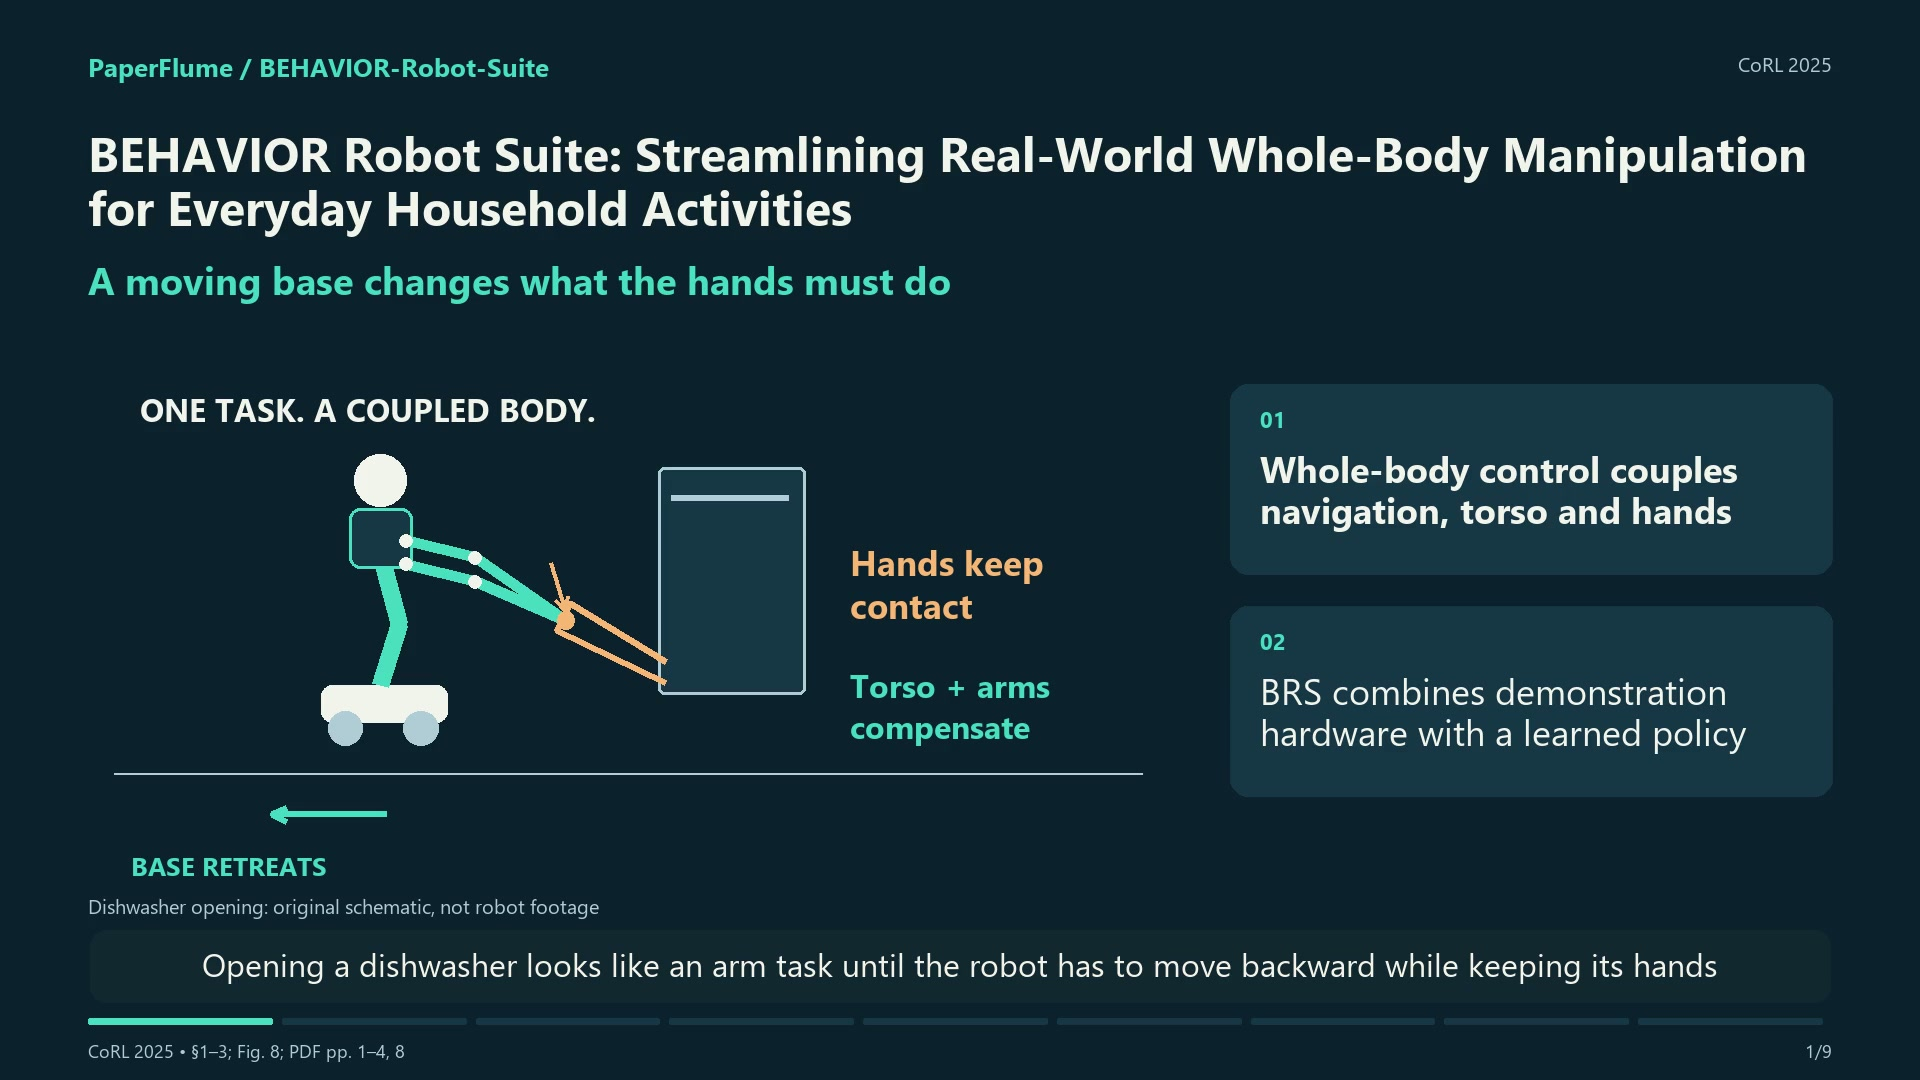
BEHAVIOR Robot Suite: Streamlining Real-World Whole-Body Manipulation for Everyday Household Activities
Mobile manipulation · deck
10:43
TopoCut: Learning Multi-Step Cutting with Spectral Rewards and Discrete Diffusion Policies
RL for control · deck
9:33
Diffusion Dynamics Models with Generative State Estimation for Cloth Manipulation
Diffusion models · deck
 9:35
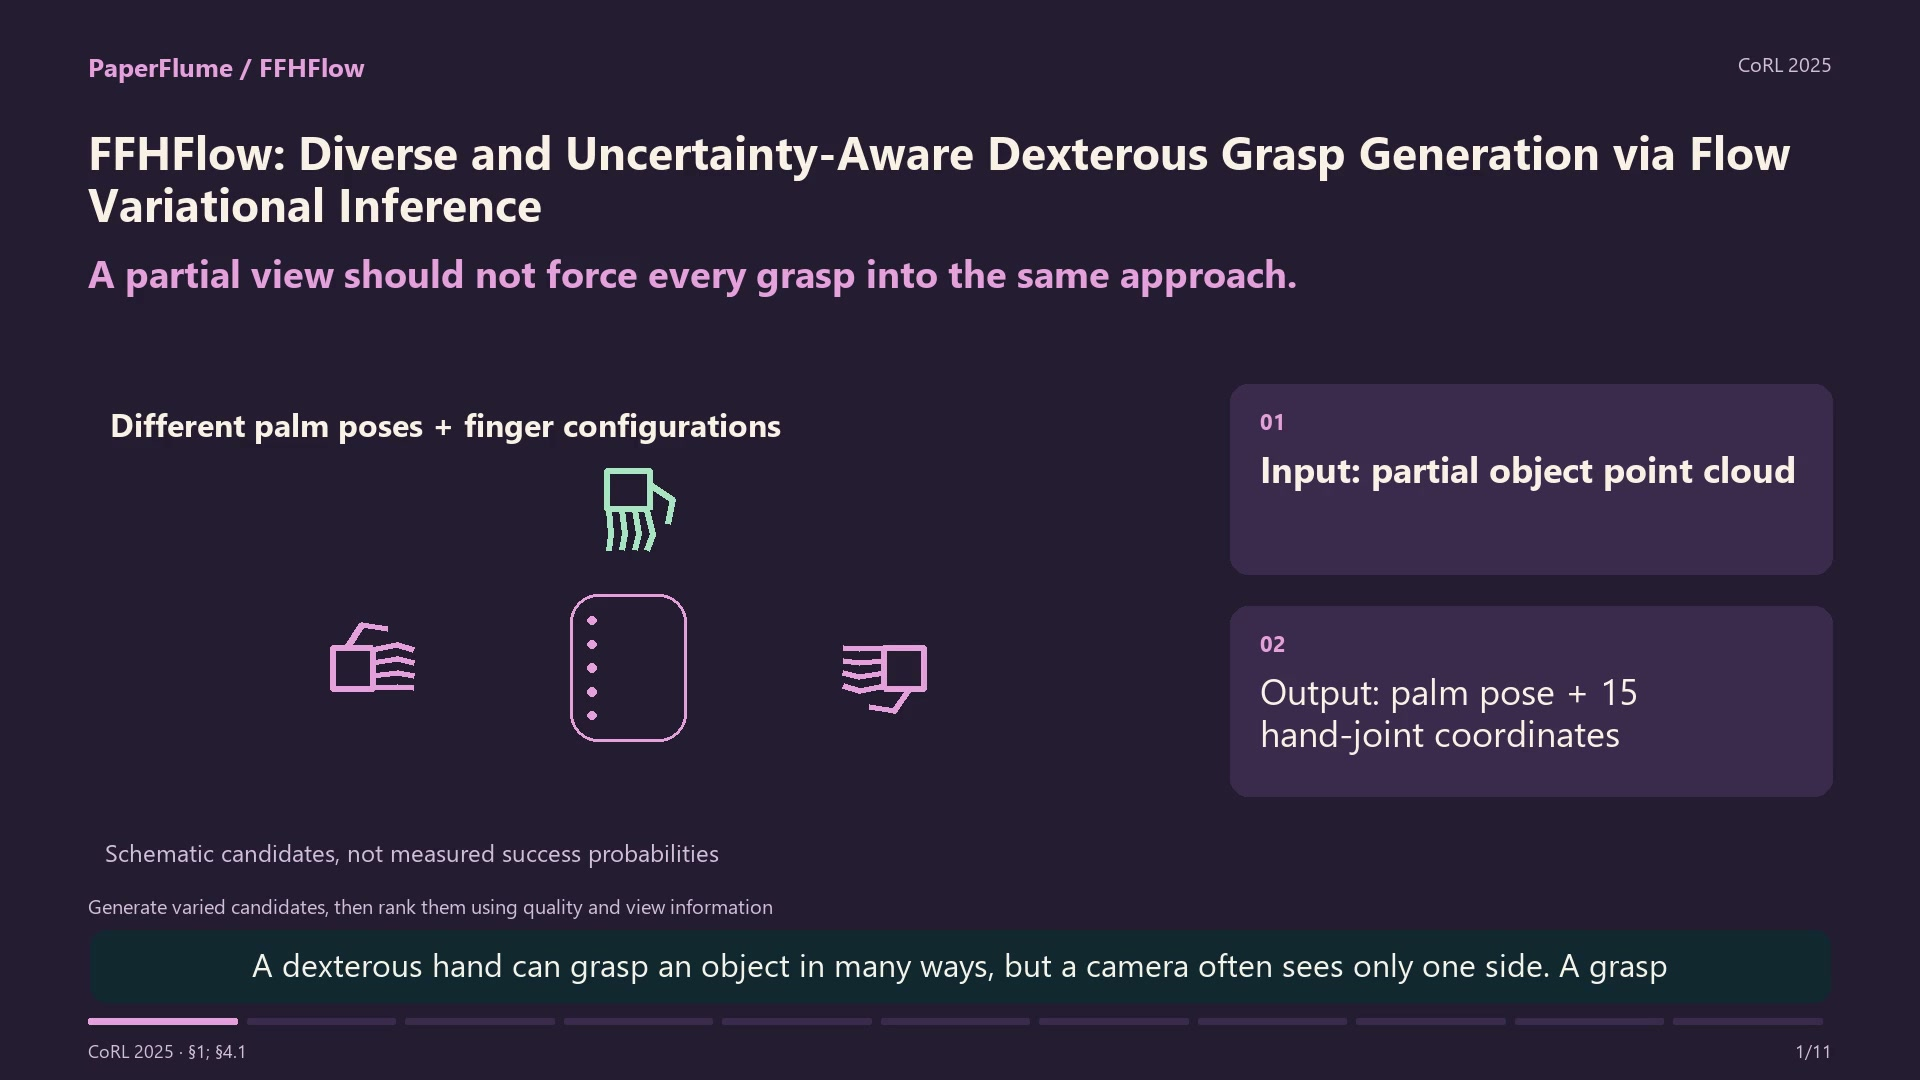
FFHFlow: Diverse and Uncertainty-Aware Dexterous Grasp Generation via Flow Variational Inference
Grasping · deck
 4:19
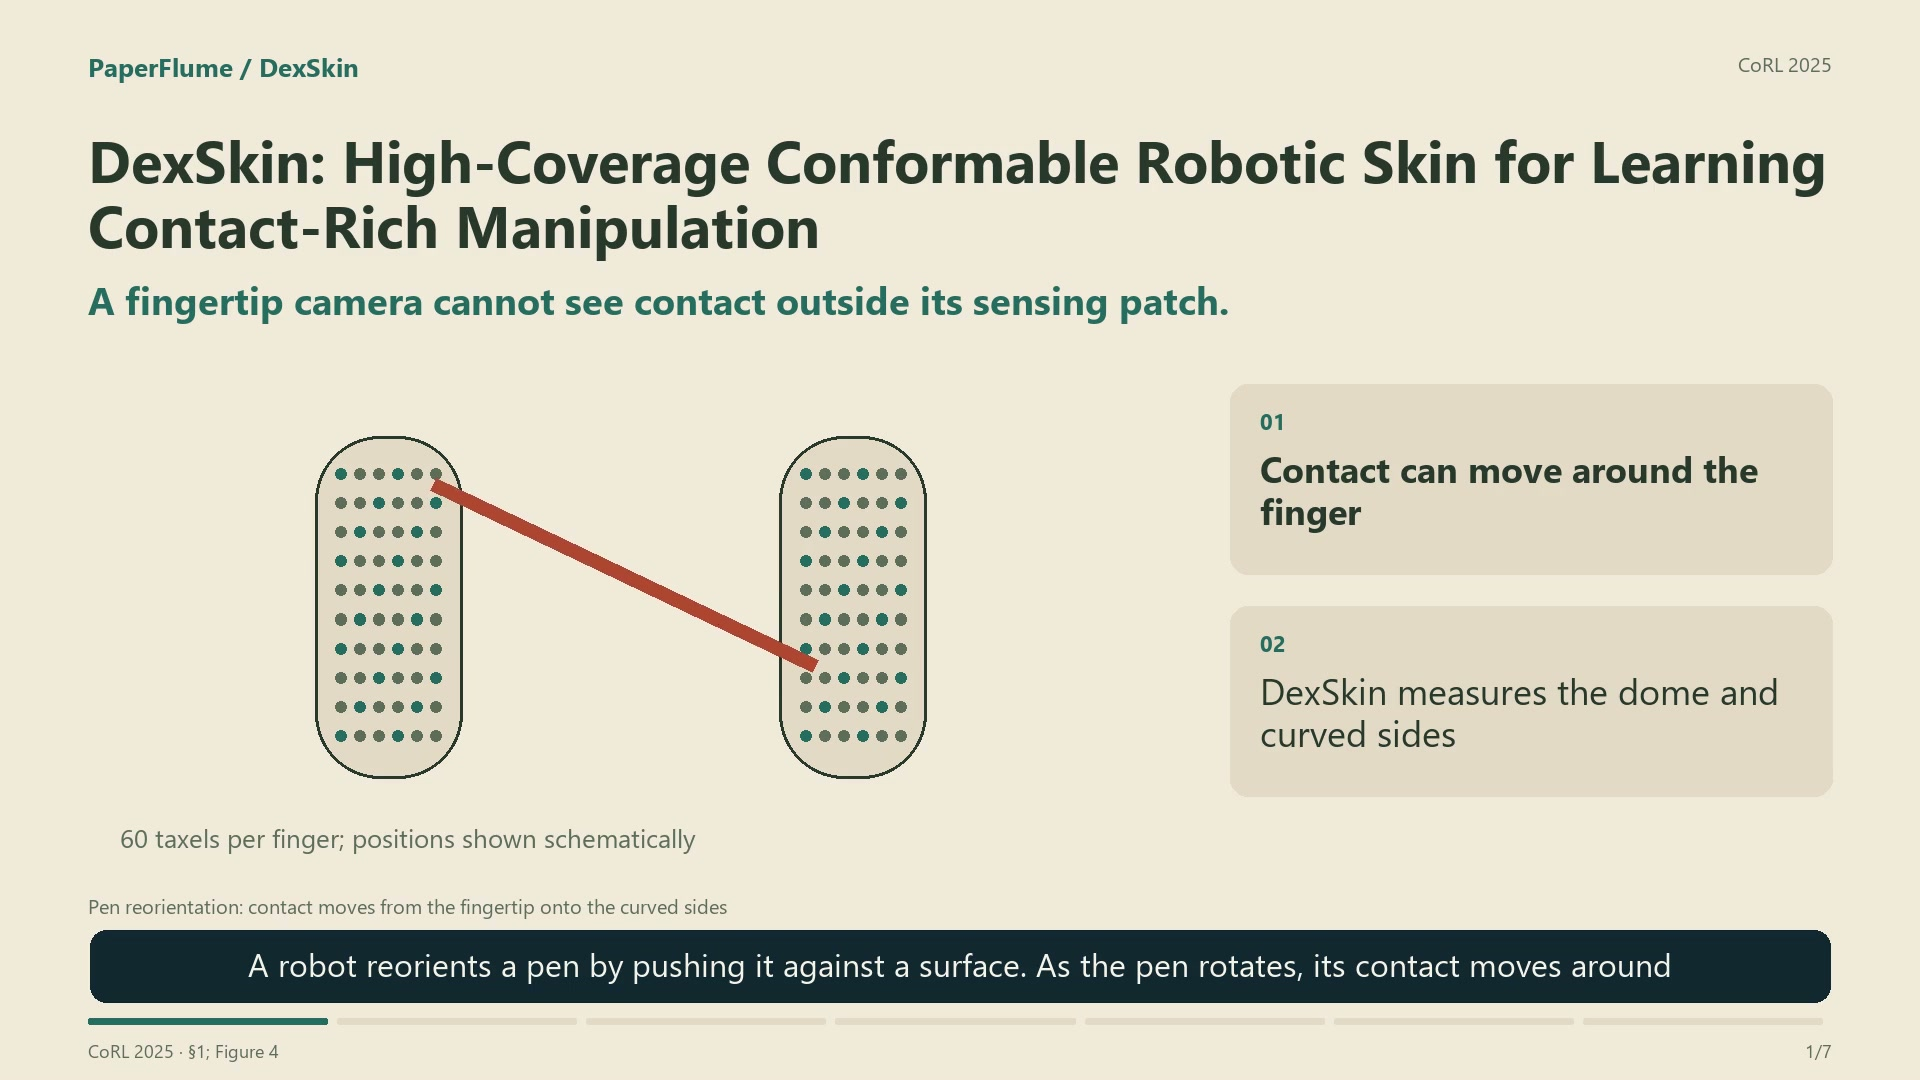
DexSkin: High-Coverage Conformable Robotic Skin for Learning Contact-Rich Manipulation
Dexterous hands · deck
 5:52
“Stack It Up!”: 3D Stable Structure Generation from 2D Hand-drawn Sketch
· deck
 6:00
Fabrica: Dual-Arm Assembly of General Multi-Part Objects via Integrated Planning and Learning
· deck
 7:37
Versatile Loco-Manipulation through Flexible Interlimb Coordination
Mobile manipulation · deck
 5:00
Learning a Unified Policy for Position and Force Control in Legged Loco-Manipulation
Mobile manipulation · deck
 5:19
ClutterDexGrasp: A Sim-to-Real System for General Dexterous Grasping in Cluttered Scenes
Grasping · deck
 5:43
Reactive In-Air Clothing Manipulation with Confidence-Aware Dense Correspondence and Visuotactile Affordance
· deck
 5:49
KineSoft: Learning Proprioceptive Manipulation Policies with Soft Robot Hands
Dexterous hands · deck
3D reconstruction
See all 20 →
8:24
Foundation4D: Towards a unified perception and reconstruction model for autonomous vehicles
Gaussian splatting · deck
2610.30340
 6:09
Geometric Algebra Planes: Convex Implicit Neural Volumes
Neural rendering · deck
 4:32
HybridGS: High-Efficiency Gaussian Splatting Data Compression using Dual-Channel Sparse Representation and Point Cloud Encoder
Gaussian splatting · deck
 5:31
Perceptual-GS: Scene-adaptive Perceptual Densification for Gaussian Splatting
Gaussian splatting · deck
 5:55
3D-LMVIC: Learning-based Multi-View Image Compression with 3D Gaussian Geometric Priors
Multi-view stereo · deck
 6:49
Predicting High-precision Depth on Low-Precision Devices Using 2D Hilbert Curves
Efficient inference · deck
 4:57
Flex3D: Feed-Forward 3D Generation with Flexible Reconstruction Model and Input View Curation
· deck
 3:41
Position: You Can’t Manufacture a NeRF
Neural rendering · deck
6:52
TVDRNet: Text-driven Viewpoint Optimization via Differentiable Rendering for 3D Reasoning Segmentation
Neural rendering · deck
8:59
NanoFLUX: Distillation-Driven Compression of Large Text-to-Image Generation Models for Mobile Devices
Neural rendering · deck
 7:05
GaussTrace: Provenance Analysis of 3D Gaussian Splatting Models with Evidence-based LLM Reasoning
Gaussian splatting · deck
 7:14
Revisiting Photometric Ambiguity for Accurate Gaussian-Splatting Surface Reconstruction
Gaussian splatting · deck
 7:56
Scalable and Differentiable Point-Cloud Registration Using Maximum Mean Discrepancy
Multi-view stereo · deck
 8:15
RGGT: A Generative-Prior-Guided Transformer for Unified Rigid and Non-Rigid Point Cloud Registration
Neural rendering · deck
 9:42
PVDepth: Panoramic Video Depth Estimation via Geometry-Aware Spatiotemporal Adaptation
Neural rendering · deck
 7:16
PolarDepth: Monocular Transparent Object Depth from Polar-Physics Priors
Multi-view stereo · deck
 7:19
DynaTok: Token-Based 4D Reconstruction from Partial Point Clouds
Neural rendering · deck
 8:16
CG-MLLM: Captioning and Generating 3D Content via Multi-modal Large Language Models
Neural rendering · deck
 6:28
3DGS-HPC: Distractor-free 3D Gaussian Splatting with Hybrid Patch-wise Classification
Gaussian splatting · deck
 5:58
Let Language Constrain Geometry: Vision–Language Models as Semantic and Spatial Critics for 3D Generation
Neural rendering · deck
Human-robot interaction
See all 19 →
5:47
Unified Visual-Tactile-Action Modeling from Human Demonstrations for Dexterous Manipulation
Dexterous hands · deck
2609.34182
 5:36
Adapt3R: Adaptive 3D Scene Representation for Domain Transfer in Imitation Learning
Learning from demonstration · deck
 5:46
Estimating Value of Assistance for Online POMDP Robotic Agents
Shared autonomy · deck
 4:48
FlashBack: Consistency Model-Accelerated Shared Autonomy
Shared autonomy · deck
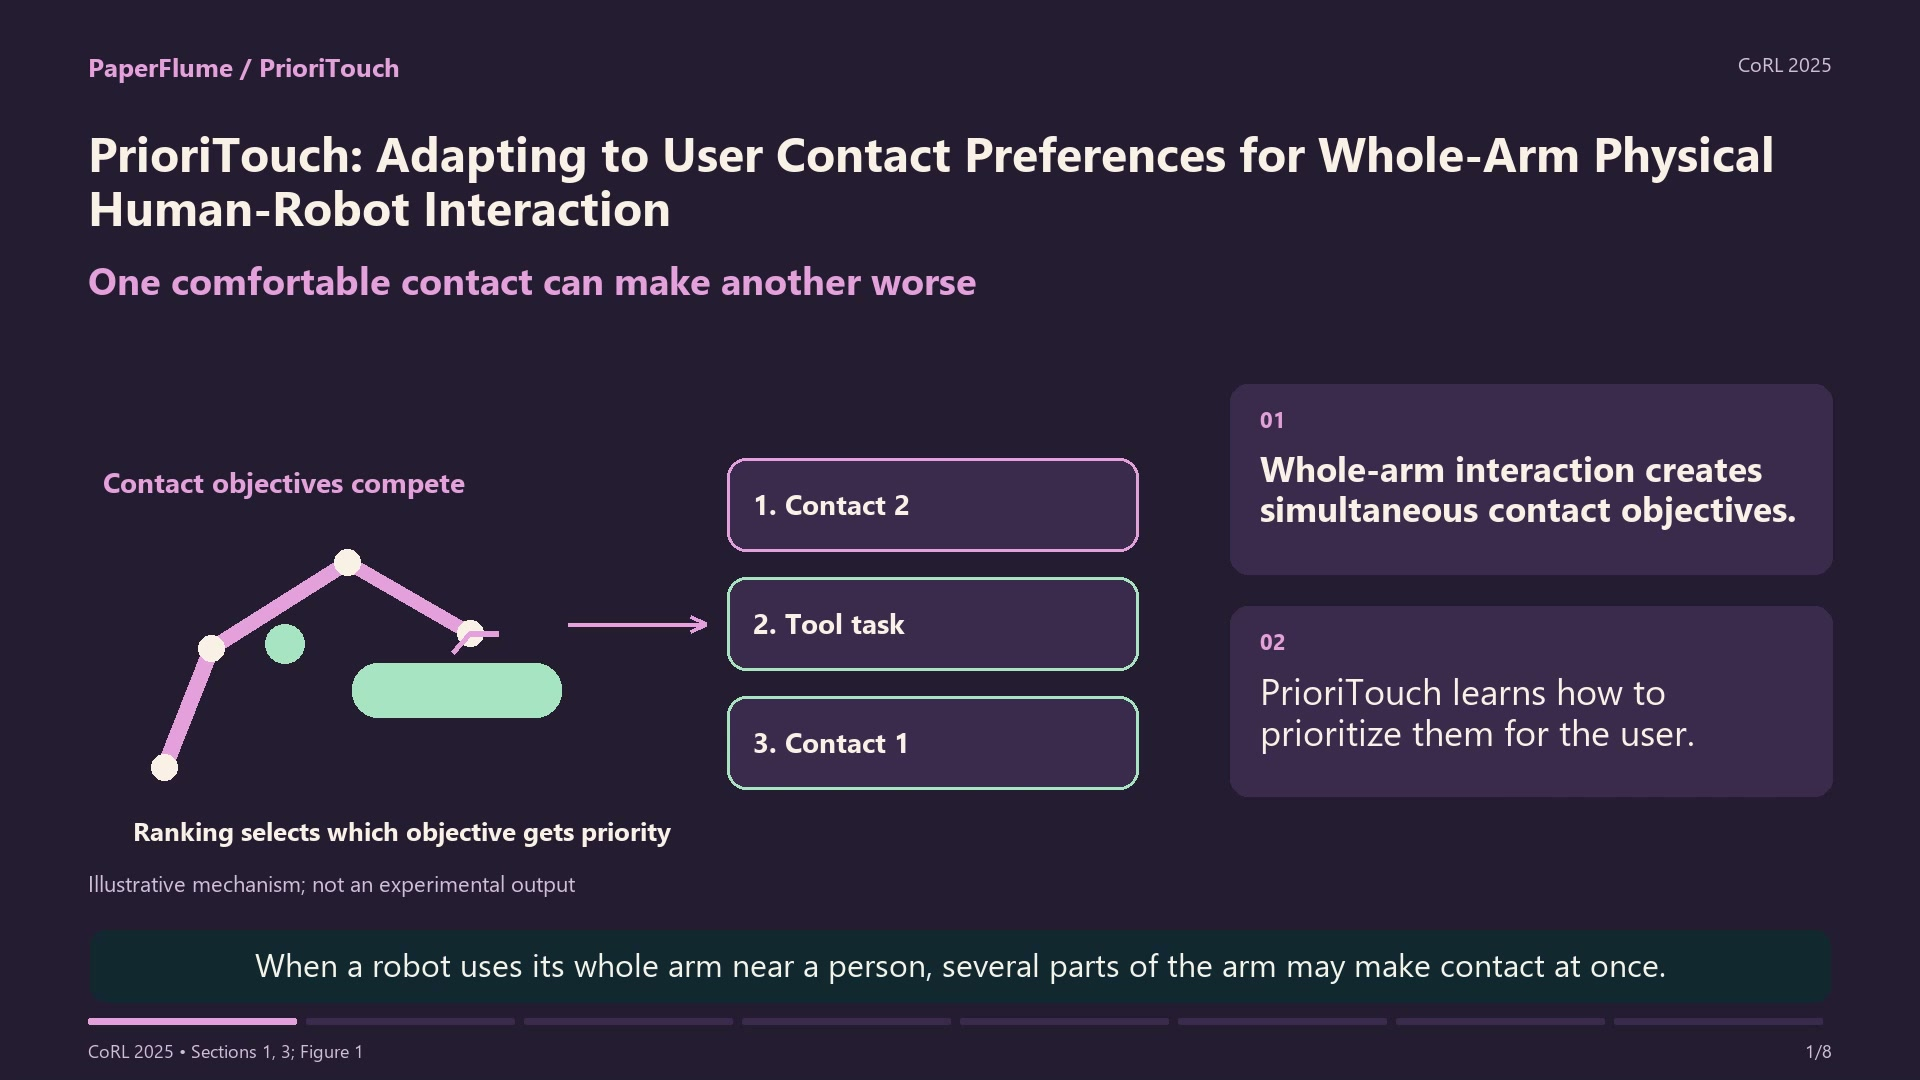 4:41
PrioriTouch: Adapting to User Contact Preferences for Whole-Arm Physical Human-Robot Interaction
· deck
5:26
KDPE: A Kernel Density Estimation Strategy for Diffusion Policy Trajectory Selection
Learning from demonstration · deck
 5:51
Data Retrieval with Importance Weights for Few-Shot Imitation Learning
Learning from demonstration · deck
 5:03
AirExo-2: Scaling up Generalizable Robotic Imitation Learning with Low-Cost Exoskeletons
Learning from demonstration · deck
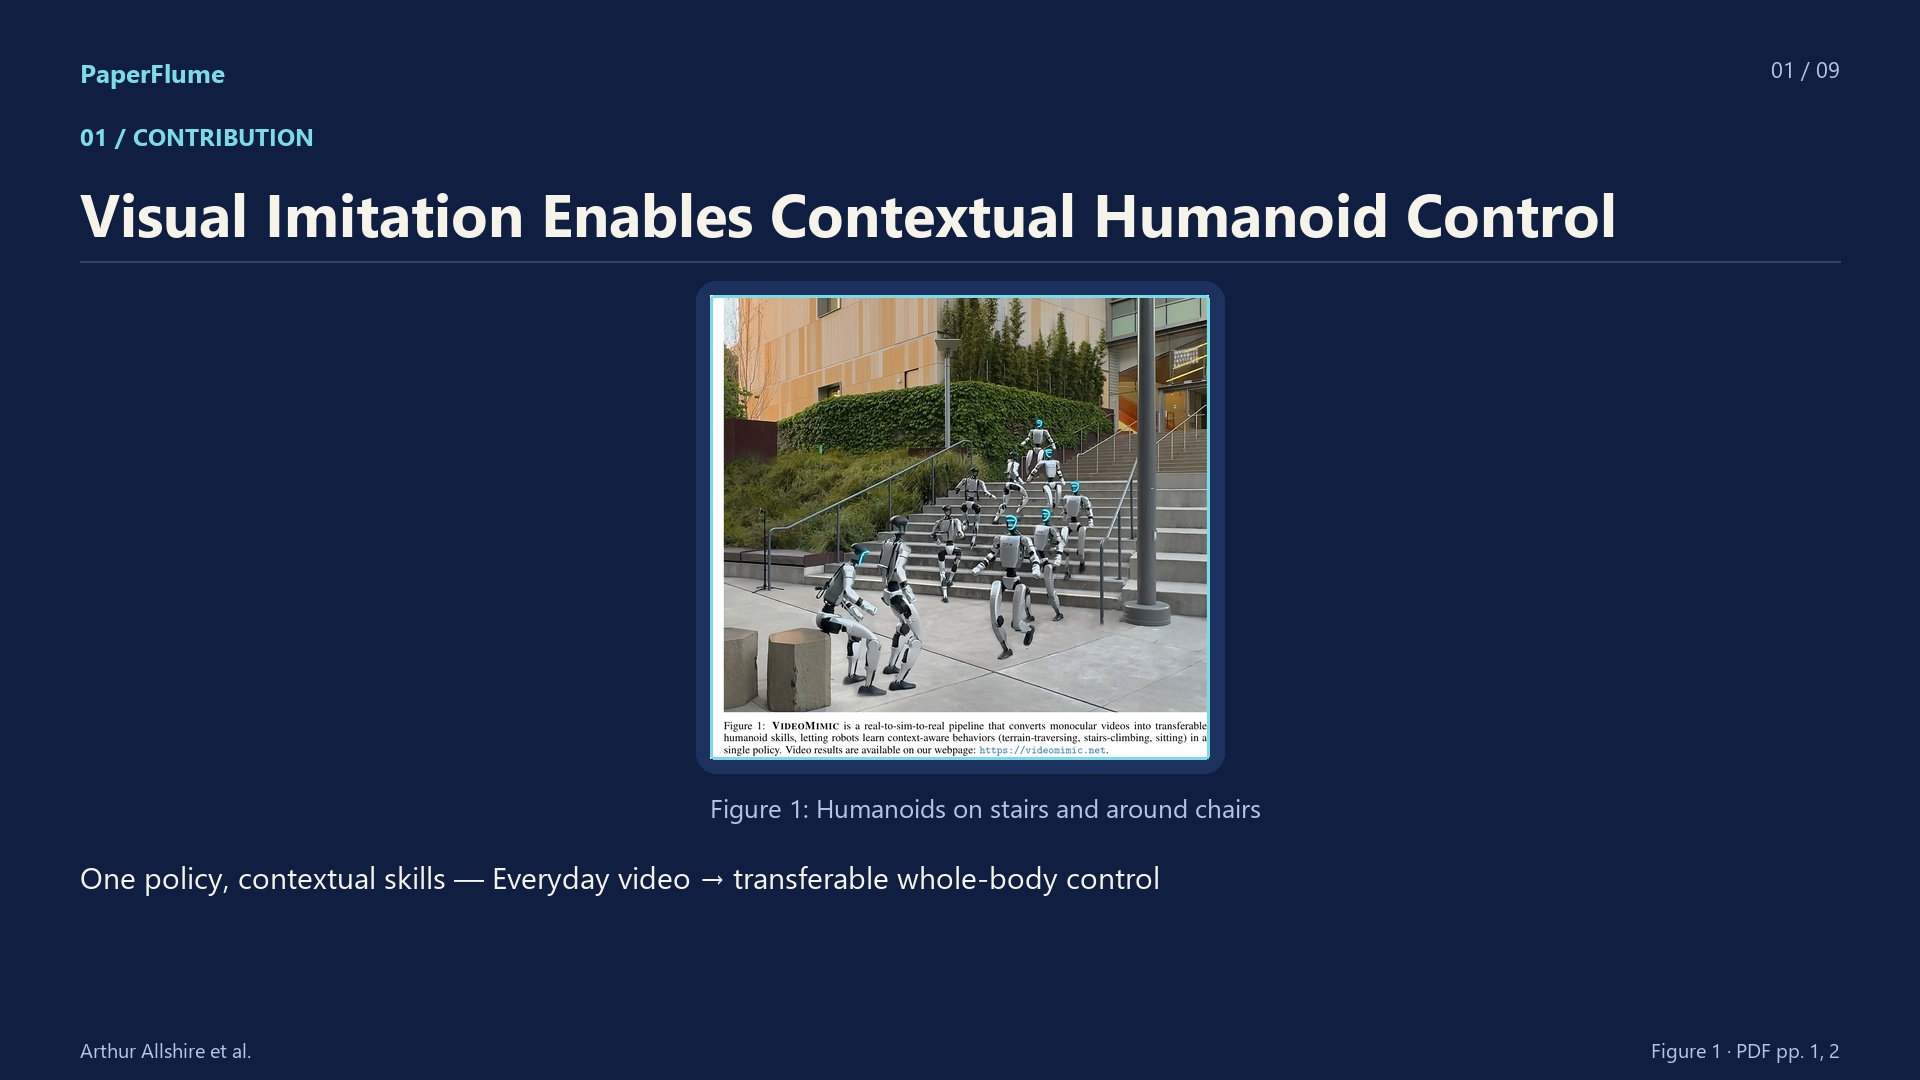 7:51
Visual Imitation Enables Contextual Humanoid Control
Learning from demonstration · deck
 7:52
SAIL: Faster-than-Demonstration Execution of Imitation Learning Policies
Learning from demonstration · deck
 5:31
ImMimic: Cross-Domain Imitation from Human Videos via Mapping and Interpolation
Learning from demonstration · deck
 5:51
DemoSpeedup: Accelerating Visuomotor Policies via Entropy-Guided Demonstration Acceleration
Learning from demonstration · deck
 7:38
A Robust Task-Level Control Architecture for Learned Dynamical Systems
Learning from demonstration · deck
 6:36
Escaping the Diversity Trap in Robotic Manipulation via Anchor-Centric Adaptation
Learning from demonstration · deck
 7:52
GCIMOPT: Learning efficient goal-conditioned policies by imitating optimal trajectories
Trajectory optimisation · deck
 6:37
Active Constraint Learning in High Dimensions from Demonstrations
Trajectory optimisation · deck
 6:58
XR-1: Towards Versatile Vision-Language-Action Models via Learning Unified Vision-Motion Representations
Learning from demonstration · deck
 6:50
DexUMI: Using Human Hand as the Universal Manipulation Interface for Dexterous Manipulation
Dexterous hands · deck
 6:17
HoMMI: Learning Whole-Body Mobile Manipulation from Human Demonstrations
Mobile manipulation · deck
2603.03243
Compute and efficiency
See all 17 →
5:01
TinyMIG: Transferring Generalization from Vision Foundation Models to Single-Domain Medical Imaging
· deck
6:23
Compressed Image Generation with Denoising Diffusion Codebook Models
Diffusion models · deck
4:48
FlashBack: Consistency Model-Accelerated Shared Autonomy
Shared autonomy · deck
4:32
HybridGS: High-Efficiency Gaussian Splatting Data Compression using Dual-Channel Sparse Representation and Point Cloud Encoder
Gaussian splatting · deck
5:57
Hybrid Spiking Vision Transformer for Object Detection with Event Cameras
Object detection · deck
5:55
3D-LMVIC: Learning-based Multi-View Image Compression with 3D Gaussian Geometric Priors
Multi-view stereo · deck
7:20
Point Cloud Dataset Distillation
Point cloud understanding · deck
6:49
Predicting High-precision Depth on Low-Precision Devices Using 2D Hilbert Curves
Efficient inference · deck
8:00
Exploring Vision Semantic Prompt for Efficient Point Cloud Understanding
Point cloud understanding · deck
8:12
GAPrompt: Geometry-Aware Point Cloud Prompt for 3D Vision Model
Point cloud understanding · deck
5:21
Training Strategies for Efficient Embodied Reasoning
VLA models · deck
5:31
Prototype-Based Test-Time Adaptation of Vision-Language Models
Test-time scaling · deck
5:49
Attention Sparsity is Input-Stable: Training-Free Sparse Attention for Video Generation via Offline Sparsity Profiling and Online QK Co-Clustering
Video generation · deck
5:50
Self-Refining Video Sampling
Video generation · deck
6:25
SPARC: Separating Perception And Reasoning Circuits for Test-time Scaling of VLMs
Multimodal LLMs · deck
7:19
MoDA: Modulation Adapter for Fine-Grained Visual Understanding in Instructional MLLMs
Multimodal fusion · deck
6:45
Motion-Aware Caching for Efficient Autoregressive Video Generation
Diffusion models · deck
Learning paradigms
See all 14 →
4:39
iDPA: Instance Decoupled Prompt Attention for Incremental Medical Object Detection
Continual learning · deck
5:36
Adapt3R: Adaptive 3D Scene Representation for Domain Transfer in Imitation Learning
Learning from demonstration · deck
7:19
Unpaired Point Cloud Completion via Unbalanced Optimal Transport
Point cloud understanding · deck
 6:46
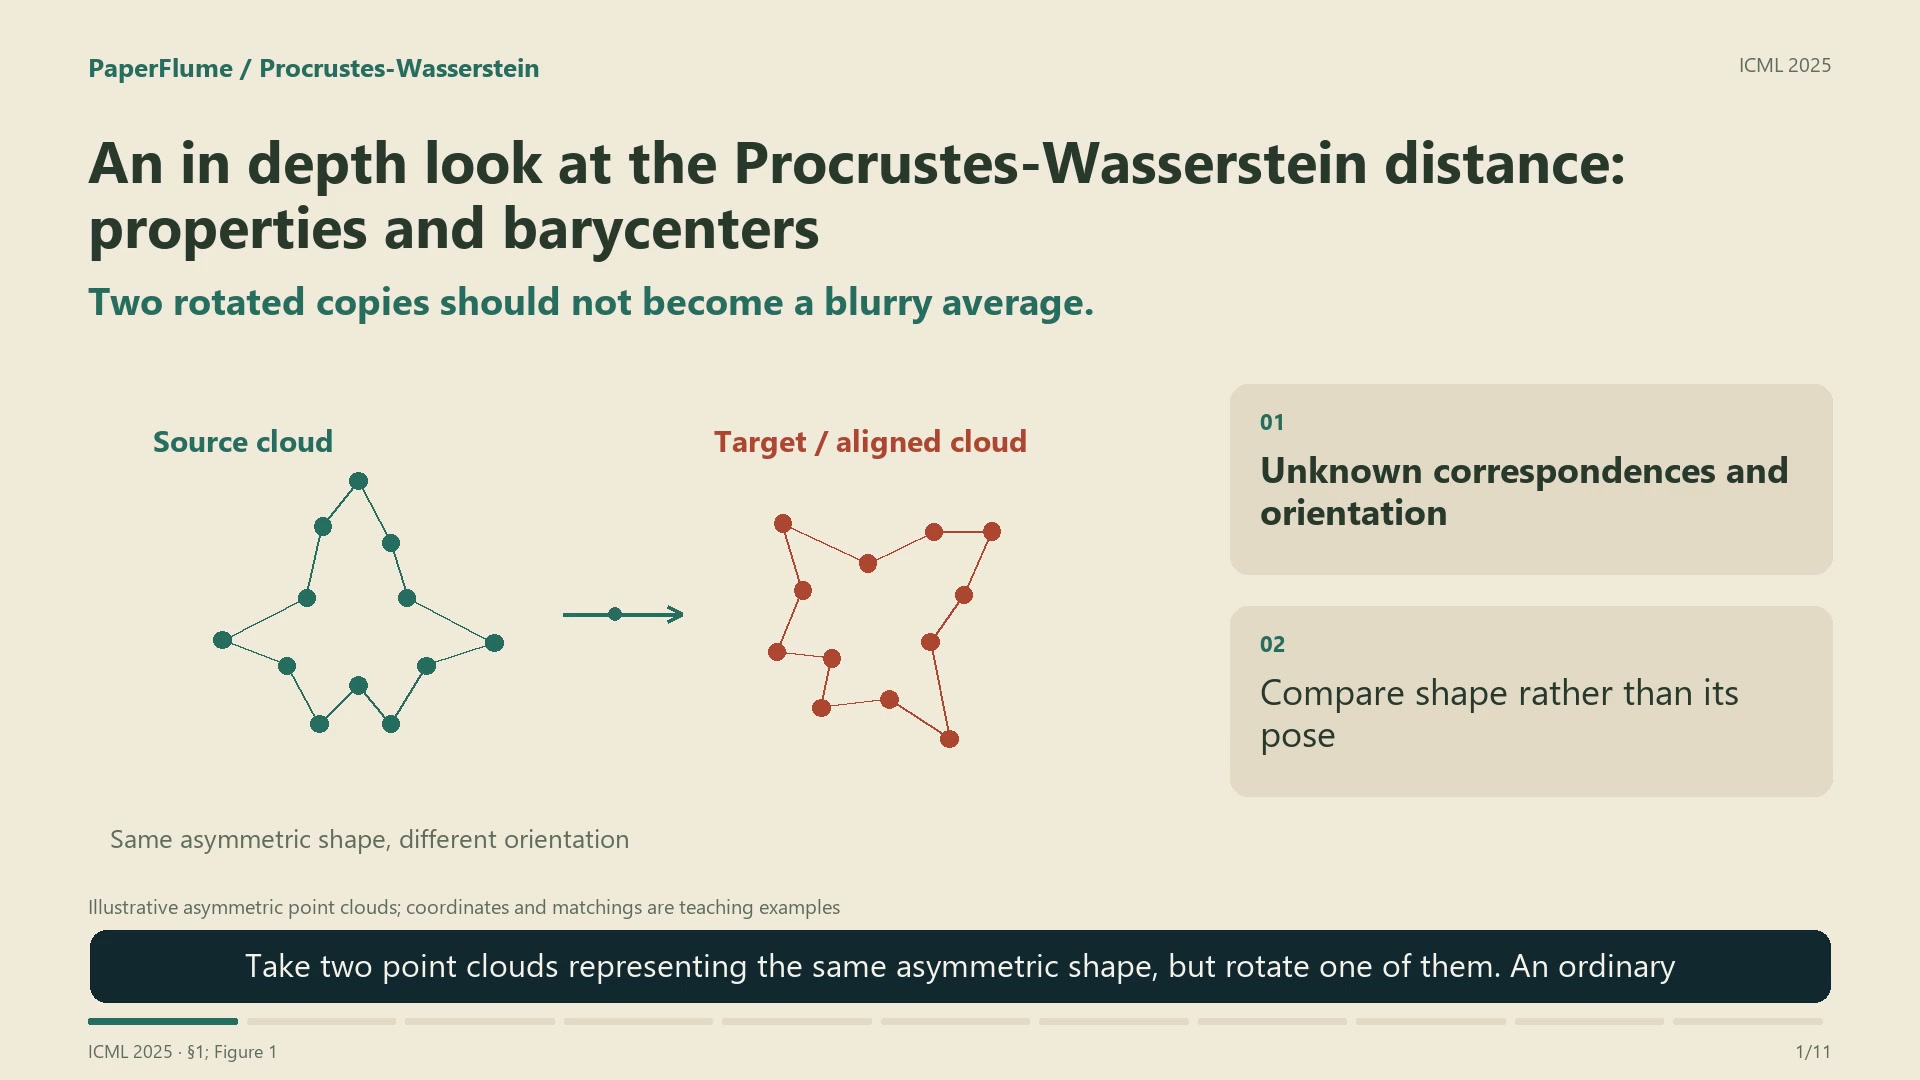
An in depth look at the Procrustes-Wasserstein distance: properties and barycenters
· deck
 3:50
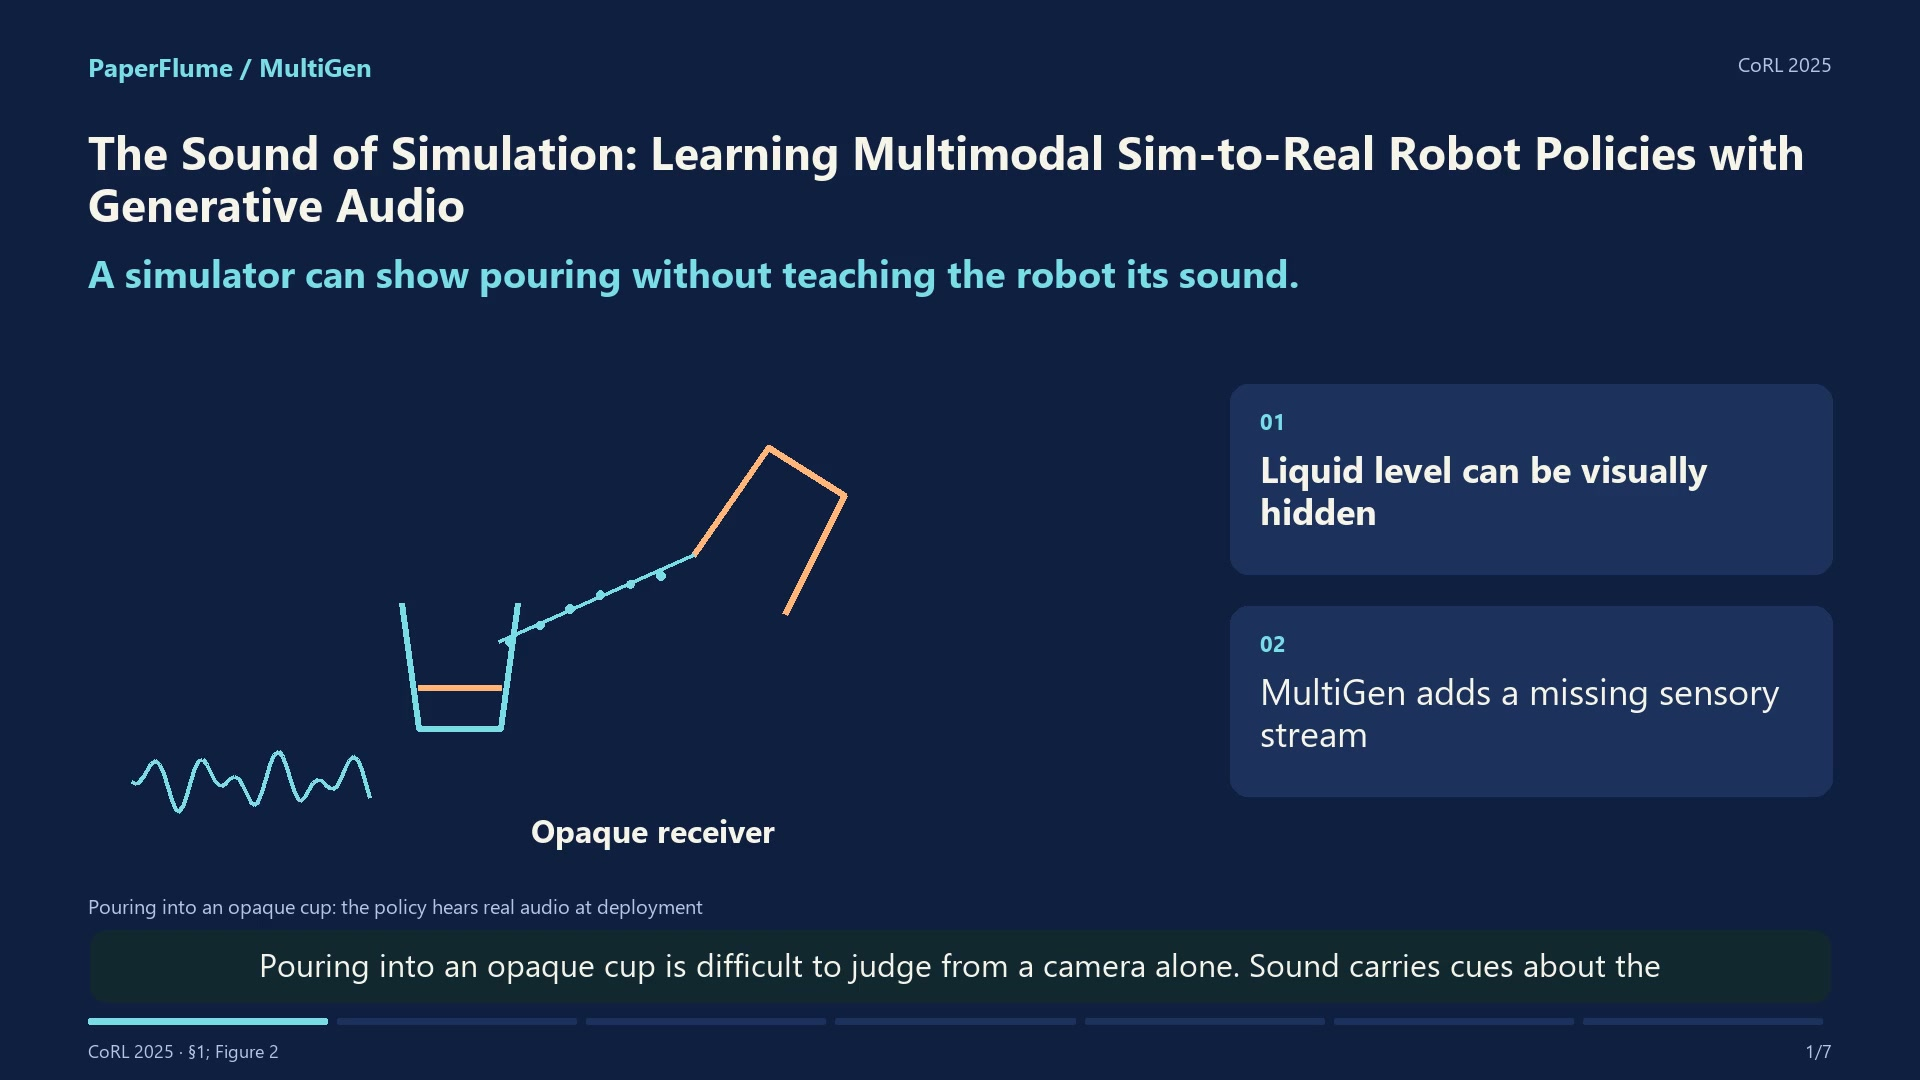
The Sound of Simulation: Learning Multimodal Sim-to-Real Robot Policies with Generative Audio
Sim-to-real transfer · deck
 6:47
Real2Render2Real: Scaling Robot Data Without Dynamics Simulation or Robot Hardware
Sim-to-real transfer · deck
 6:41
Sampling-based System Identification with Active Exploration for Legged Sim2Real Learning
Sim-to-real transfer
 6:42
X-Sim: Cross-Embodiment Learning via Real-to-Sim-to-Real
Sim-to-real transfer
 7:29
FetchBot: Learning Generalizable Object Fetching in Cluttered Scenes via Zero-Shot Sim2Real
Sim-to-real transfer · deck
 5:42
One View, Many Worlds: Single-Image to 3D Object Meets Generative Domain Randomization for One-Shot 6D Pose Estimation
Sim-to-real transfer · deck
 6:30
Adapting World Models with Latent-State Dynamics Residuals
Sim-to-real transfer · deck
6:46
Amodal Instance Segmentation with IRAIS Dataset for Sim-to-Real Transfer
Segmentation · deck
6:41
Focus, Align, and Sustain: Counteracting Gradient Dilution in Incremental Object Detection
Object detection · deck
 7:01
MedCRP-CL: Continual Medical Image Segmentation via Bayesian Nonparametric Semantic Modality Discovery
Segmentation · deck
Short overviews
 0:57
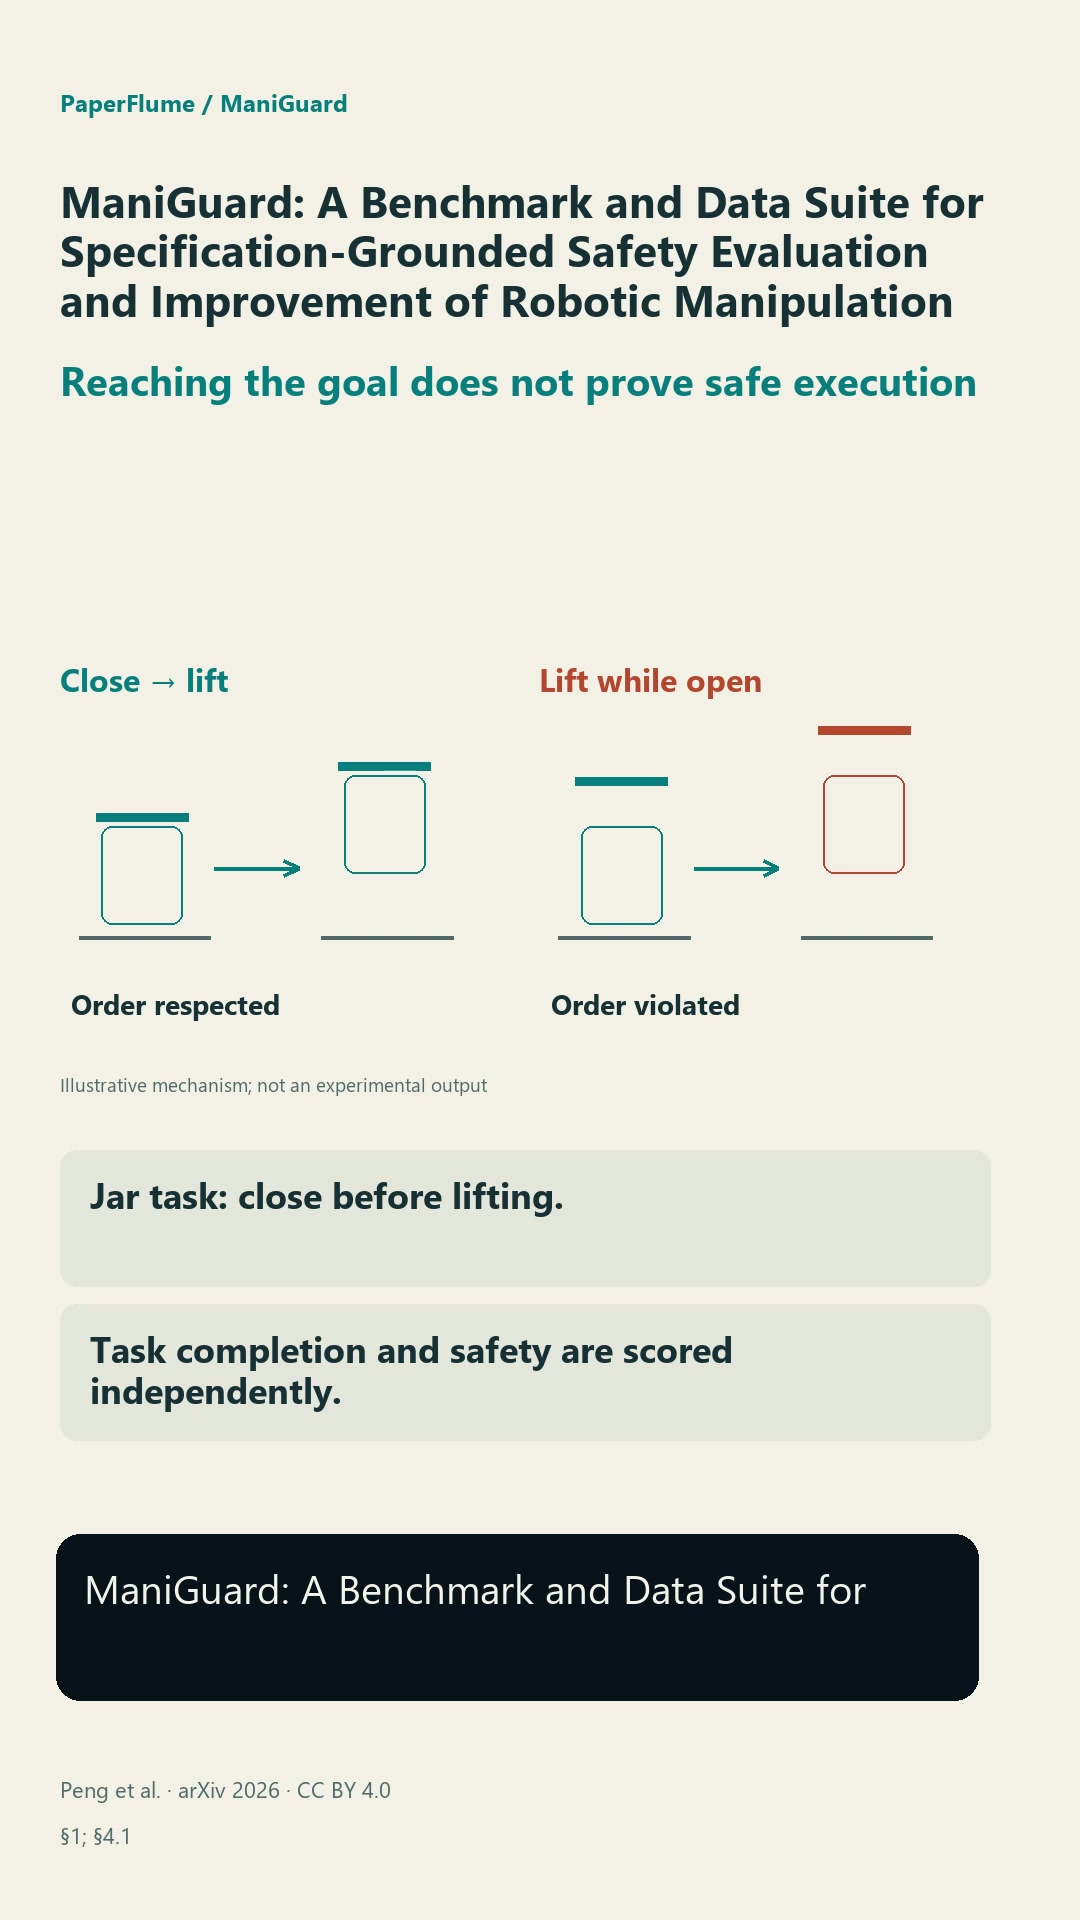
ManiGuard: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
VLA models
2608.17386
 0:57
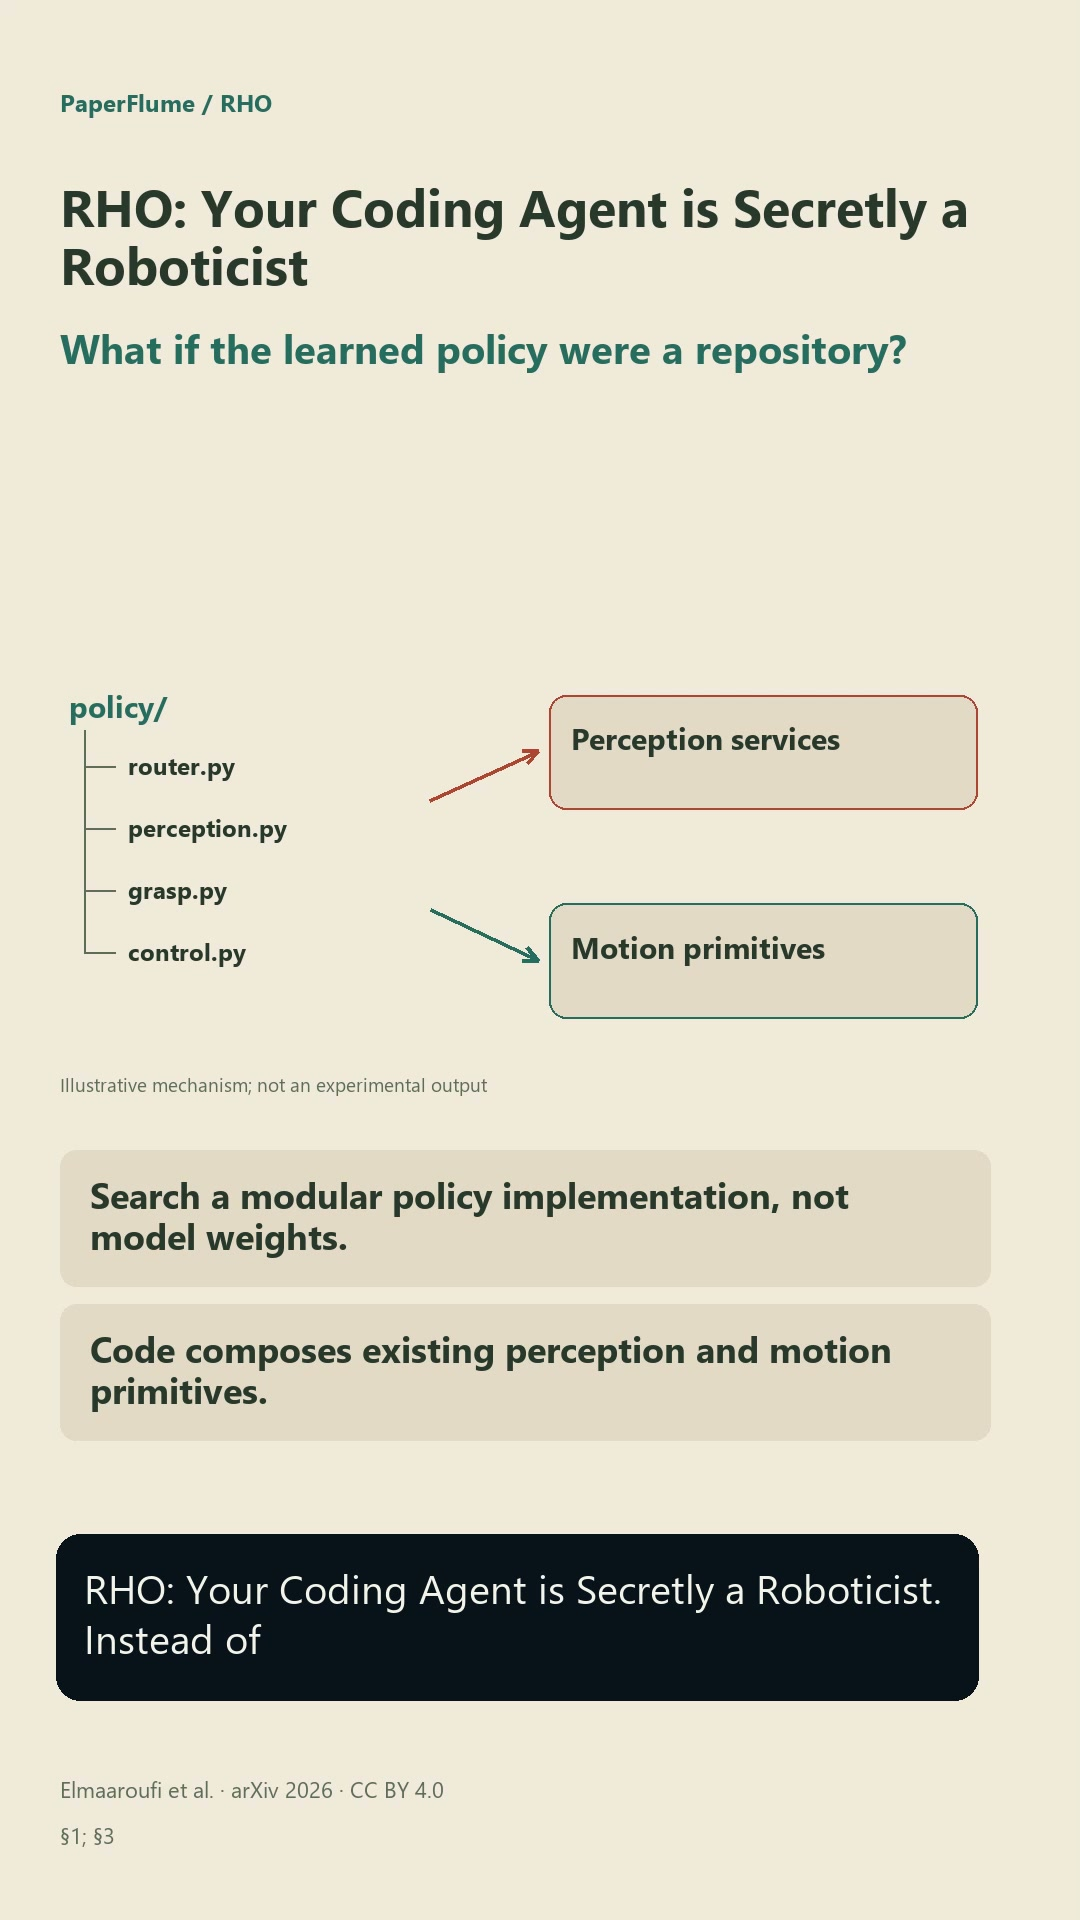
RHO: Your Coding Agent is Secretly a Roboticist
Multimodal LLMs
2606.16458
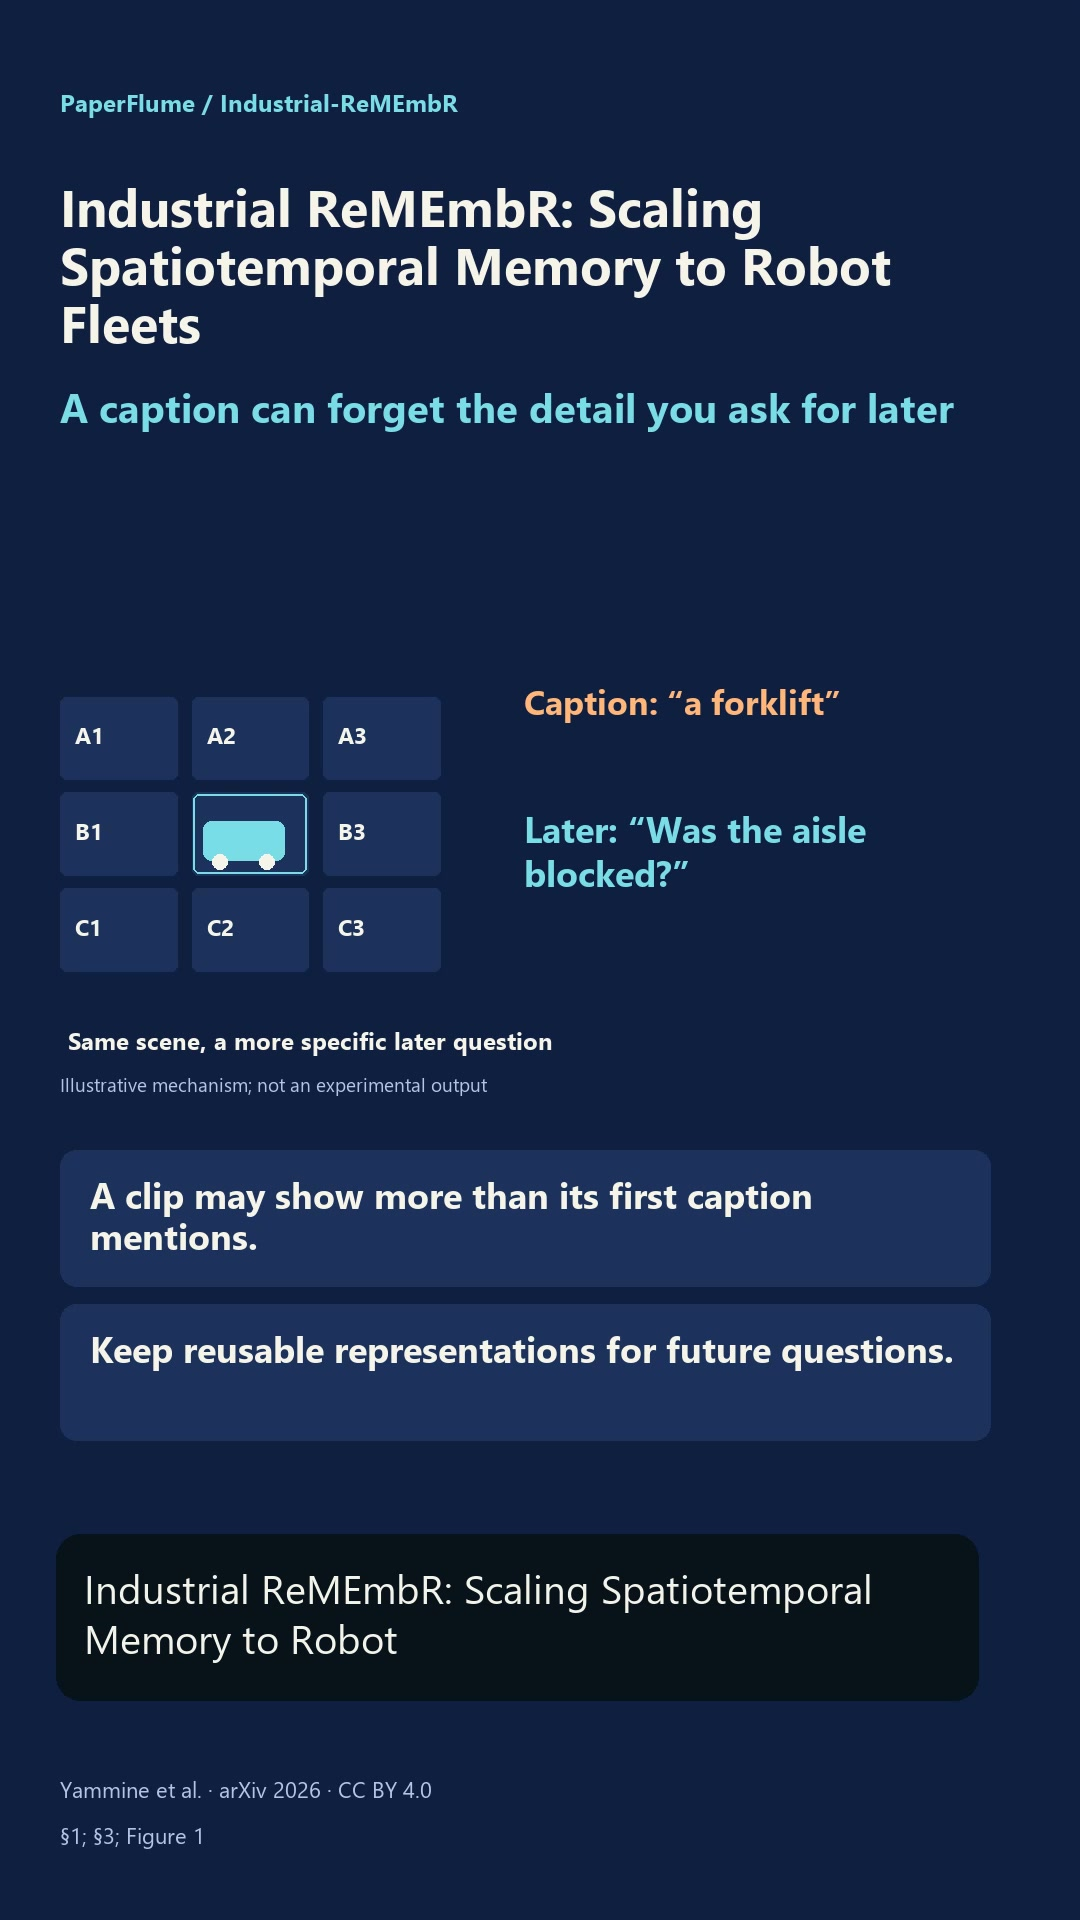 0:51
Industrial ReMEmbR: Scaling Spatiotemporal Memory to Robot Fleets
Video understanding
2610.28624
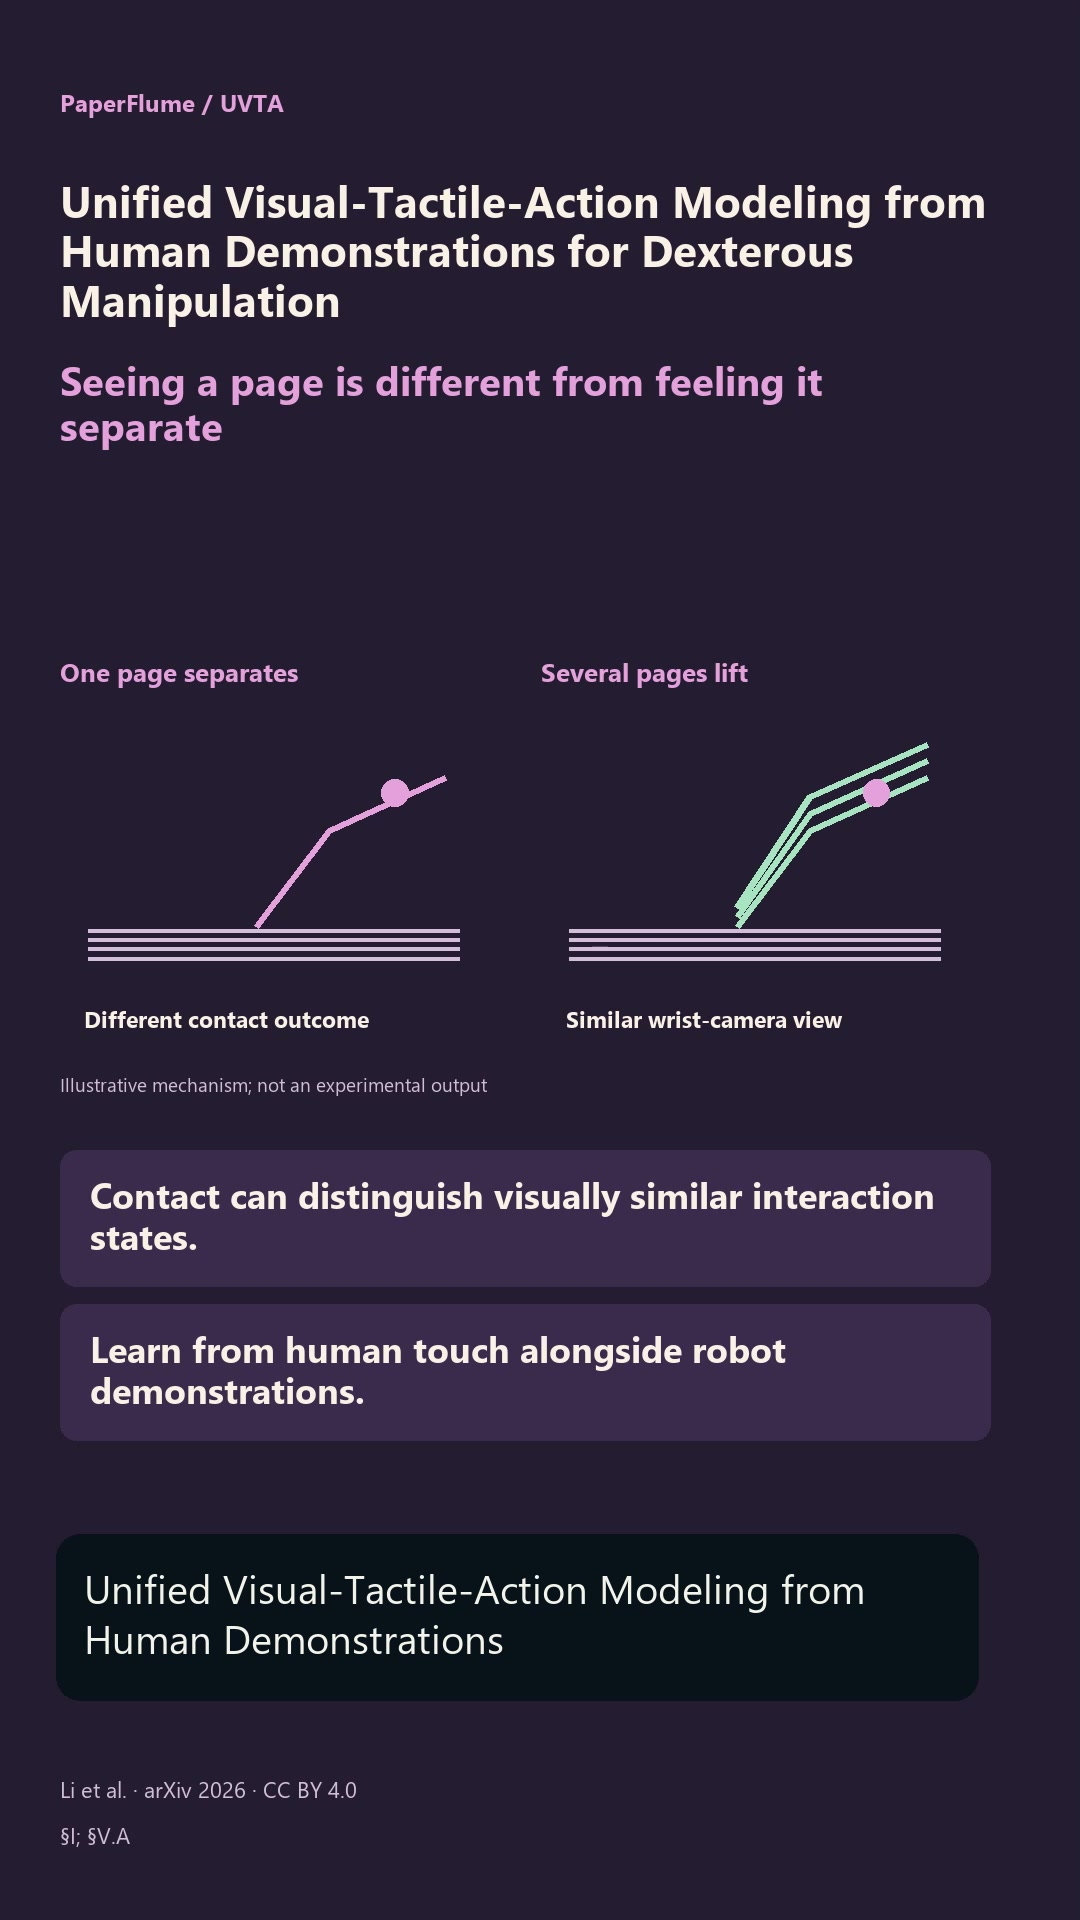 0:48
Unified Visual-Tactile-Action Modeling from Human Demonstrations for Dexterous Manipulation
Dexterous hands
2609.34182
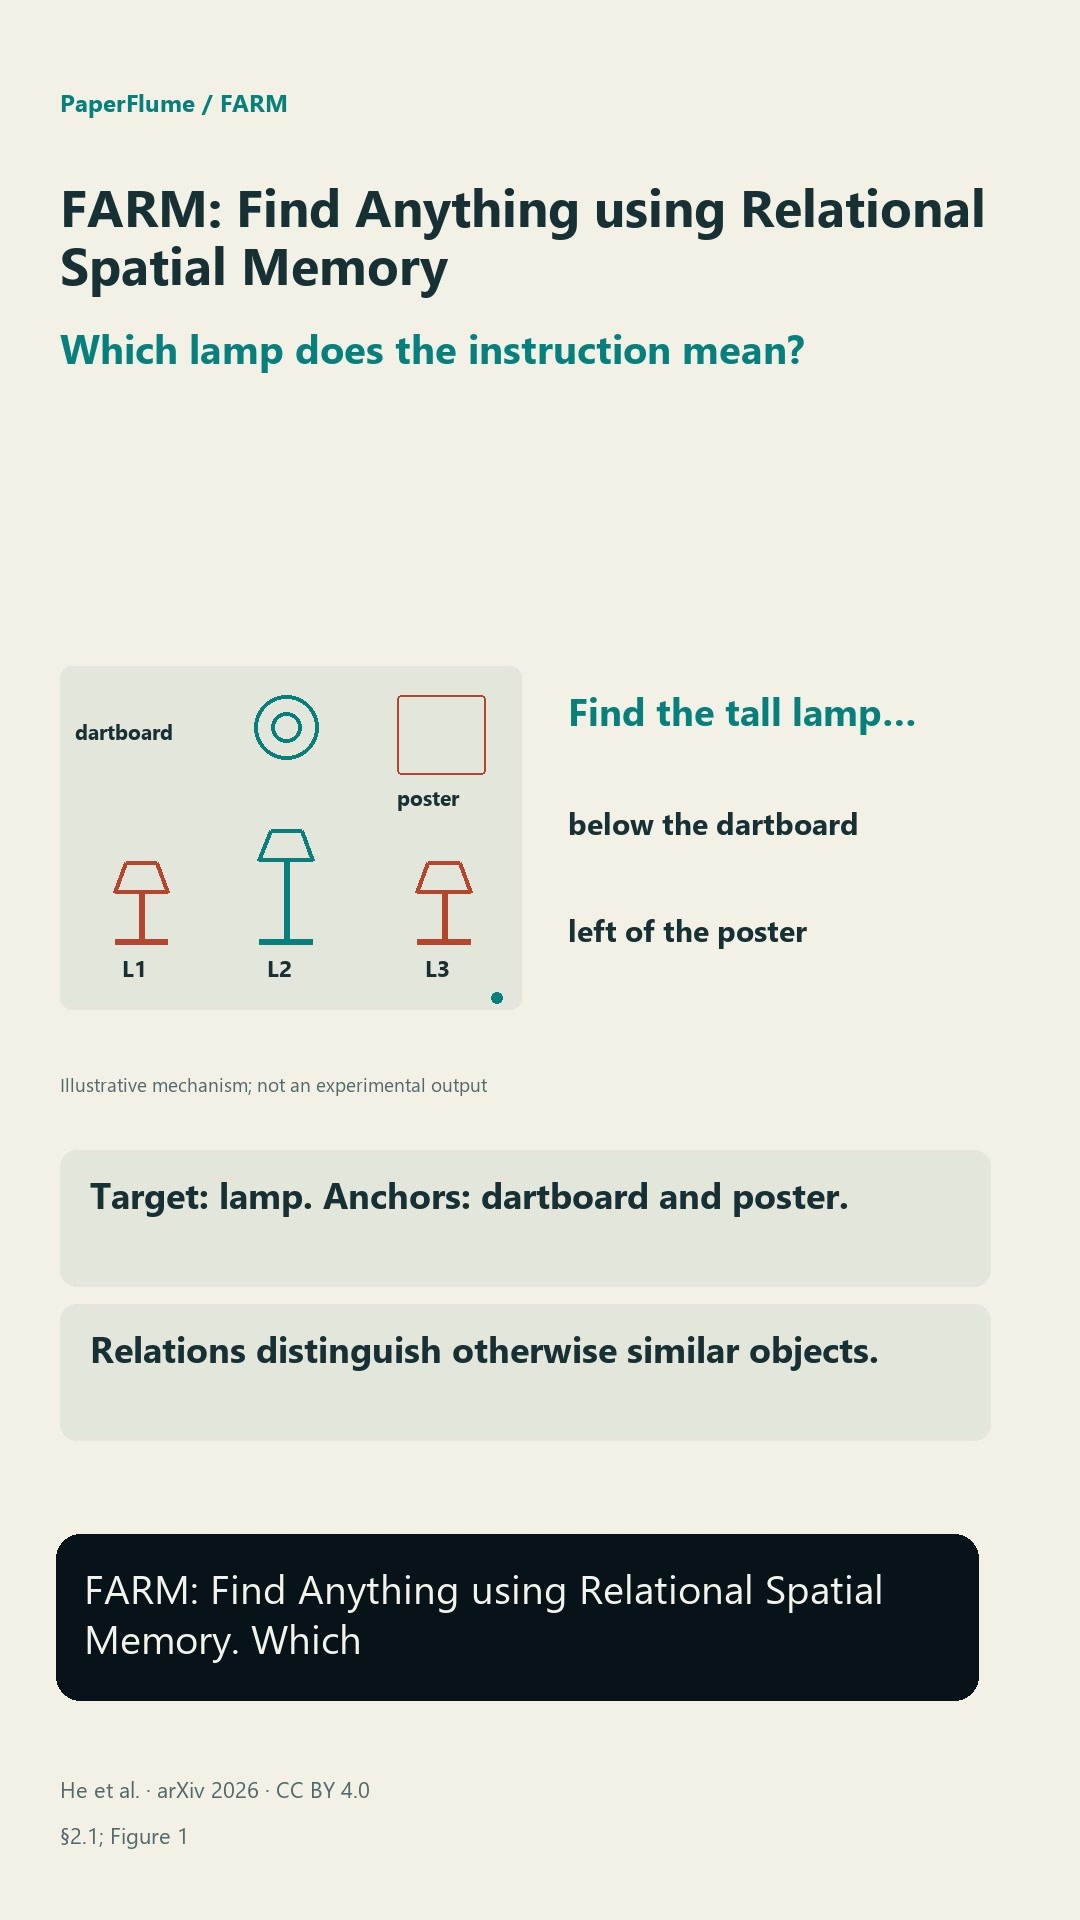 0:52
FARM: Find Anything using Relational Spatial Memory
Open-vocabulary perception
2606.15476
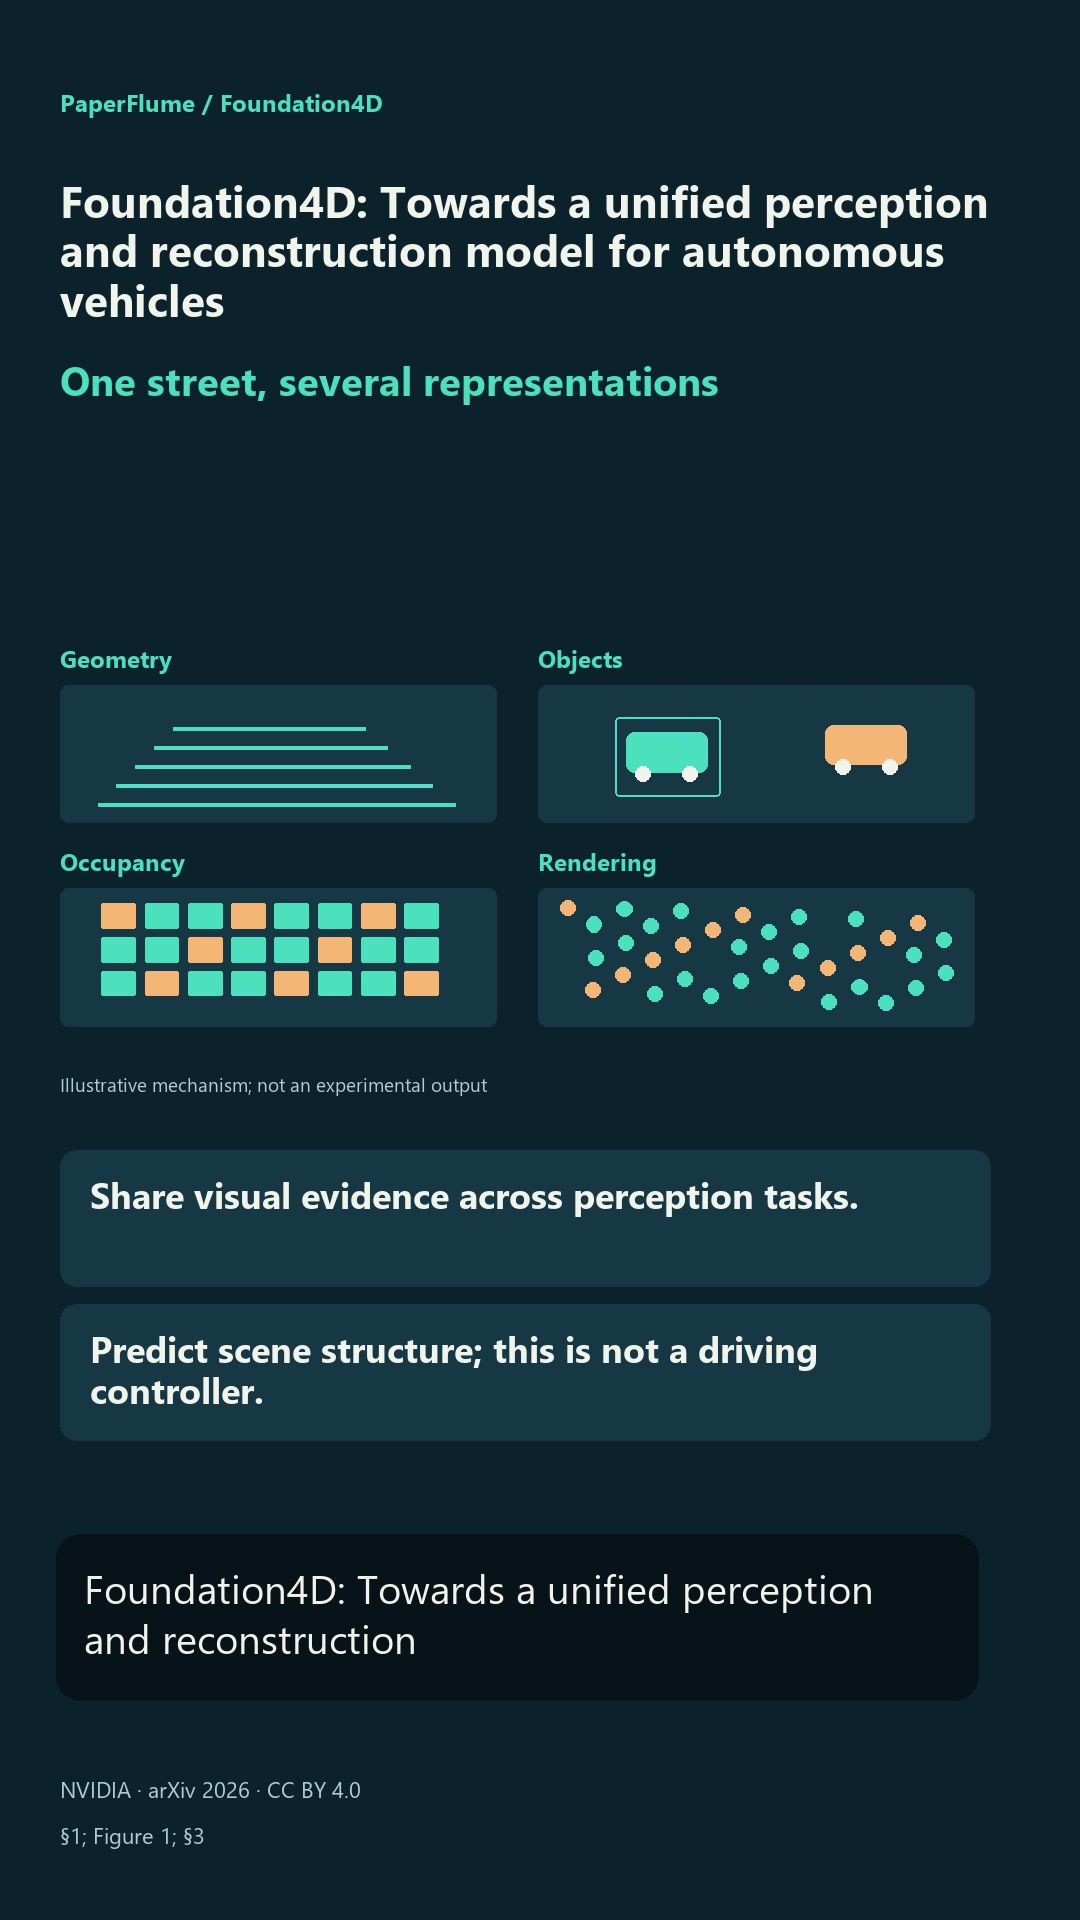 1:01
Foundation4D: Towards a unified perception and reconstruction model for autonomous vehicles
Gaussian splatting
2610.30340
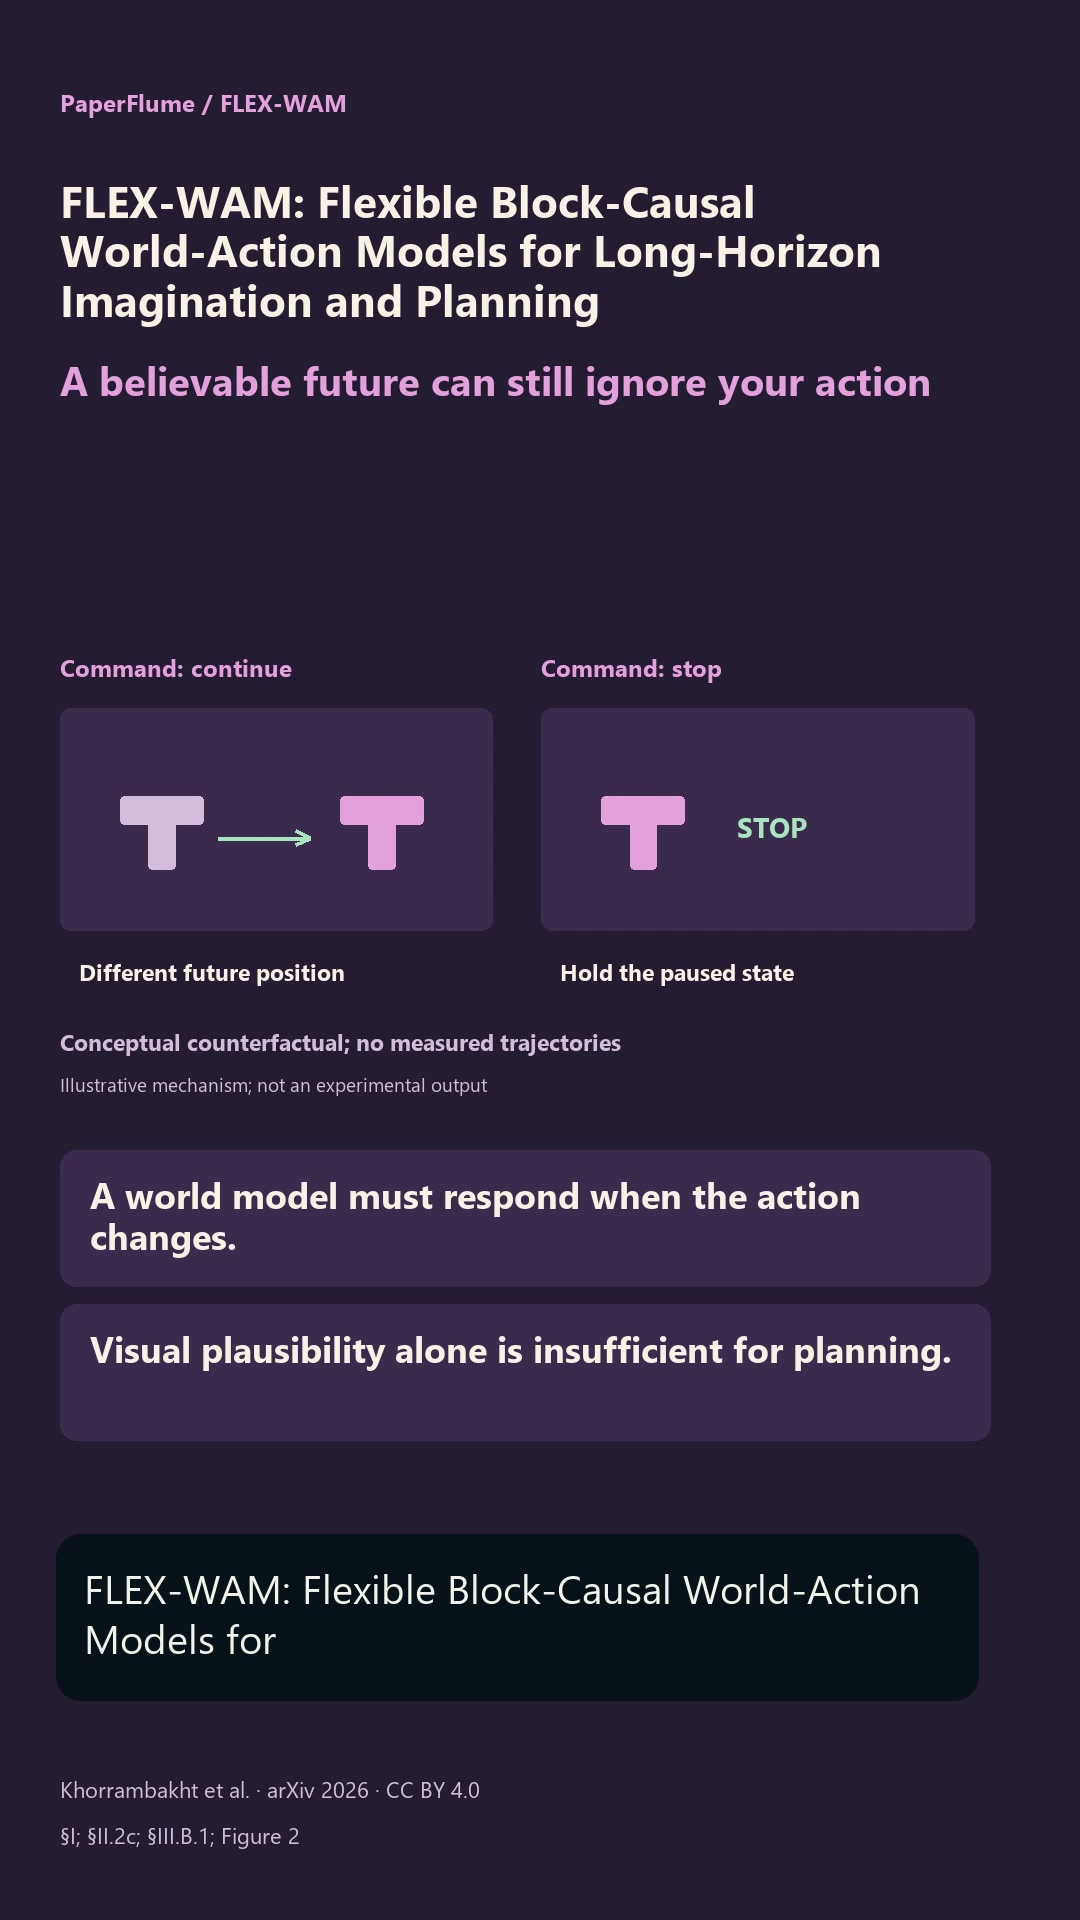 0:53
FLEX-WAM: Flexible Block-Causal World-Action Models for Long-Horizon Imagination and Planning
VLA models
2610.05483
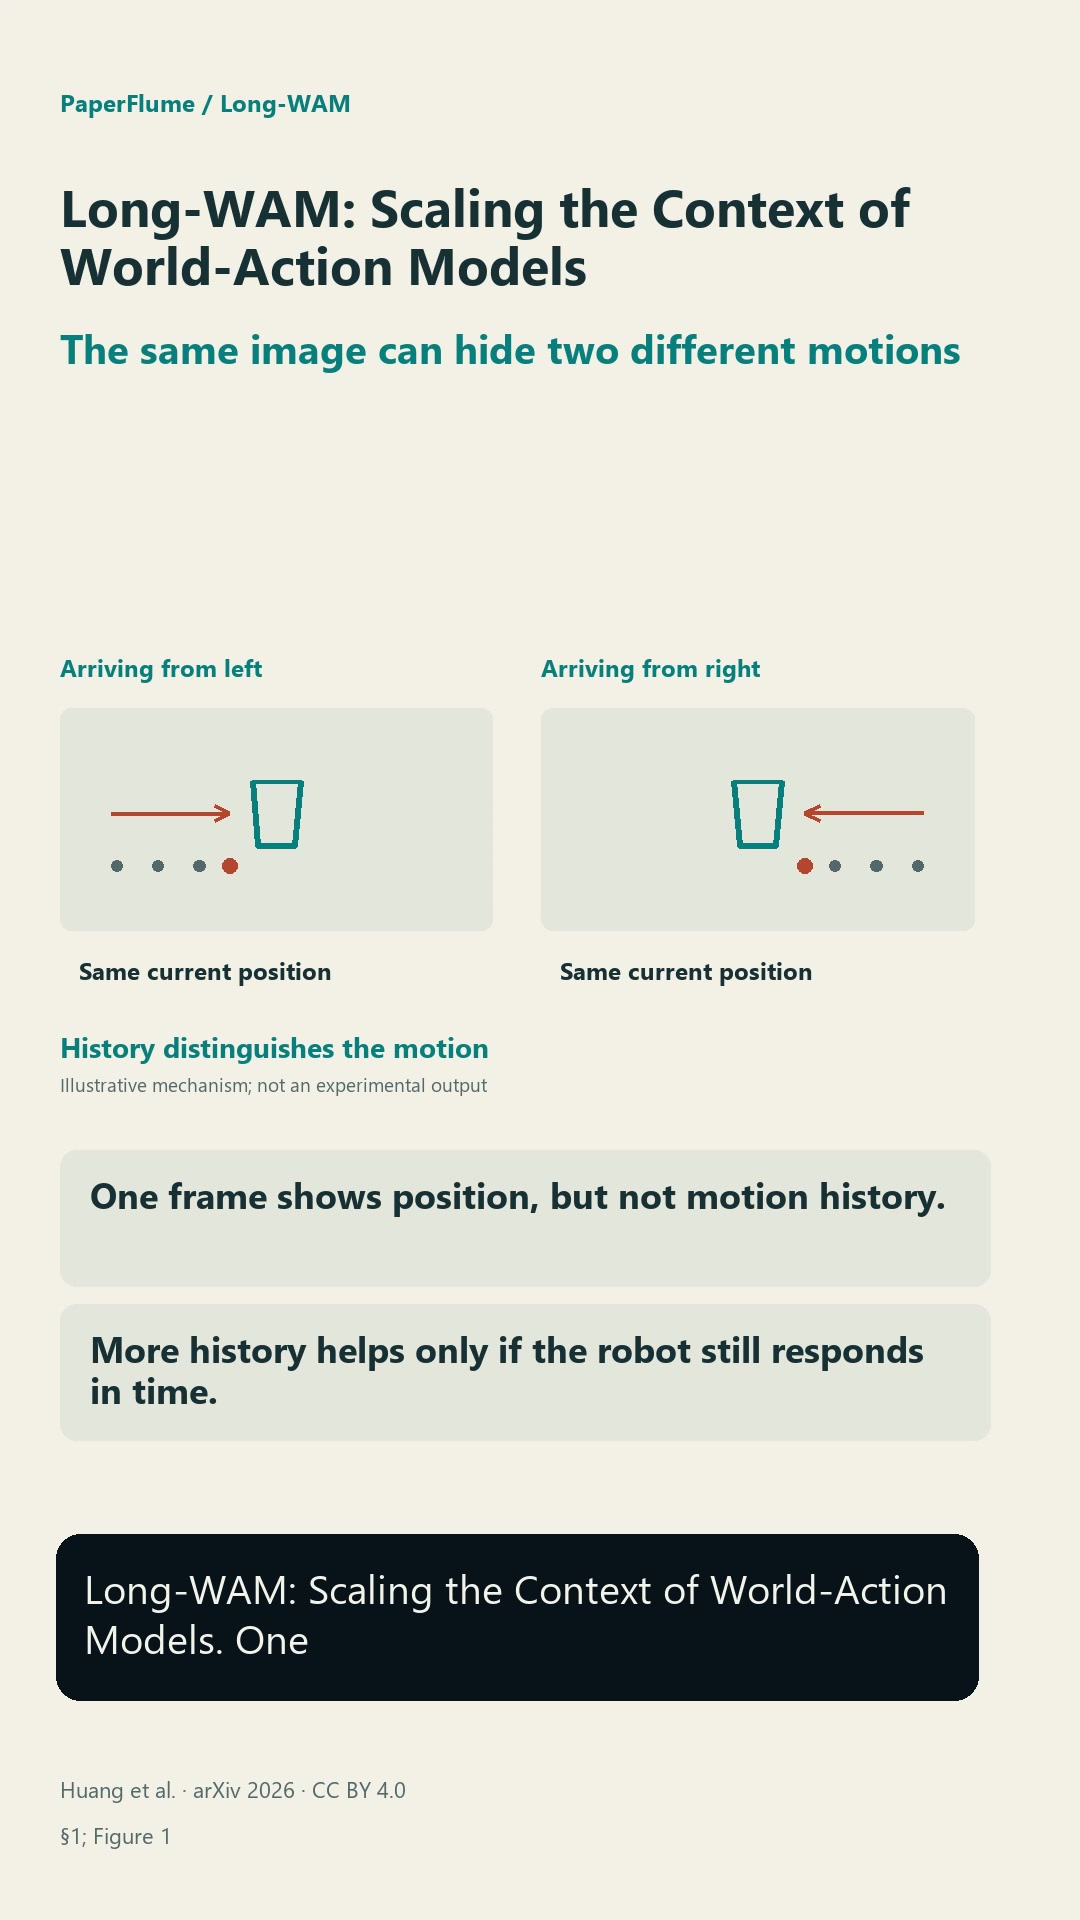 0:52
Long-WAM: Scaling the Context of World-Action Models
VLA models
2610.10528
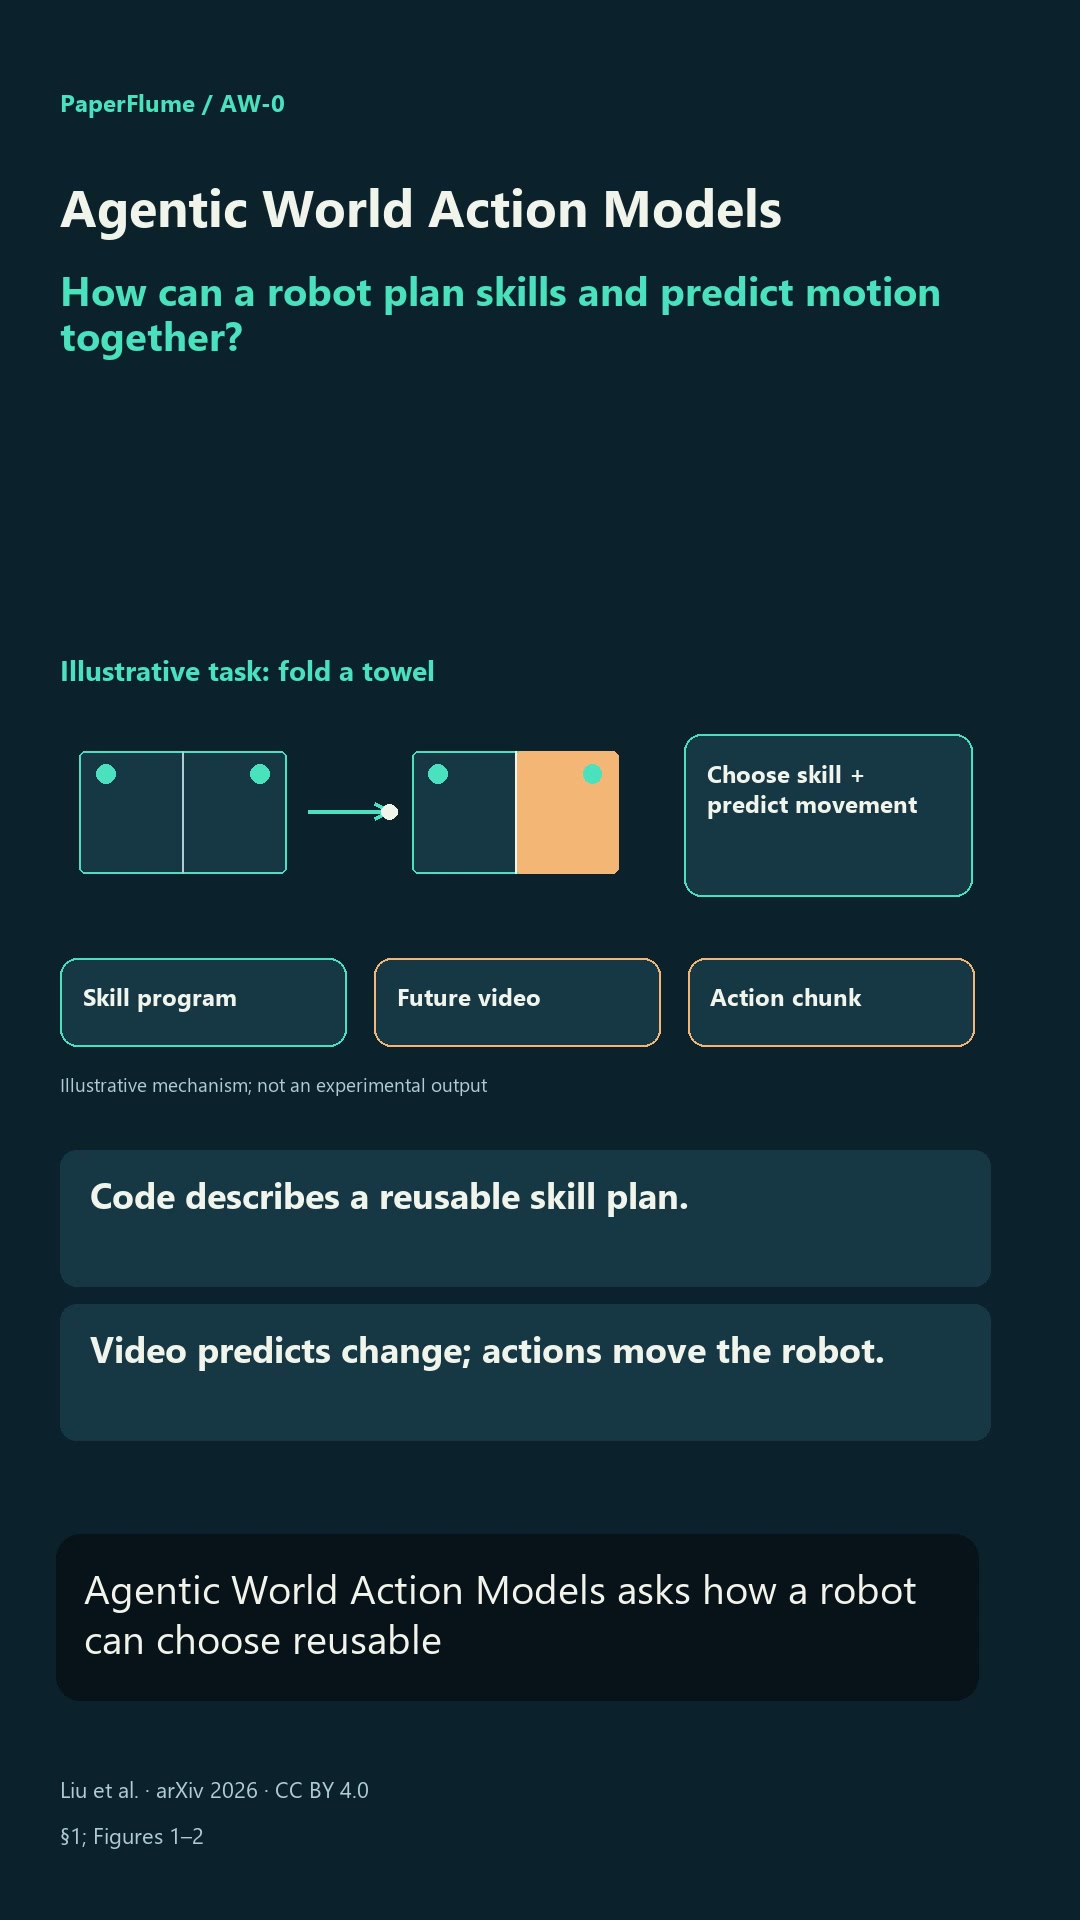 0:51
Agentic World Action Models
VLA models
2610.30136
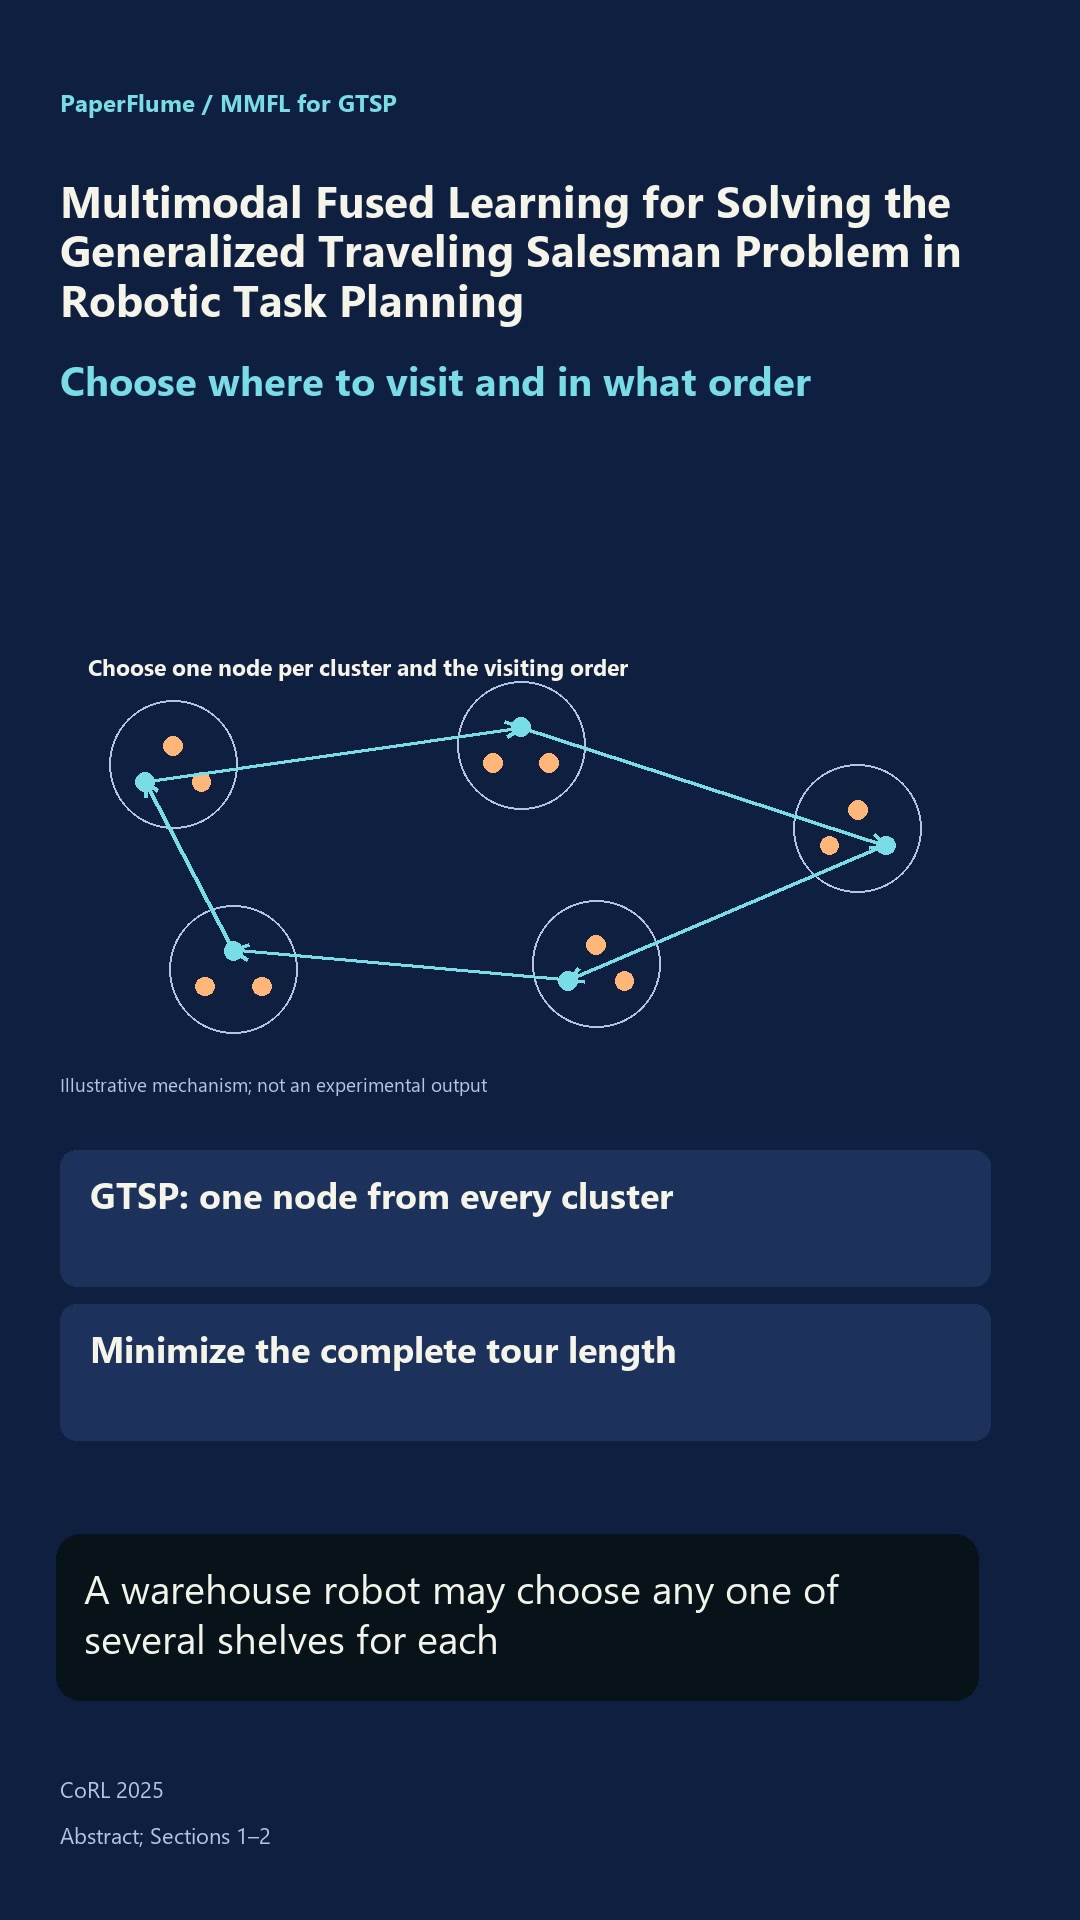 0:55
Multimodal Fused Learning for Solving the Generalized Traveling Salesman Problem in Robotic Task Planning
Task allocation
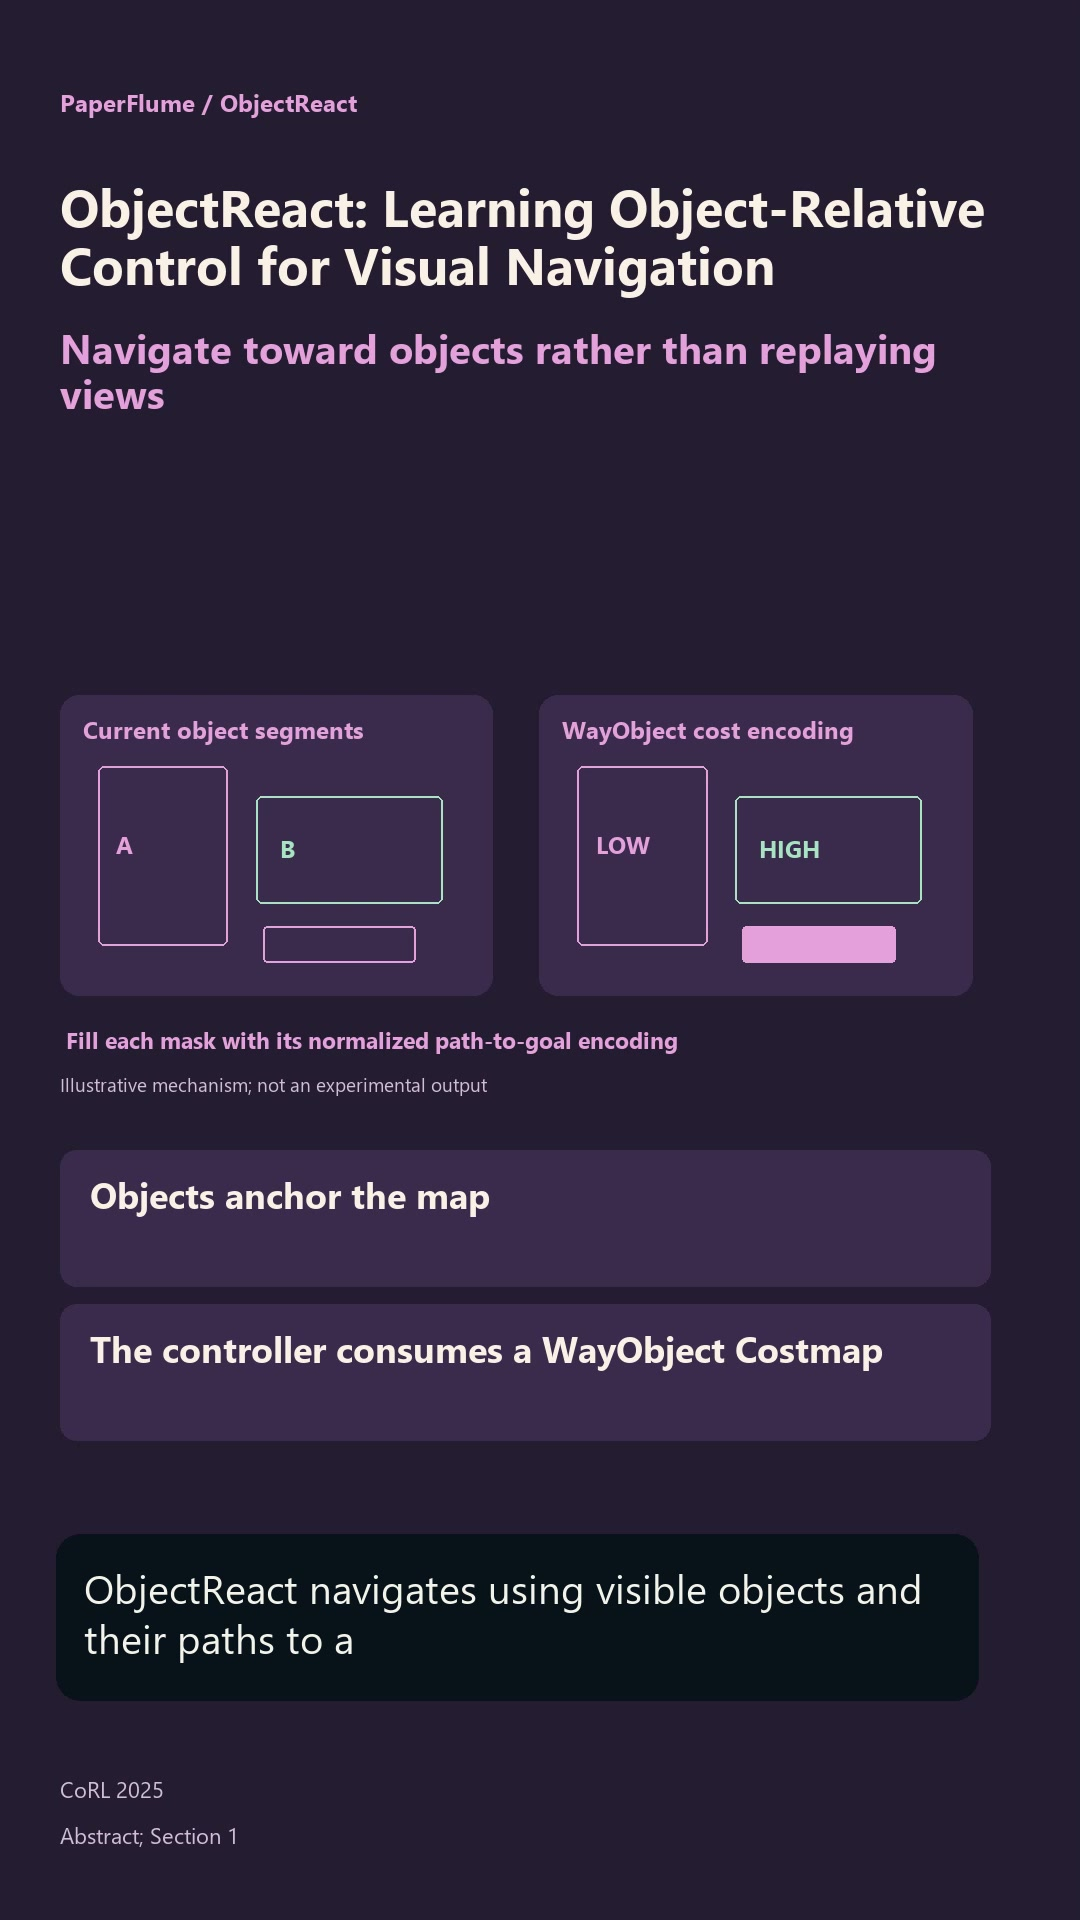 0:50
ObjectReact: Learning Object-Relative Control for Visual Navigation
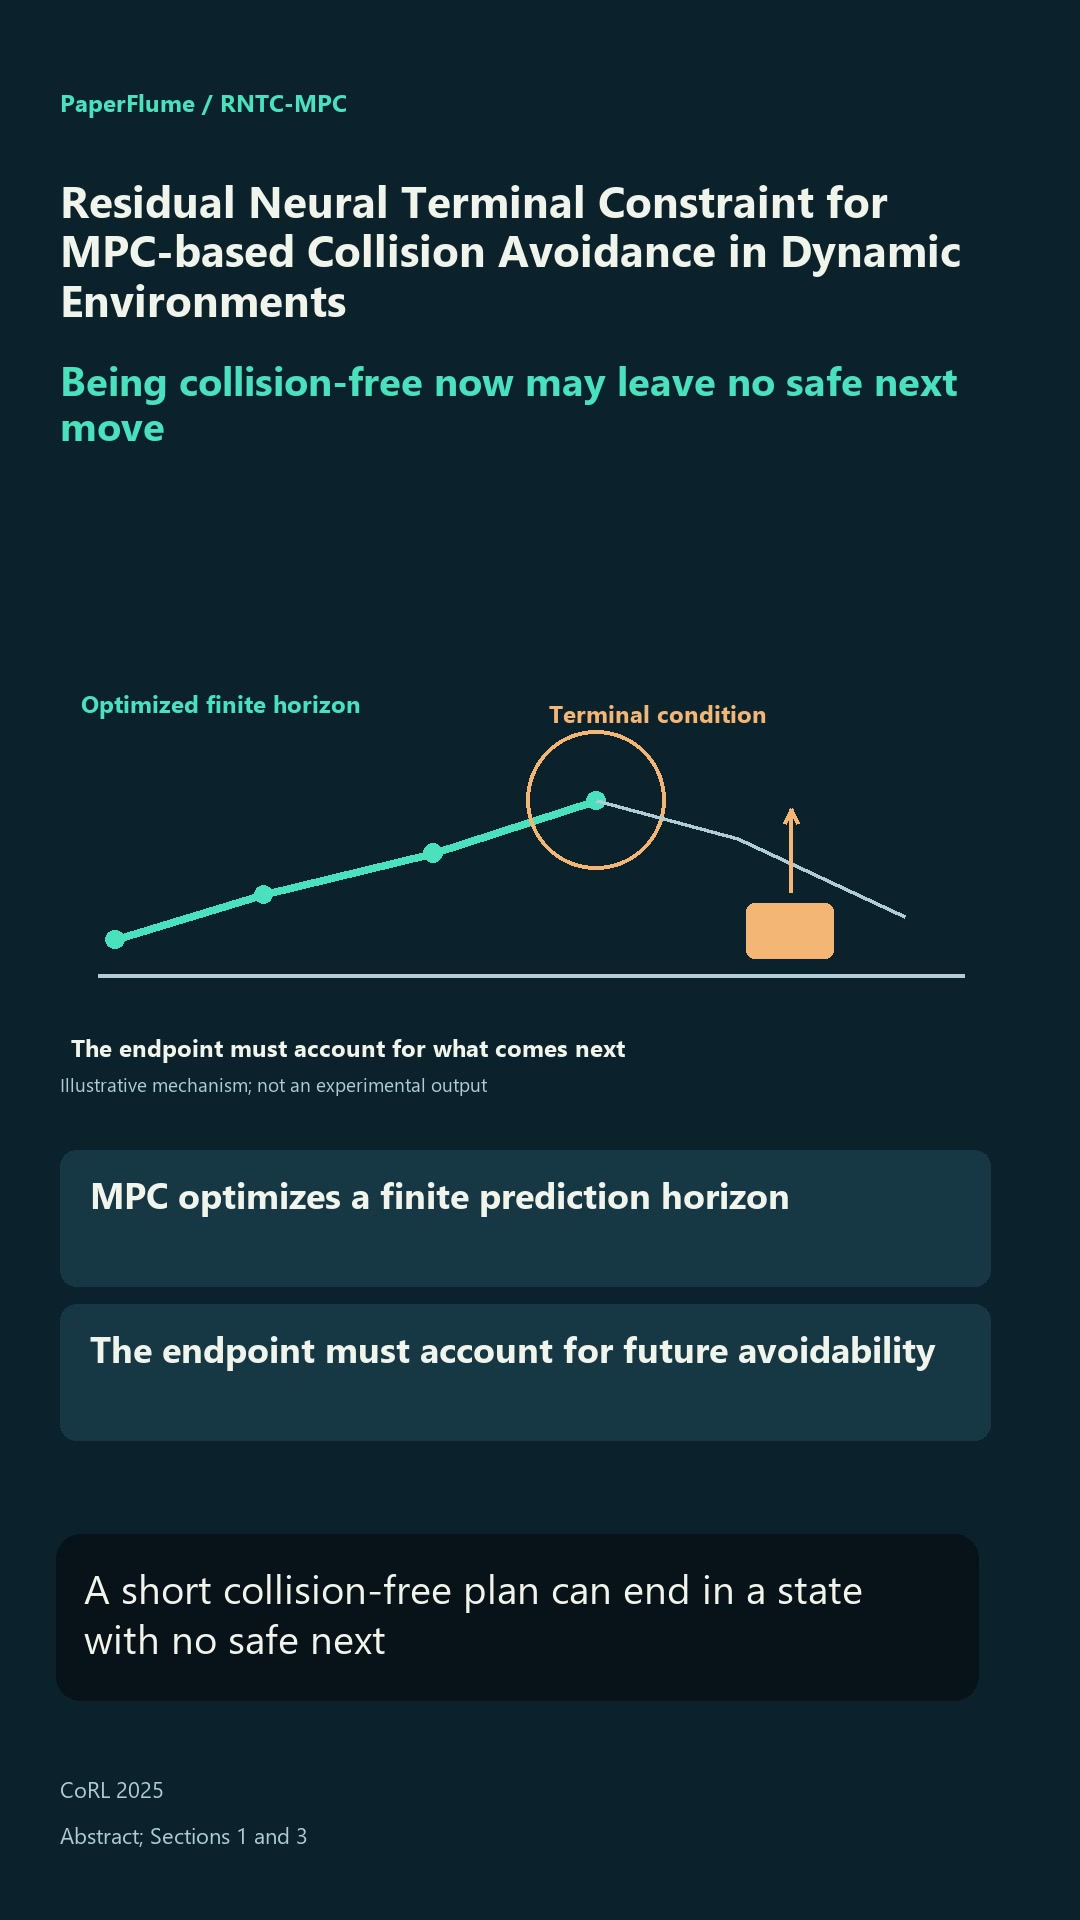 0:48
Residual Neural Terminal Constraint for MPC-based Collision Avoidance in Dynamic Environments
Model predictive control
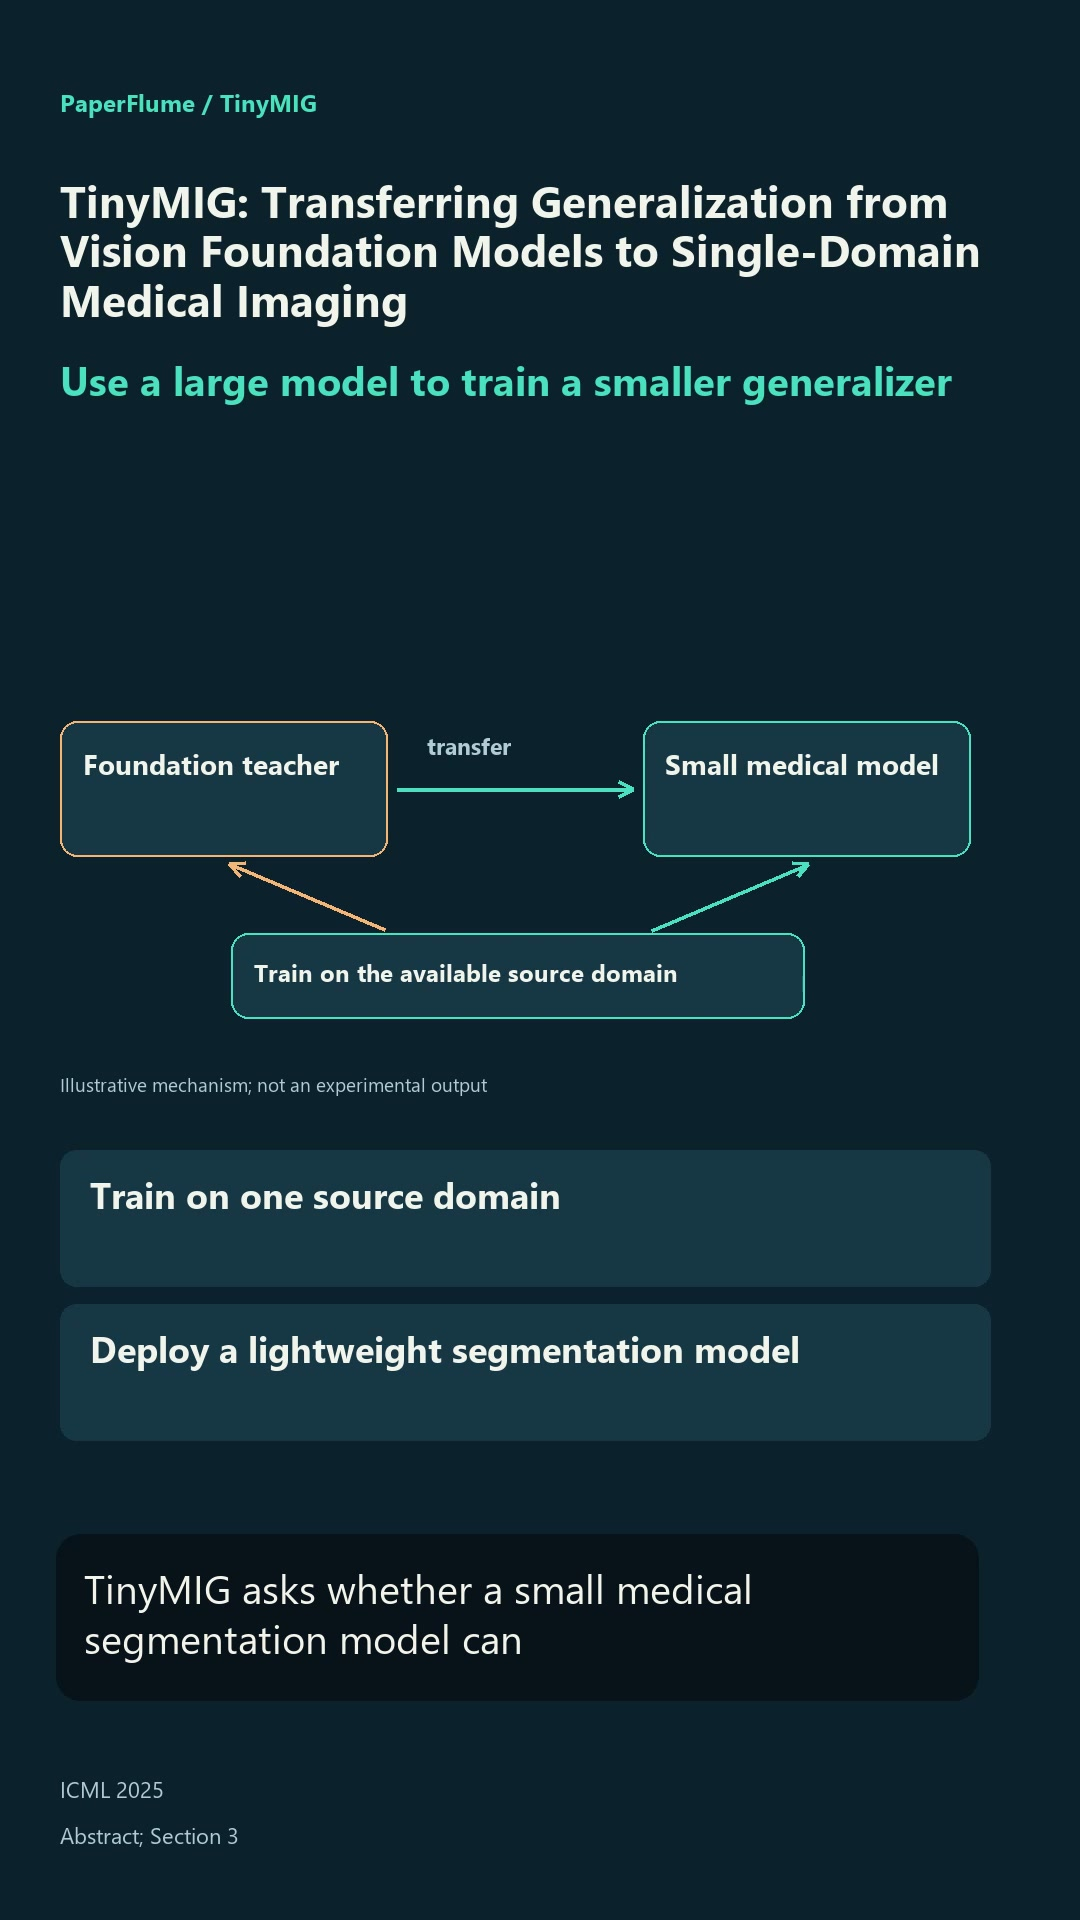 0:53
TinyMIG: Transferring Generalization from Vision Foundation Models to Single-Domain Medical Imaging
 0:55
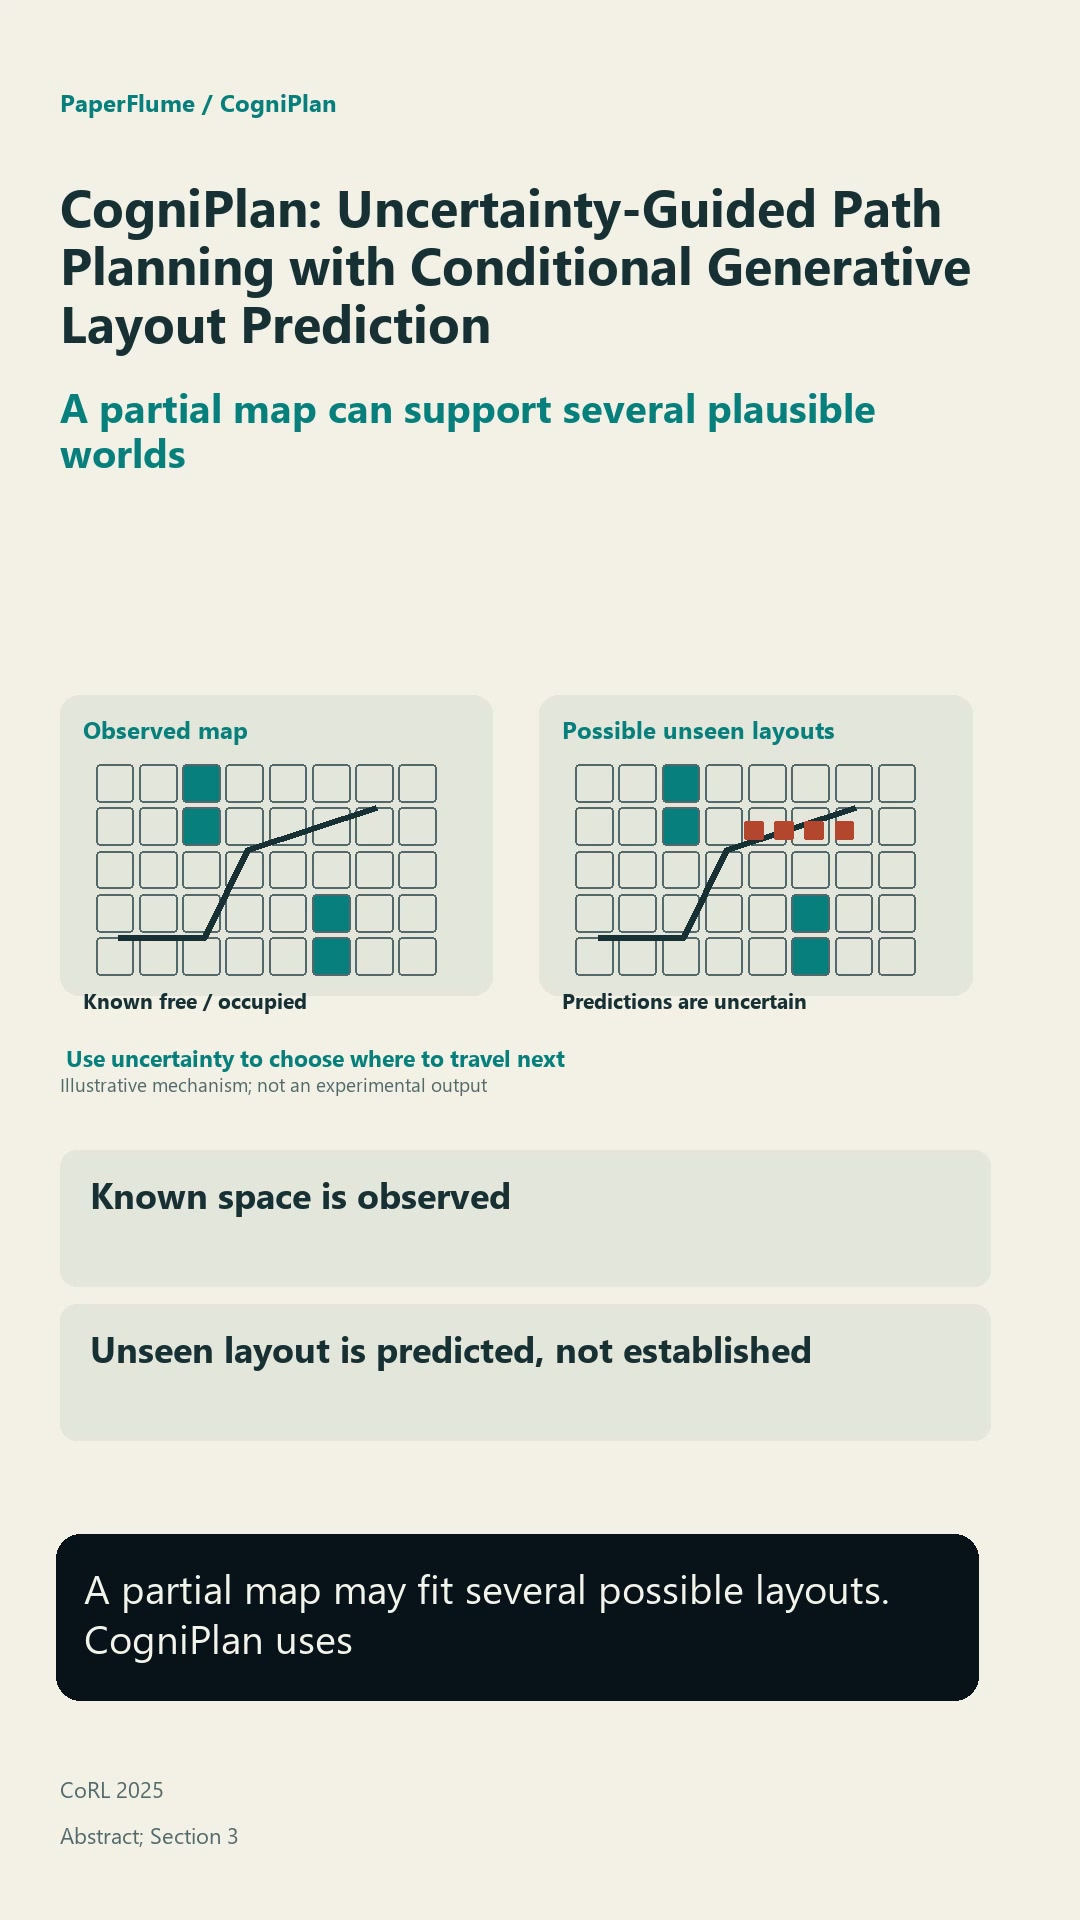
CogniPlan: Uncertainty-Guided Path Planning with Conditional Generative Layout Prediction
Informative path planning
 0:52
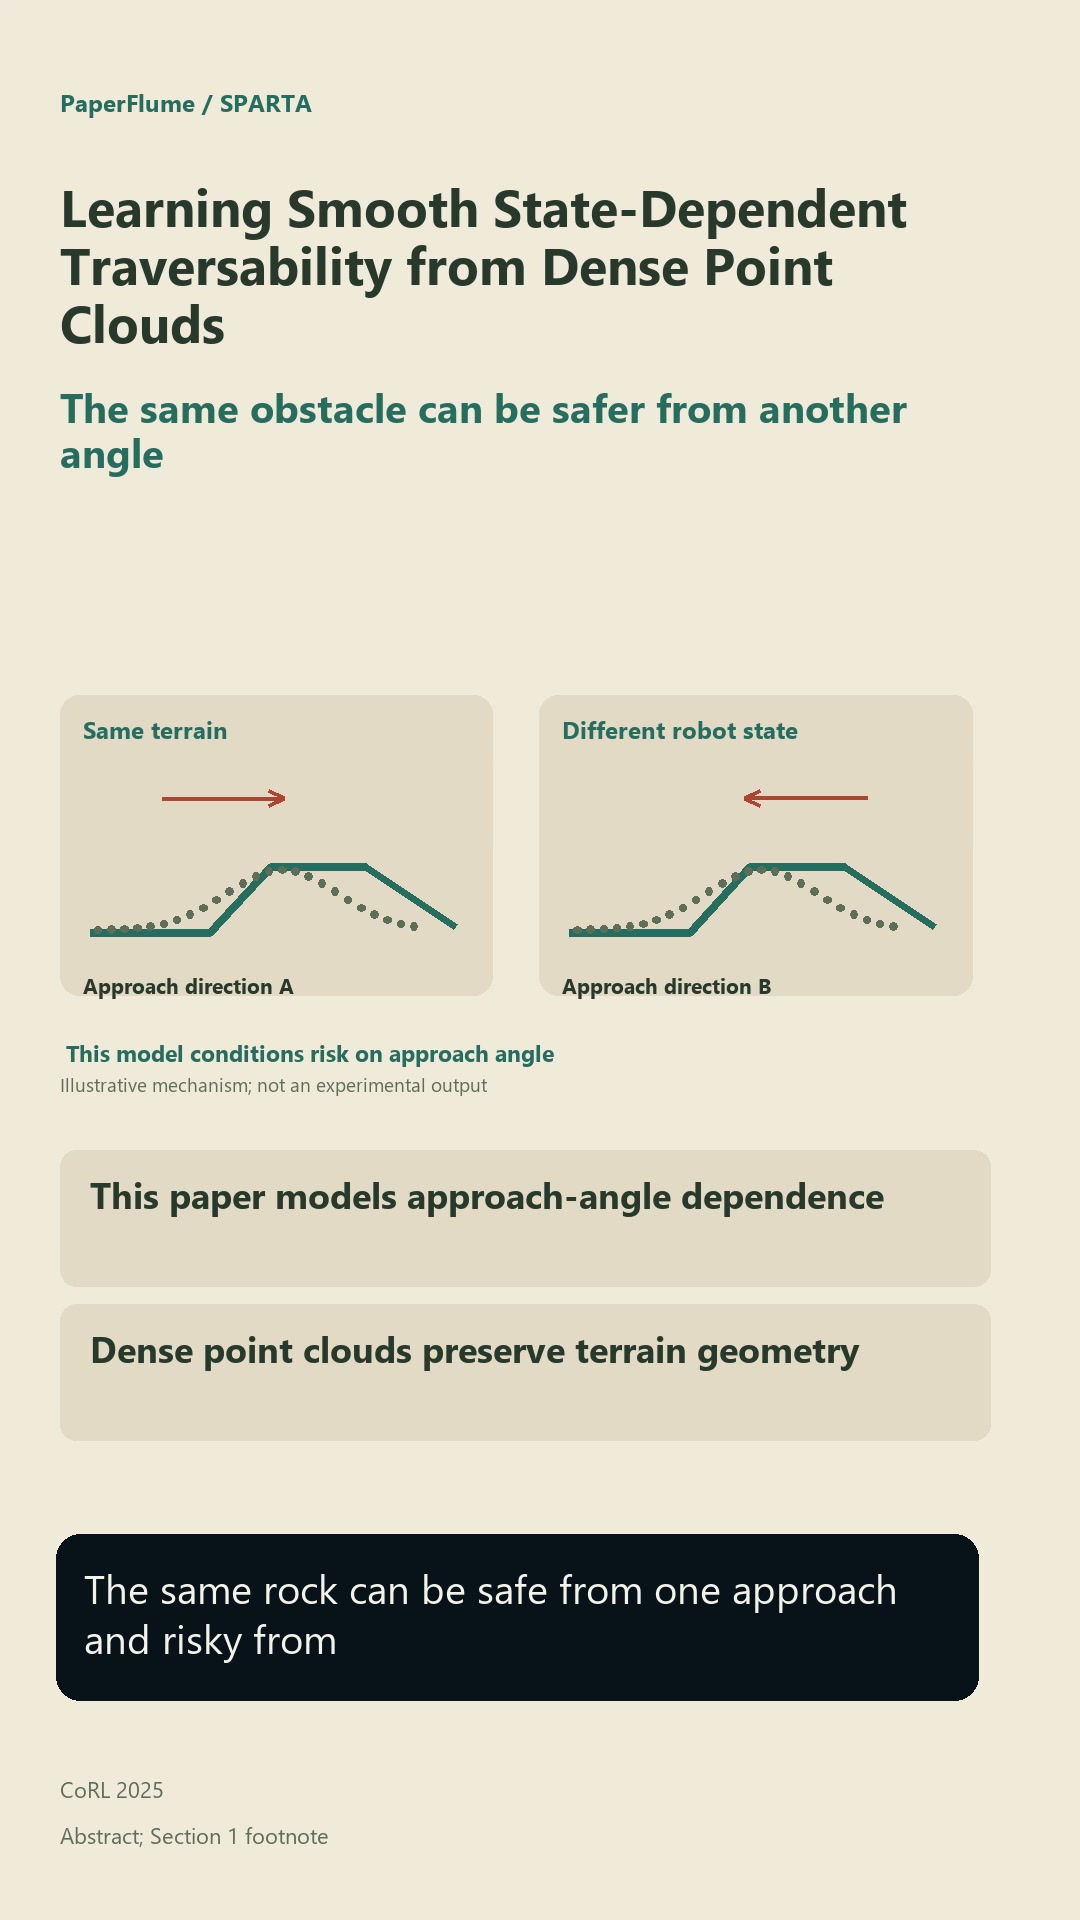
Learning Smooth State-Dependent Traversability from Dense Point Clouds
Point cloud understanding
 0:56
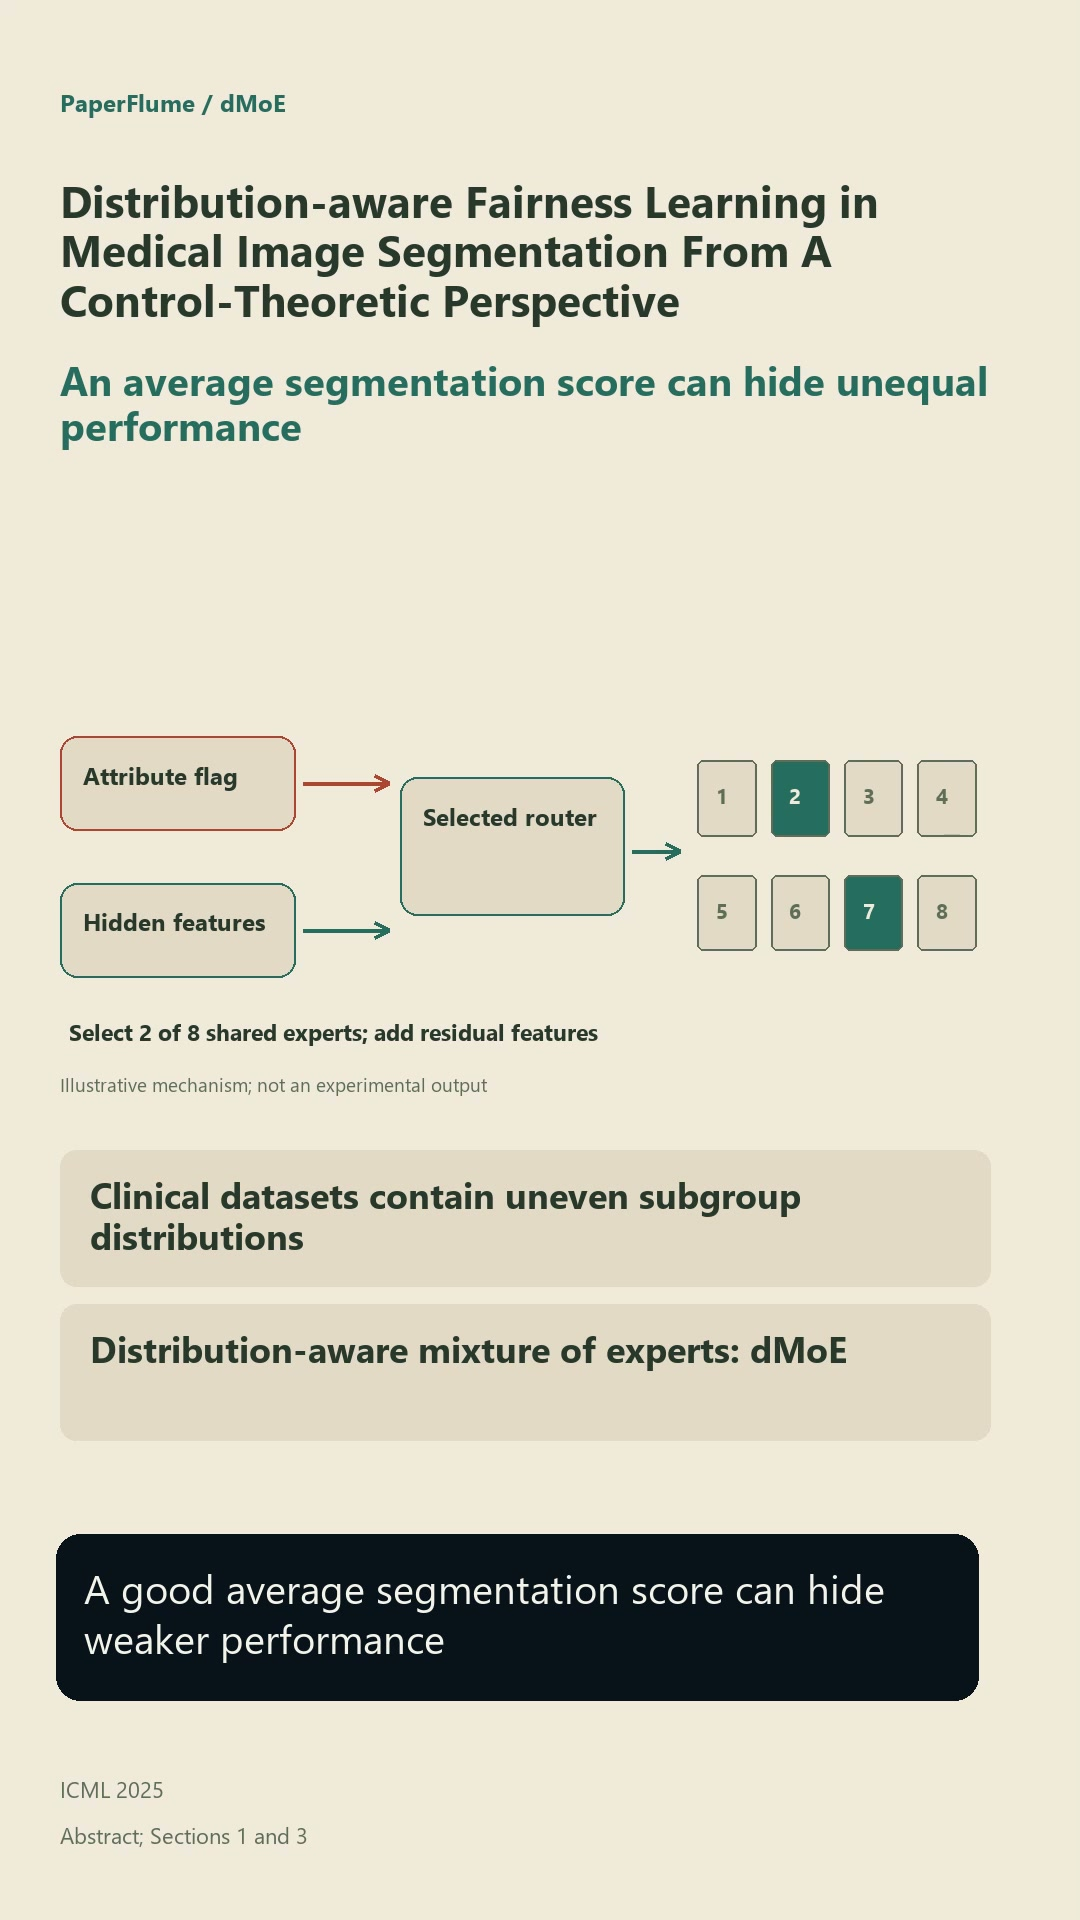
Distribution-aware Fairness Learning in Medical Image Segmentation From A Control-Theoretic Perspective
Medical image segmentation
 0:51
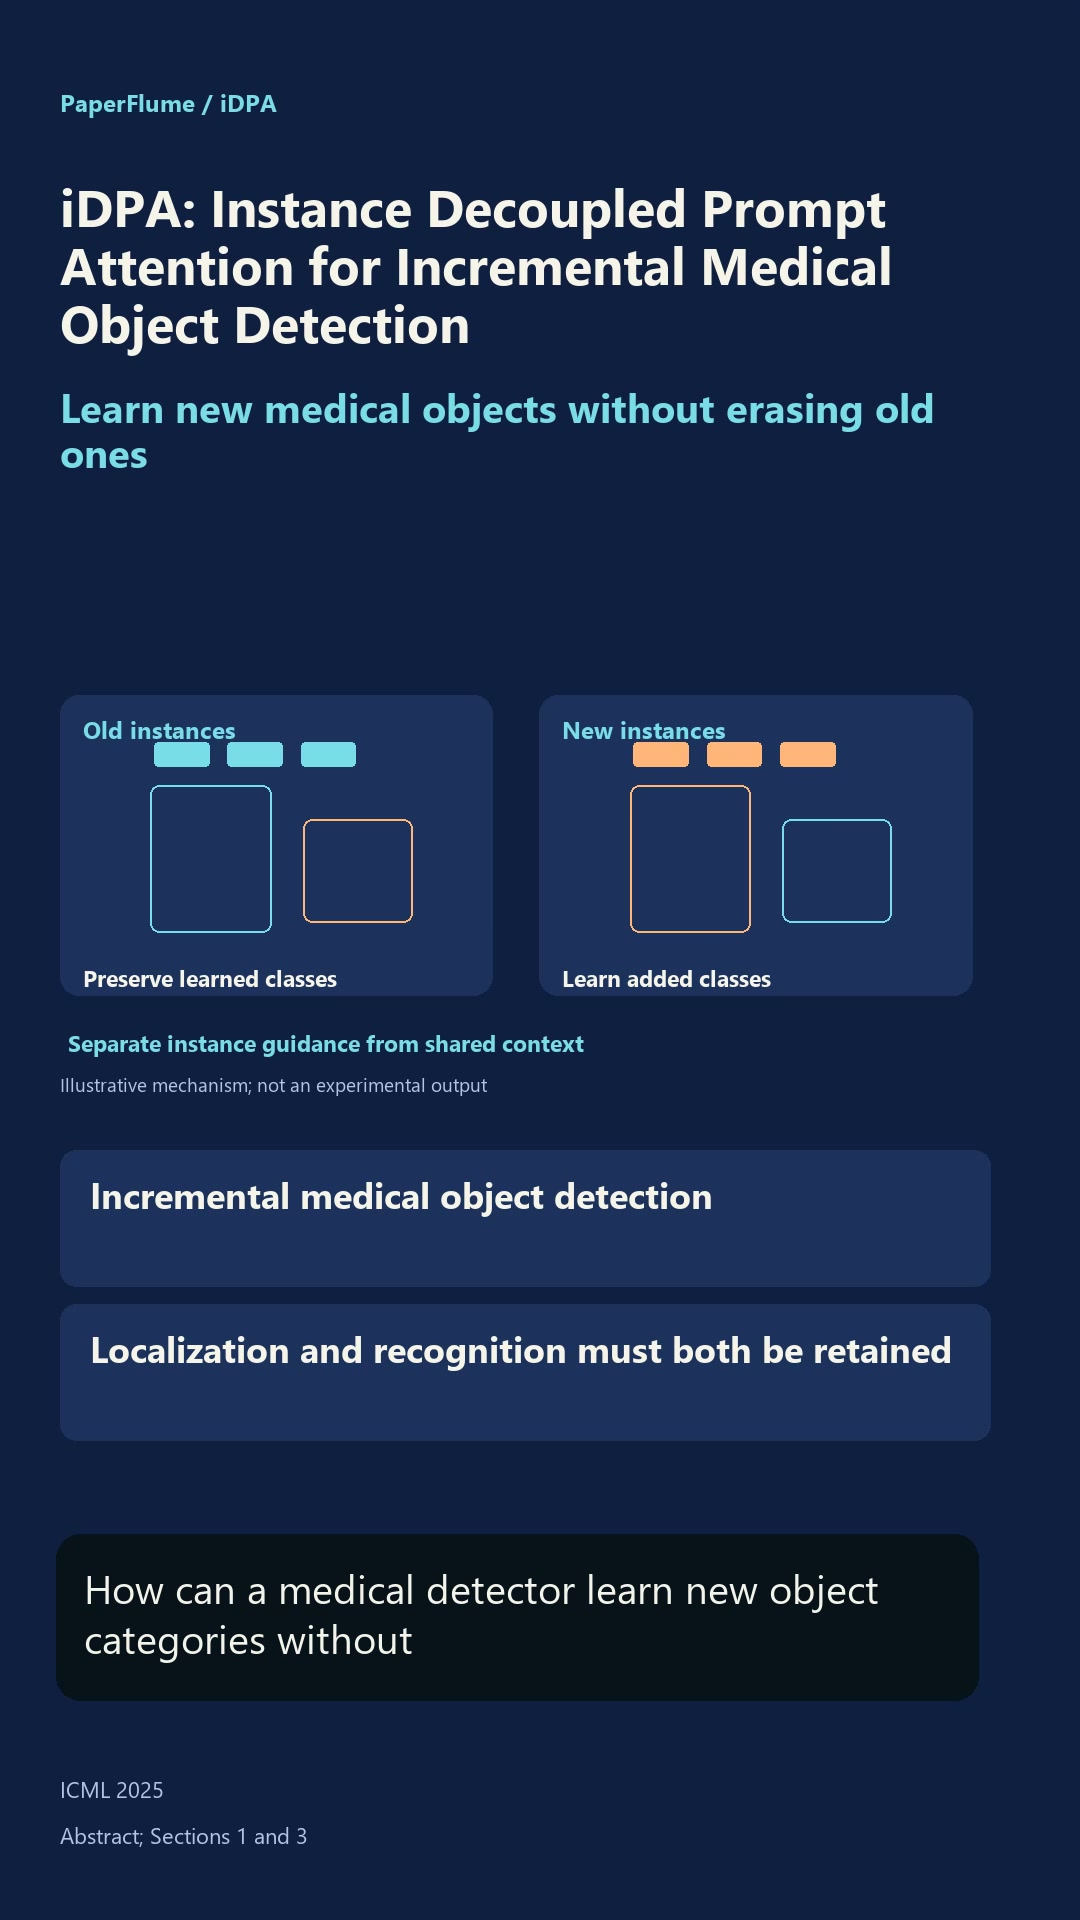
iDPA: Instance Decoupled Prompt Attention for Incremental Medical Object Detection
Continual learning
 0:59
L-Diffusion: Laplace Diffusion for Efficient Pathology Image Segmentation
Diffusion models
 0:51
Learning Long-Horizon Robot Manipulation Skills via Privileged Action
 0:51
SPIN: distilling Skill-RRT for long-horizon prehensile and non-prehensile manipulation
Multi-robot systems
See all 7 →
6:10
Industrial ReMEmbR: Scaling Spatiotemporal Memory to Robot Fleets
Video understanding · deck
2610.28624
5:39
Multimodal Fused Learning for Solving the Generalized Traveling Salesman Problem in Robotic Task Planning
Task allocation · deck
 7:19
AT-Drone: Benchmarking Adaptive Teaming in Multi-Drone Pursuit
Collaboration · deck
 5:39
ReCoDe: Reinforcement Learning-based Dynamic Constraint Design for Multi-Agent Coordination
Distributed control · deck
 5:48
Robot Trains Robot: Automatic Real-World Policy Adaptation and Learning for Humanoids
Collaboration · deck
 7:55
CASH: Capability-Aware Shared Hypernetworks for Flexible Heterogeneous Multi-Robot Coordination
Collaboration · deck
 7:26
Latent Theory of Mind: A Decentralized Diffusion Architecture for Cooperative Manipulation
Collaboration · deck
Multimodal perception
See all 8 → 5:39
Task-Gated Multi-Expert Collaboration Network for Degraded Multi-Modal Image Fusion
Multimodal fusion · deck
 4:20
Tactile Beyond Pixels: Multisensory Touch Representations for Robot Manipulation
Multimodal fusion · deck
3:50
The Sound of Simulation: Learning Multimodal Sim-to-Real Robot Policies with Generative Audio
Sim-to-real transfer · deck
 4:11
Cross-Sensor Touch Generation
Multimodal fusion · deck
 4:21
SAVOR: Skill Affordance Learning from Visuo-Haptic Perception for Robot-Assisted Bite Acquisition
Multimodal fusion · deck
7:19
MoDA: Modulation Adapter for Fine-Grained Visual Understanding in Instructional MLLMs
Multimodal fusion · deck
7:39
Cross-Modal Semantic Decoupling and Transfer for Text-to-Visible-Infrared Person Re-Identification
Multimodal fusion · deck
8:29
LightAVSeg: Lightweight Audio-Visual Segmentation
Segmentation · deck
Uncertainty quantification
See all 8 →
9:35
FFHFlow: Diverse and Uncertainty-Aware Dexterous Grasp Generation via Flow Variational Inference
Grasping · deck
 7:23
Scalable Data-Driven Reachability Analysis and Control via Koopman Operators with Conformal Coverage Guarantees
Safe control and safety filters · deck
 6:18
Temporal Difference Calibration in Sequential Tasks: Application to Vision-Language-Action Models
VLA models · deck
 6:42
Safety Beyond the Training Data: Robust Out-of-Distribution MPC via Conformalized System Level Synthesis
Model predictive control · deck
 7:57
Safe Control using Learned Safety Filters and Adaptive Conformal Inference
Safe control and safety filters · deck
7:58
When Environments Shift: Safe Planning with Generative Priors and Robust Conformal Prediction
Model predictive control · deck
 6:06
Safe Planning in Interactive Environments via Iterative Policy Updates and Adversarially Robust Conformal Prediction
Trajectory optimisation · deck
 7:19
Time-aware Motion Planning in Dynamic Environments with Conformal Prediction
Safe control and safety filters · deck
Medical imaging
See all 7 →
5:01
TinyMIG: Transferring Generalization from Vision Foundation Models to Single-Domain Medical Imaging
· deck
5:38
Distribution-aware Fairness Learning in Medical Image Segmentation From A Control-Theoretic Perspective
Medical image segmentation · deck
4:39
iDPA: Instance Decoupled Prompt Attention for Incremental Medical Object Detection
Continual learning · deck
5:42
L-Diffusion: Laplace Diffusion for Efficient Pathology Image Segmentation
Diffusion models · deck
7:03
Refining Context-Entangled Content Segmentation via Curriculum Selection and Anti-Curriculum Promotion
Segmentation · deck
 6:45
MEDSIGHT: Towards Grounded Visual Comprehension in Medical Large Vision-Language Models
Segmentation · deck
7:01
MedCRP-CL: Continual Medical Image Segmentation via Bayesian Nonparametric Semantic Modality Discovery
Segmentation · deck
Navigation
See all 7 →
5:46
ObjectReact: Learning Object-Relative Control for Visual Navigation
· deck
5:24
CogniPlan: Uncertainty-Guided Path Planning with Conditional Generative Layout Prediction
Informative path planning · deck
5:28
Learning Smooth State-Dependent Traversability from Dense Point Clouds
Point cloud understanding · deck
 6:34
Omni-Perception: Omnidirectional Collision Avoidance for Legged Locomotion in Dynamic Environments
· deck
5:44
Trajectory-Level Experimental Design for Fast Safety Parameter Estimation of Unknown Environments by Autonomous Systems
Safe control and safety filters · deck
 6:19
AdaNav: Adaptive Reasoning with Uncertainty for Vision-Language Navigation
Vision-language navigation · deck
 6:39
Provably Safe Stein Variational Clarity-Aware Informative Planning
Trajectory optimisation · deck
Aerial and space robotics
See all 4 →
6:39
Provably Safe Stein Variational Clarity-Aware Informative Planning
Trajectory optimisation · deck
 7:41
Learned Incremental Nonlinear Dynamic Inversion for Quadrotors with and without Slung Payloads
UAV systems · deck
7:19
AT-Drone: Benchmarking Adaptive Teaming in Multi-Drone Pursuit
Collaboration · deck
 4:40
Learning Robust Policies for Generalized Debris Capture with an Automated Tether-Net System
RL for control
2201.04180
Retrieval and grounding
See all 5 →
6:10
Industrial ReMEmbR: Scaling Spatiotemporal Memory to Robot Fleets
Video understanding · deck
2610.28624
6:42
FARM: Find Anything using Relational Spatial Memory
Open-vocabulary perception · deck
2606.15476
5:51
Data Retrieval with Importance Weights for Few-Shot Imitation Learning
Learning from demonstration · deck
6:23
When RAG Hurts: Diagnosing and Mitigating Attention Distraction in Retrieval-Augmented LVLMs
Multimodal LLMs · deck
7:09
VideoTrace-R1: Long Video-based Retrieval-Augmented Generation via Reinforcement Learning
Video understanding · deck