Next
Papers near this one.
Walkthroughs
 5:47
Unified Visual-Tactile-Action Modeling from Human Demonstrations for Dexterous Manipulation
2609.34182
shares Dexterous hands
 6:50
DexUMI: Using Human Hand as the Universal Manipulation Interface for Dexterous Manipulation
shares Dexterous hands 6:17
HoMMI: Learning Whole-Body Mobile Manipulation from Human Demonstrations
2603.03243
shares Mobile manipulation
Short cuts
 0:48
Unified Visual-Tactile-Action Modeling from Human Demonstrations for Dexterous Manipulation
2609.34182
shares Dexterous hands
 0:52
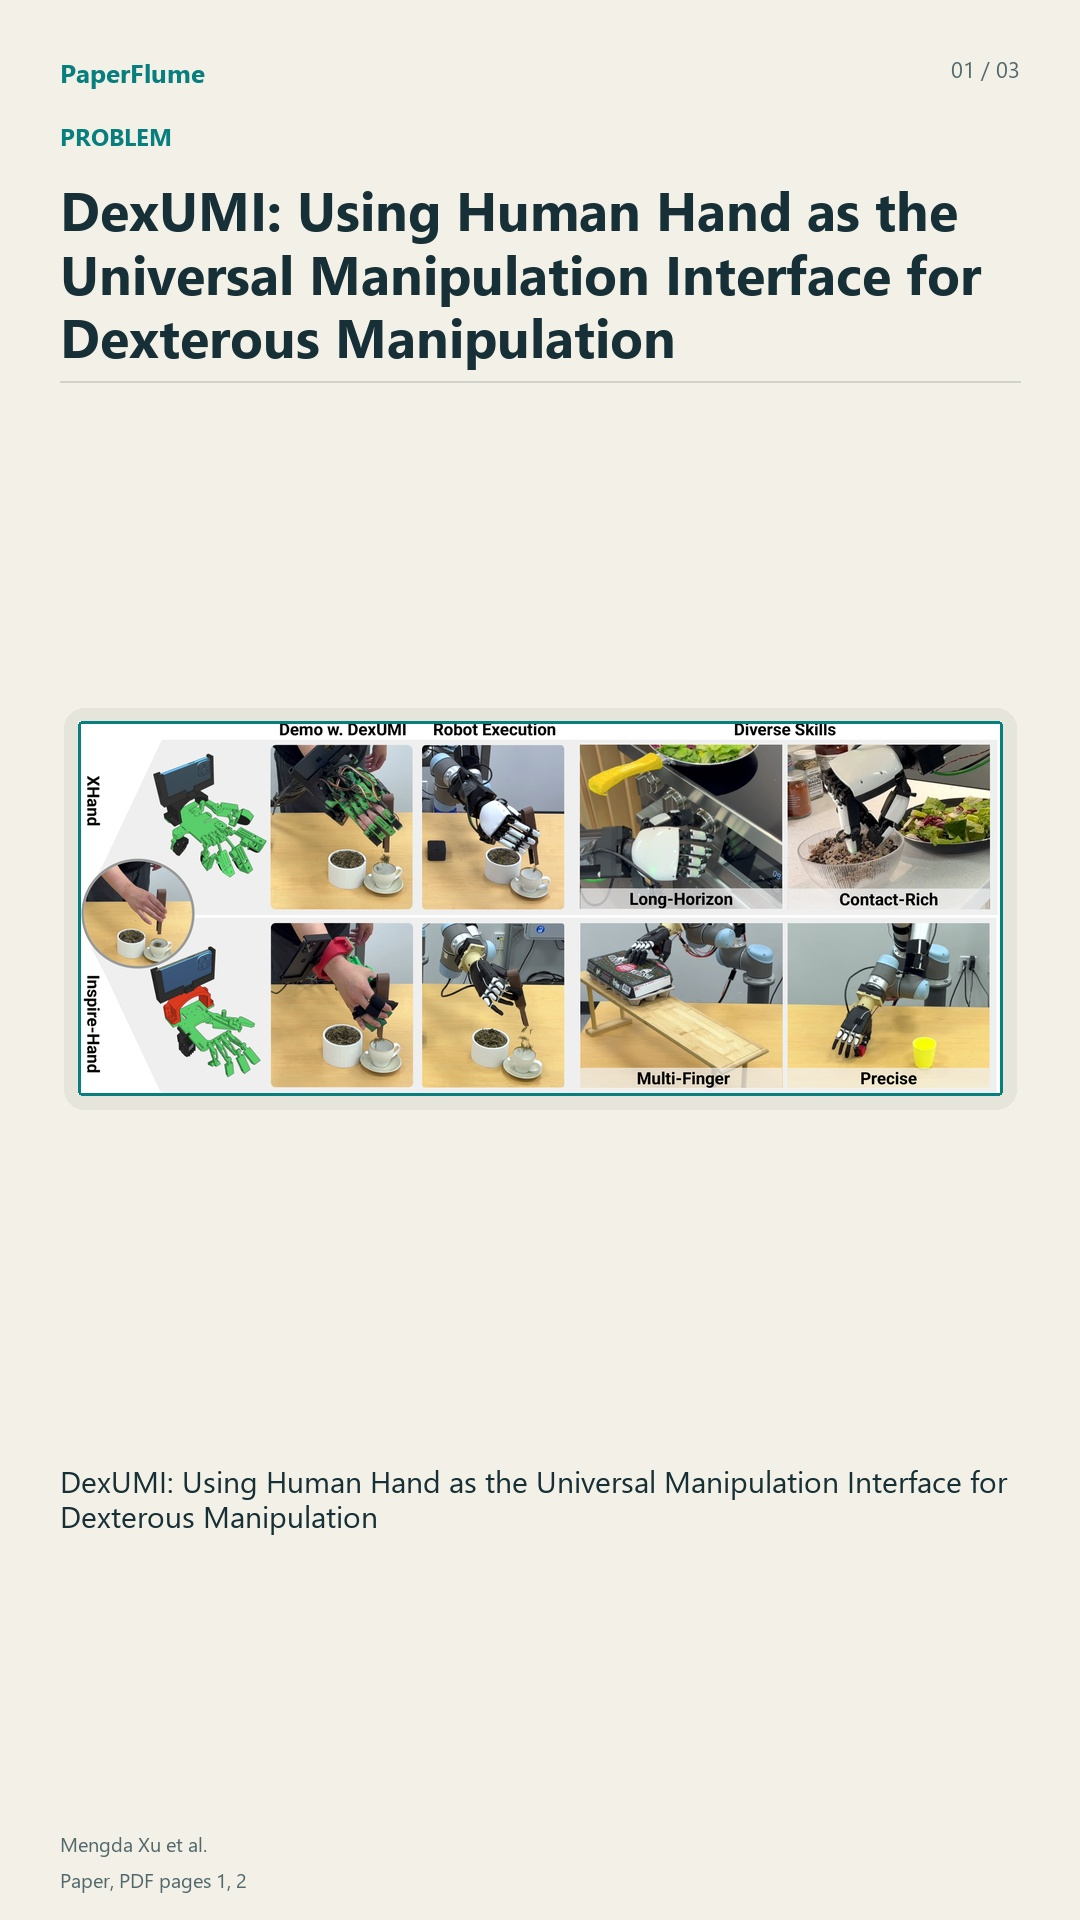
DexUMI: Using Human Hand as the Universal Manipulation Interface for Dexterous Manipulation
shares Dexterous hands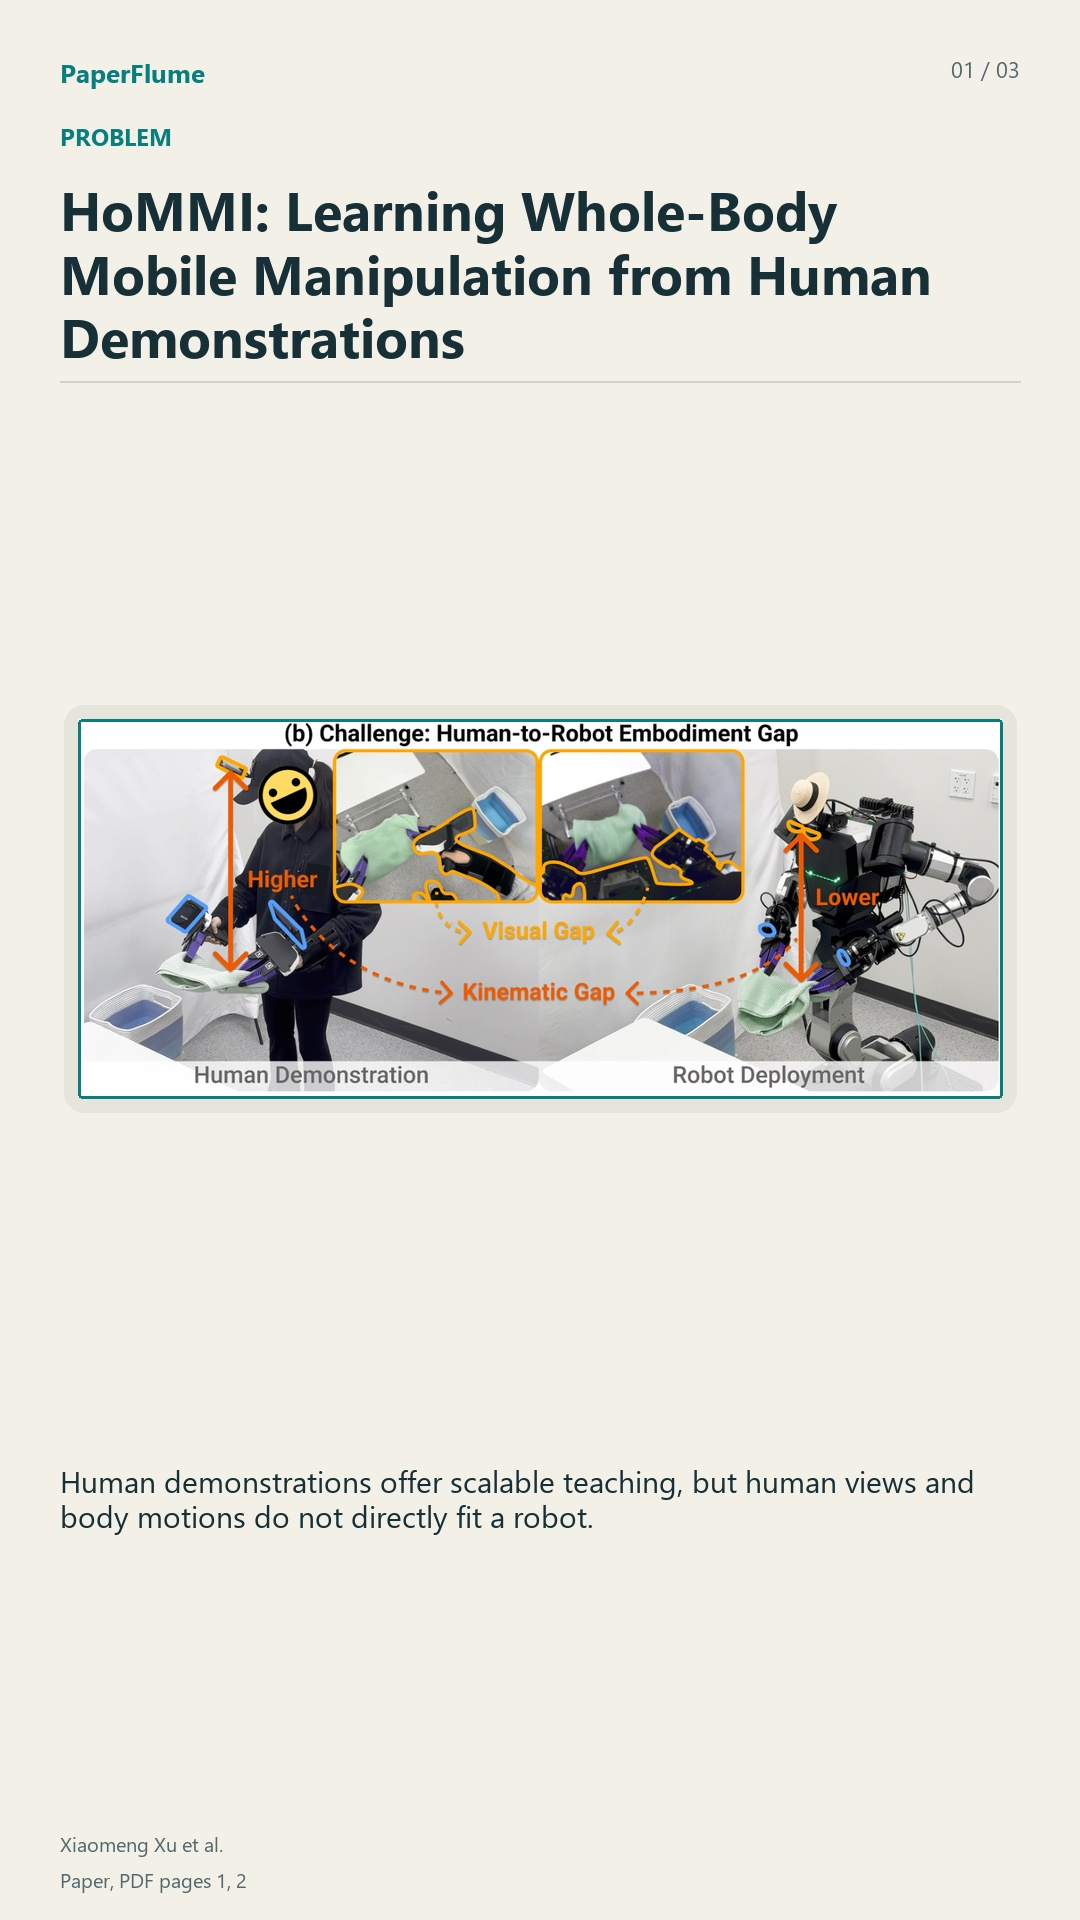 0:54
HoMMI: Learning Whole-Body Mobile Manipulation from Human Demonstrations
2603.03243
shares Mobile manipulation