Next
Papers near this one.
Walkthroughs
 5:46
ObjectReact: Learning Object-Relative Control for Visual Navigation
 5:24
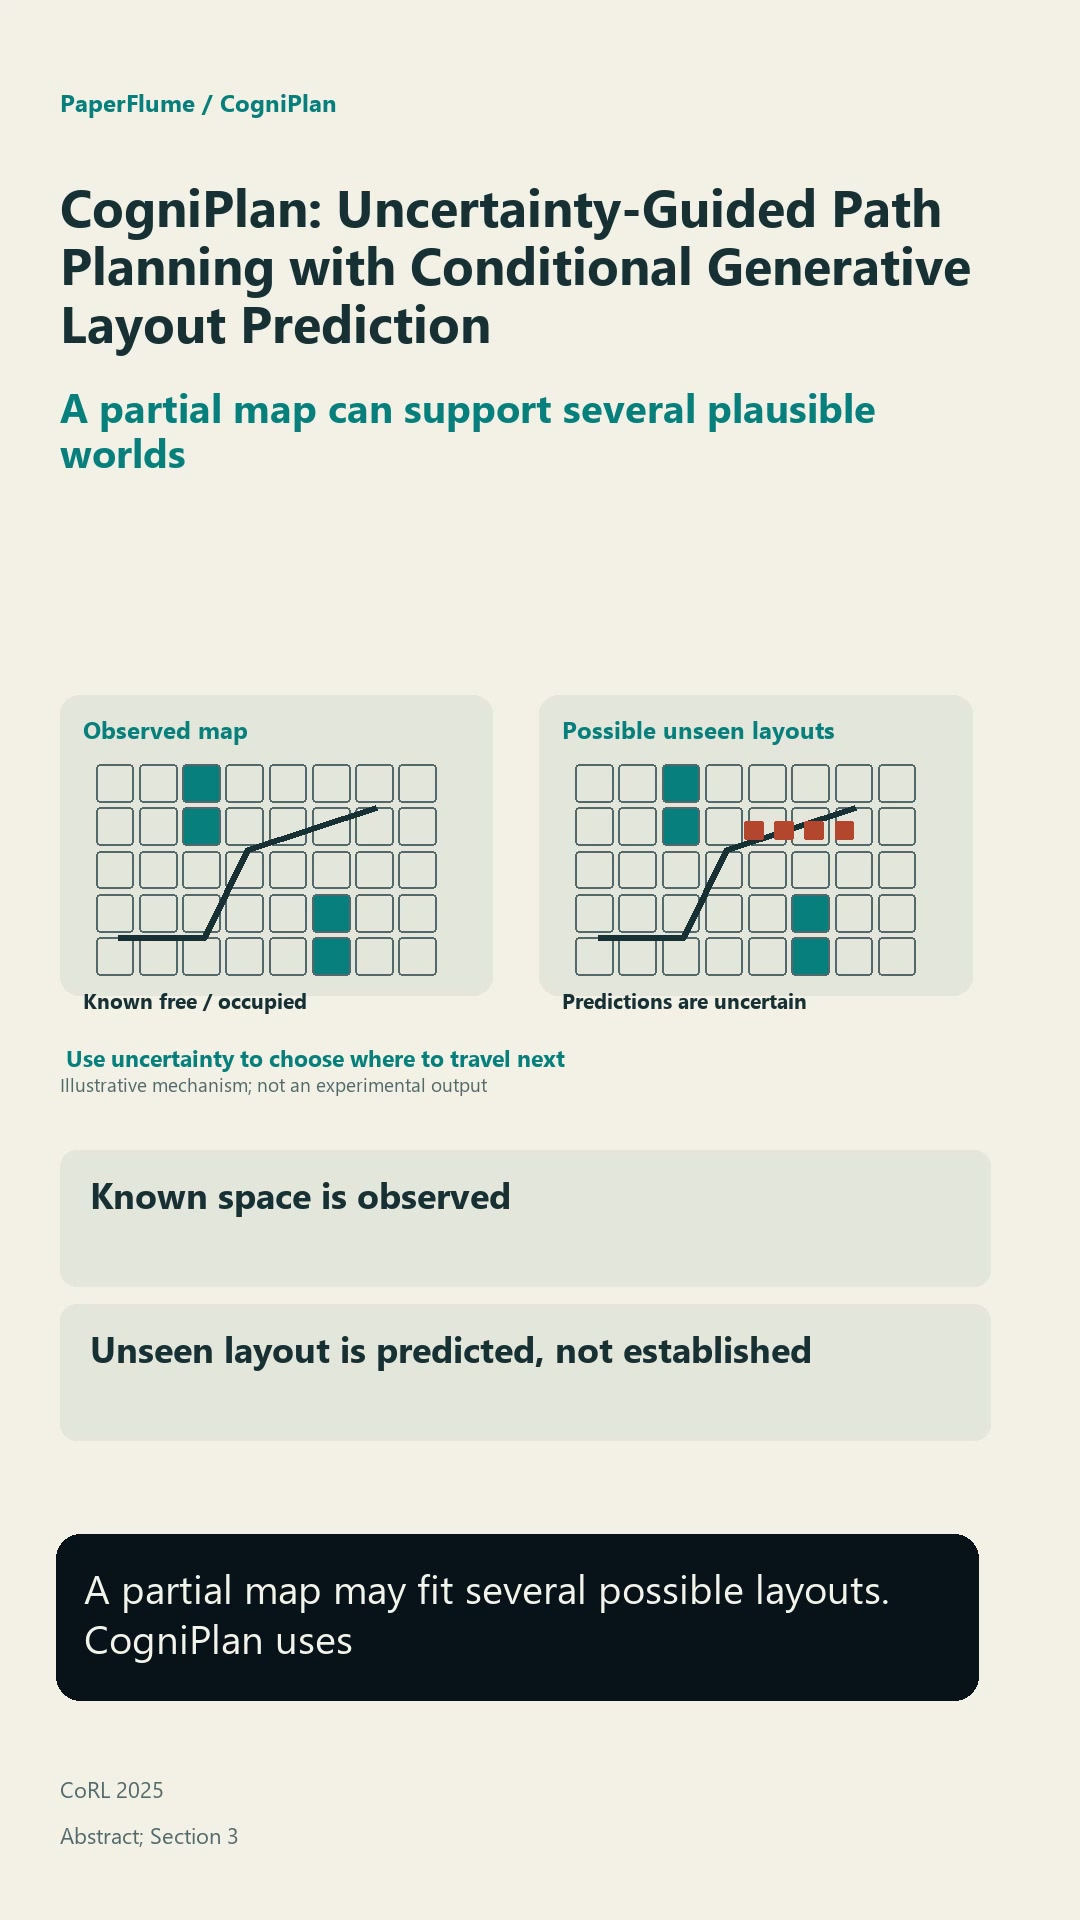
CogniPlan: Uncertainty-Guided Path Planning with Conditional Generative Layout Prediction
shares Informative path planning 5:28
Learning Smooth State-Dependent Traversability from Dense Point Clouds
shares Point cloud understandingShort cuts
 0:50
ObjectReact: Learning Object-Relative Control for Visual Navigation
 0:55
CogniPlan: Uncertainty-Guided Path Planning with Conditional Generative Layout Prediction
shares Informative path planning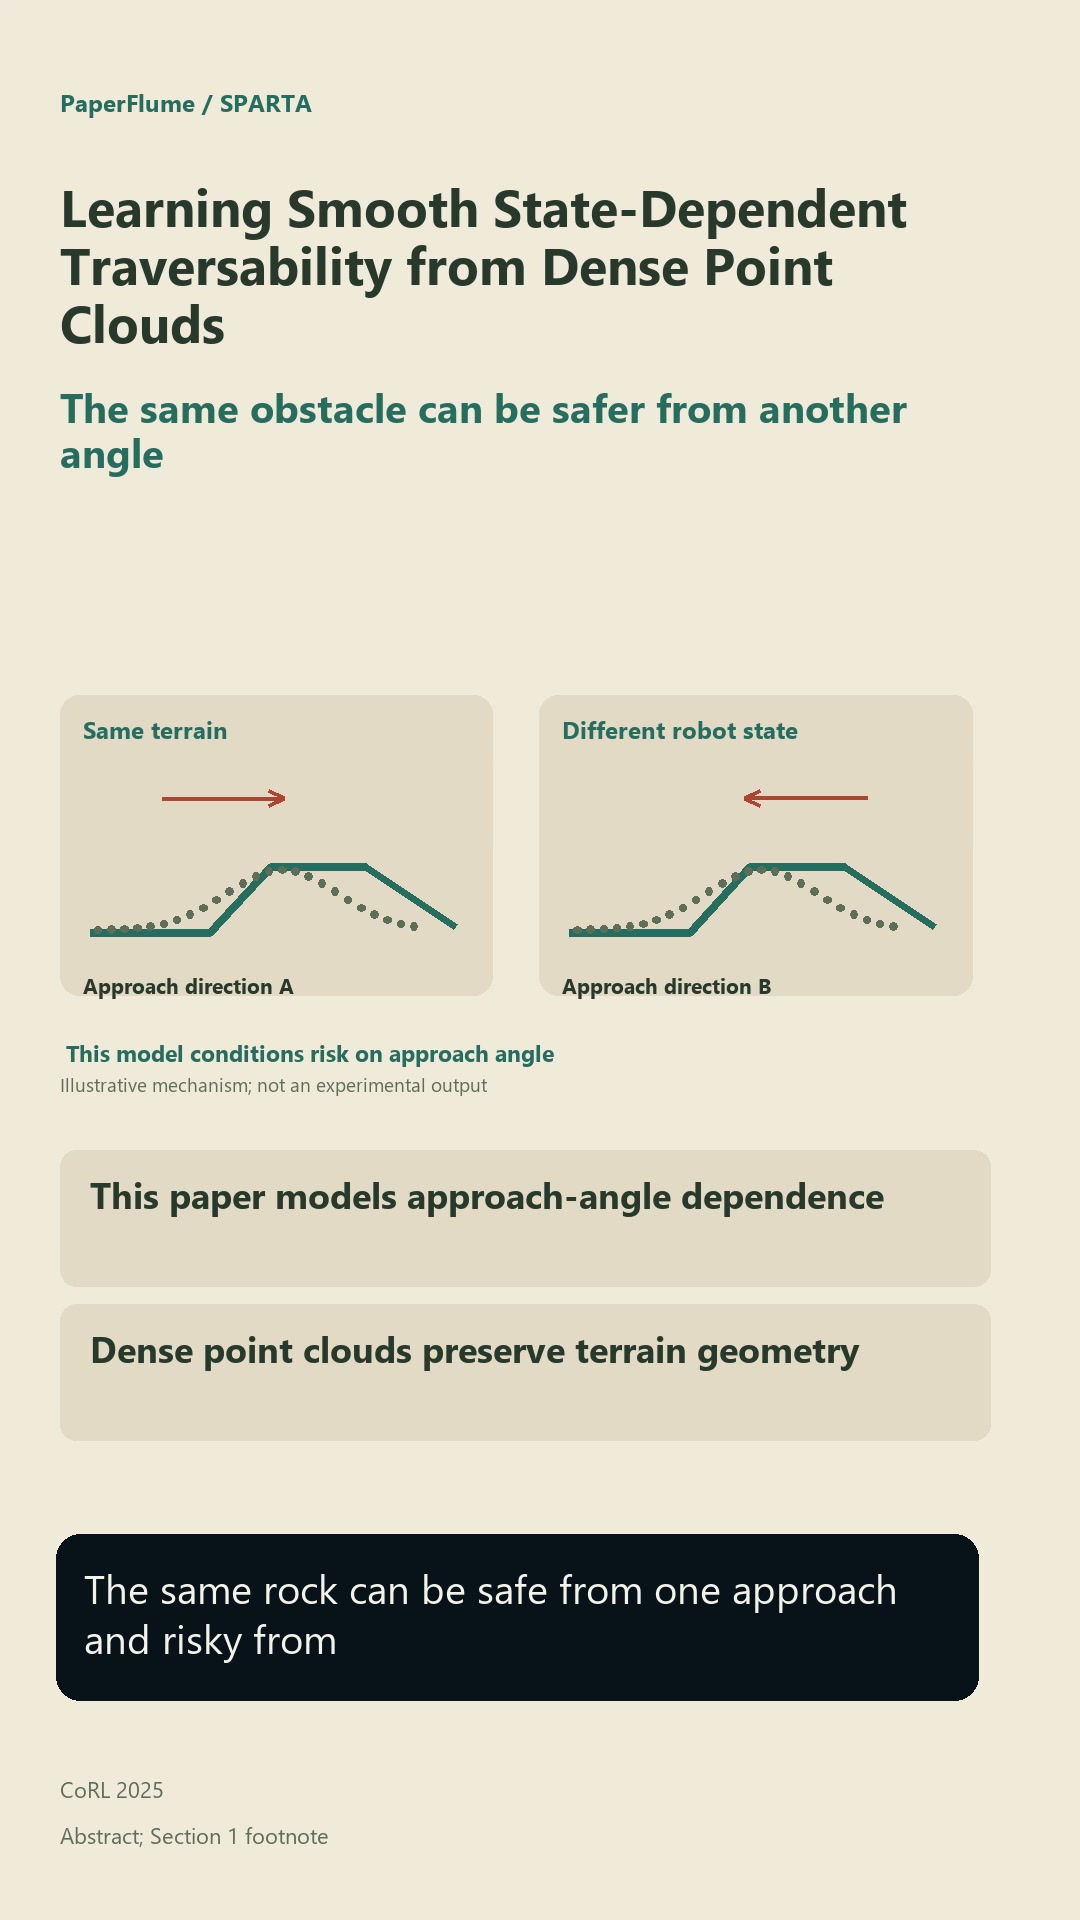 0:52