Next
Papers near this one.
Walkthroughs
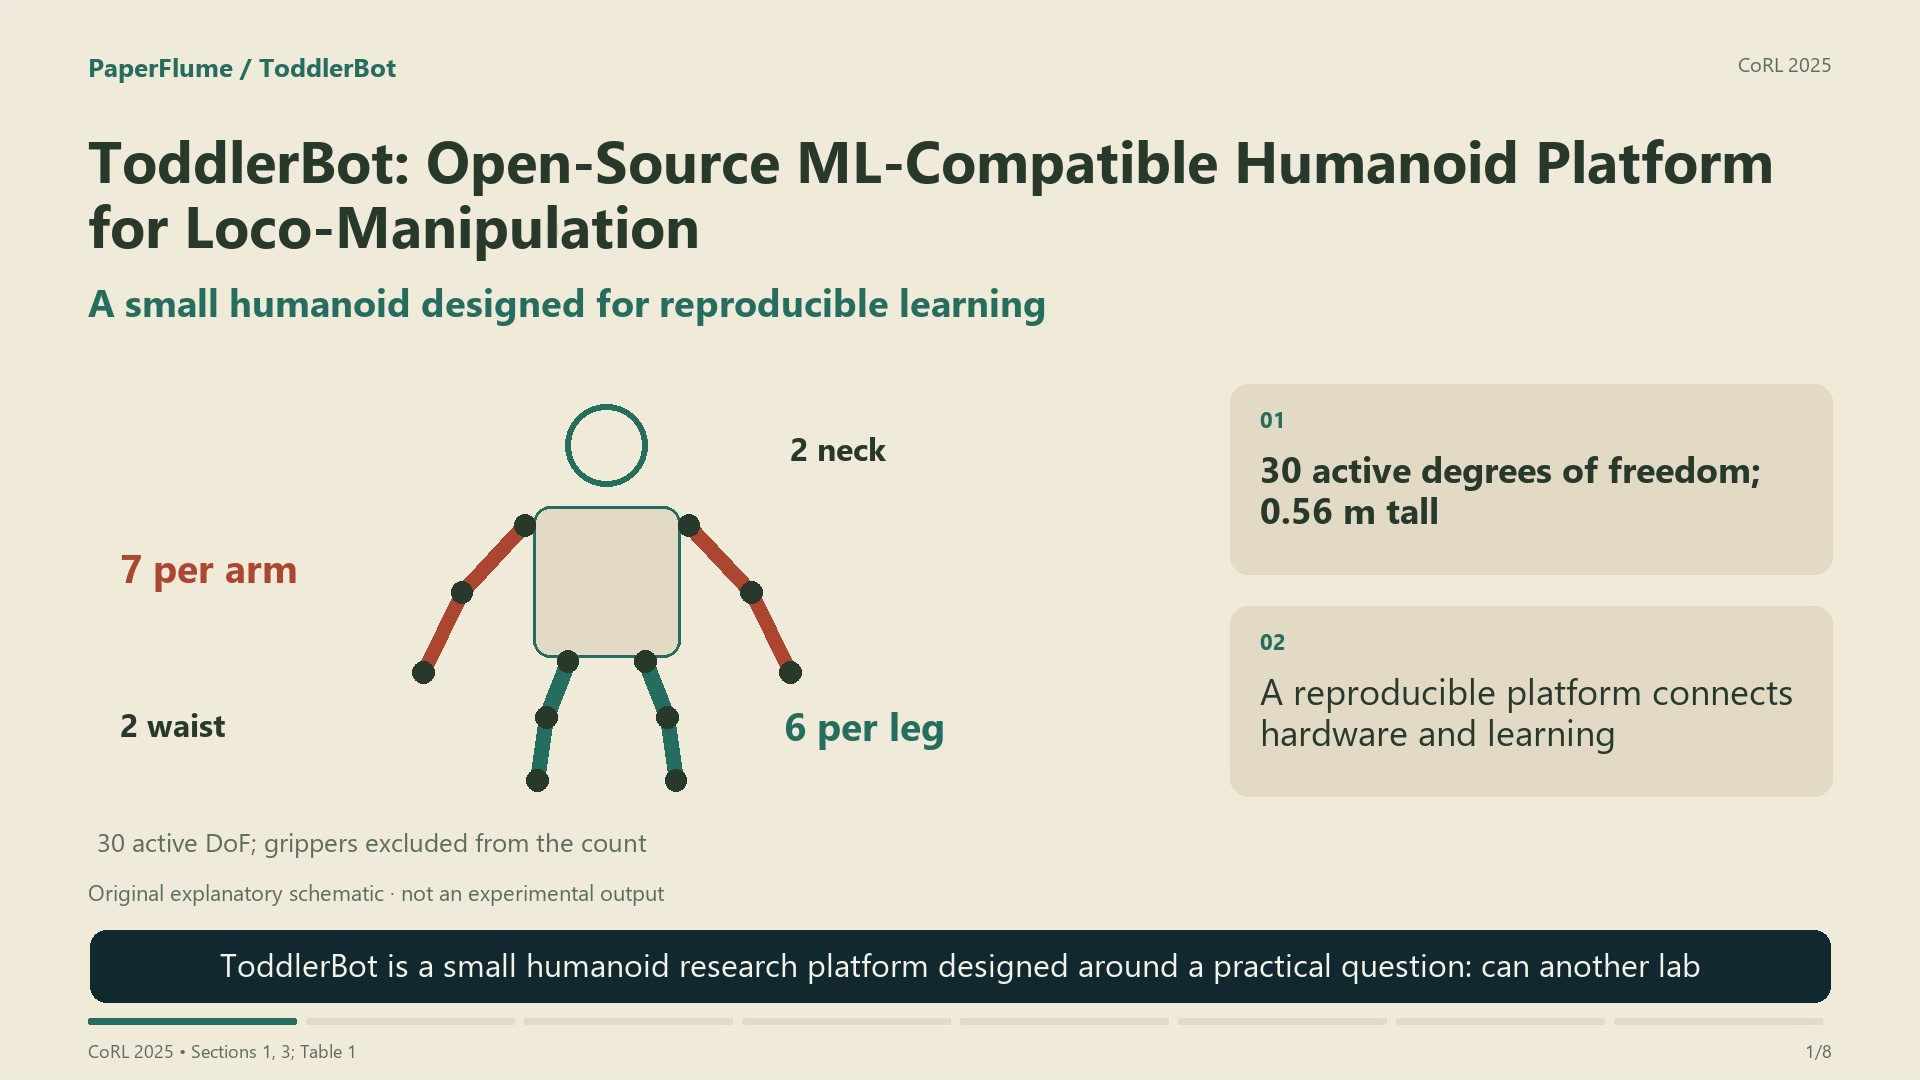 6:13
ToddlerBot: Open-Source ML-Compatible Humanoid Platform for Loco-Manipulation
shares RL for control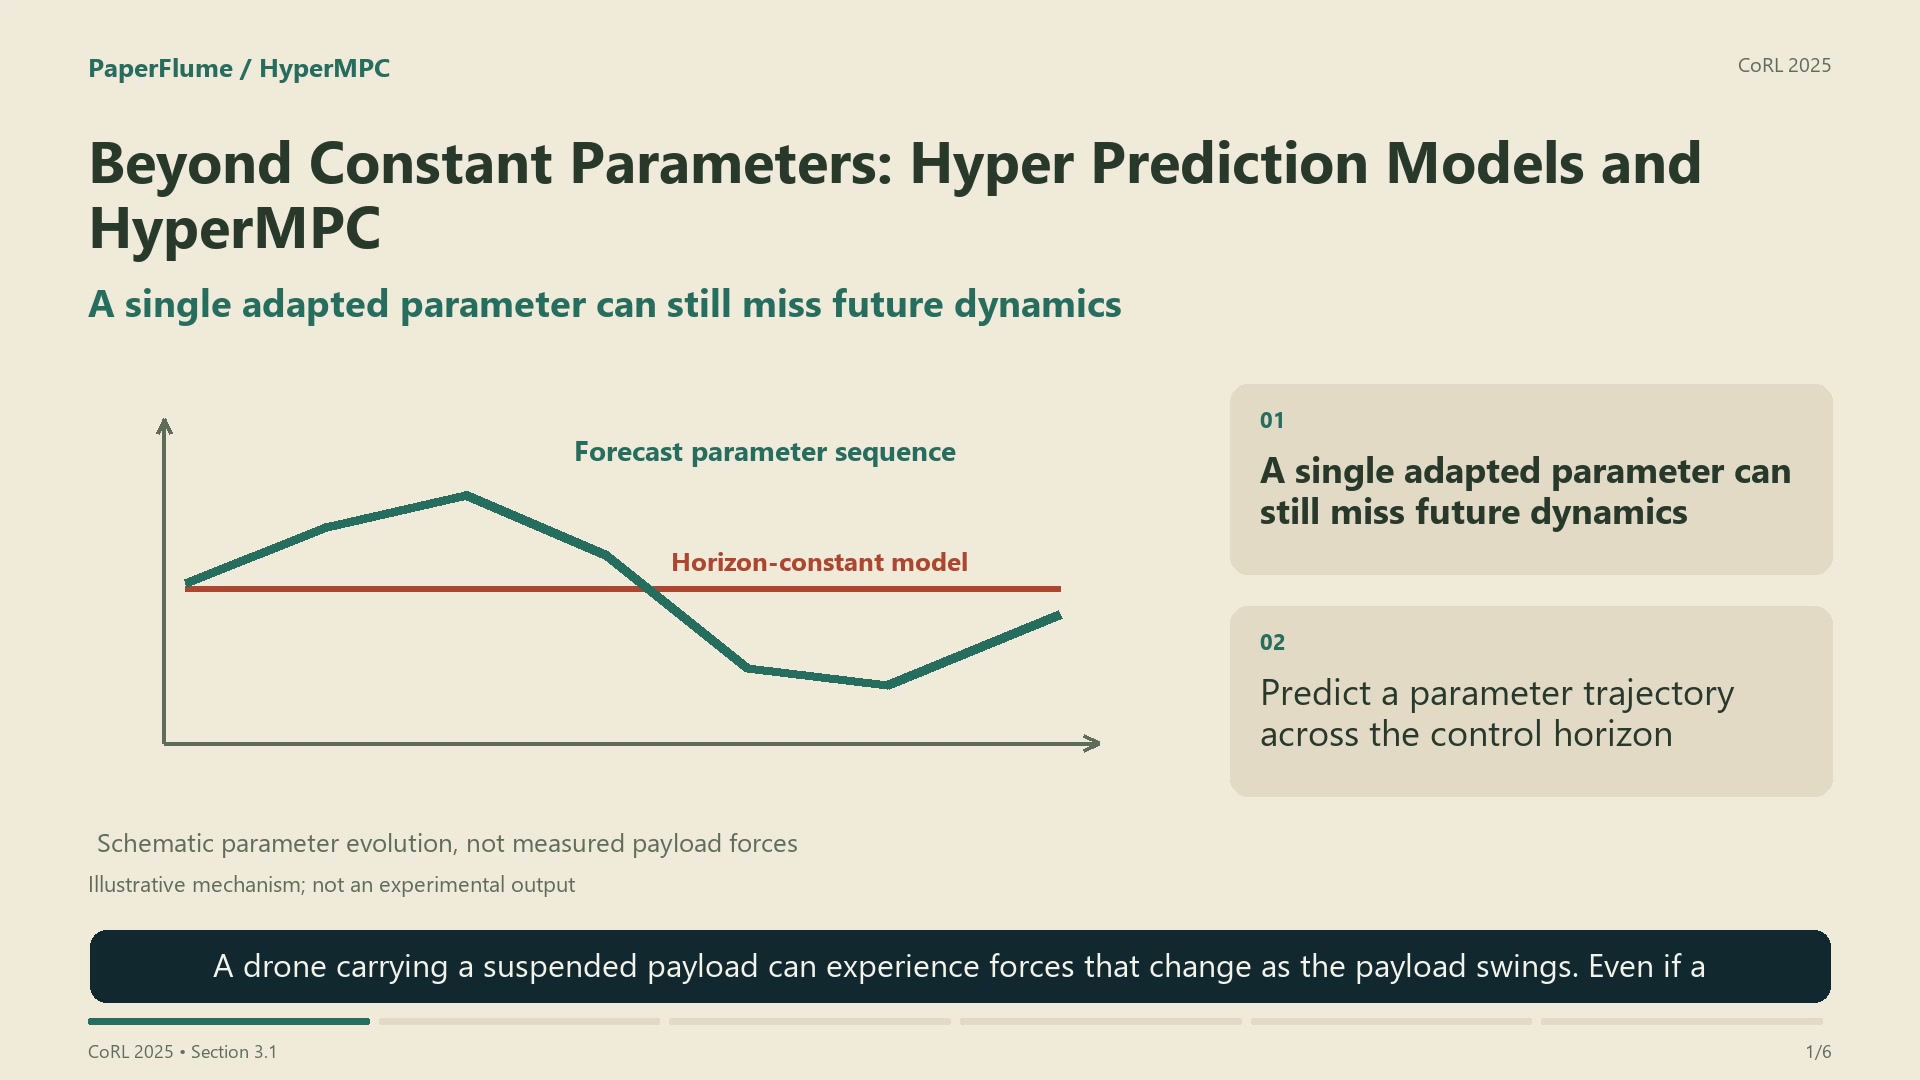 3:51
Beyond Constant Parameters: Hyper Prediction Models and HyperMPC
shares Model predictive control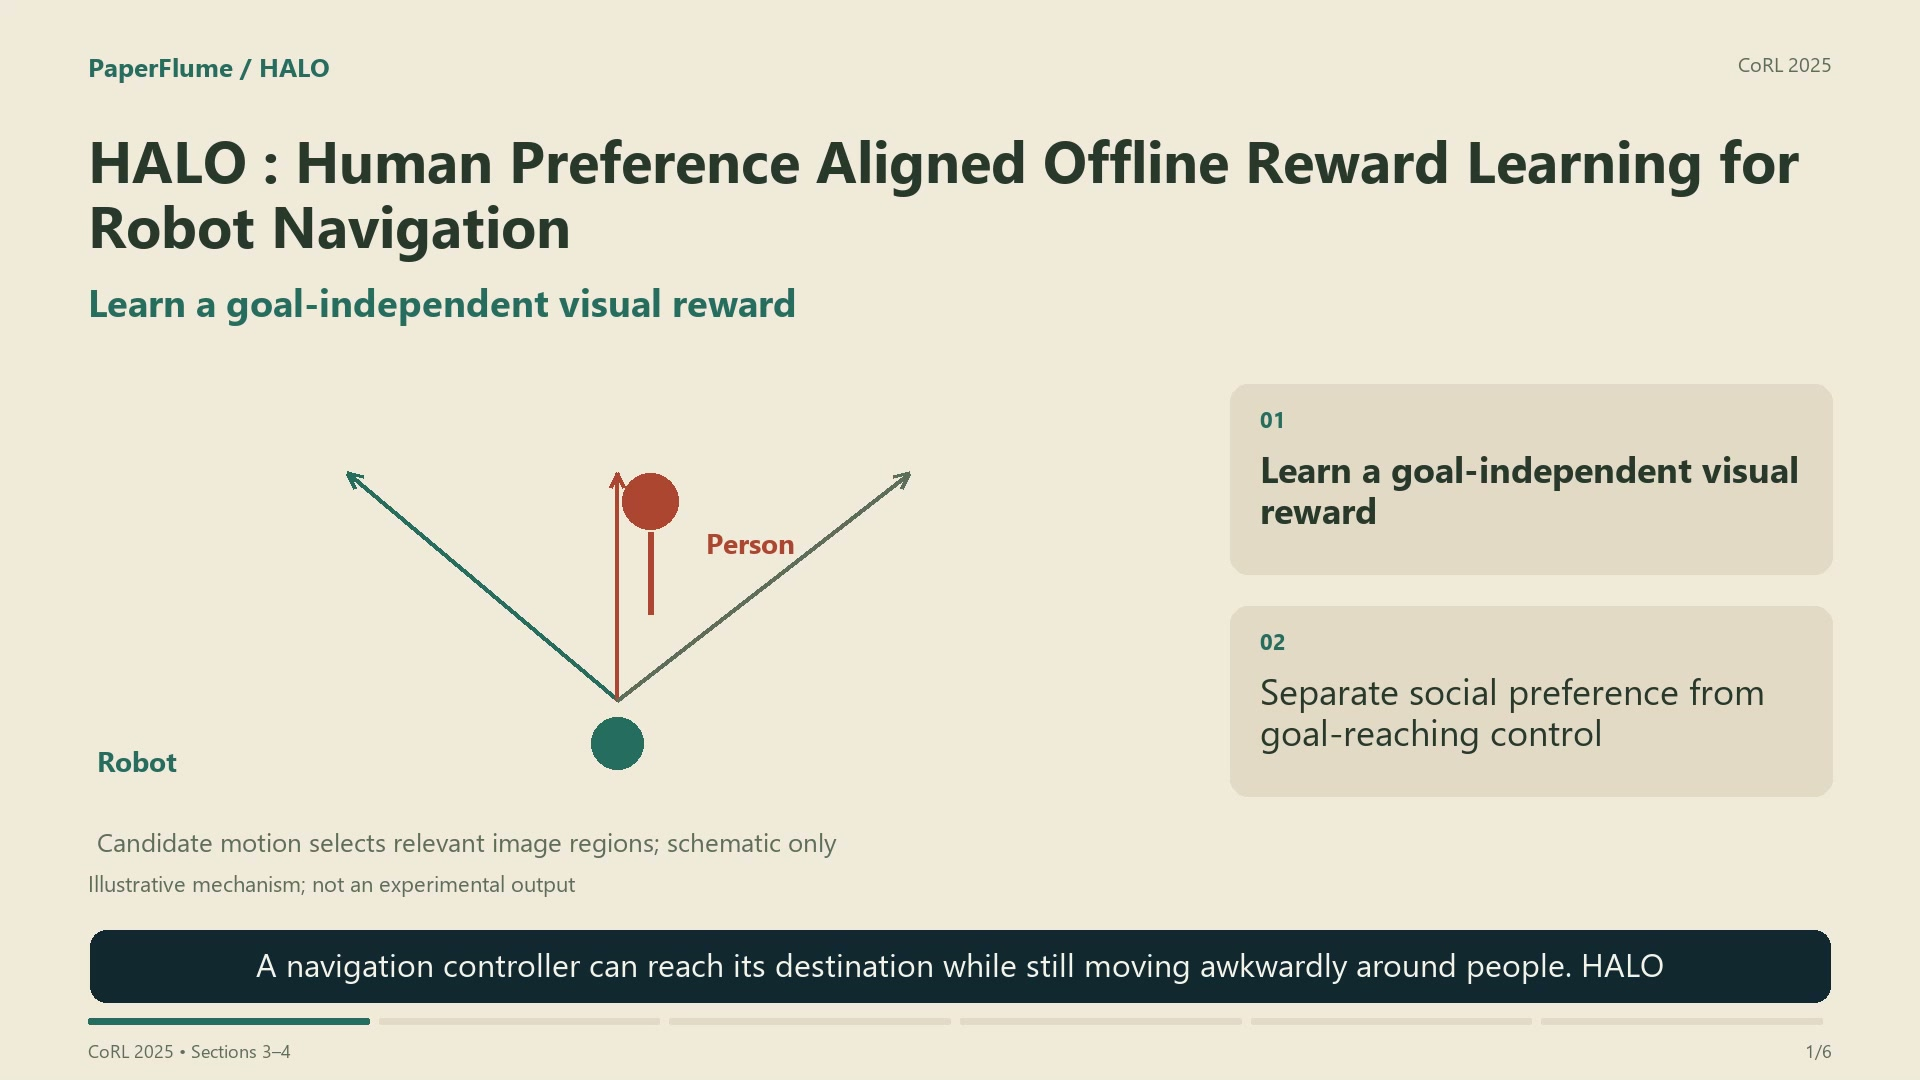 3:56
HALO : Human Preference Aligned Offline Reward Learning for Robot Navigation
shares RL for controlShort cuts
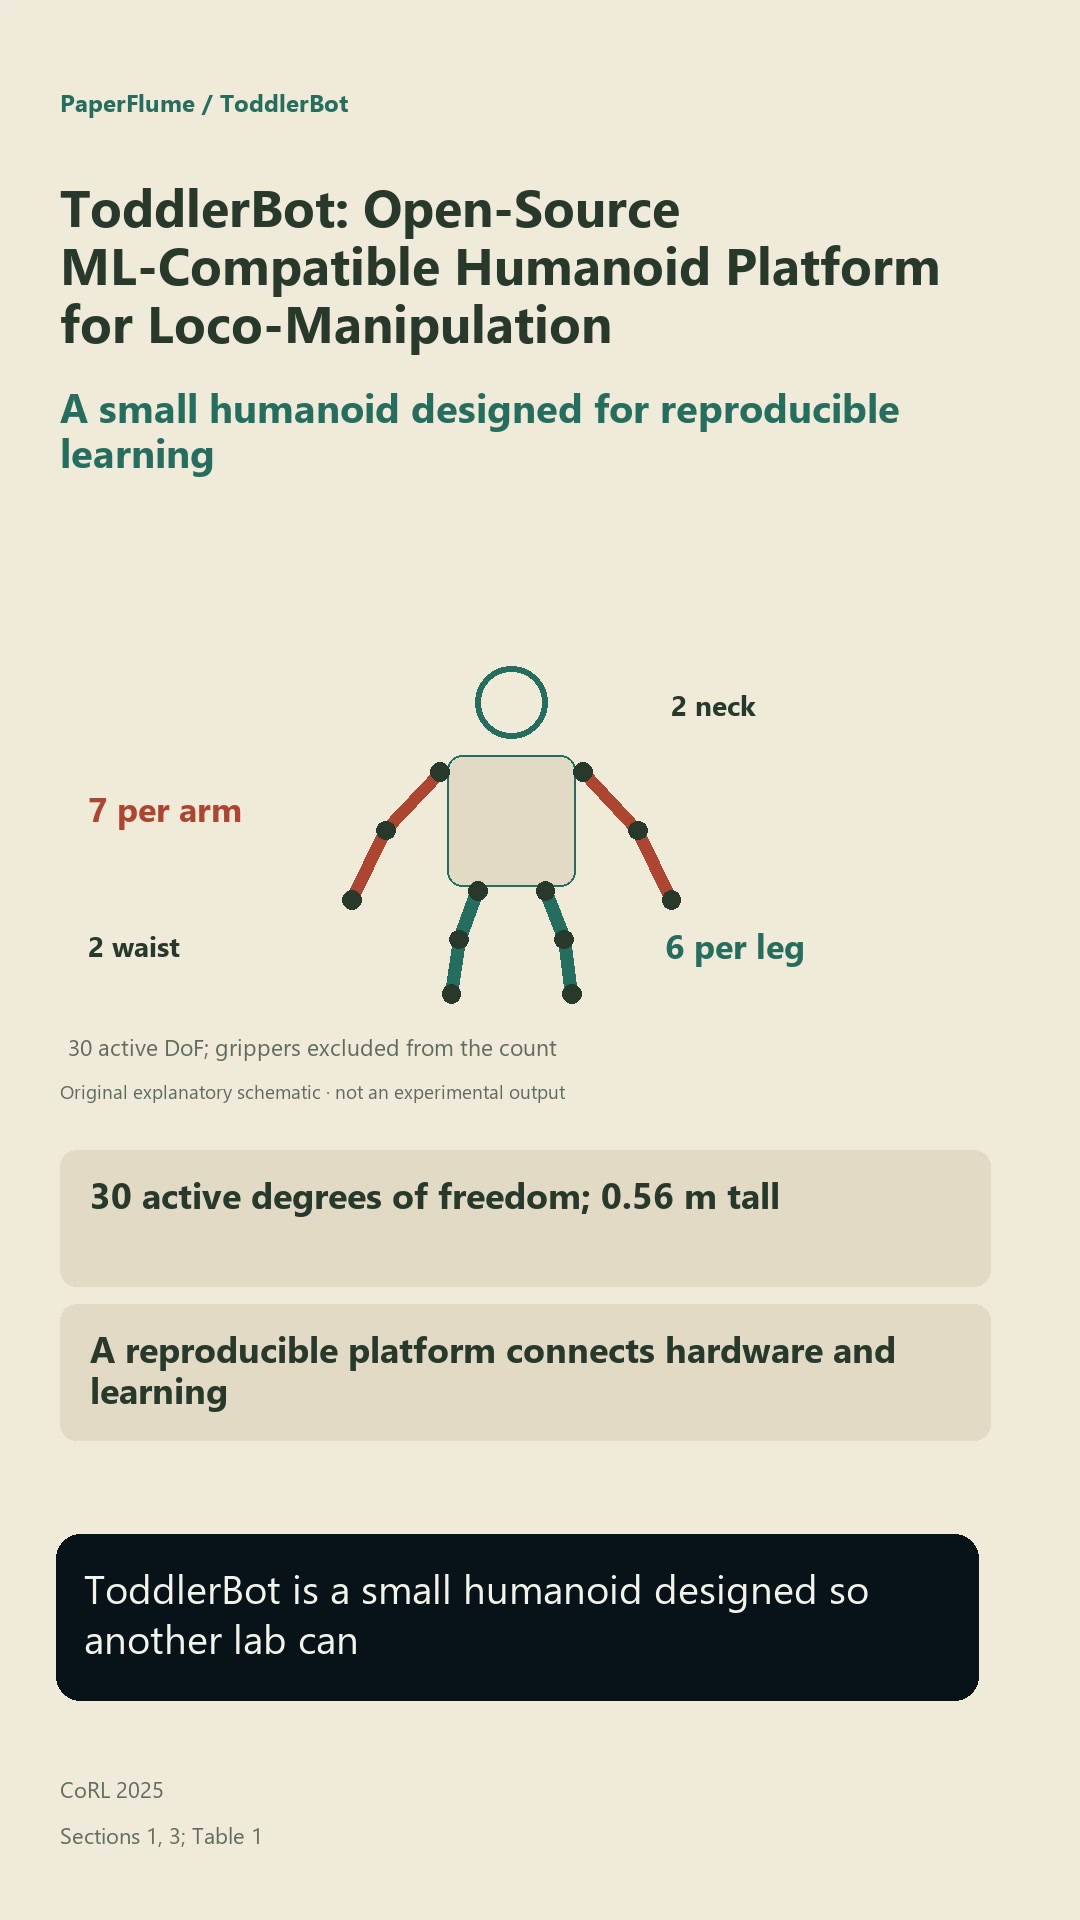 1:01
ToddlerBot: Open-Source ML-Compatible Humanoid Platform for Loco-Manipulation
shares RL for control 0:38
Beyond Constant Parameters: Hyper Prediction Models and HyperMPC
shares Model predictive control 0:37