Next
Papers near this one.
Walkthroughs
 3:58
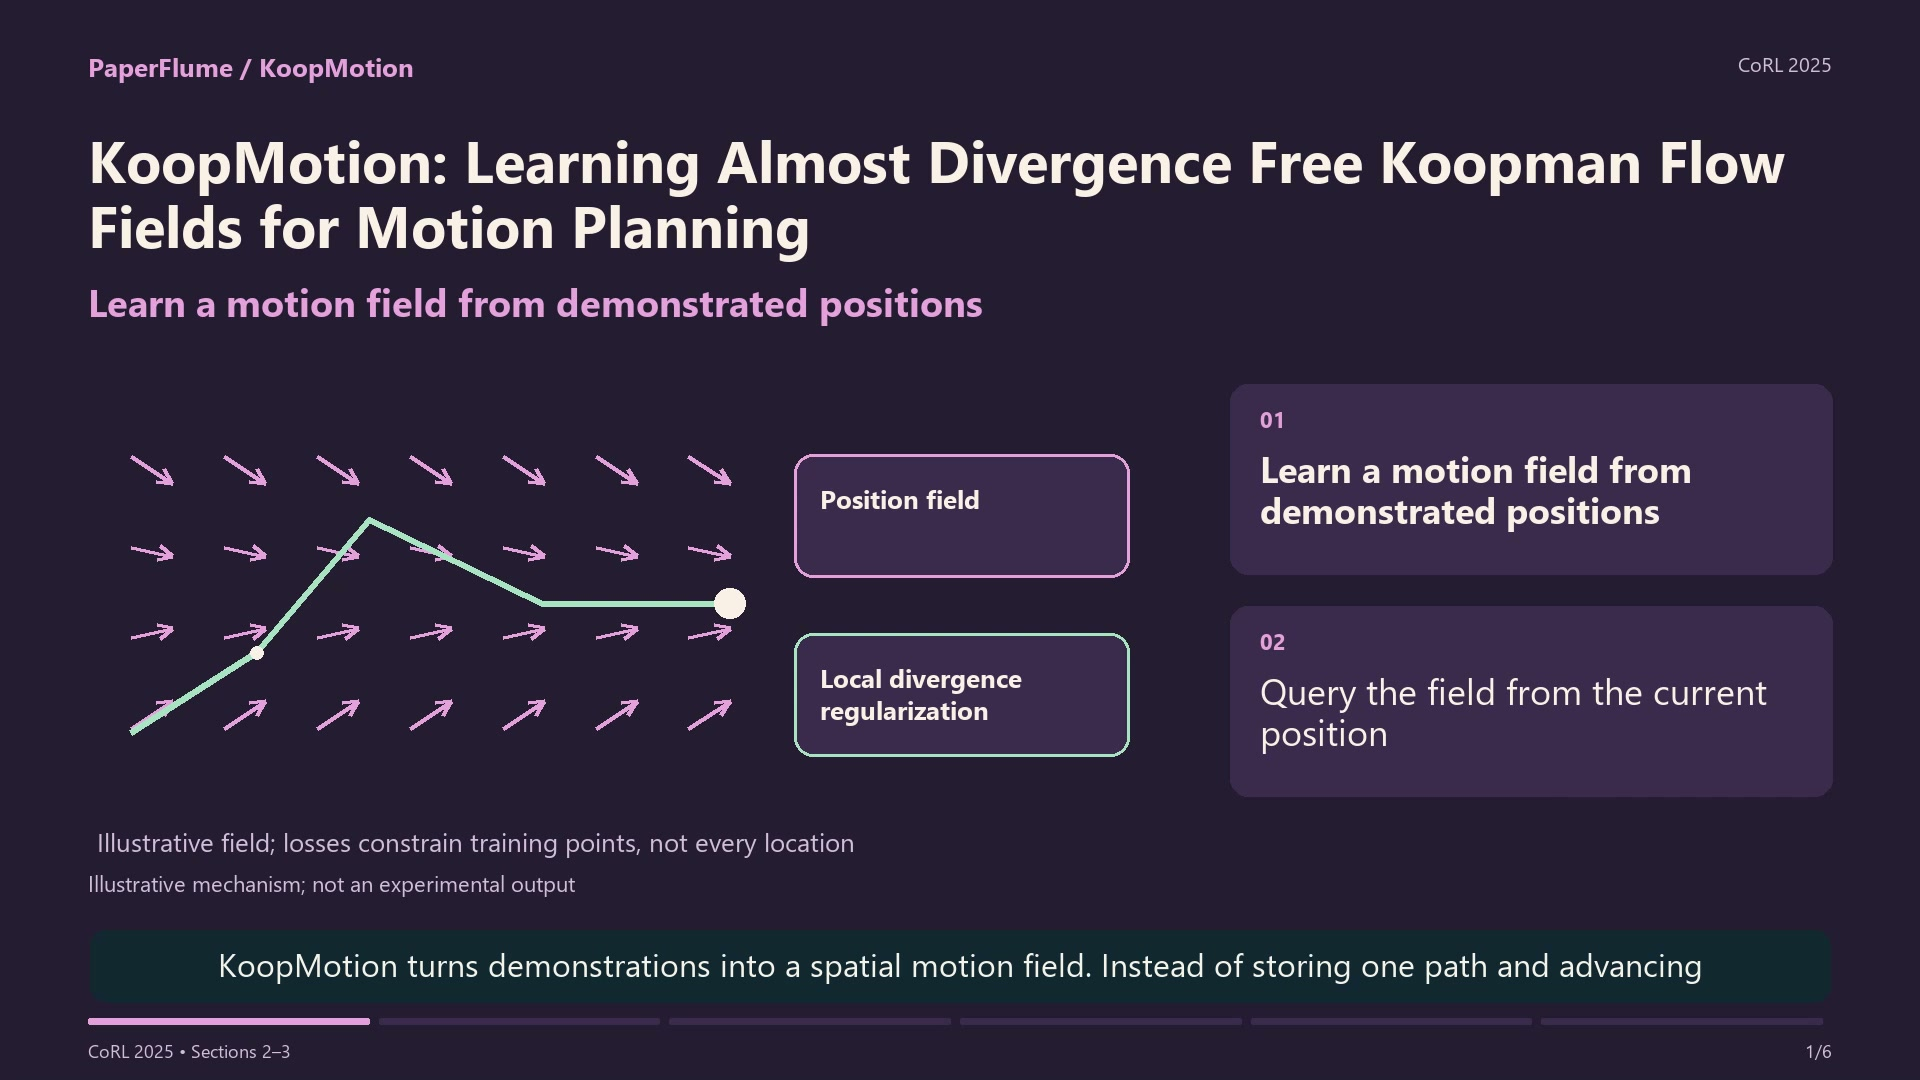
KoopMotion: Learning Almost Divergence Free Koopman Flow Fields for Motion Planning
shares Trajectory optimisation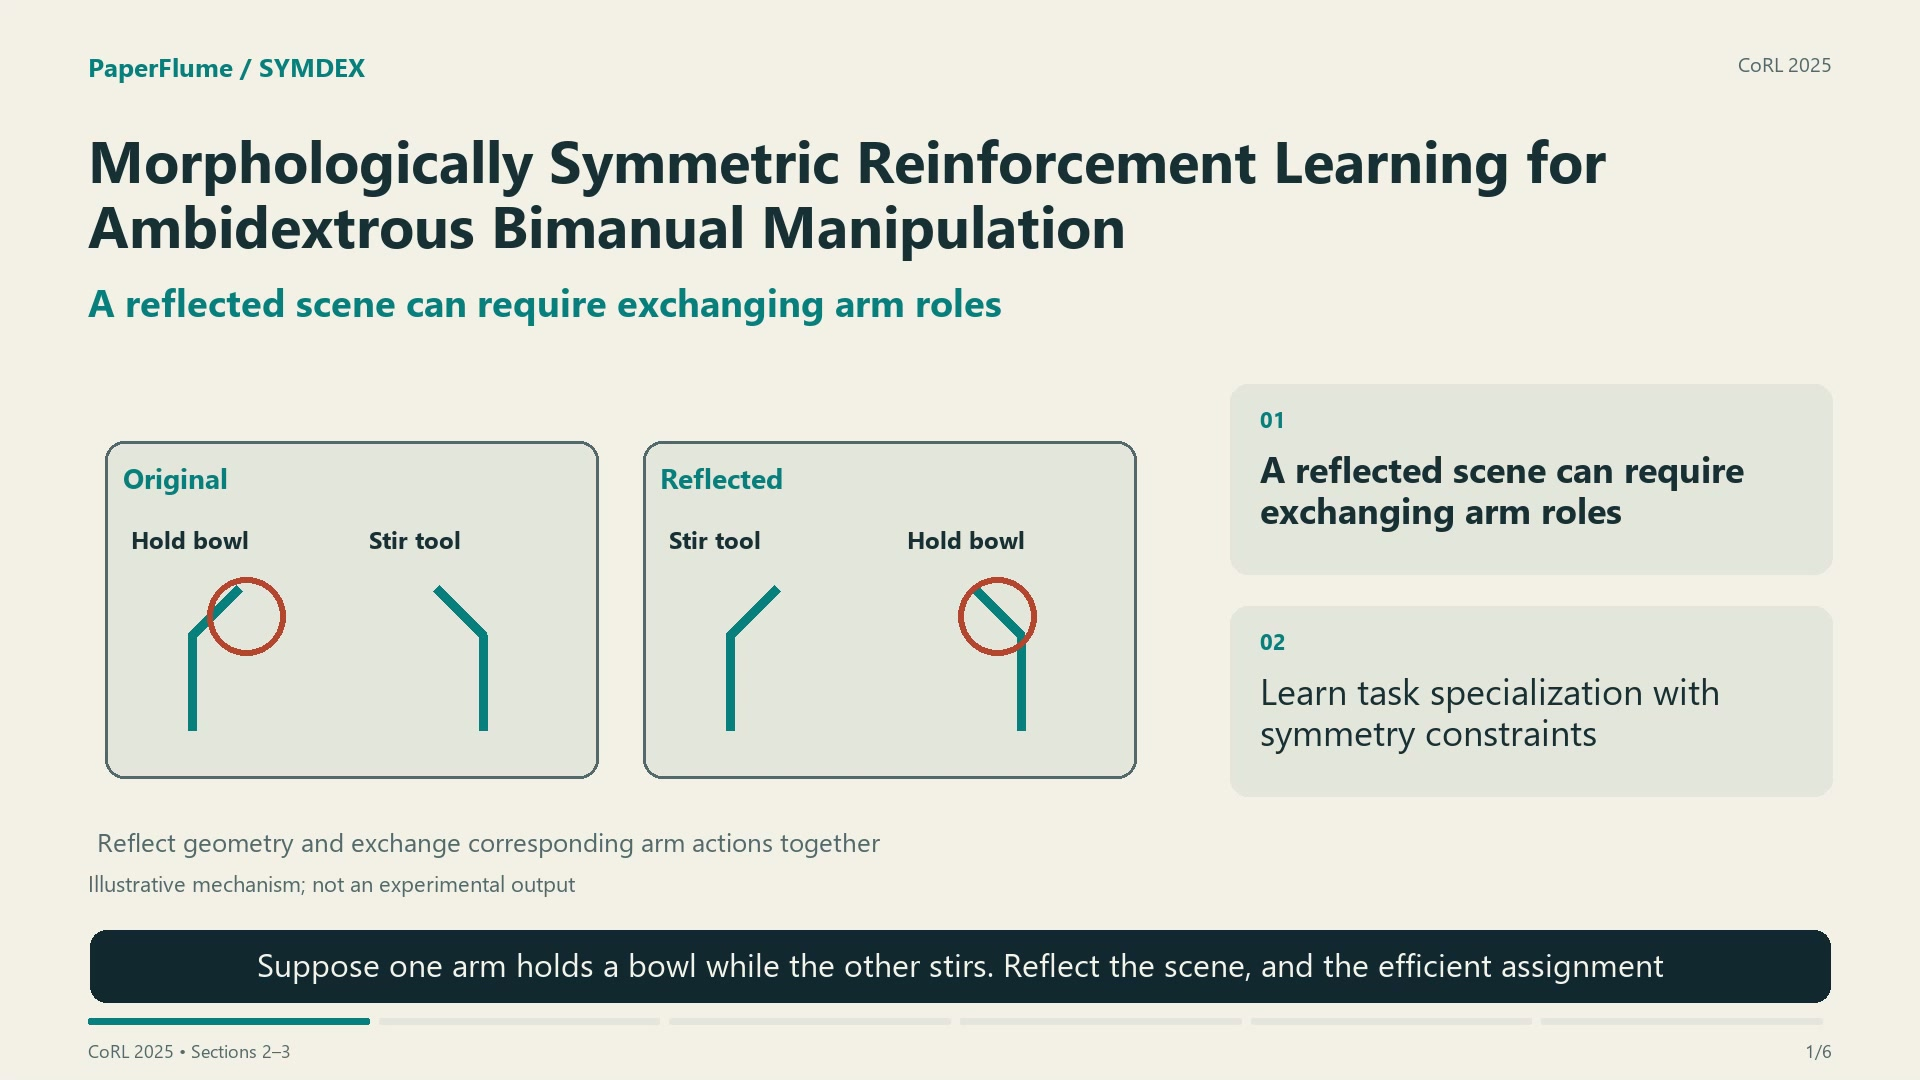 4:12
Morphologically Symmetric Reinforcement Learning for Ambidextrous Bimanual Manipulation
shares RL for control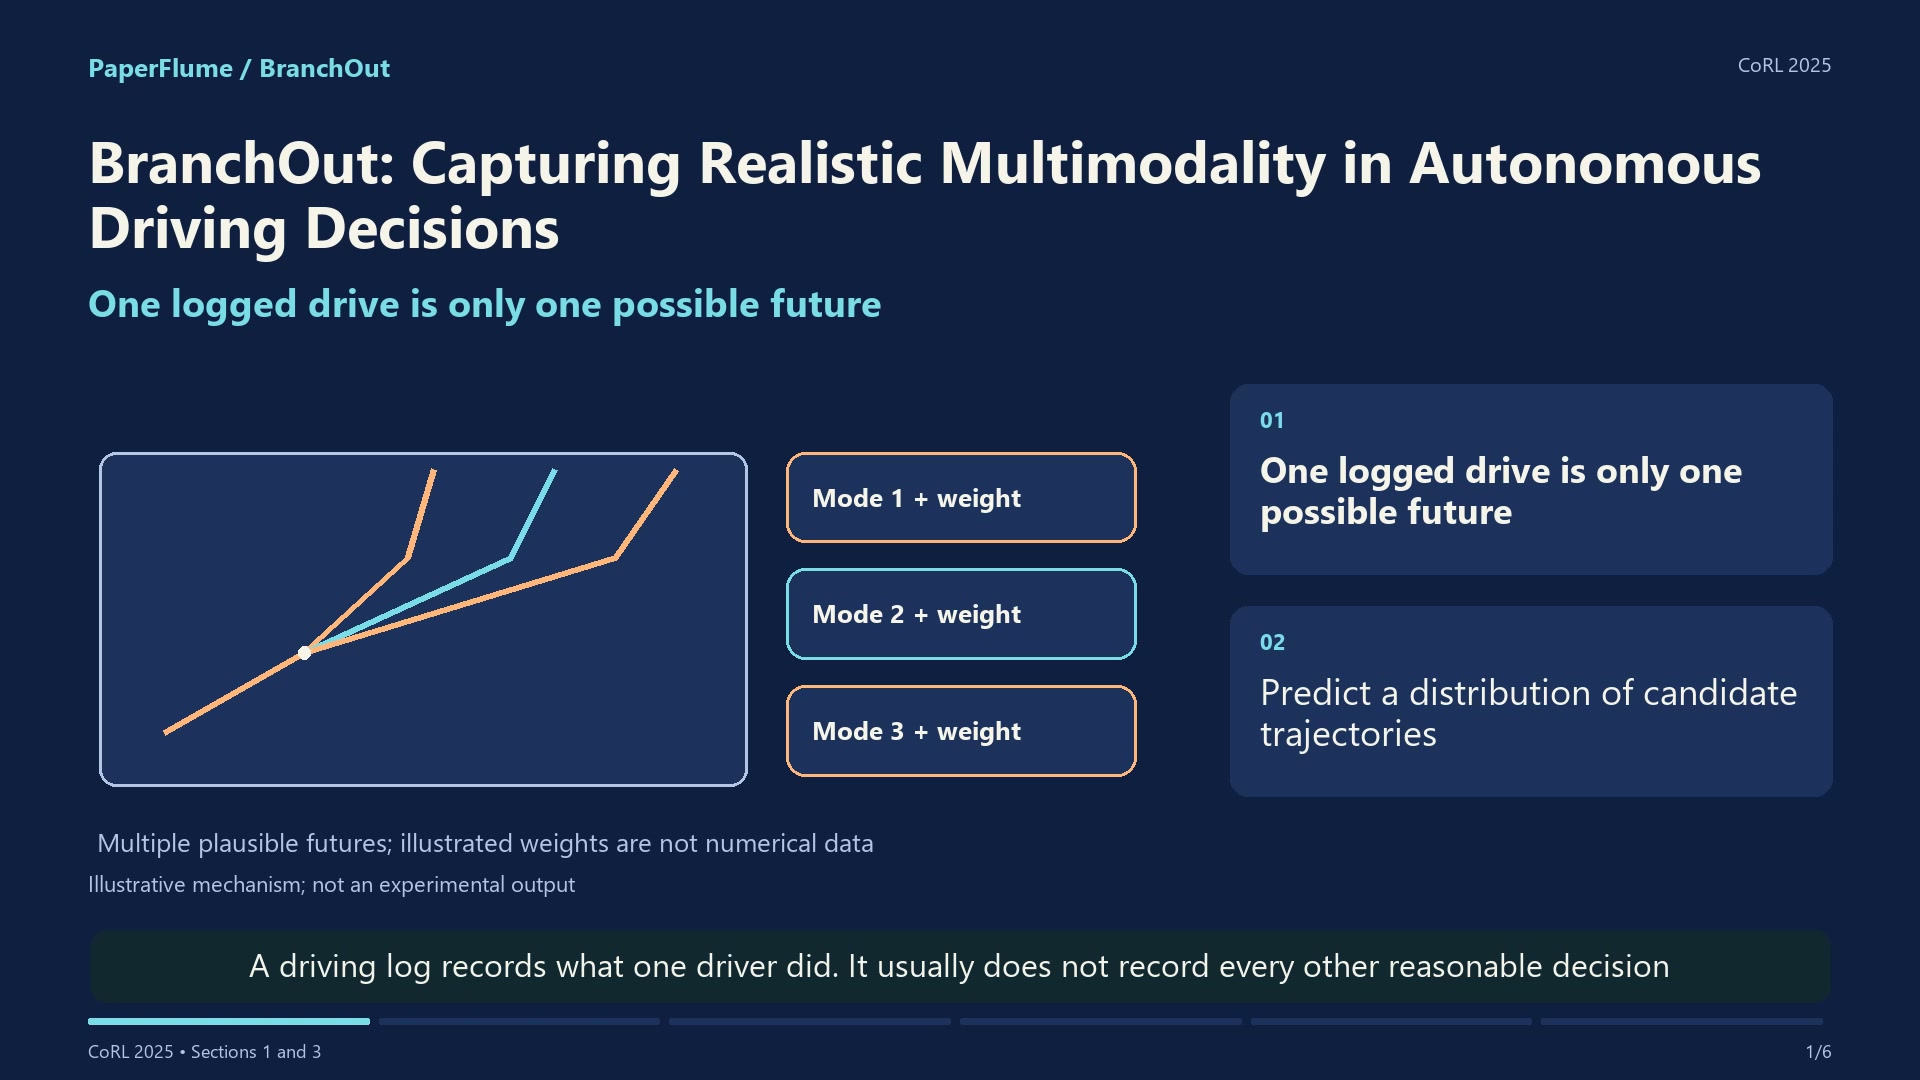 4:10
BranchOut: Capturing Realistic Multimodality in Autonomous Driving Decisions
shares Trajectory optimisationShort cuts
 0:41
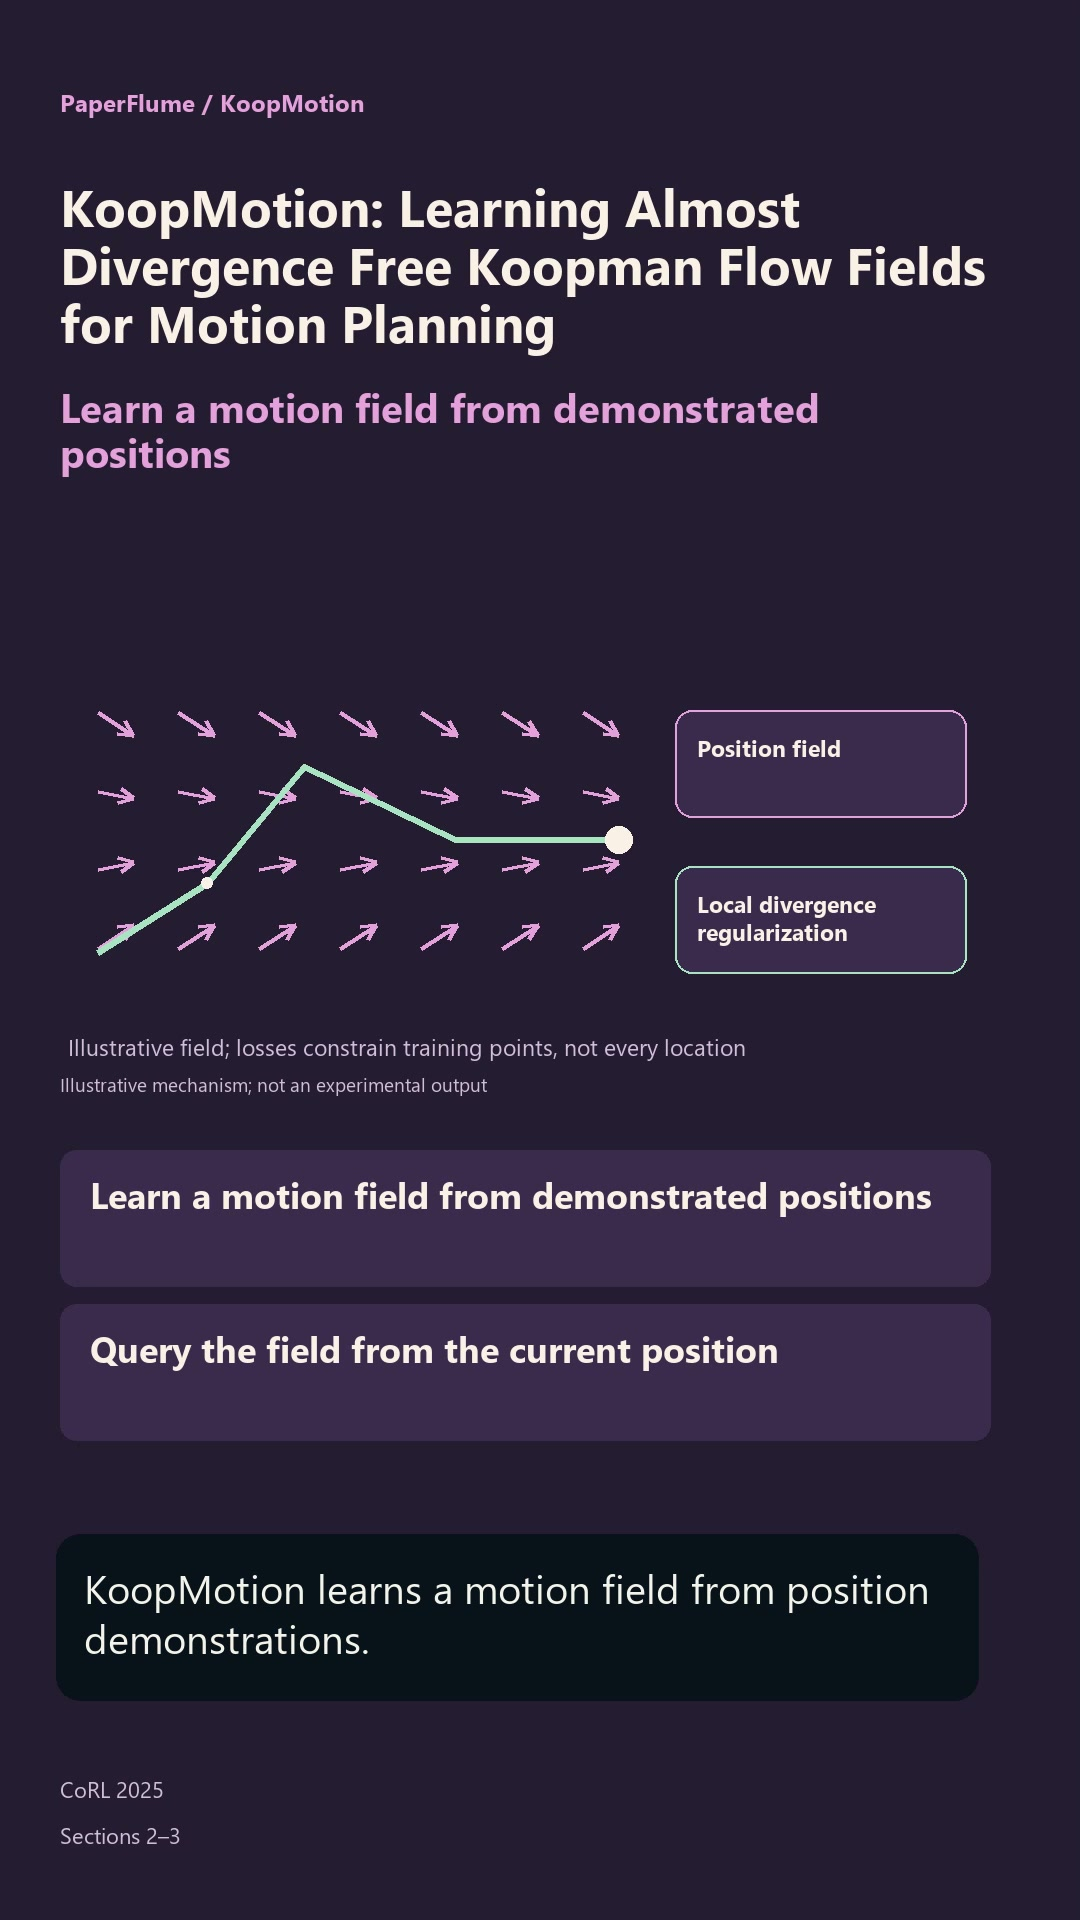
KoopMotion: Learning Almost Divergence Free Koopman Flow Fields for Motion Planning
shares Trajectory optimisation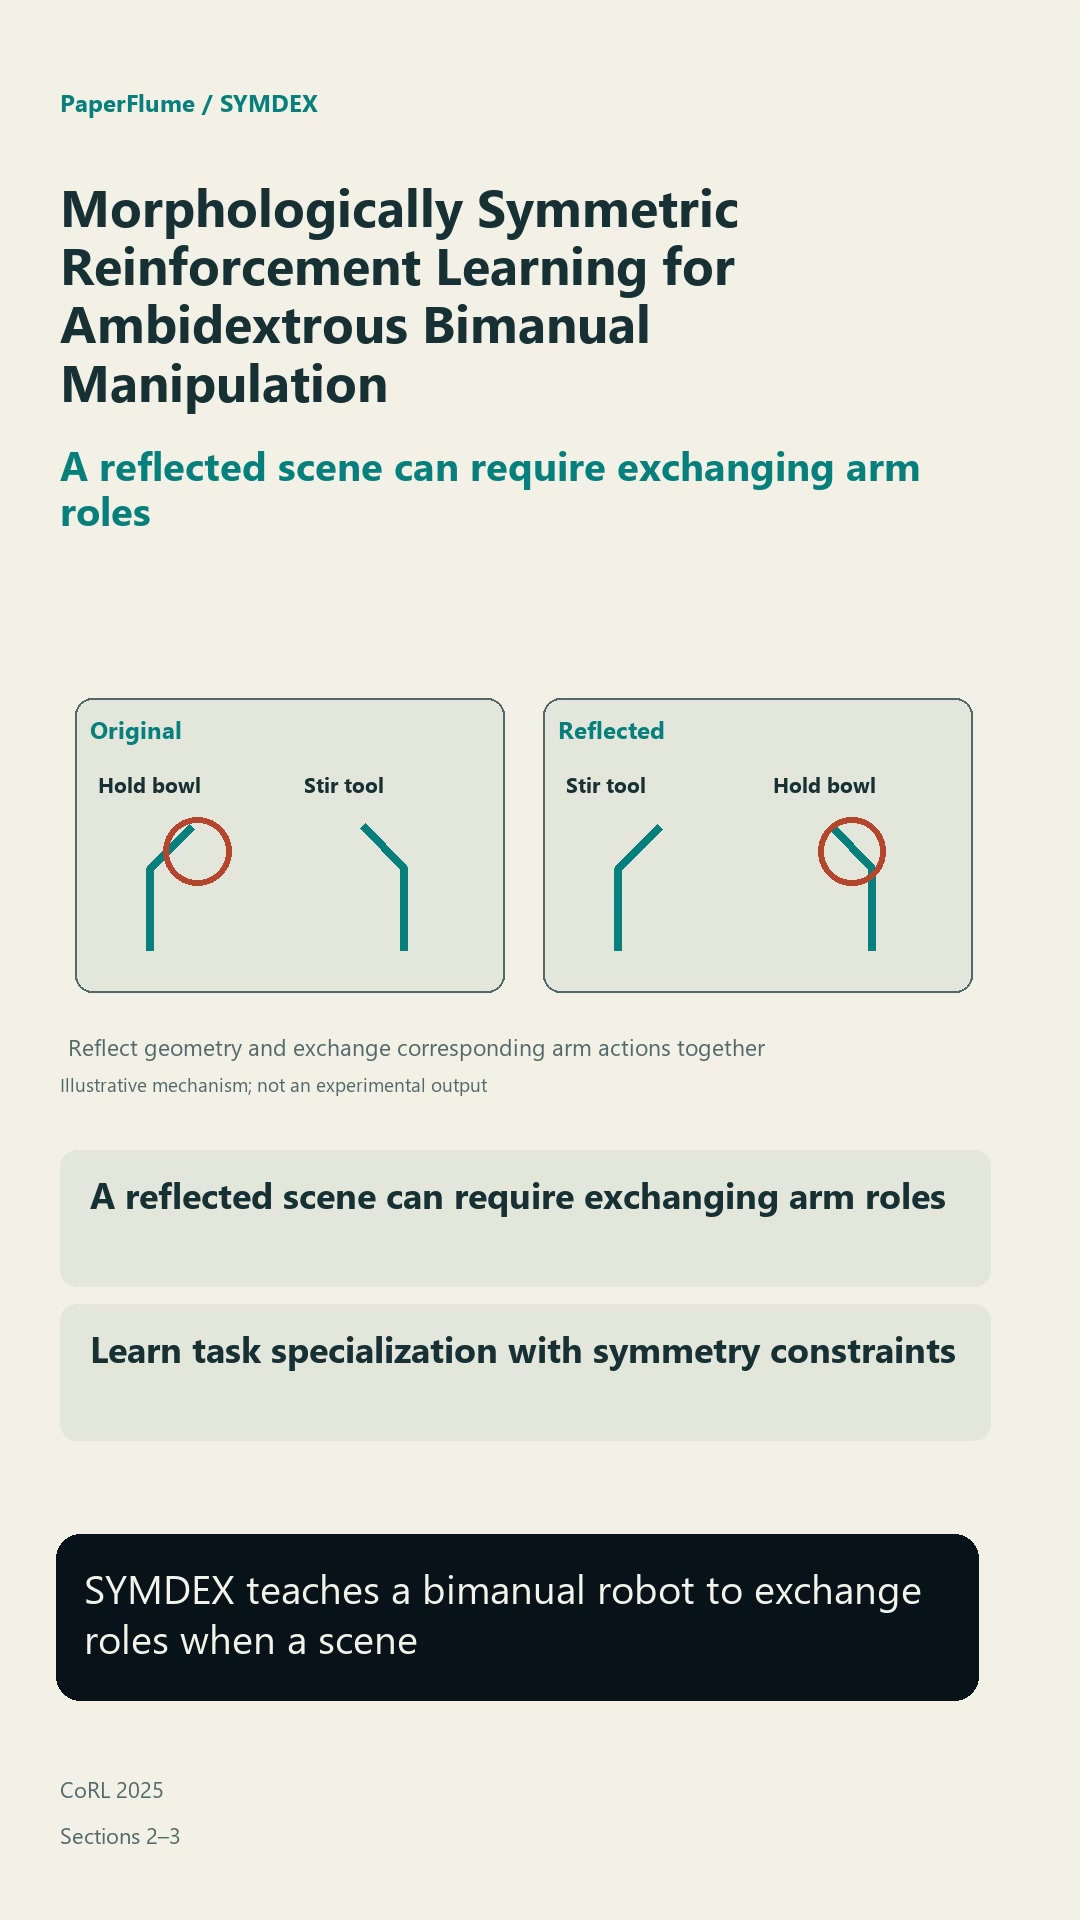 0:37
Morphologically Symmetric Reinforcement Learning for Ambidextrous Bimanual Manipulation
shares RL for control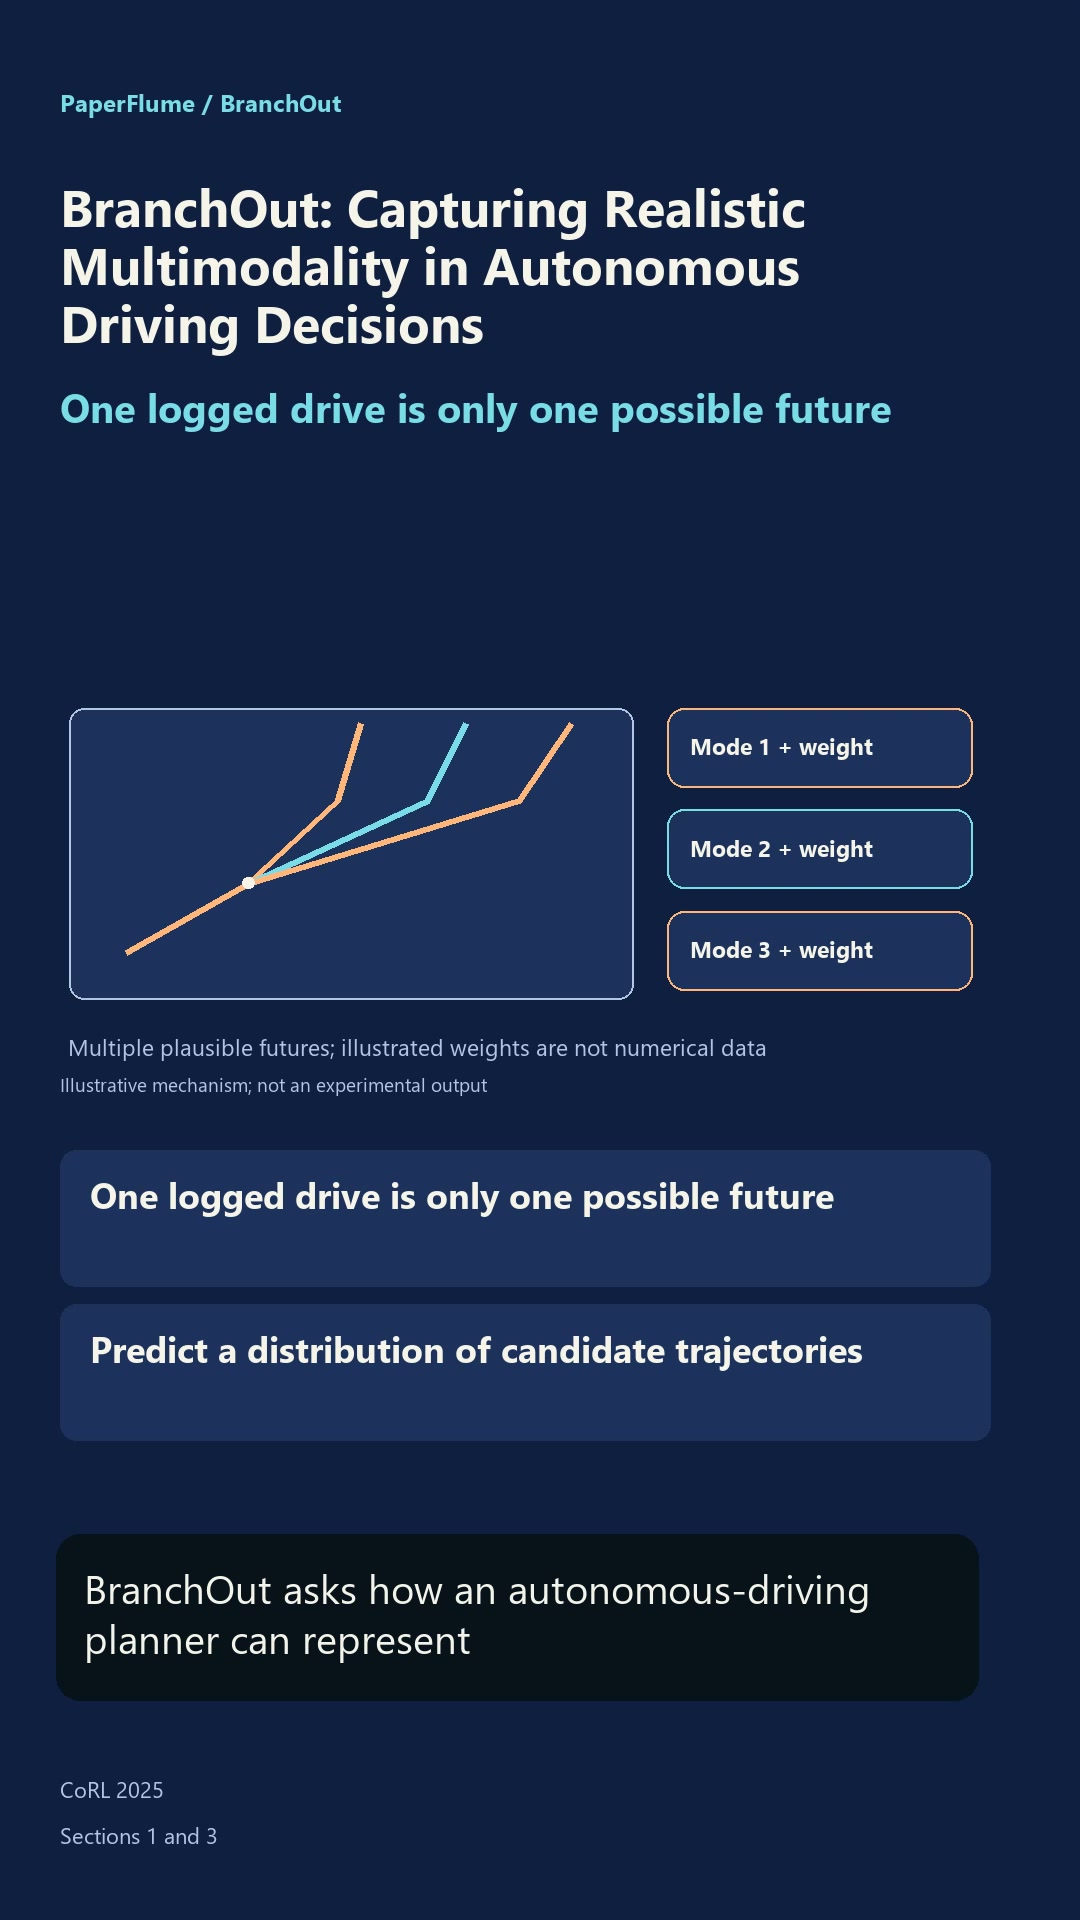 0:35