Next
Papers near this one.
Walkthroughs
 5:47
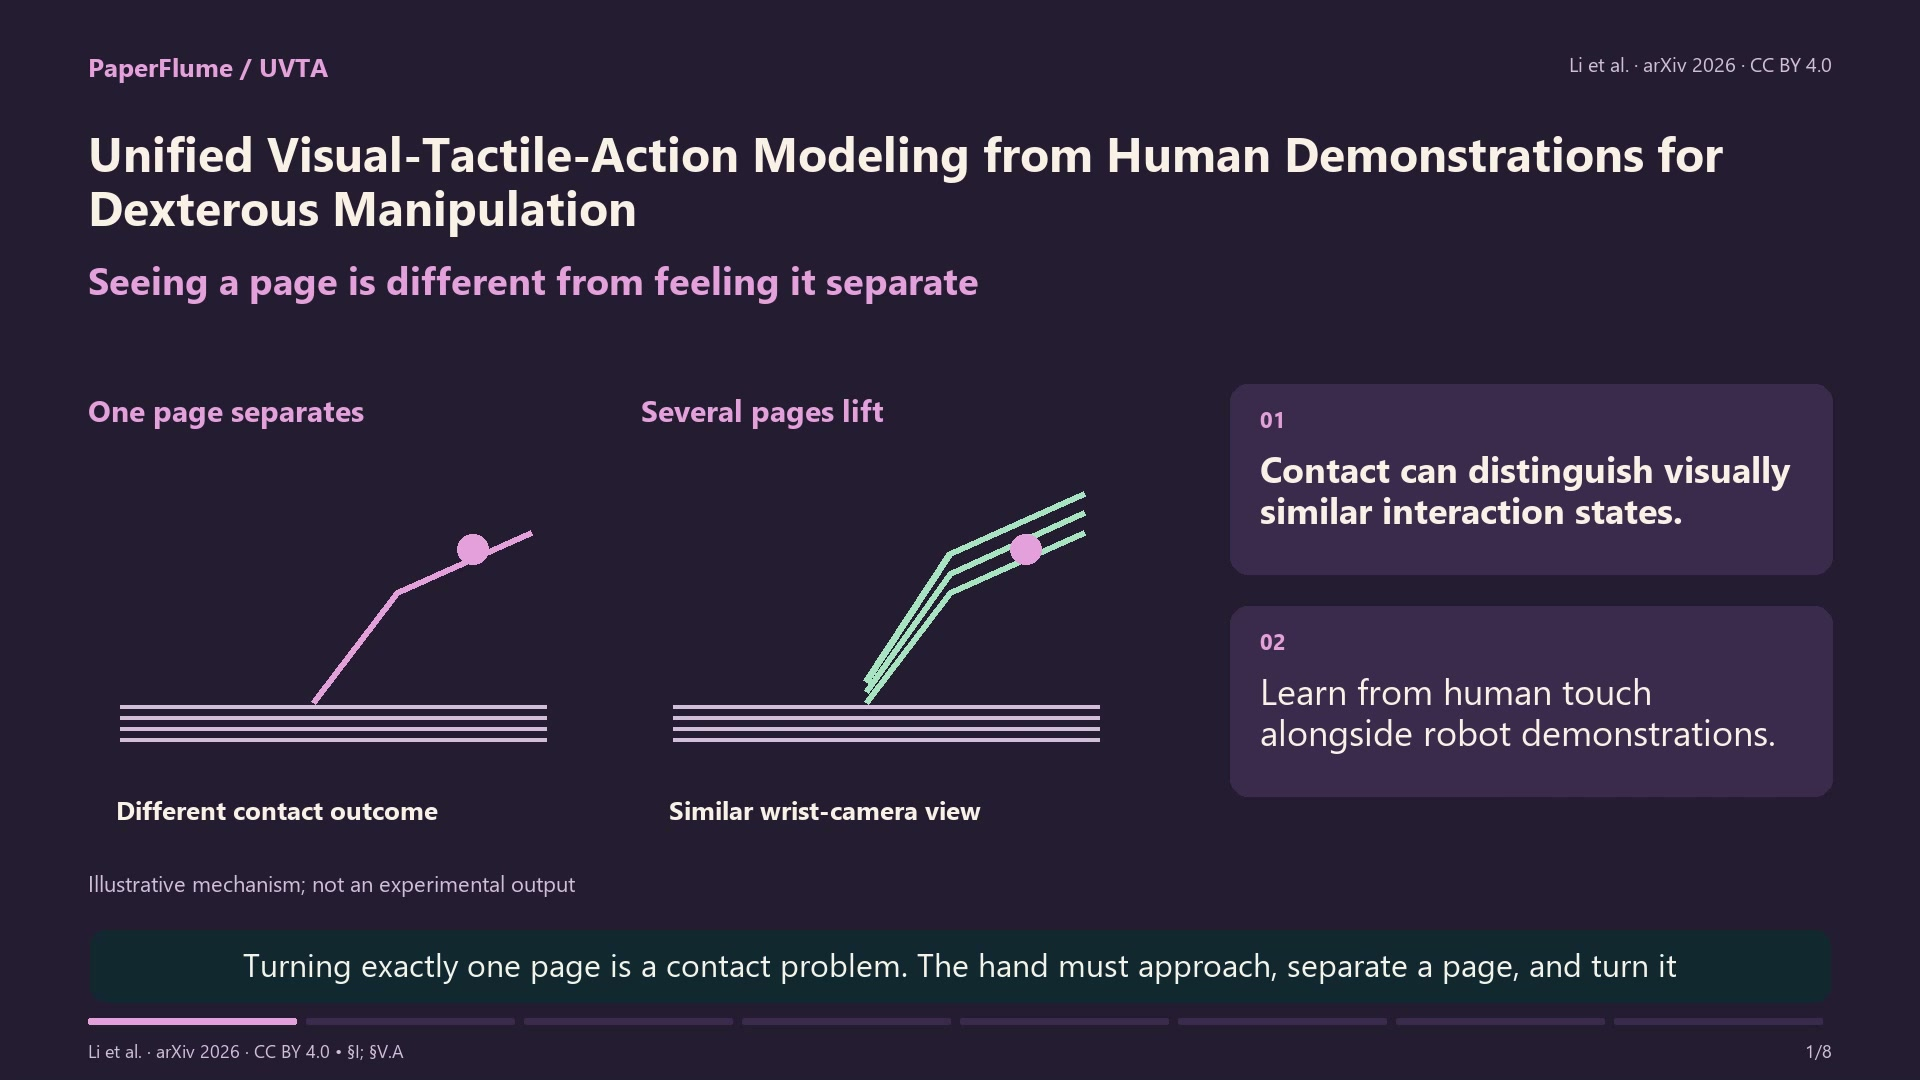
Unified Visual-Tactile-Action Modeling from Human Demonstrations for Dexterous Manipulation
2609.34182
shares Dexterous hands
 5:49
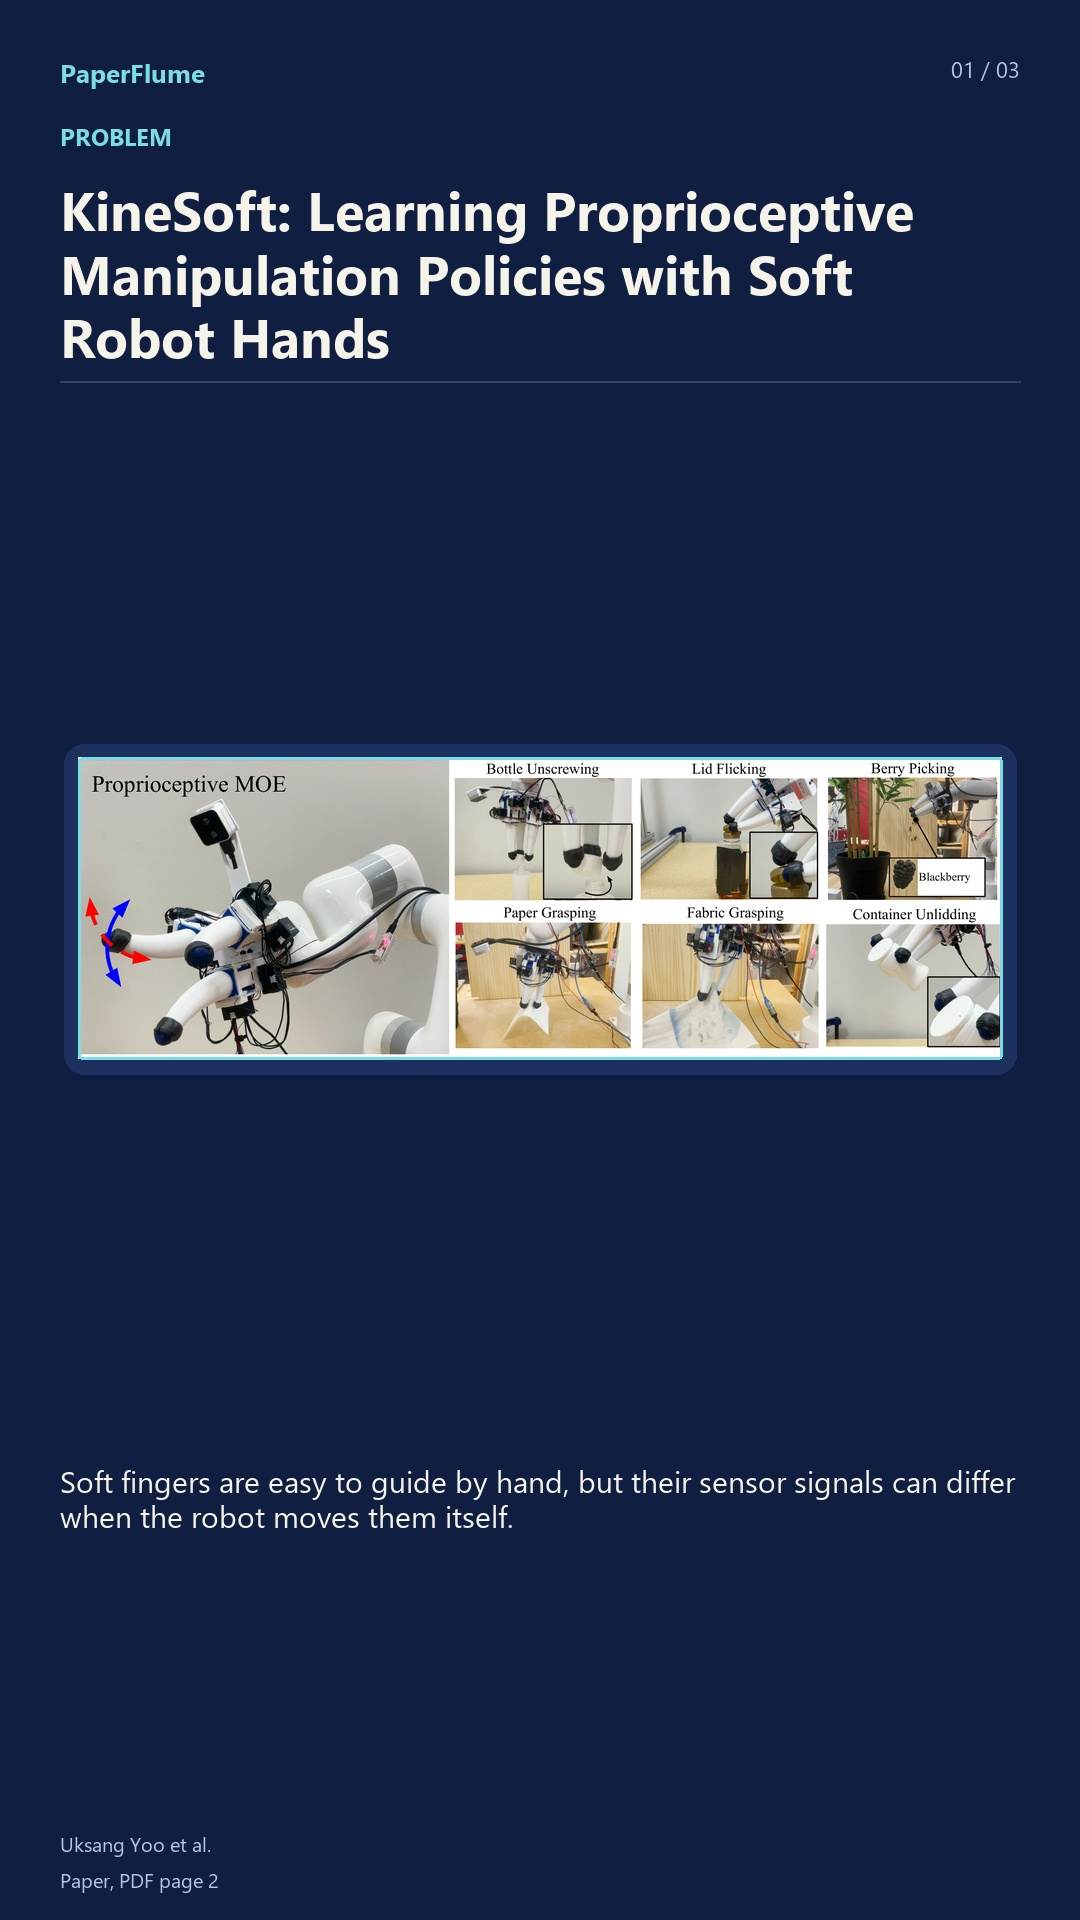
KineSoft: Learning Proprioceptive Manipulation Policies with Soft Robot Hands
shares Dexterous hands 6:50
DexUMI: Using Human Hand as the Universal Manipulation Interface for Dexterous Manipulation
shares Dexterous handsShort cuts
 0:48
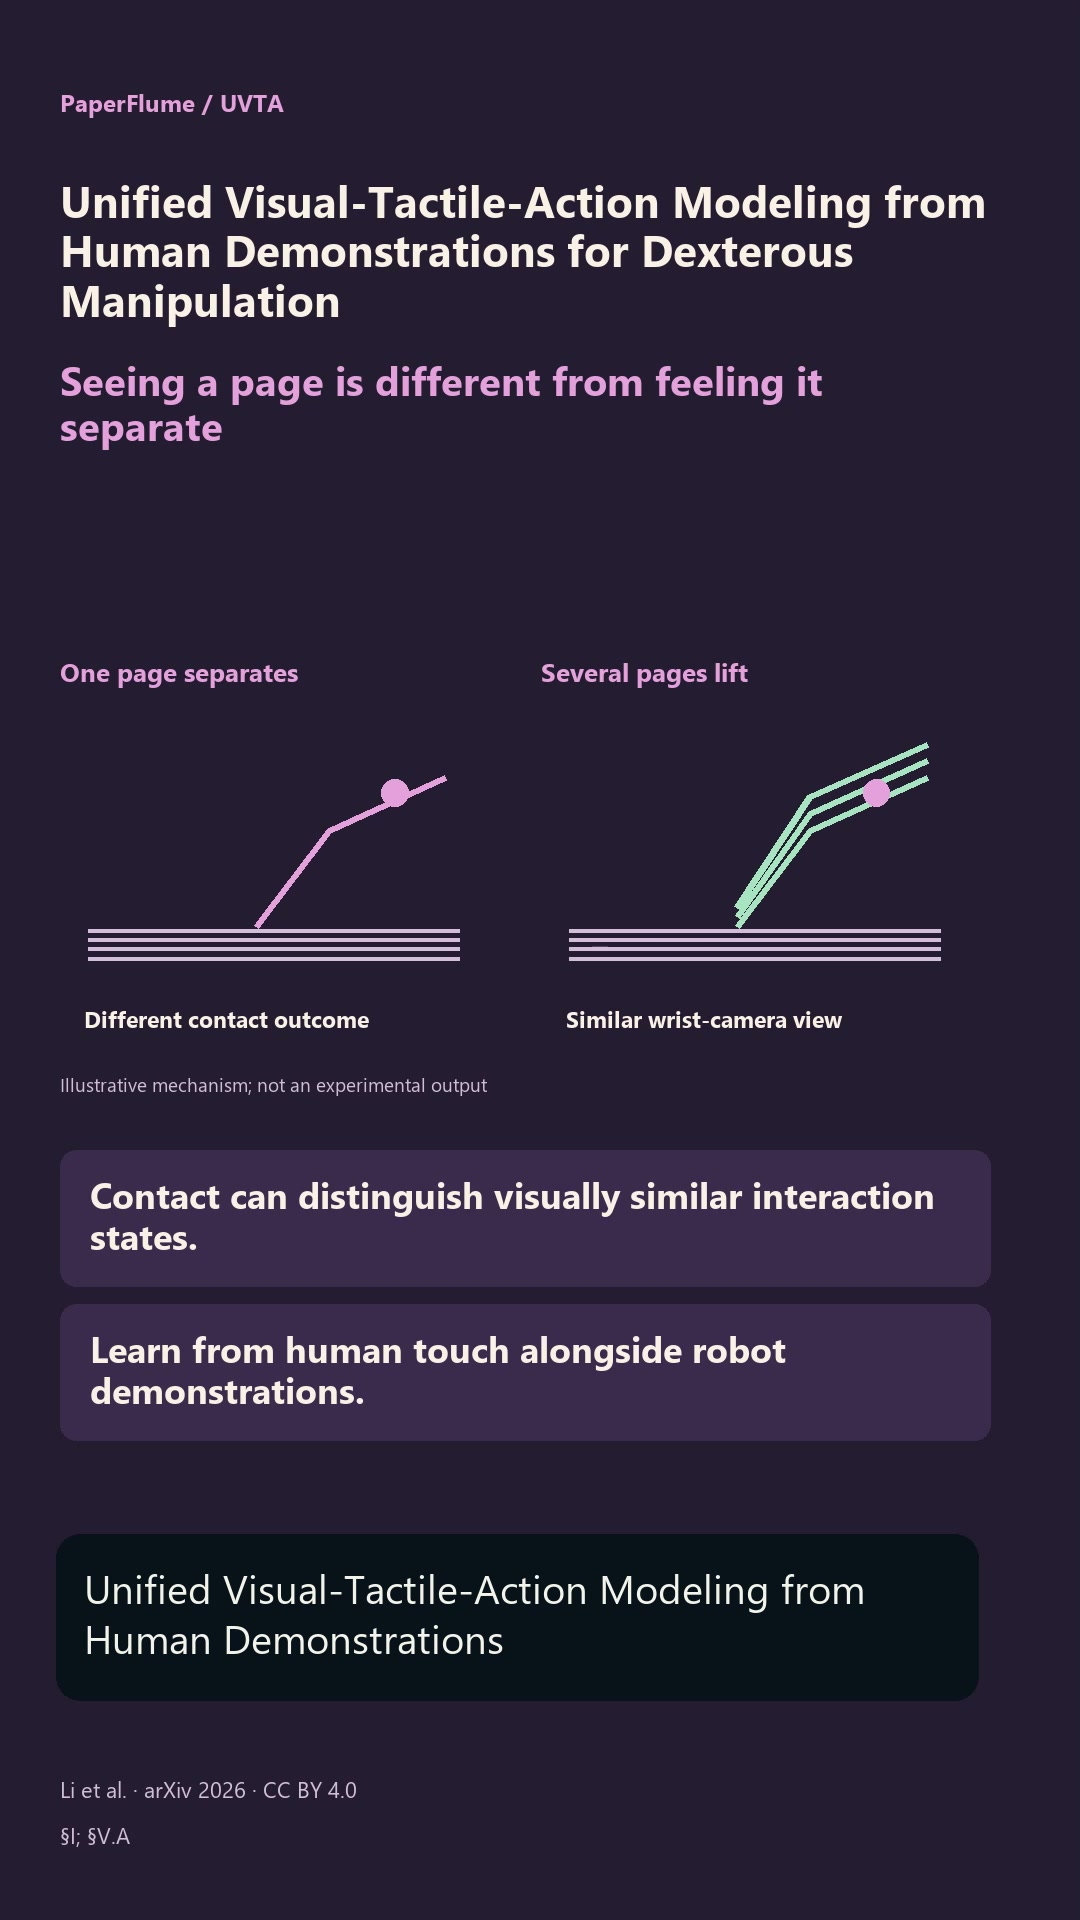
Unified Visual-Tactile-Action Modeling from Human Demonstrations for Dexterous Manipulation
2609.34182
shares Dexterous hands
 1:01
KineSoft: Learning Proprioceptive Manipulation Policies with Soft Robot Hands
shares Dexterous hands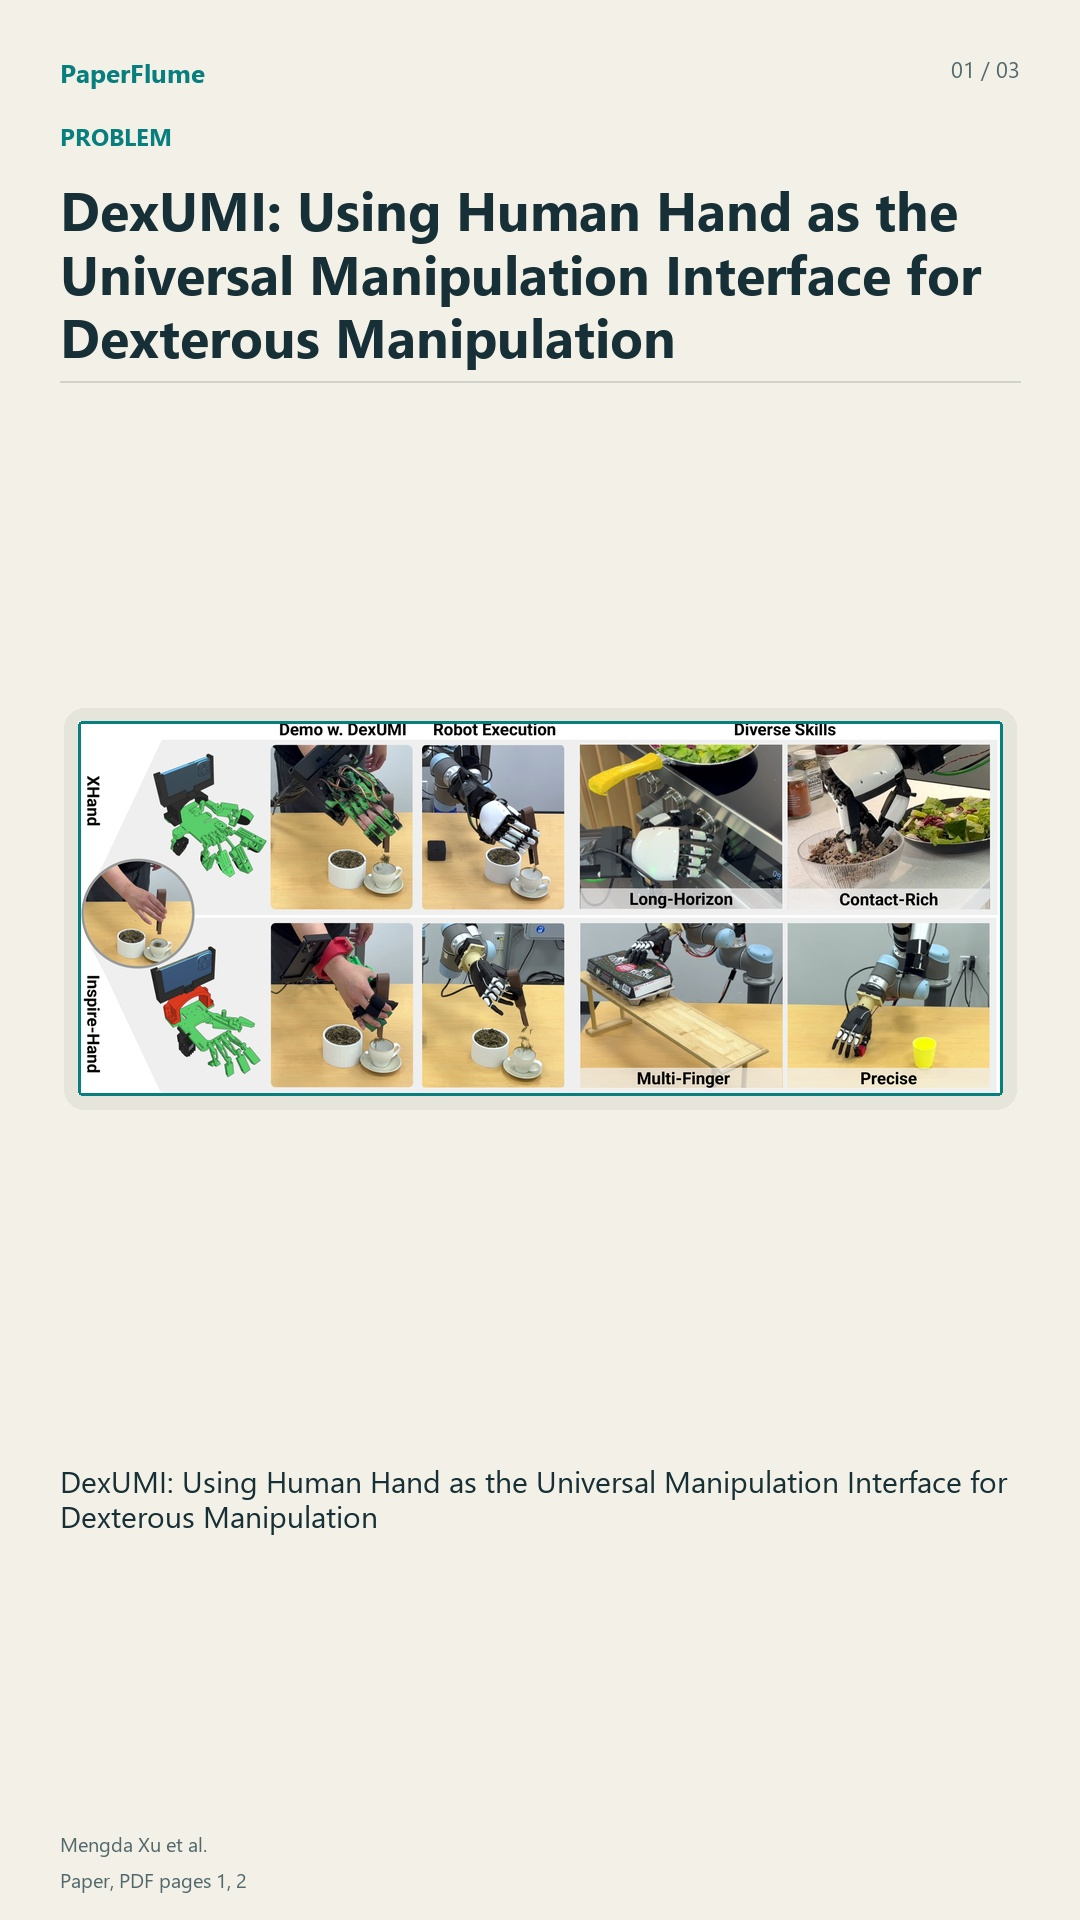 0:52