Next
Papers near this one.
Walkthroughs
 5:32
Multi-critic Learning for Whole-body End-effector Twist Tracking
shares RL for control 5:21
Multi-Loco: Unifying Multi-Embodiment Legged Locomotion via Reinforcement Learning Augmented Diffusion
shares RL for control 10:43
TopoCut: Learning Multi-Step Cutting with Spectral Rewards and Discrete Diffusion Policies
shares RL for controlShort cuts
 0:59
Multi-critic Learning for Whole-body End-effector Twist Tracking
shares RL for control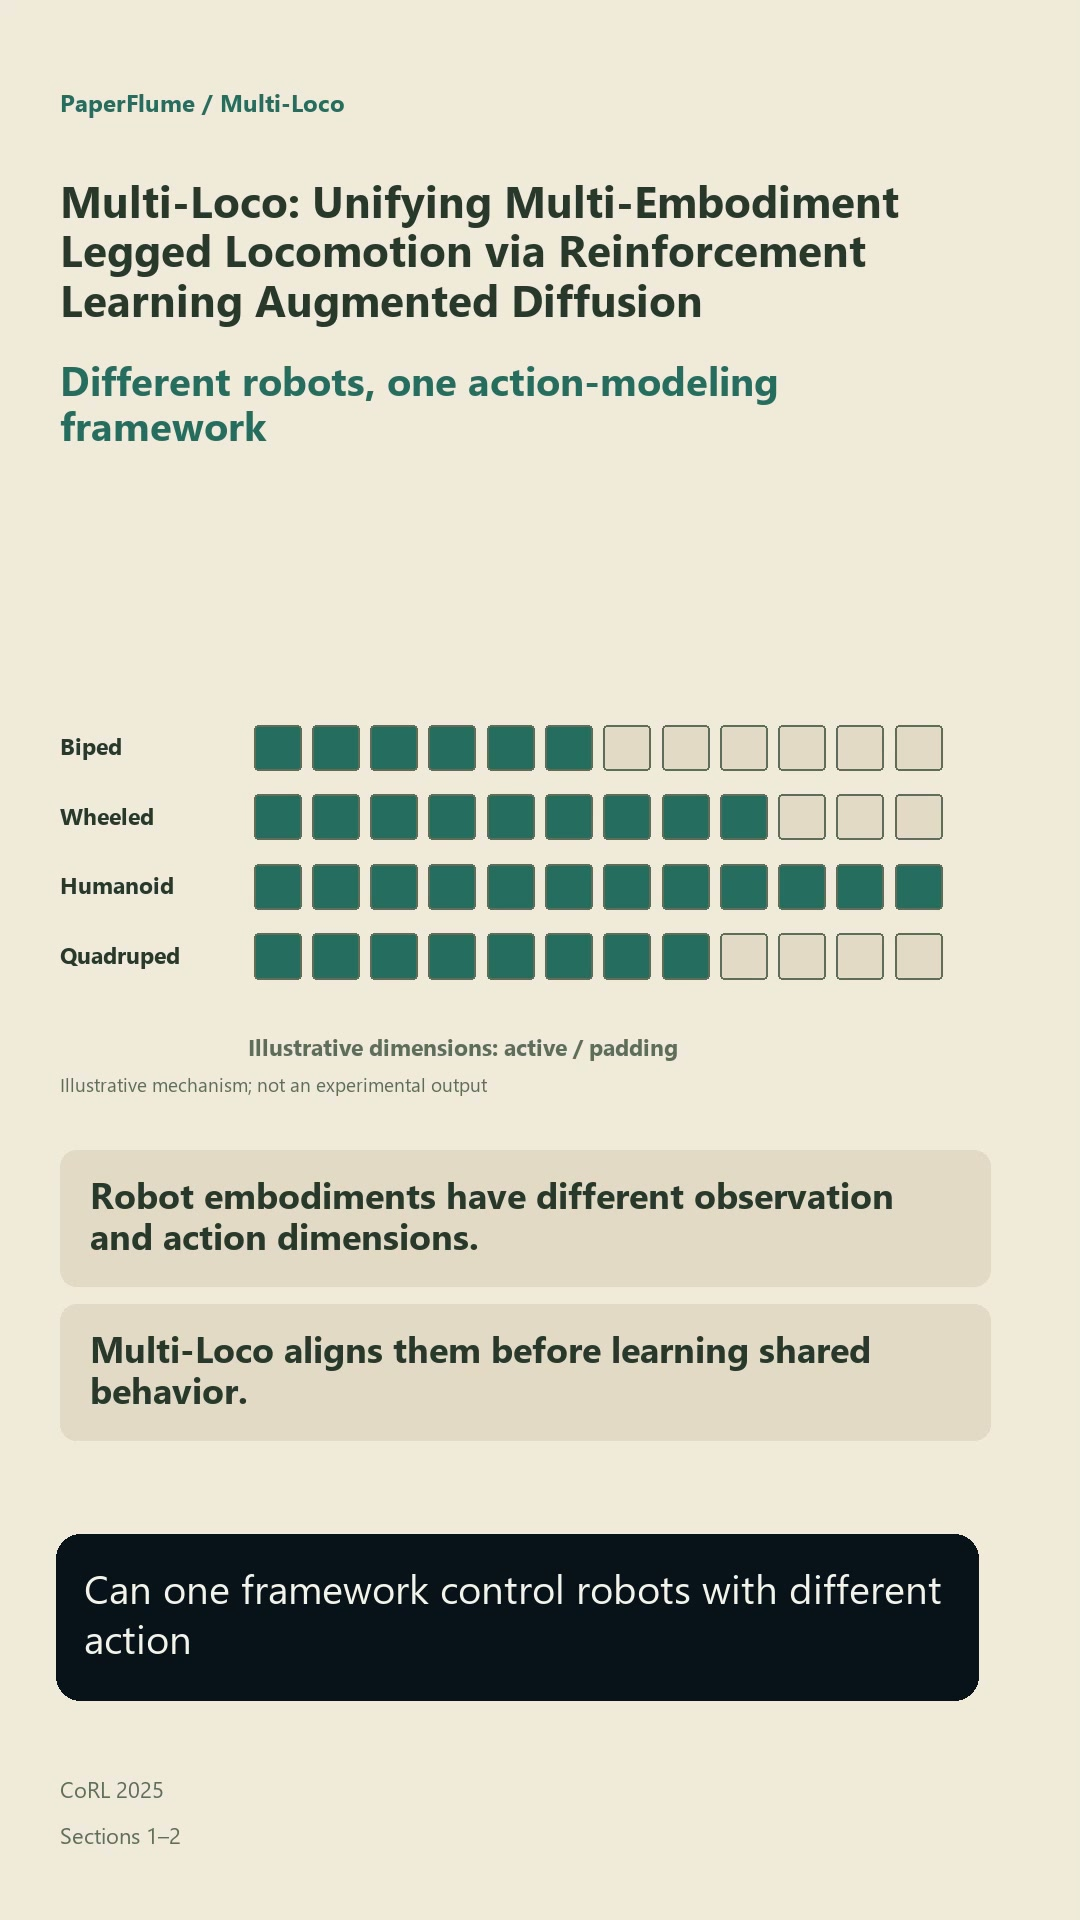 0:58
Multi-Loco: Unifying Multi-Embodiment Legged Locomotion via Reinforcement Learning Augmented Diffusion
shares RL for control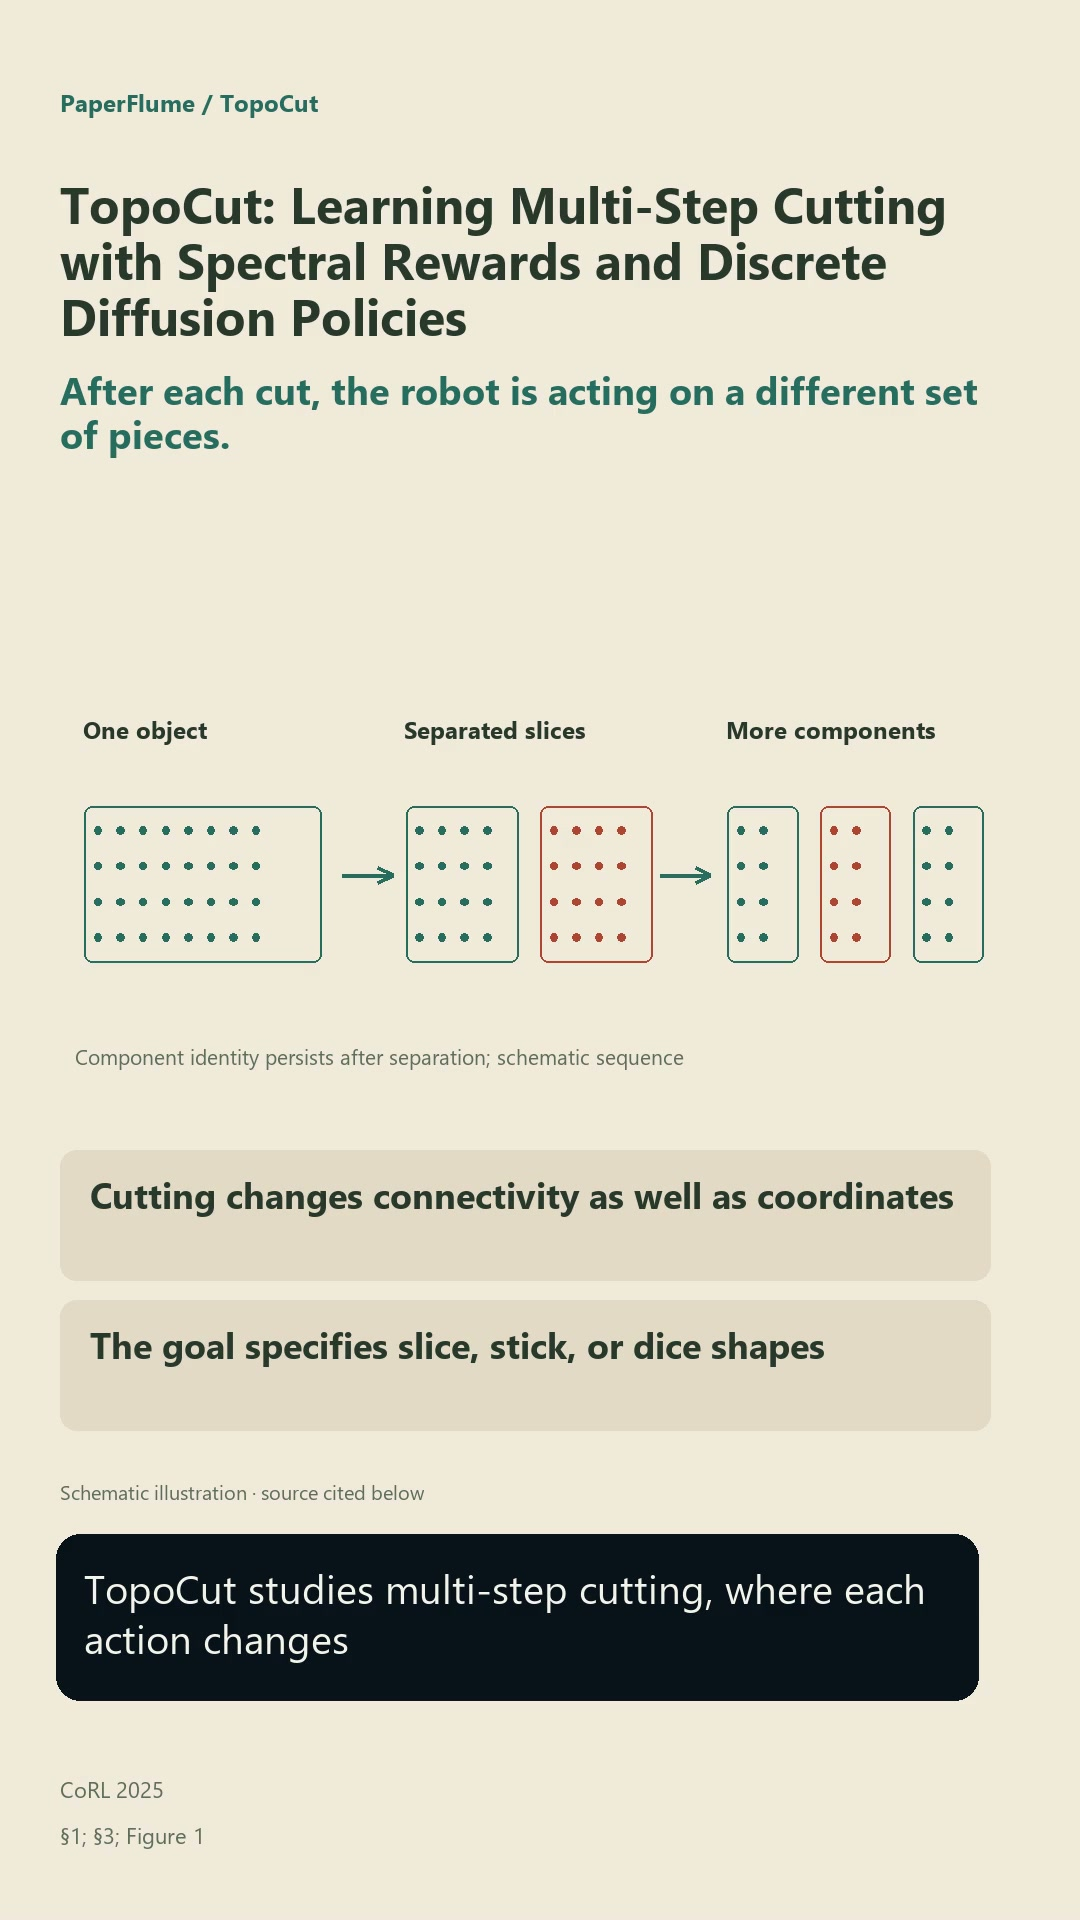 1:21