Next
Papers near this one.
Walkthroughs
 4:25
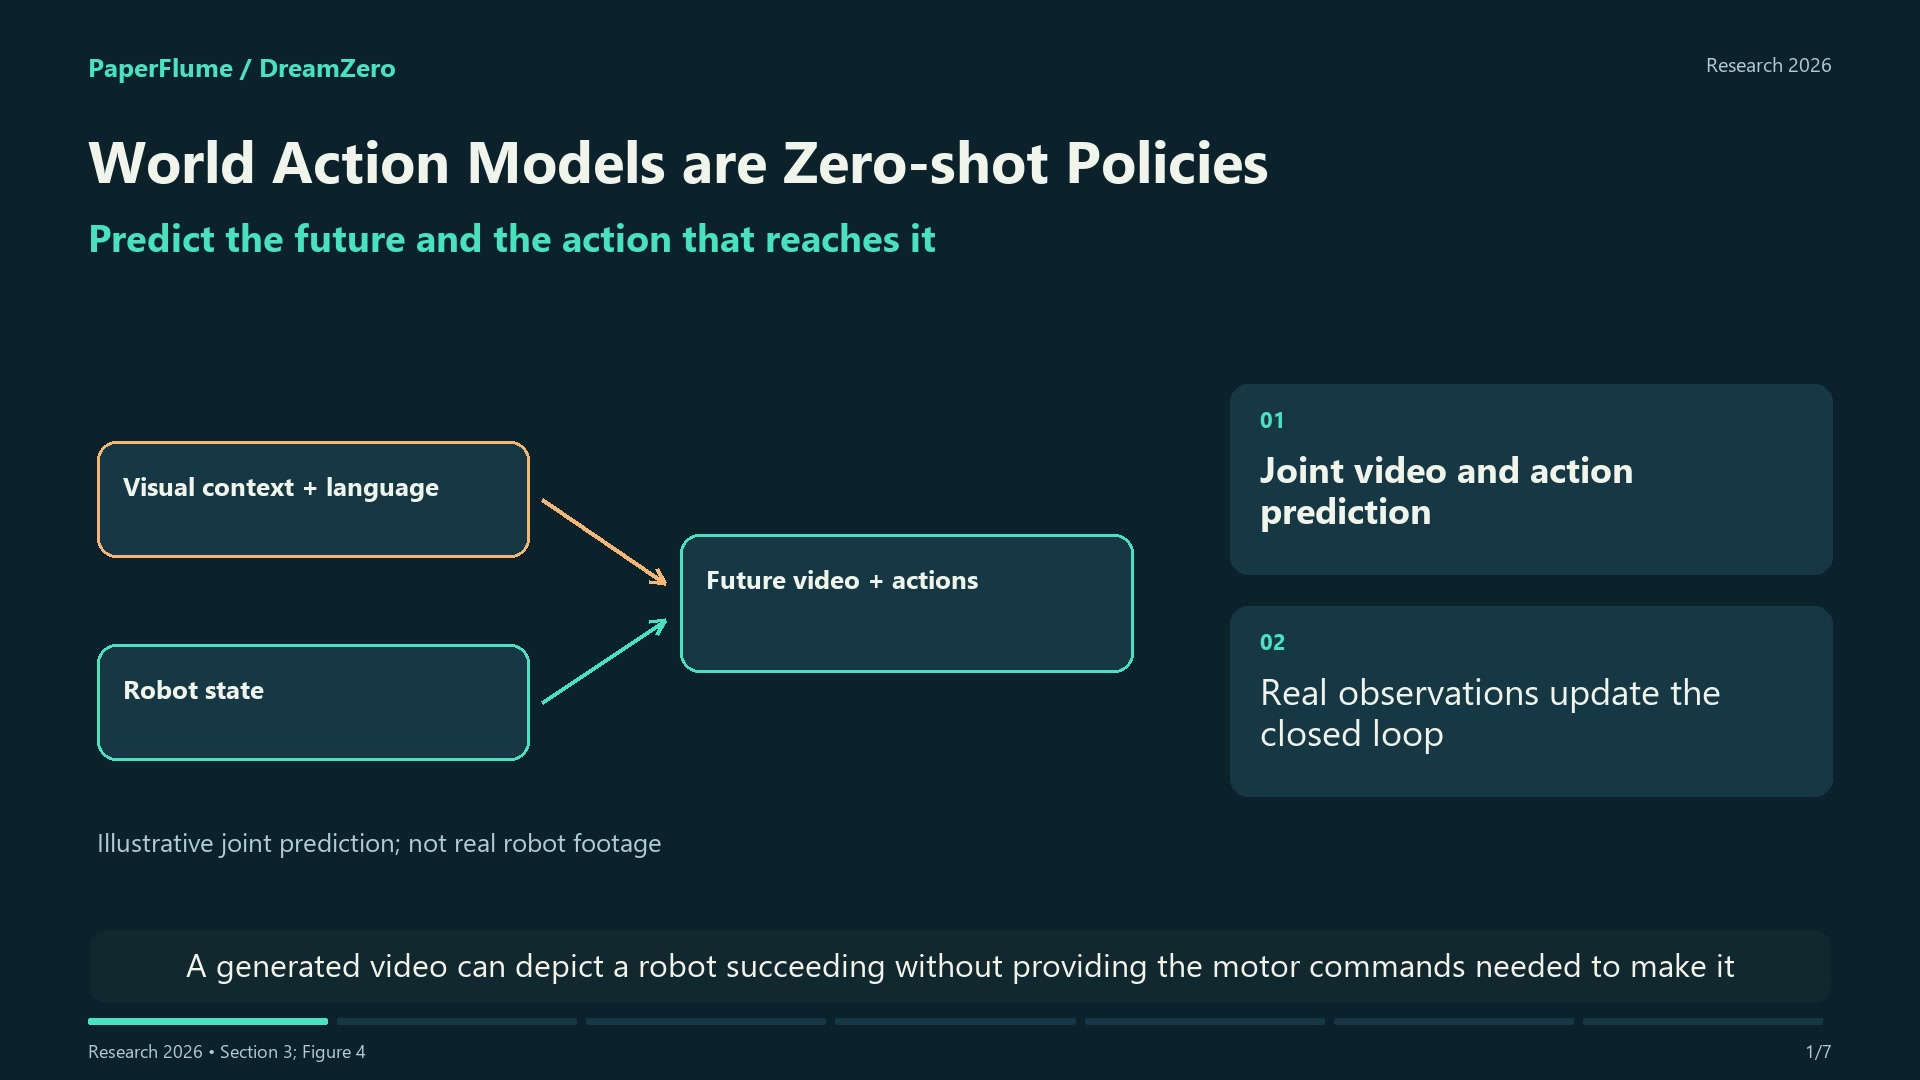
World Action Models are Zero-shot Policies
2602.15922
shares Learning from demonstration
 6:36
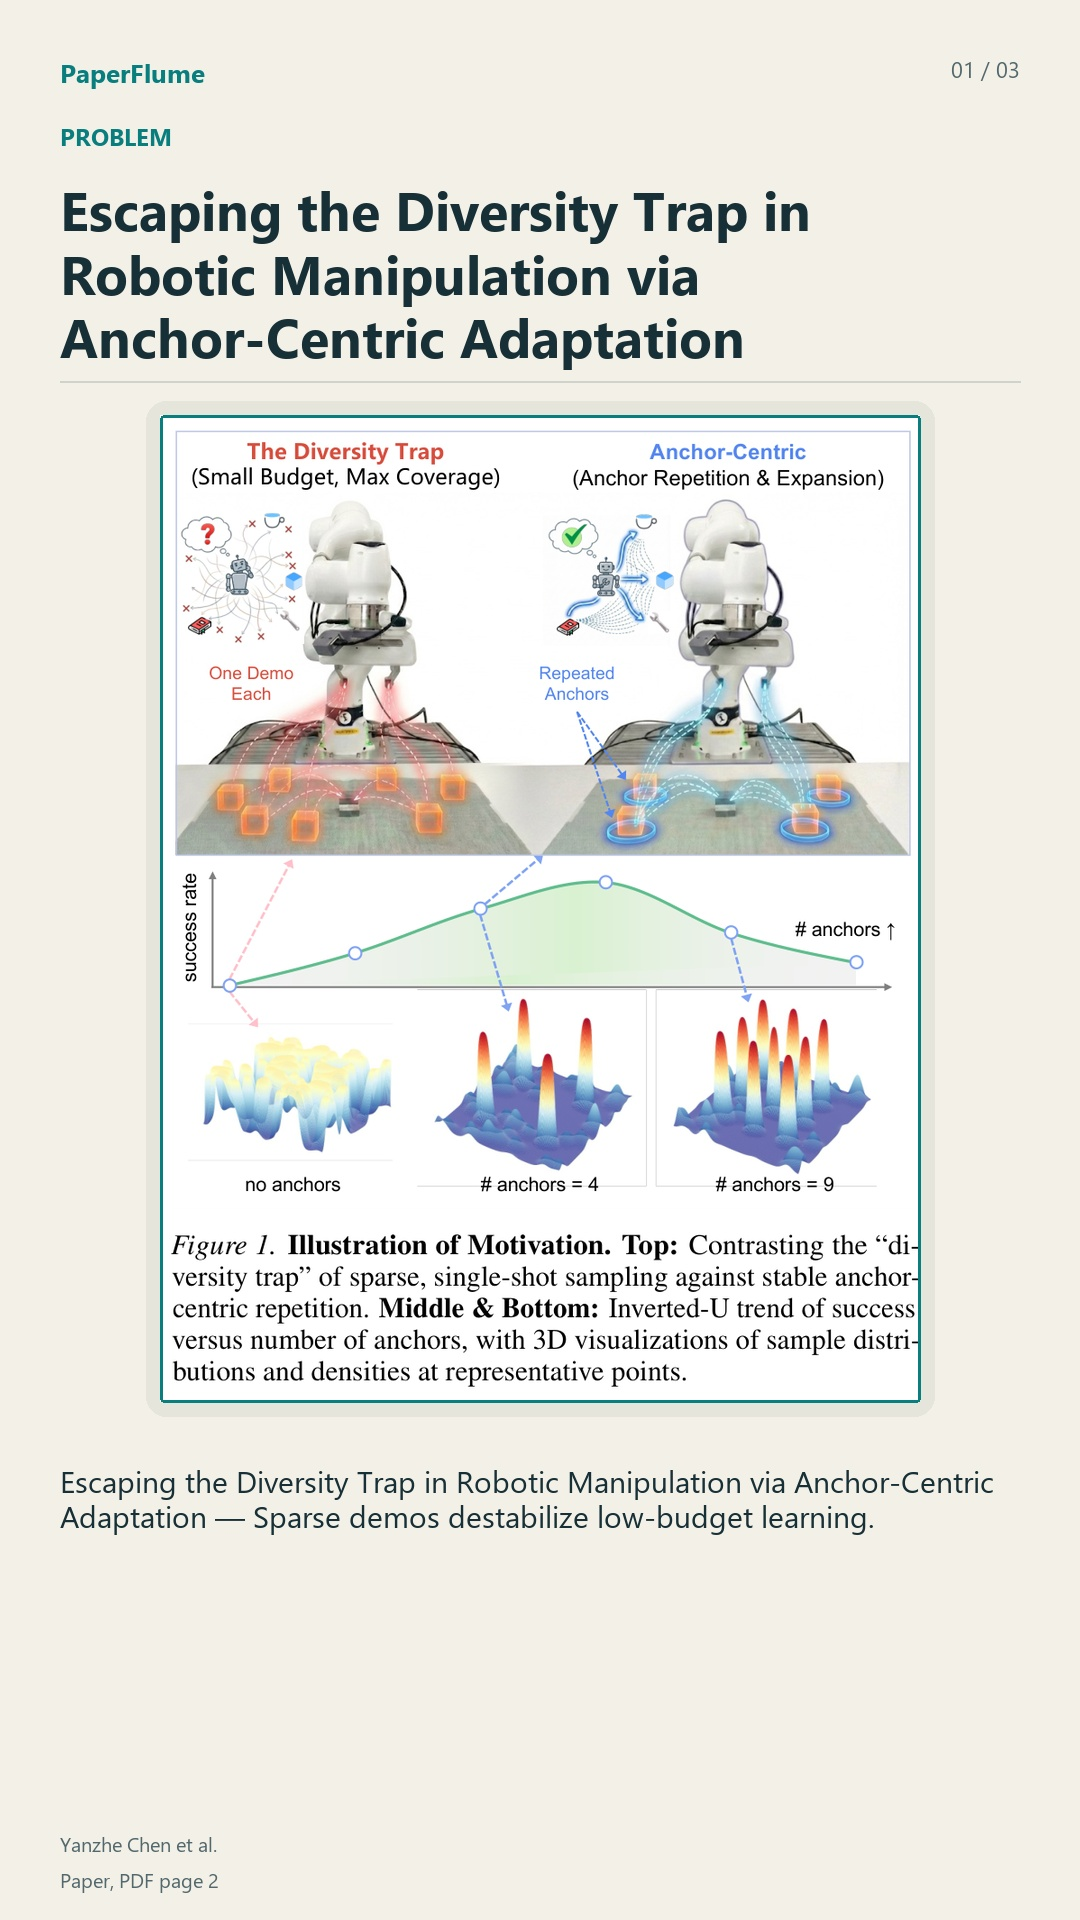
Escaping the Diversity Trap in Robotic Manipulation via Anchor-Centric Adaptation
shares Learning from demonstration 6:58
XR-1: Towards Versatile Vision-Language-Action Models via Learning Unified Vision-Motion Representations
shares Learning from demonstrationShort cuts
 0:44
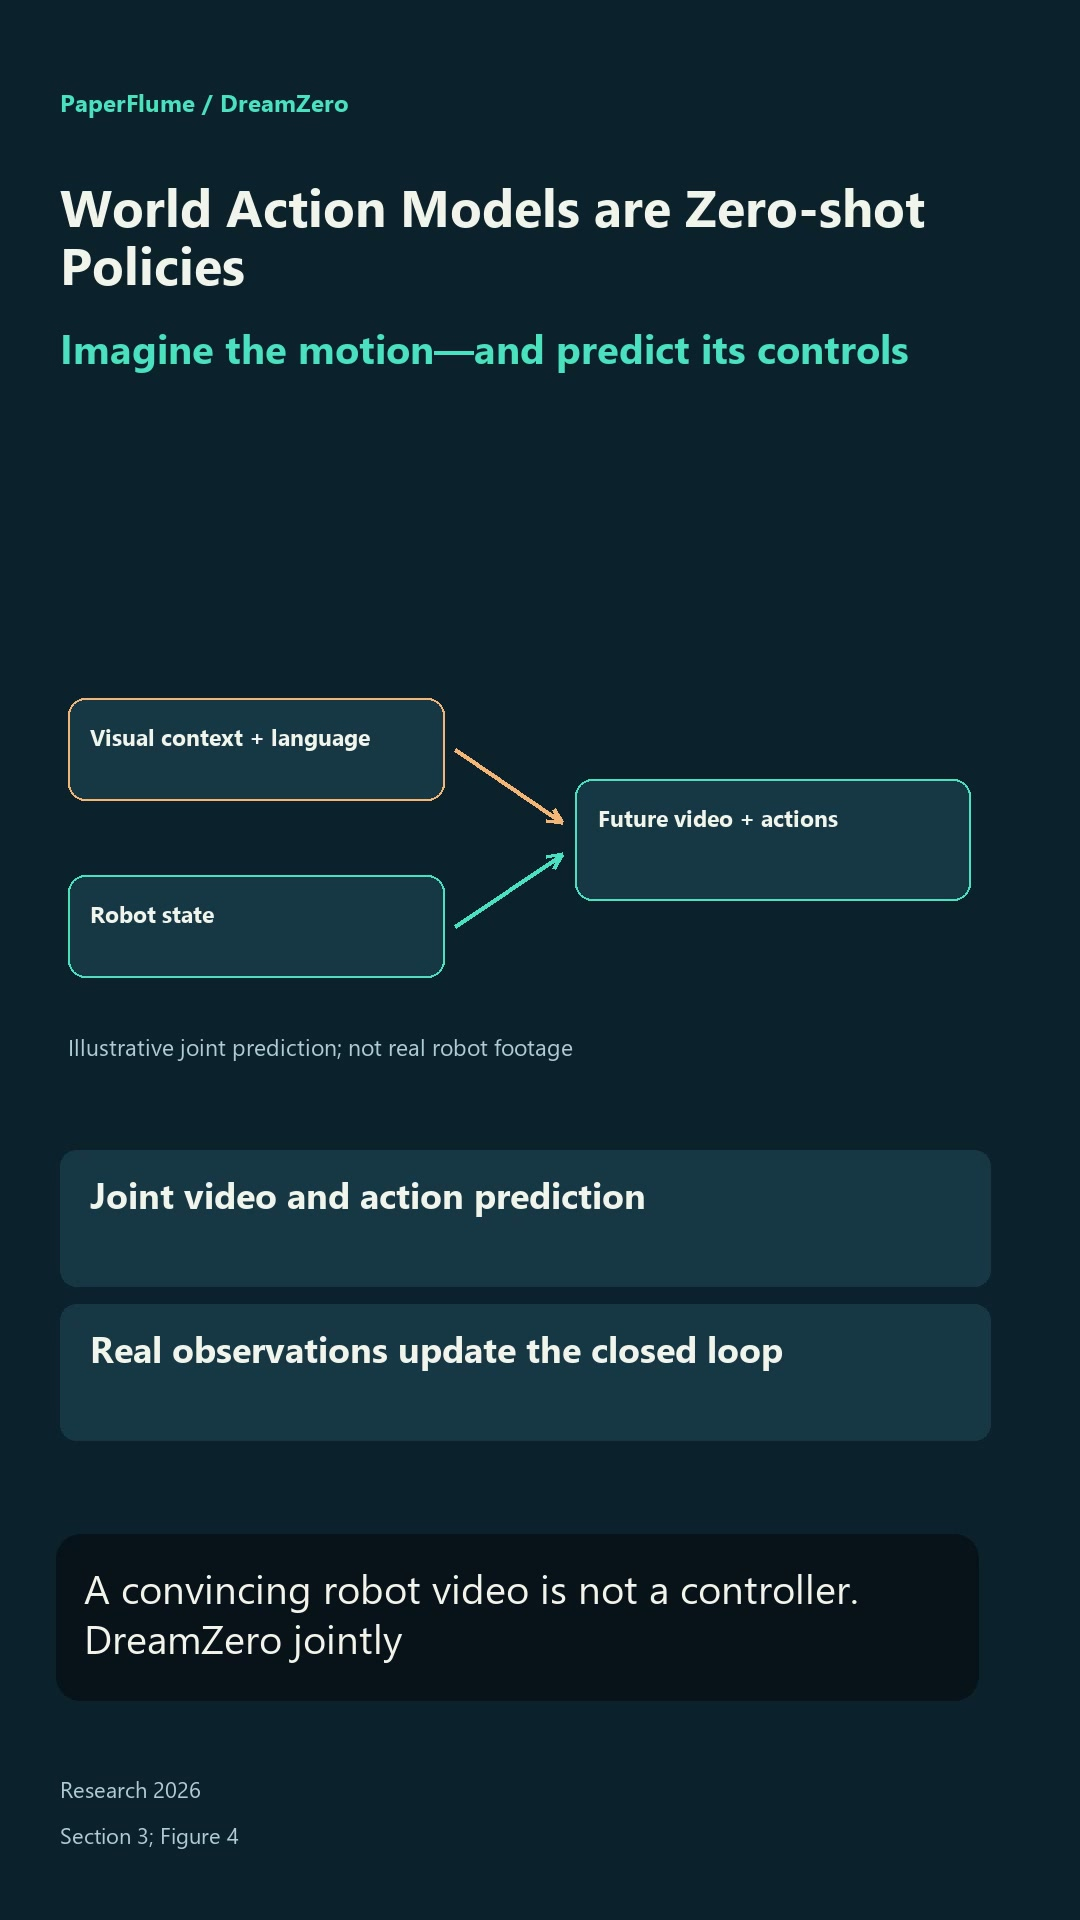
World Action Models are Zero-shot Policies
2602.15922
shares Learning from demonstration
 0:45
Escaping the Diversity Trap in Robotic Manipulation via Anchor-Centric Adaptation
shares Learning from demonstration 0:57